サービスロボット導入シミュレーション Log#10 | ロボットなしなら、Unity と試算は合った
配膳ロボットを入れたファミレスを、Unity(建物や人を3Dで置いて動かせるソフト)の中で動かし、サイトに置いている配膳ロボットの試算( https://pixelstomotors.com/series8 )と同じ数字が出るかを確かめています。試算はロボットや人を点として動かす計算です。Unity は、それを床・卓・人の体のある3Dの店で動かします。同じ店の形・同じ人数・同じ客の数で回し、数字がどれくらい合うかを見ます。
この記事は、その作業の段階Aの終わりから段階Bまでの記録です。段階Aでは、Unity の店を最後まで止まらずに回る状態にしました。段階Bでは、条件を変えて18回まとめて回し、1回1行の台帳にしてサイトの試算と並べました。
段階A Unity の店を作る
- ねらい:ロボット2台の店が、客が全員帰るまで止まらずに回り切ること。ロボットが時間内に卓へ届けられない往復(時間切れ)と、店が止まらないように Unity に入れている逃がし弁(待ちきれない客を帰す・動けない人を移す・卓を空ける)を、ほぼ0にすること
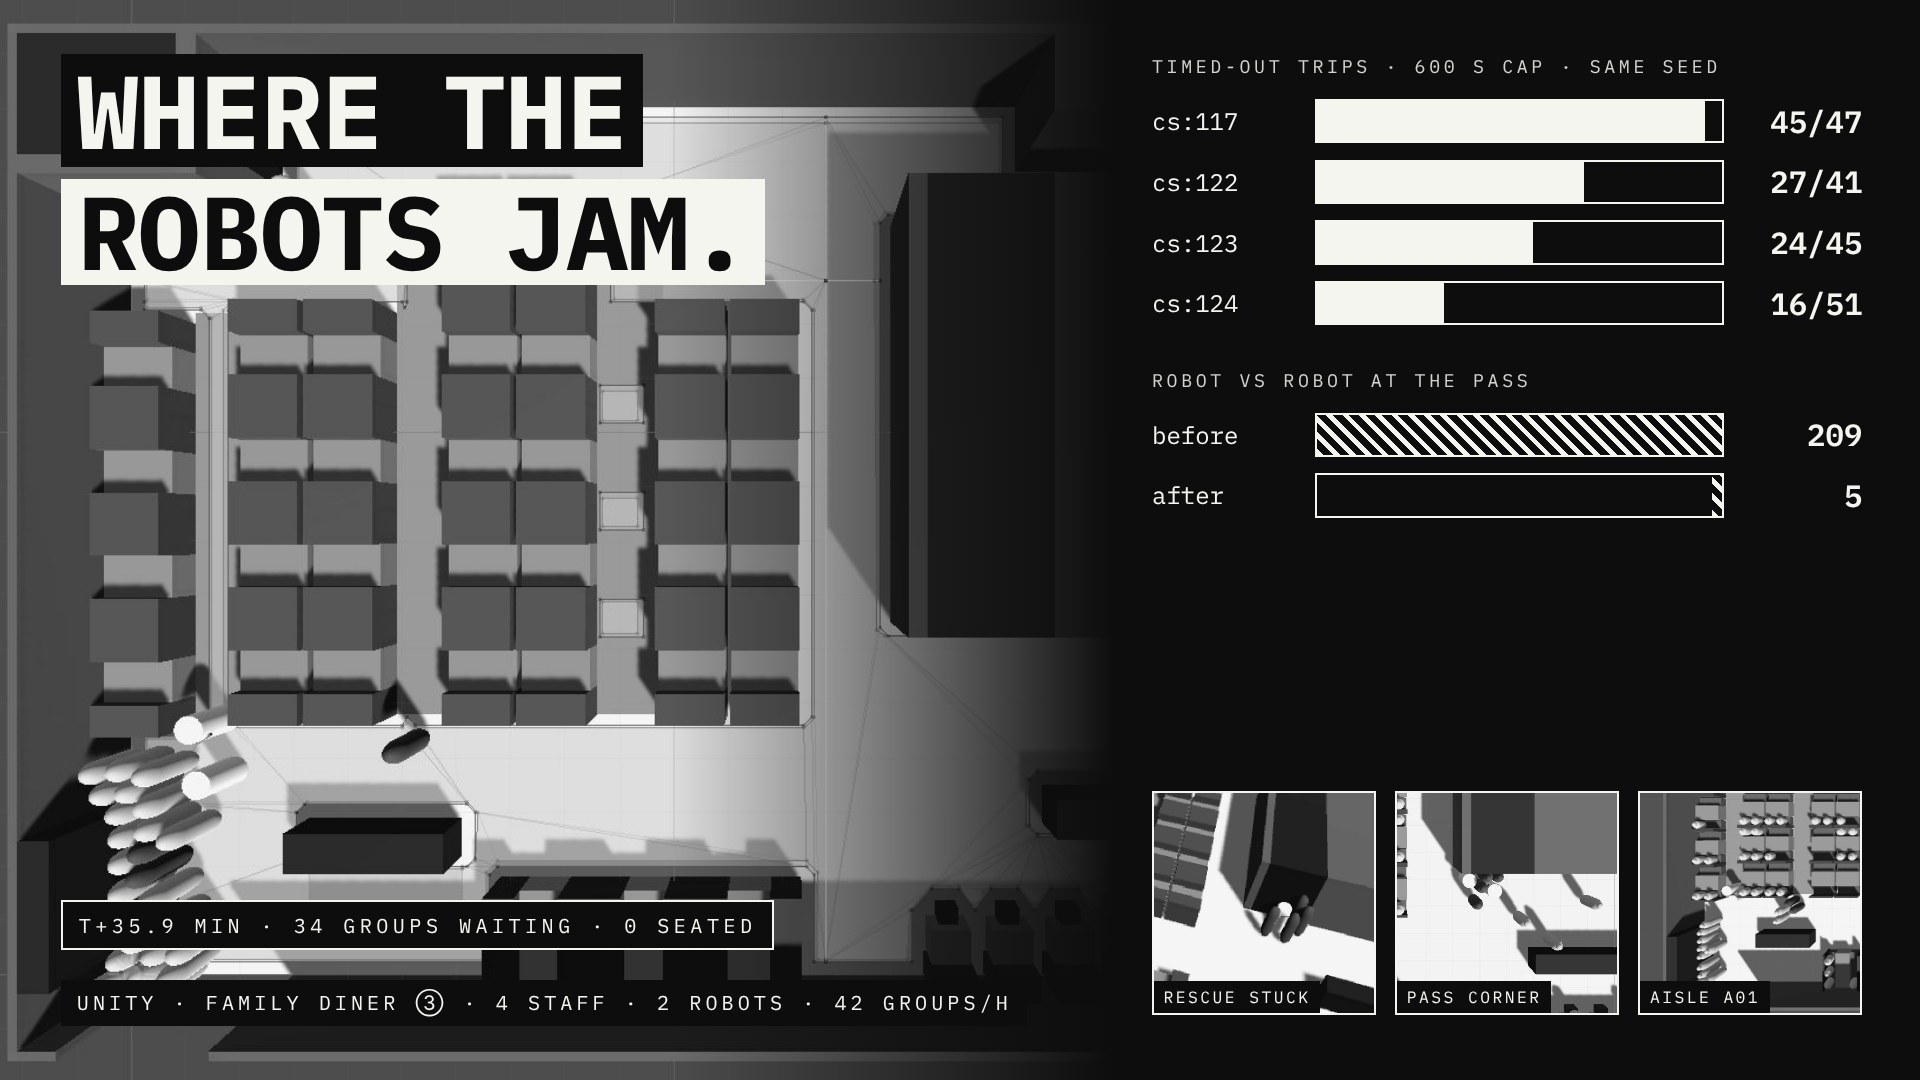
- 結果:③⑦とも、全員が帰るまで回り切った。③の店で直す前の回と最後の回を比べると、時間切れの往復は31%(51回のうち16)から7%(92回のうち6)に、ロボットが運んだ料理は32%から68%になった。逃がし弁は303回から218回に減ったが、0にはならなかった。直すたびに詰まる場所が移るので、先に決めておいた区切りで直すのをやめた
段階B 回して台帳にまとめる
- ねらい:店2つ×ロボット0・1・2台×乱数3通りの18回を、夜のうちに手を入れずに回し、1回ごとに台帳へ1行を書くこと。サイトの試算とどこがずれるかを言えるようにすること
- 結果:18回すべて回り切り、3時間で台帳に18行がそろった。ロボットなしでは、料理ができてから卓に届くまでの待ちが、試算と平均0.2〜0.4分しか違わない。ロボットを入れると Unity は3.5〜4.5分で、試算(ロボット2台で1.0分)より大きく延びた
人だけで回す部分は試算とほぼ合っていて、ずれはロボットを入れたときにだけ出る。差の原因は、ロボットの動きの側に絞れました。
段階Bの18回を、条件ごとに3回の平均で並べるとこうなります。
| 3回の平均 | 料理の待ち(Unity / 試算) | 入店待ち(Unity / 試算) | ロボットが運んだ料理の割合(Unity / 試算) |
|---|---|---|---|
| ③ ロボットなし | 0.9分 / 0.7分 | 2.7分 / 3.2分 | ― |
| ③ ロボット1台 | 3.6分 / 2.0分 | 3.7分 / 1.6分 | 64% / 73% |
| ③ ロボット2台 | 4.5分 / 1.0分 | 4.8分 / 0.8分 | 68% / 99% |
| ⑦ ロボットなし | 1.1分 / 0.7分 | 2.7分 / 4.4分 | ― |
| ⑦ ロボット1台 | 3.7分 / 2.1分 | 7.9分 / 1.3分 | 62% / 72% |
| ⑦ ロボット2台 | 3.5分 / 1.0分 | 9.9分 / 1.6分 | 77% / 99% |
③は卓42・席160の店で、客席の列のあいだの通路が1.2mあります。⑦は卓と席を③と同じにしたまま、その通路を0.95mに狭めた店です。どちらもスタッフ4人、1時間に42組の客が来て、ロボットは料理を運ぶだけです。
段階Aで直したのは、次の5つです。ロボットが運んだ料理が増えたのは、Unity の詰まりを直したことに加えて、料理をロボット優先で割り当てる決まりに変えたためでもあります。
| 直したこと | なぜ | 結果 |
|---|---|---|
同じ通路の卓に2台を向かわせない | 左の通路の入口で2台が鉢合わせていた(79回) | 鉢合わせは0回に |
レジで通路を狭くしない(会計の列にロボットを通さない) | 会計に並ぶ客が、ロボットの通る道の上に立っていた | レジのまわりの止まりが112回から31回に |
⑦の細い通路を0.8mから0.95mに | 0.8mではロボットがほとんど動けなかった | 細い通路を通る往復が29回できた |
料理はロボット優先。2分待っても来なければ人が運ぶ | ロボットを入れたのに、受け渡し口の横にいる人が先に運んでいた | 試算でロボットが運ぶ割合が69%から85%に |
譲る順番をロボット>スタッフ>客に。譲る側は道から横へどく | 厨房の角で、ロボットと人が向かい合ったまま止まっていた | 角で止まる時間の割合が32%から12%に |
下の図で、店とロボットの台数を切り替えると、3回それぞれの値とサイトの試算を並べて見られます。
ロボットなしの回では Unity の方が入店待ちが短く、ロボットを入れると Unity の方がずっと長くなります。入店待ちは同じ条件でも回によって1.8分から15分までぶれるので、3回だけでは言い切れません。料理の待ちは3回ともほぼ同じ値に収まっています。次は、ロボットが運んだ料理の待ちを、料理がロボットを待っていた時間と、運んでいる途中の時間に分け、試算が前提にしているロボットの速さや止まる回数と並べます。
作業ログ ― この記事で扱う範囲と、Unity の版
前の記事(LOG364)は、③の店で5回回して、詰まりを1つずつ直したところで終わりました。そのとき、直すのは区切りで止めて、次の段階へ進みながら2つ(同じ通路に2台を集めない、レジで通路を狭くしない)を直すと決めていました。この記事はその続きで、Unity の作りを cs:139 で固めてから、cs:140 で18回をまとめて回したところまでです。
この研究の進め方は3段階に分けています。
| 段階 | やること | この記事の時点 |
|---|---|---|
| A. 店を作る | ③⑦を Unity で建て、最後まで回り切らせる | cs:139 で終わり |
| B. 回して台帳にまとめる | 条件ごとに回し、1回ごとに台帳へ1行 | 18回を回し終えた |
| C. ずれを調べる | サイトと Unity の数字を並べ、ずれの理由を分ける | 次 |
Unity のコードは Claude Code(Unity のコードを書く AI)が書き、Claude が記録を読んで原因を調べ、依頼文を作りました。サイトの試算と店の形は Claude が直しています。Unity のメニューを押して回すのと、画面を見て詰まりに気づくのは手で行いました。Unity の版は、Unity Version Control の Check-in の番号(cs:125〜cs:140)で書きます。
| Check-in | 中身 | 動きが変わったか |
|---|---|---|
| cs:125 | 同じ通路に2台を集めない。③⑦を新しい店の形(レジの直し)で建て直す | 変わった |
| cs:126 | 店員優先のよけ方(切り替え。既定は切)と、キッチンのモニター | 切り替えたときだけ |
| cs:127〜cs:133 | キッチンのモニターの見た目(板 → 吹き出し → 画面に貼るパネル) | 変わらない |
| cs:134 | ⑦を新しい店の形(細い通路0.95m)で建て直す。床の色をサイトの図面から塗る | 変わらない |
| cs:135 | ⑦の設定ファイルに残っていた0.8mを直す | 変わらない |
| cs:136 | Unity Version Control にたまっていた保留の変更を整理 | 変わらない |
| cs:137 | 料理はロボット優先(120秒) | 変わった |
| cs:138 | 譲る順番 ロボット>スタッフ>客、譲る側は道から横へどく | 変わった |
| cs:139 | スタッフが譲るのは、ロボットの進む先にいるときだけ | 変わった |
| cs:140 | 18回をまとめて回す仕組みと台帳 | 変わらない |
cs:130 は、この作業の中では報告に出てきませんでした。
店の形の版(サイトの図面の版の印)は、この記事の中で2回変わりました。9628954a582f → f282eaa6cb71(レジの直し)→ 82023936eb99(⑦の通路0.95m)です。サイトの試算は v2.6 を公開し、v2.7(料理をロボット優先にした版)は作業用の枝に置いたまま、まだ公開していません。Unity には、Mac に置いた v2.7 の条件のファイルを読ませています。
回した記録は、段階Aの確かめが6回、段階Bが18回です。
| 回 | Check-in | 店・ロボット | 出力のフォルダ(KIOXIA の r2r2r-data/service_sim/unity/ の下) |
|---|---|---|---|
| 1311 | cs:125 | ③・2台 | 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 |
| 1536 | cs:126 | ③・2台(店員優先) | 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 |
| 1941 | cs:135 | ⑦・2台 | 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 |
| 2227 | cs:138 | ③・2台 | 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 |
| 2253 | cs:139 | ③・2台 | 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 |
| 2309 | cs:139 | ⑦・2台 | 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 |
| 段階B | cs:140 | ③⑦ × 0・1・2台 × 種0・1・2 | 20261023_stageB_fam_{p1,p5}_r{0,1,2}_s{0,1,2} |
cs:137 で回し始めた③の回は、途中で角の詰まりに気づいて止めたので、記録を使っていません。
どの回も、スタッフ4人・1時間に42組・空の店から120分だけ客が来て全員が帰るまで回す・ロボットは料理を運ぶだけ・1往復で3卓まで、です。1コマは0.05秒で進めています。
同じ通路の卓に2台を向かわせない(cs:125):左の通路の入口の鉢合わせが79回から0回に
前の記事の最後の回(cs:124・出力の名前の末尾 1135)で、ロボットが動けなくなった場所の1位は、A01(いちばん左の細い通路)の入口での「もう1台のロボット」でした。2台が同じ通路の卓を受け持ち、入口で鉢合わせていました。
Unity では、ロボットが料理を受け持つときに、ほかの台が向かっている、または中にいる細い通路の卓を後に回すようにしました。後に回せない料理しかないときは、通路の入口ではなく待機場所で待ちます。サイトの試算には通路という考え方がないので、これは Unity だけの決まりとして、RobotSpec(ロボットの設定ファイル)の1か所で入れたり切ったりできるようにしています。
あわせて、このあと書くレジの直しで変わった店の形で、③⑦を建て直しました(cs:125)。Claude Code はネットからサイトのファイルを取れないので、同じファイルを Mac に置いて写させています。
前の回(1135・cs:124) | 今回(1311・cs:125) | |
|---|---|---|
| 時間切れの往復 | 16 / 51(31%) | 9 / 46(20%) |
| 動けなくなった回数 | 84 | 64 |
| A01 の入口でロボットどうし | 79 | 0 |
| レジのまわりの止まり | 112 | 31 |
逃がし弁(あきらめた/移した/卓を空けた) | 153/85/65 | 123/57/43 |
| 受け渡し口のまわりの止まり | 50 | 81 |
| ふつうの往復(真ん中の値) | 46秒(うち止まり4.5秒) | 71秒(うち止まり17秒) |
| ロボットが運んだ料理の割合 | 32% | 35% |
逃がし弁は、客が待ちきれずに帰る(あきらめた)、動けなくなった人を元の場所へ移す(移した)、客が座れない卓を空ける(卓を空けた)の3つです。店が止まらないように Unity に入れている仕組みで、これが多いほど、実際の店では起きない処理に頼っていることになります。
2つの直しは、ねらった所に効きました。その代わり、詰まりが受け渡し口のまわりに移り、ふつうの往復も1回あたり12秒ほど余計に止まるようになりました。なお、A01 の入口の鉢合わせは、依頼文では73回と書いていました。あとで記録を数え直した値が79回です。
レジで通路を狭くしない:会計に立つ点と並ぶ点は、ロボットの道から0.75m以上(店の形の版 f282eaa6cb71)
前の記事の5回目で、動けなくなった場所の2番目は、レジの前の「人が立ち止まっていた」でした。レジに並ぶ客の立つ点が、客席の下の通路のまん中にありました。
サイトの6つの店の図面を調べると、会計に立つ点か並ぶ点が、ロボットの道から0.75m未満の店が4つありました。0.75mは、人がロボットをよけるときに空ける距離と同じ値です。
| 店 | 道にかかっていた点 | 直し方 |
|---|---|---|
| ② 定番の郊外型 | 会計に立つ点(道から0.09m)・並ぶ点1 | 会計の列にロボットを通さない |
| ③ 効率重視・入口が角 | 会計に立つ点・並ぶ点1・2 | レジを縦向きにし、客は入口の側に立って入口へ並ぶ |
| ⑥ ゆったり・入口が左 | 並ぶ点1〜3 | ③と同じ |
| ⑦ ③の通路を狭めた店 | ③と同じ | ③と同じ |
| ④⑤ | なし | そのまま |
②は、記憶にある店をもとにした店です。
②(記憶の店)のレジはどこにあっては、入り口の前から少し離れてパントリーより。お客さんは入口の方に並んでいたよ
図面のレジは、もともと記憶のとおりの位置にありました。引っかかっていたのは、ロボットが入口の左の卓(T10・T14・T15)と右の卓(T16・T17・T19)のあいだを移るとき、会計に並ぶ列の前を横切っていたことでした。最初は「会計に立つ点と並ぶ点のまわり0.75mを、ロボットの道にしない」案を出しました。
会計に立つ点と並ぶ点のまわり0.75m そんなに広くもつの? レジ横をロボットが通ってもいいけどね。 ドリンクバーを少し狭くして通路広くするとか?
0.75mは、会計に立つ人の体の中心からロボットの体の中心までの距離です。人の半径0.2mとロボットの半径0.25mを足すと0.45mで、体どうしが触れます。0.75mのとき、体のあいだは約30cmです。対象は客が立つ点と並ぶ点だけで、レジのカウンターの横をロボットが通るのはかまいません。
②で試すと、会計の列の所だけ(カウンターから入口まで、幅1m)をロボットが通らない場所にしても、変わるのは入口の左右の卓を移る道の9本だけで、1本あたり1.1〜2.6m長くなるだけでした。受け渡し口から卓への道は変わりません。ドリンクバーを狭める案は、列の前を横切る道が残るうえ、②の卓までの道が変わって試算を計算し直すことになるので、選びませんでした。
距離は 0.75m のまま 会計の列の所だけロボットを通さない ドリンクバーはそのまま
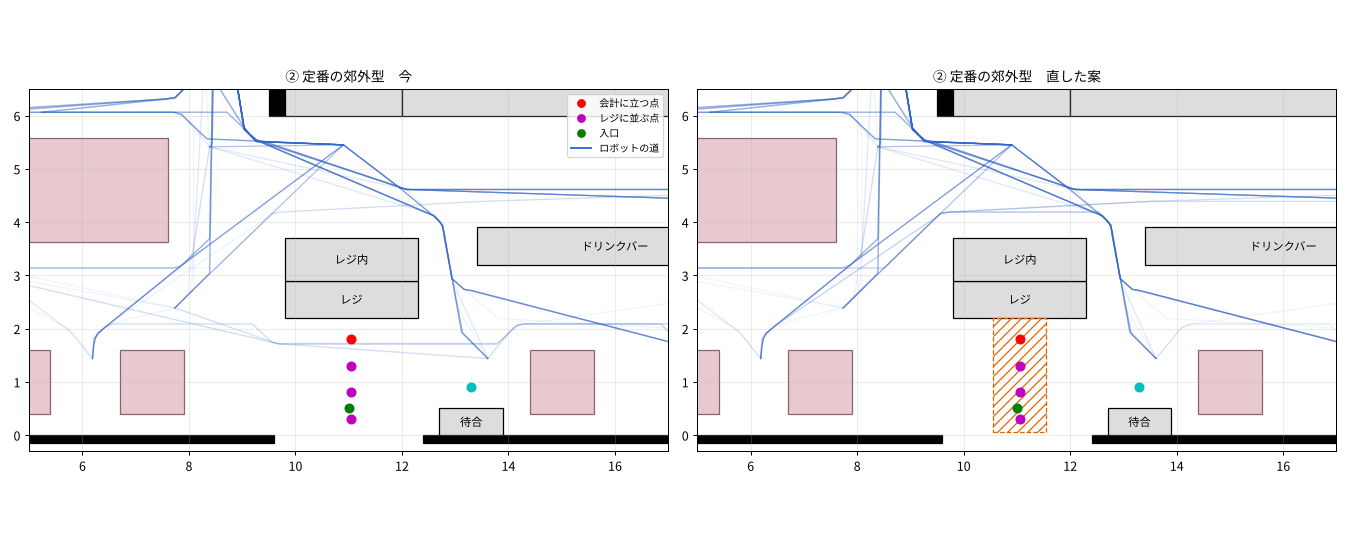
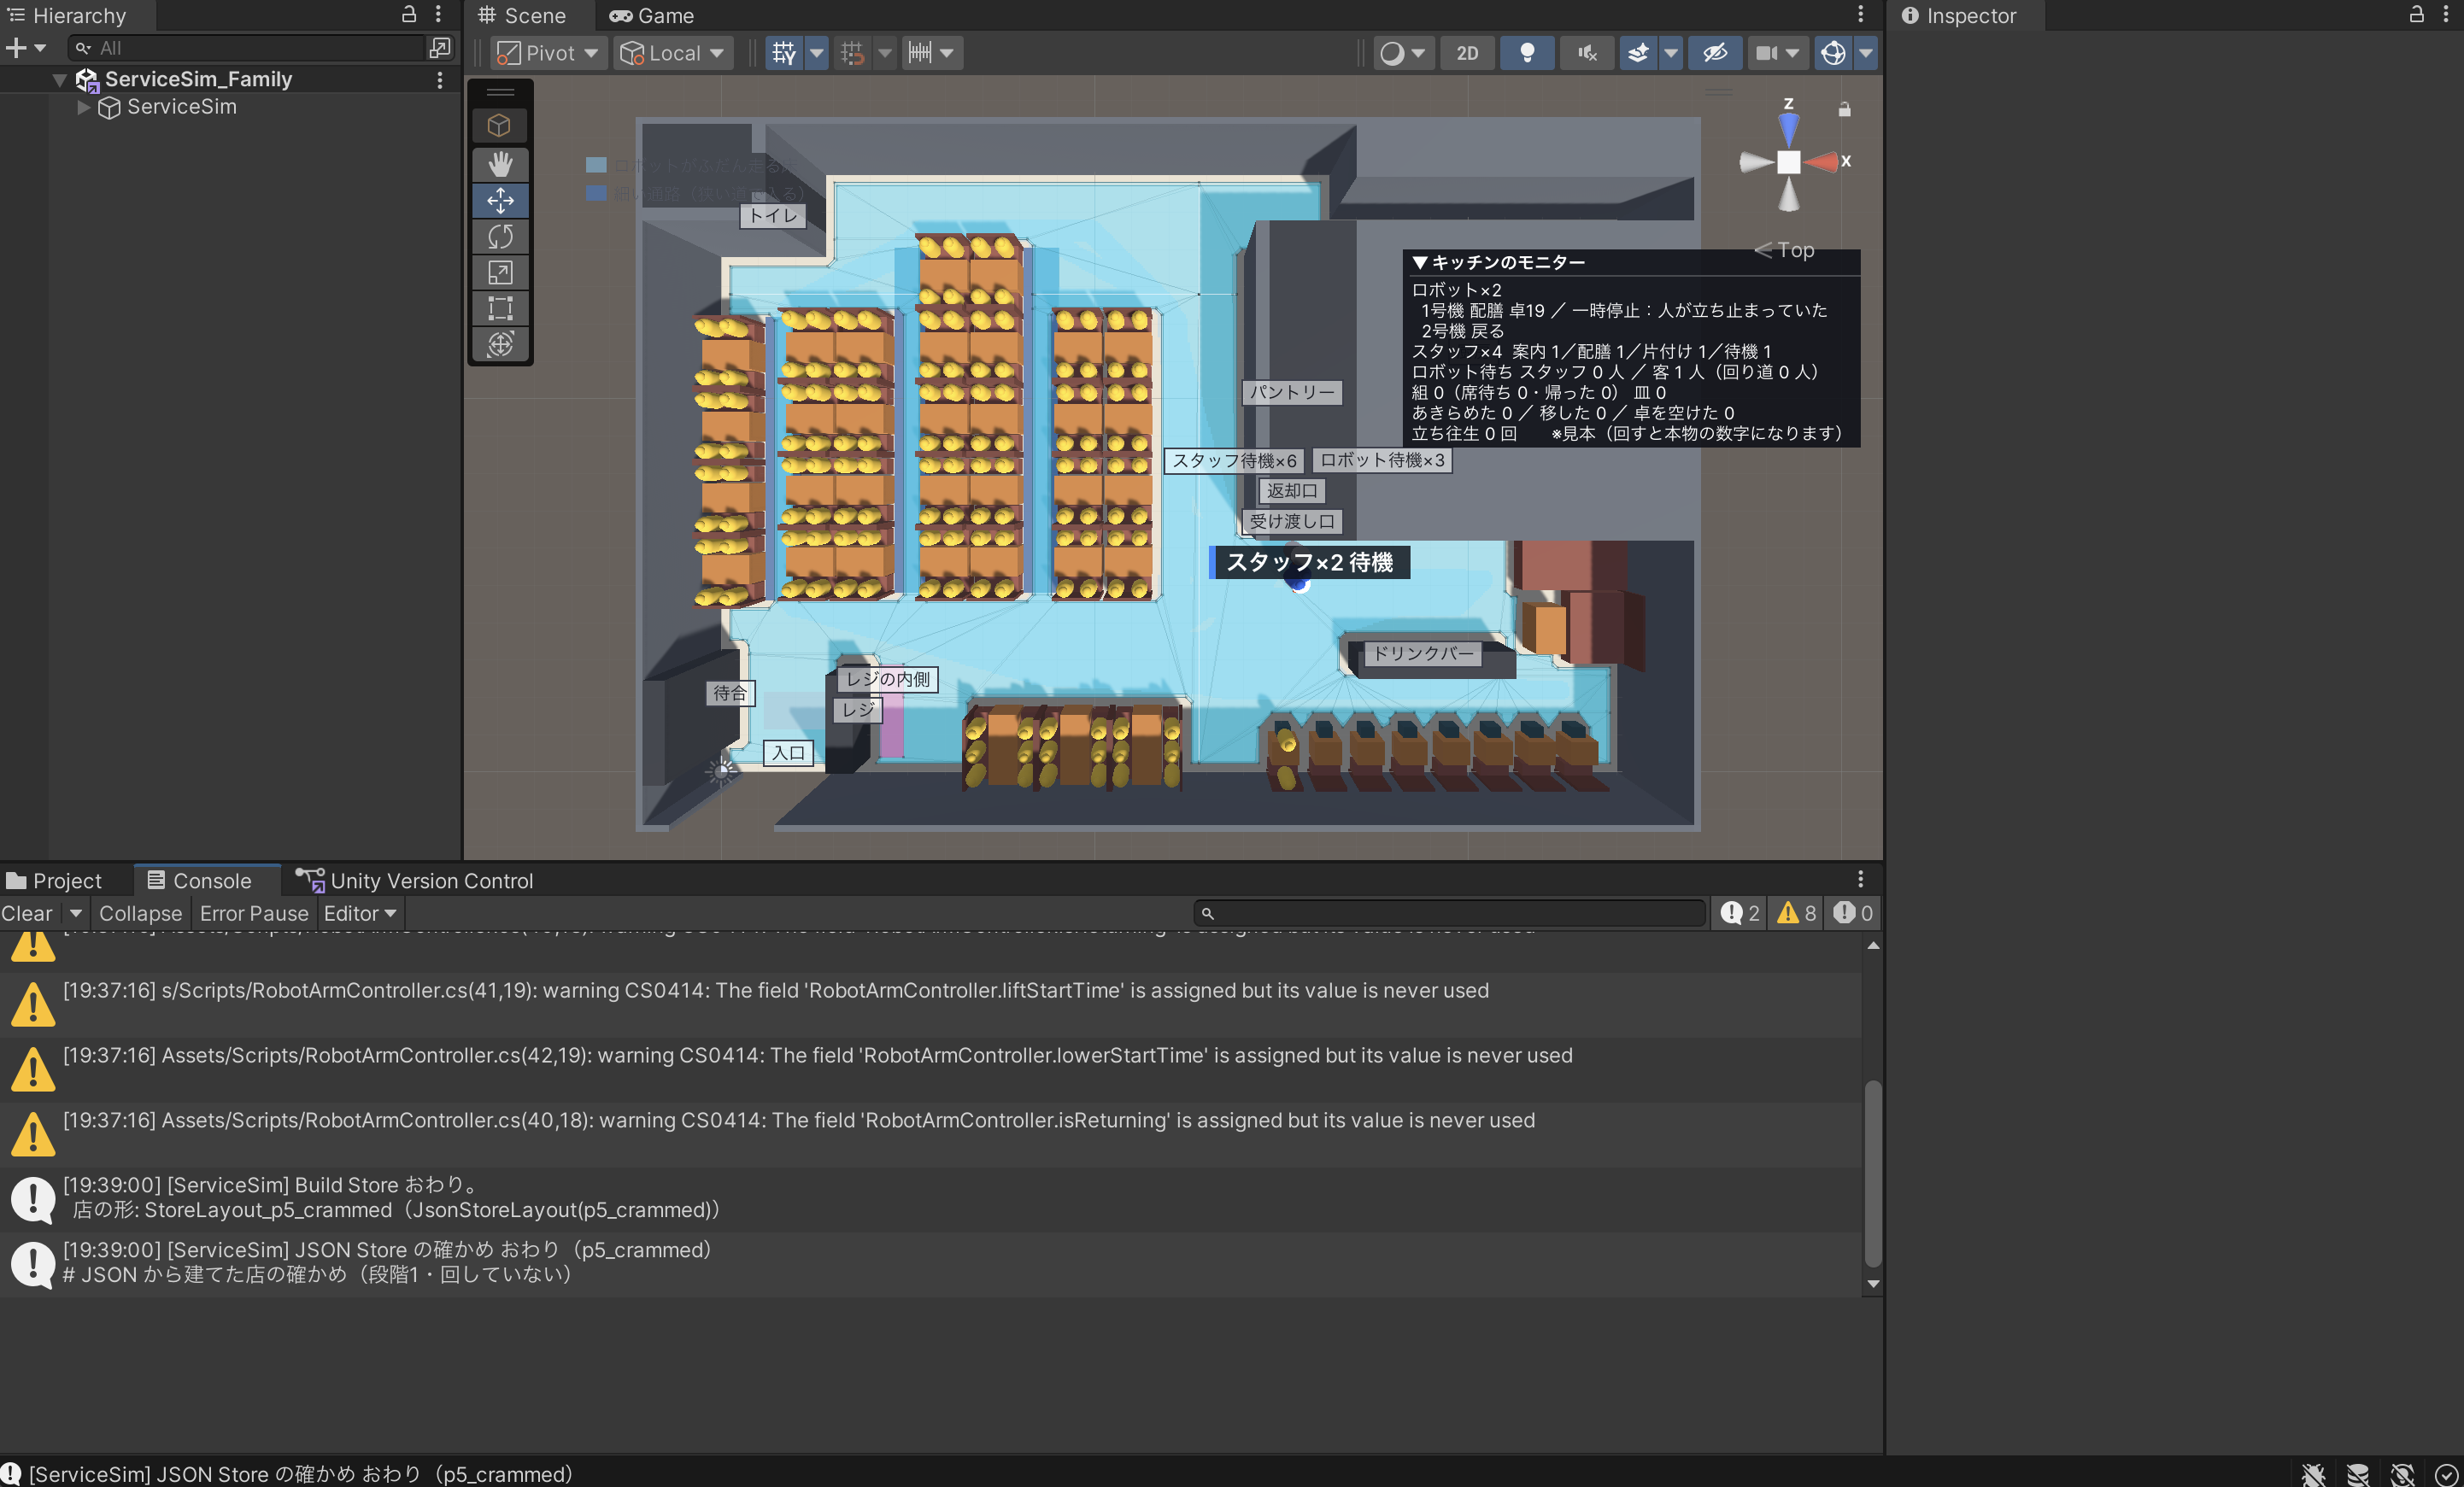
会計の列は、ロボットにとっては通れない場所、人にとっては通れる場所として図面に入れました(Unity 用の図面では robot_keepout)。Unity では壁として建てず、床の印だけにしています。店の形の確かめには「会計に立つ点と並ぶ点は、ロボットの道から0.75m以上」を足し、守れない店は図面を書き出さないようにしました。
6店とも、卓までの距離・止まる位置・卓の分け方は1つも変わりませんでした。変わったのは卓から卓への道だけです(②の9本は1.1〜2.6m長く、③⑥⑦は数cm)。試算は計算し直さず、条件のファイルの版の番号だけを更新して公開しました。版は f282eaa6cb71 です。
キッチンのモニター:測る回でも出す。板から、画面に貼るパネルに作り直した(cs:126〜cs:133)
これって動いている時に何をしているか(スタッフとロボット)表示できないんだっけ?たとえばキッチンのスペースにモニターさせたりとか
Unity には、人やロボットの頭の上に「いま何をしているか」を出す表示がありました。ただ、数字を測る回では自動で切る決まりにしていました。結果がずれるからではなく、重いからです。35卓ぶん以上の字幕を毎コマ描くと、計算の進みが遅くなります。シミュレーションは1コマ0.05秒ずつ進むので、画面の表示があっても中の時間は変わりません。
キッチンのモニターなら、測る回でも出してよい それで進めよう。問題があるようなら切れるようにしておこう
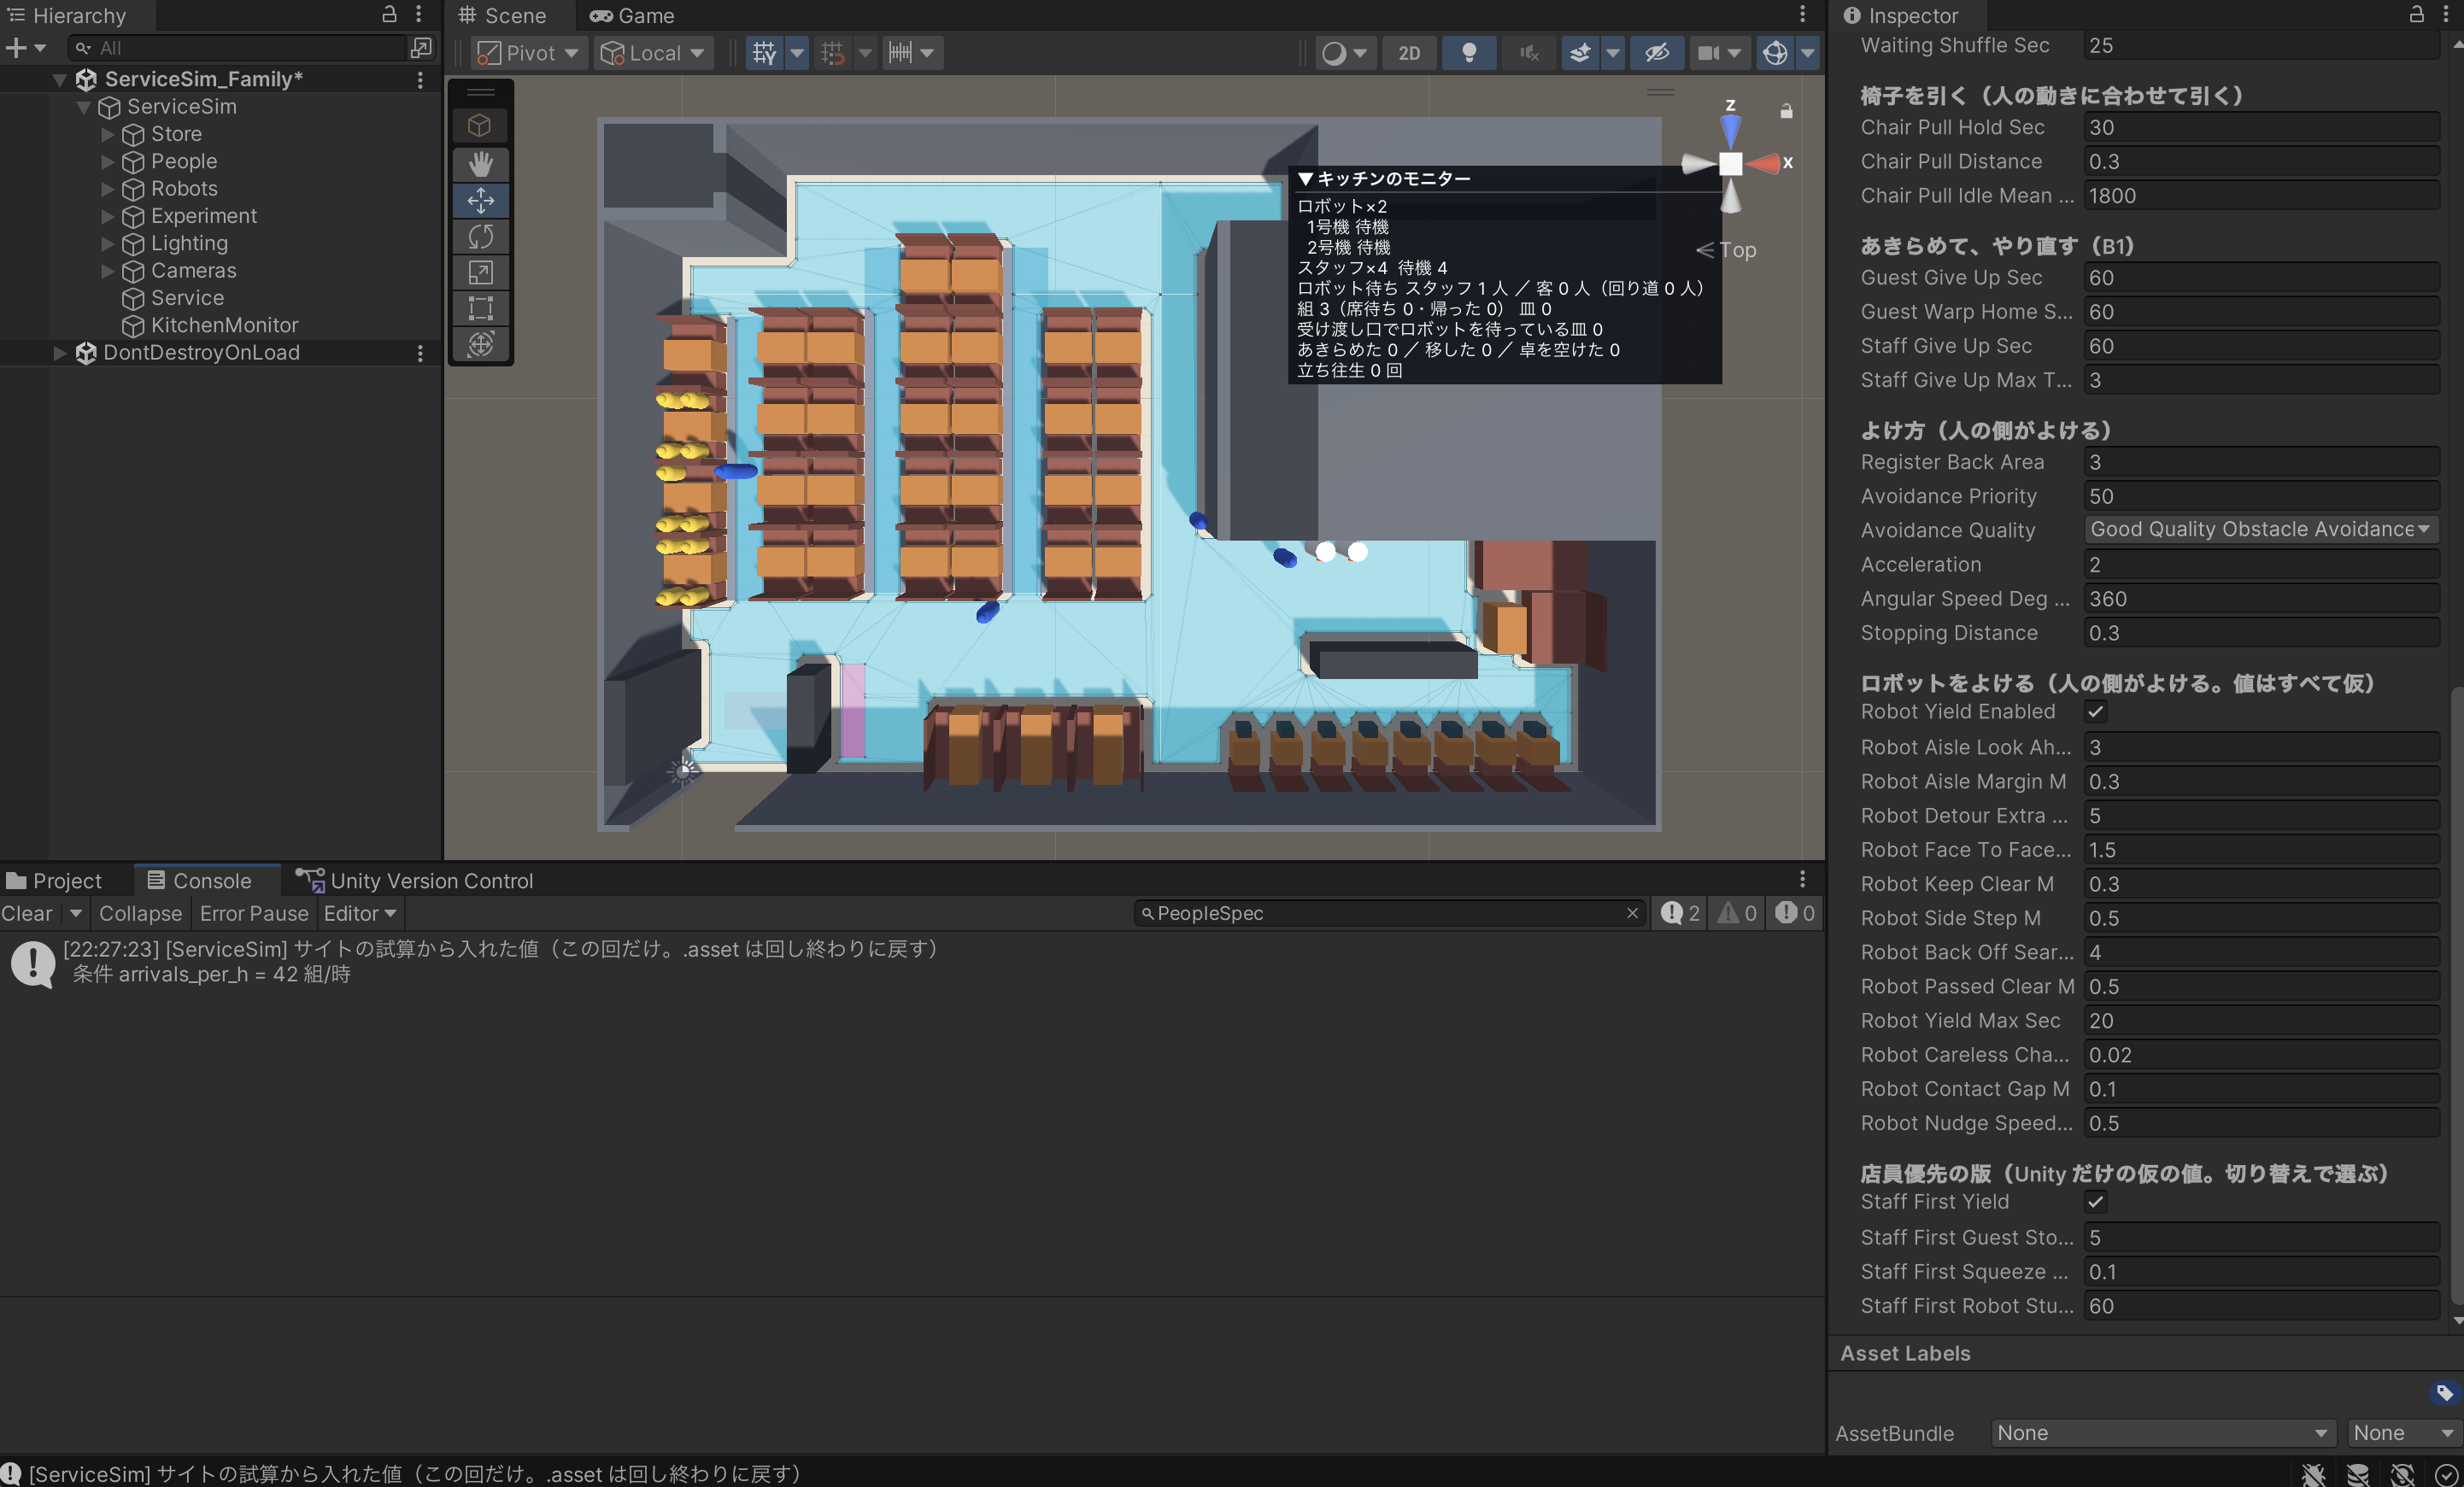
モニターに出すのは、ロボット1台ごとの仕事(料理を運ぶ→卓の番号/戻る/待機)と止まっている理由、スタッフの仕事ごとの人数、ロボットを待っている人の数、入口で待つ組、逃がし弁の回数です。言葉は記録のファイル(trips.csv・stops.csv など)と同じものだけを使い、画面にだけある数字は作らない、と決めました。
最初はキッチンの屋根の上に板を置く作りでしたが、編集中にキッチンの場所を見つけられず何も出ない(cs:127)、字が小さい・鏡文字になる(cs:128)、大きさを合わせる処理が効かない(cs:129)、と続きました。
あとテキストの向きはシーンの向き変えたら追従するようにしないと(他のテキスト吹き出しと同じように。キッチン上のモニターも吹き出しにしたら?)
吹き出しにすると(cs:131)、今度は通路の上まではみ出しました。
今度はちょっと大きすぎだね。通路の方まではみ出てるね。 パネルを掴んで動かせないのかね
店の上に浮かべるのをやめ、Scene ビュー(Unity の作業画面)の隅に貼り付けるパネルにしました(cs:132)。カメラを回しても動かず、見出しを掴んで好きな位置へ動かせて、押すとたためます。最後に左端の白い線だけを消して(cs:133)、モニターはここで終わりにしました。どれも見た目だけの直しで、シミュレーションの動きは変えていません。
受け渡し口の横に人とロボットが溜まる:店員が必ず道を空けるよけ方を、切り替えで入れた(cs:126)
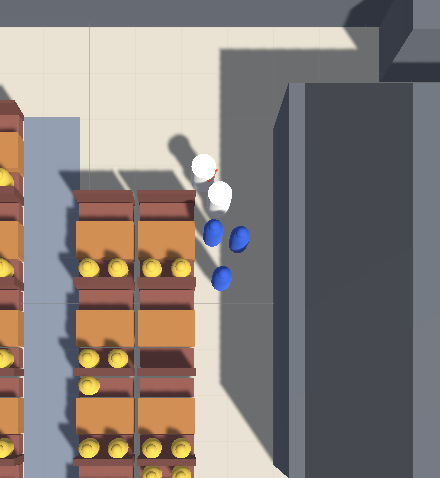
こういうロボットと人が溜まってしまうのは基本的に何が原因なの?
溜まる理由は3つ重なっていました。料理は受け渡し口からしか出ないので、みんなの出発点と終点が1か所に集まります。スタッフの待つ場所が、ロボットの通る道のすぐ横にあります。そして、ロボットも人も「相手が動くのを待つ」決まりで動いていました。ロボットは人がセンサーに入ると止まり、人はロボットから0.75m離れようと下がるか待ちます。実際の店では、店員は必ず道を空けますし、ロボットにも通る線が決めてあります。
前の記事で決めておいた「店員は必ず道を空ける」よけ方を、切り替えで入れることにしました。
前に決めた「店員は必ず道を空ける」よけ方を切り替え かな。
| 今のよけ方(既定) | 店員優先の版(切り替えで選ぶ) | |
|---|---|---|
| 店員 | 0.75m離れる。細い通路では下がって待つが、20秒で諦めて進む | 必ず道を空ける。通路の脇か入口まで下がり、ロボットが通るまで待つ |
| 客 | 店員と同じ | 長くて5秒止まり、別の道があれば回り道、なければ横を詰めて通る |
相手のロボットが別の理由で止まったままだと、店員は待ち続けてしまいます。そのため、60秒たったら回り道をする逃げ道を足しました。
| 今のよけ方(1311) | 店員優先(1536) | |
|---|---|---|
| ふつうの往復(真ん中の値) | 71秒(うち止まり17秒) | 56秒(うち止まり6秒) |
ロボットの往復の数/運んだ料理の割合 | 46回/35% | 55回/38% |
| 受け渡し口のまわりの止まり | 81回・10分 | 73回・17分 |
| ロボットどうしで止まった | 131回・43分 | 187回・71分 |
| 動けなくなった回数 | 64 | 83 |
| 時間切れの往復 | 9 / 46 | 15 / 55 |
| 店員が60秒待って回り道した | ― | 241回 |
人がよけるようになって、ふつうの往復は速くなりました。その分、ロボットどうしの詰まりが一番の原因になり、ロボットが詰まると店員が60秒待ってから回り道するので、受け渡し口のまわりの止まりは長くなりました。
段階Aの終わりを決めた:直すたびに詰まる場所が移るだけで、終わりがないため
これが終わったら次は何を行いますか?今の改良はいつまで行いますか?
A01 の入口を直すと受け渡し口に詰まりが移り、よけ方を変えるとロボットどうしの詰まりが増えました。このまま直し続けても終わりが来ないので、店員優先のよけ方とモニターを段階Aの最後の直しにして、そこで Unity の作りを固めると決めました。そのあと見つかる詰まりは直さずに、段階Cの「ずれの一覧」に書きます。
ただ、このあと⑦を回してみて、Unity の決まりそのものが実際の店と違う所が2つ見つかりました(料理を誰が運ぶか、角で誰が譲るか)。どちらも店の回し方の決まりなので、固めた作りを開け直して入れています。最終的に固めた版は cs:139 です。
床の水色は、使っていない NavMesh の形を塗っていた(cs:134)
⑦の店を真上から見ていて、細い通路にロボットが入れないように見える所がありました。
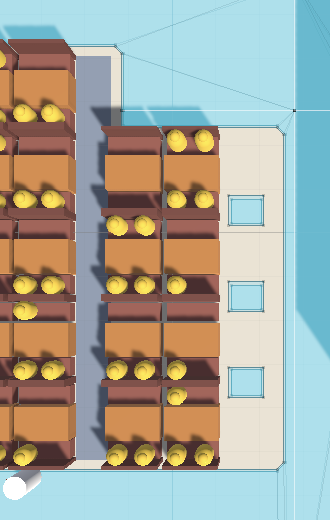
この3つの通路はロボット入れなきゃおかしいだろ。仕事ができないだろ?
じゃあなんのために水色塗られているんだよ?視覚的にわかりづらいんじゃないのか?
最初は「卓のそばに空けている余白」と説明しましたが、それは間違いでした。水色はもともと「ロボットが入れる床」を見せるための色でした。10月22日に、ロボットの道を Unity の NavMesh(Unity が床の形から自動で作る、歩ける範囲の地図)で決めるのをやめ、サイトの図面から道順を受け取る形に変えています。そのとき塗り方を直さなかったので、水色はロボットが実際に走る所ではなく、使っていない NavMesh の形を塗っていました。細い通路は NavMesh に入れていないので、塗られていなかったのです。
ロボットの道を Unity の NavMesh で決めるのをやめ なんでやめた?
やめた理由は2つです。1つは、⑦の0.8mの通路を NavMesh に入れると、ロボットの半径の分だけ壁や卓から離すと床がほとんど残らず、床が途切れて入れない卓が出たこと。もう1つは、サイトの試算と道の決め方をそろえたかったことです。試算は「ふだんは幅1.0mの道、届かない卓だけ狭い道」で卓を分けて道のりを測ります。NavMesh が道を選ぶと、試算と違う道を通ってしまい比べられません。
床の色をサイトの図面から塗るようにしました。水色はロボットがふだん走る道の上でロボットの体が通る範囲、濃い水色は細い通路の区画です。Claude Code は、指示どおり狭い道も濃い水色にすると⑦の床のほとんどが「細い通路」に見えてしまうので、濃い水色は区画だけにしていました。その方が分かりやすいので、そのままにしています。
| 水色 | 濃い水色 | |
|---|---|---|
| ③ | 58.4 m² | 30.1 m²(1.2 m × 3 本) |
| ⑦ | 64.1 m² | 23.5 m²(0.95 m × 3 本) |
⑦の細い通路を0.8mから0.95mに:島を右へずらし、卓と席は変えない(試算 v2.6・店の形の版 82023936eb99)
通路はもう少し広く(ほんの少し)して、もっとロボットが動けるように修正
ここの通路多少広いんだから、多少机動かしたりして調整できるだろ
⑦は③の通路を詰めて作った店なので、詰めた分が右端の列の横に余っていました(右端の列からパントリーまで約3.2m。③は2.0m)。卓の島を右へずらせば、卓と席を変えずに通路を広げられます。最初に0.9mで作りました。
90cmの意味はあるの?もっと広くできそうだけど?
0.9mに深い理由はありませんでした。⑦は「同じ卓・同じ席で、通路だけ狭いと何が変わるか」を見るための店です。ロボットをふだん走らせる幅は1.0mなので、通路が1.0m以上になると⑦の24卓はふだんの道で入れるようになり、③とほぼ同じ店になります。
| 通路 | ⑦がどんな店になるか |
|---|---|
| 0.8m(前) | 配膳ロボット BellaBot が通れる幅ちょうど。Unity ではほとんど動けない |
| 0.9m | 1.0mより狭い通路を、狭い道で入る店のまま。左右に5cmの余裕 |
| 1.0m | ふだんの道で入れるようになり、「細い通路の24卓」がなくなる |
| 1.2m | 右の余りを使い切った形。③とまったく同じ店になる |
一度「1.0で」と決まり、書き換えを始めたところで0.95mに変わりました。1.0mの書き換えがすでにファイルに入っていたので、0.9mの版に戻してから0.95mを当て直しています。
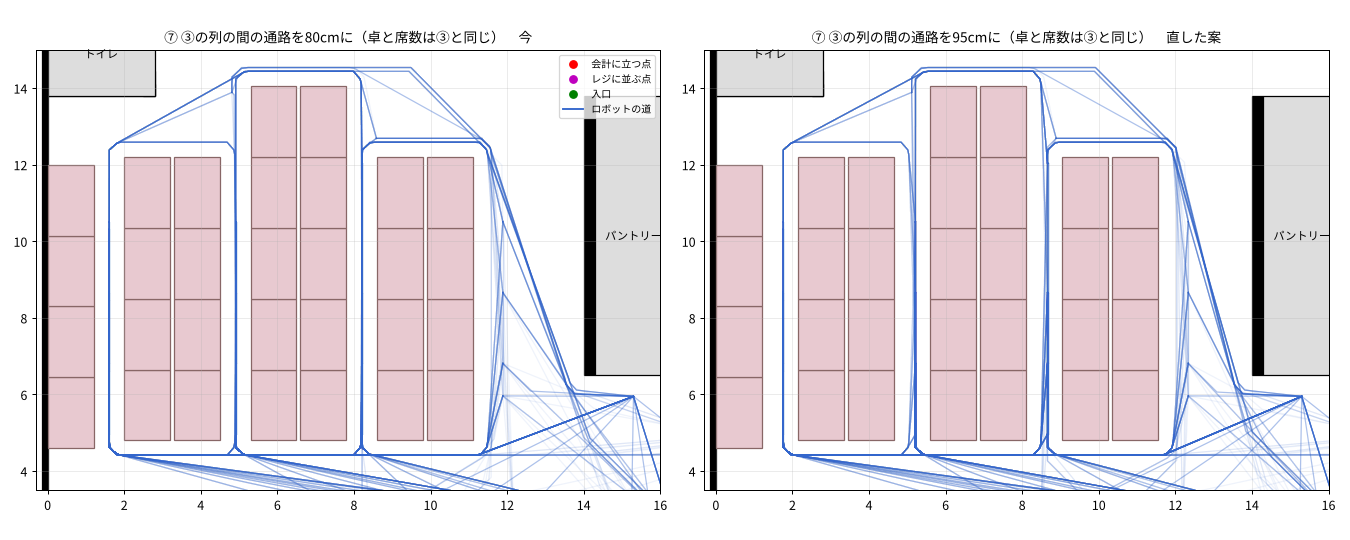
試算は⑦の1,533条件だけを回し直しました。ほかの店の14,892条件は数字が変わりません。⑦の卓までの平均の道のりは11.04mから10.85mに、店が回らない条件は204から203になりました。
このとき、昼にレジを直して公開したときに、試算ページの平面図を作り直していなかったことにも気づきました。ページの図だけ、レジが横向きの前の店のままでした。数字には効かないので、⑦の直しと一緒に図を作り直し、v2.6 として公開しました。店の形の版は 82023936eb99 です。
⑦を建てる:設定ファイルに0.8mが残っていた(cs:135)
⑦を新しい図面で建てると、Unity は「図面と合わないものが1件ある」と言って建てるのをやめました。原因は、⑦の設定ファイル(StoreLayout_p5_crammed.asset)に通路の幅0.8mが残っていたことでした。図面が正なので、Unity の側の値を0.95に直し、今後は設定ファイルの幅が違っても図面の幅に合わせて進むようにしました(cs:135)。
⑦を初めて回した結果(1941)は、③(1311)より詰まりが少ないものでした。
| ③ 通路1.2m(1311) | ⑦ 通路0.95m(1941) | |
|---|---|---|
| 最後まで回り切った | ○(195分) | ○(182分) |
| 時間切れの往復 | 9 / 46(20%) | 6 / 48(13%) |
| 動けなくなった回数 | 64 | 26 |
逃がし弁(あきらめた/移した/卓を空けた) | 123/57/43 | 40/46/15 |
| ふつうの往復(真ん中の値) | 71秒(うち止まり17秒) | 56秒(うち止まり4秒) |
| ロボットが運んだ料理の割合 | 35% | 32% |
| 細い通路を通った往復 | ― | 29回(うち時間切れ4) |
料理はロボット優先にした:2分待っても来なければ人が運ぶ(試算 v2.7・Unity cs:137)
⑦で配膳している時、なんでロボットより先に人が配膳やるの?
1941 の記録では、191皿のうちロボットが運んだのは62皿、スタッフが129皿でした。サイトの試算の決まりは「料理ができたら、ロボットとスタッフのうち先に空いた方が運ぶ(同時ならロボット)」で、Unity もそれに合わせていました。ロボットは2台で、1回の往復に3卓分まとめて回るので、出ている時間が長くなります。一方スタッフは受け渡し口のすぐ横で待っていることが多い(スタッフの時間の27%が待機)ので、先に空くのはスタッフの方でした。
最初は、このまま段階Bに進み、ロボット優先は段階Cの候補にする案を出しました。
ロボット導入しているのにロボット最優先で使わないでどうすんの。人よりロボットをたくさん働かせろよ
決まりを次のように変えました。料理ができたら、まずロボットが戻るのを待ちます。スタッフは料理を持たず、案内・片付け・会計を続けます。受け渡し口で待ってもロボットが来なければ、そこからはロボットとスタッフの先に空いた方が運びます。割れ物を人が運ぶ設定のときと、ロボット0台のときは、今までどおり人が運びます。
ロボットが詰まると料理の待ちが延びる、と心配を書いたところ、こう返ってきました。
ロボットが詰まったら、人がサポートすんだよ
動けなくなったロボットをスタッフが助けに行く仕組みは、試算にも Unity にもすでに入っています。料理の待ちが延びるのは、ロボットが2台とも配膳に出ていて受け渡し口に戻るまでの時間です。そこを人が拾うまでの待ちの長さを決めてもらいました。
2分でよい
店の回し方の決まりなので、サイトの試算(正)から直しました。全部の条件(16,425)を回し直すのに、Mac と作業用の計算機に分けて回しています。
| ロボットありの条件の平均 | v2.6 先に空いた方 | v2.7 ロボット優先 |
|---|---|---|
| ロボットが運ぶ料理 | 69% | 85% |
| スタッフの歩く距離(1人) | 2.31km | 2.14km |
| 店が回らない条件 | 3,006 | 2,955 |
| 入店待ち | 9.27分 | 9.23分 |
| 料理が届くまで | 0.59分 | 1.01分 |
| 3分を超えて届いた皿 | 1.4% | 3.7% |
ロボットがよく働き、スタッフの手と足が空きます。その分、案内が早くなって回る店が少し増えました。料理はロボットの戻りを待つので、平均で約25秒延びます。ロボット0台の条件は、数字が1つも変わっていません(決まりが余計な所に効いていないことの確かめ)。
試算 v2.7 は作業用の枝(wip/robot-first-v27)に置いたままで、サイトのページはまだ v2.6 です。Unity には v2.7 の条件のファイルを Mac から読ませ、料理の割り当てを同じ決まりにしました(cs:137)。皿ごとの記録(dishes.csv)には、誰が運んだか、受け渡し口で待った秒数、2分を過ぎて人が拾ったかを残しています。
その前に、Mac が落ちて Unity を開き直したときに、Unity Version Control の保留の変更が37件たまっていたので、Claude Code に1件ずつ仕分けさせてから整理しました(cs:136)。Unity と関係のない .git のファイルが管理に入っていたもの、回したときに書き換わった設定の値、中身の変わっていない取り出しが混ざっていました。
厨房の角の吹き溜まり:譲る順番をロボット>スタッフ>客に。譲る側は道から横へどく(cs:138)
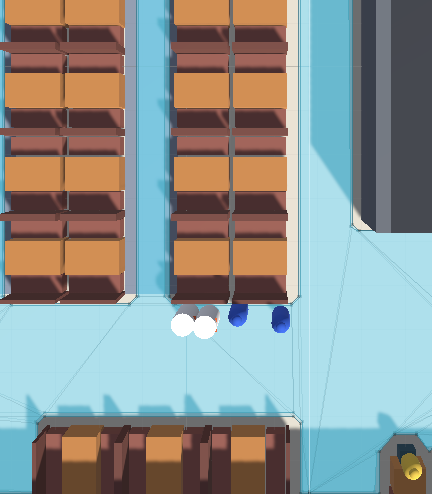
ここで吹き溜まりするね。いい加減にしろよ。
どっちか譲って避けろよ
受け渡し口と客席をつなぐ角(x 10.5〜13.5・z 3.5〜5.8)は、店で一番詰まる所でした。前の2回(1311・1536)で、ロボットが止まっていた時間の約3分の1がこの角です。受け渡し口と客席をつなぐ通り道がここしかなく、スタッフの待つ点もすぐ横にあります。
Claude Code の報告で原因がはっきりしました。それまでの作りは、細い通路の入口と中でしか譲る仕組みが動いていませんでした。広い所の角では0.3m横に寄るだけで、向かい合ったまま止まっていました。また、譲る側は同じ道の上で後ろに下がっていたので、下がった先でまた鉢合わせていました。
| 出会った相手 | 譲る側 | 譲り方 |
|---|---|---|
| ロボット と スタッフ | スタッフ | 必ずよける。ロボットの道から横へ0.6m以上どき、通り過ぎるまで待つ |
| ロボット と 客 | 客 | 長くて5秒止まり、回り道か横を詰めて通る |
| ロボット と ロボット | 番号の大きい台 | 後ろへ下がらず、相手の道から横へどいて待ち、相手が通ったら出る |
店員優先のよけ方は、ここで既定を「入れる」に変えました。前は「既定は切、回し終わったら外す」としていたので、逆になります。誰が誰に譲ったかは yields.csv に残すようにしました。
長い依頼文はチャットからうまくコピーできなかったので、ここからは依頼文をファイルにして Mac に置き、Claude Code には「このファイルを読んで、その通りにして」とだけ送っています。
| 1311 | 1536 | 2227(cs:138) | |
|---|---|---|---|
| 角で止まった時間の割合 | 32% | 47% | 4% |
| ロボットが運んだ料理 | 35% | 38% | 75% |
| ロボットの往復 | 46 | 55 | 92 |
| 時間切れの往復 | 9(20%) | 15(27%) | 6(7%) |
| 動けなくなった回数 | 64 | 83 | 46 |
| 入店待ち | 4.3分 | 10.9分 | 11.4分 |
| 料理が届くまで | 3.7分 | 3.9分 | 5.2分 |
逃がし弁(あきらめた/移した/卓を空けた) | 123/57/43 | 155/71/63 | 199/87/77 |
角の溜まりはほぼ消え、ロボットは前の2倍働きました。その代わり、入店待ちと逃がし弁が悪くなりました。
スタッフが譲りすぎていた:ロボットの進む先にいるときだけ譲る(cs:139)
2227 の記録では、スタッフが譲った回数が13,173回、譲って待った時間の合計が19,535秒(約5.4時間)ありました。スタッフ4人の時間の約4割です。1回の待ちの真ん中の値は0.05秒で、ほとんどは近くにロボットがいただけで譲っていました。cs:138 の作りは、ロボットが1.5m以内に来たら、進む向きに関係なく譲っていたからです。その分、案内と片付けが遅れて入店待ちが延びていました。
スタッフが譲るのは、ロボットが動いていて、スタッフがロボットのこれから進む道(今の位置から先の2.0m分)から横に0.6m+体の半径の内にいて、ロボットが近づいてくるときだけにしました。Claude Code は、一番近い1台しか見ていなかった見落としも一緒に直しています。
| 1311(直す前) | 2227(cs:138) | 2253(cs:139) | |
|---|---|---|---|
スタッフが譲っていた時間の割合 | ― | 39% | 5%(13,173回 → 933回) |
| 角で止まった時間の割合 | 32% | 4% | 12% |
| ロボットが運んだ料理 | 35% | 75% | 68% |
| ロボットの往復 | 46 | 92 | 92 |
| ふつうの往復(真ん中の値) | 71秒(止まり17秒) | 89秒(31秒) | 68秒(5秒) |
| 時間切れの往復 | 9 / 46 | 6 / 92 | 6 / 92 |
| 入店待ち | 4.3分 | 11.4分 | 7.1分 |
逃がし弁(あきらめた/移した/卓を空けた) | 123/57/43 | 199/87/77 | 109/65/44 |
譲りすぎはなくなり、スタッフの時間が戻りました。ロボットは前の2倍の往復をしながら、1往復の止まりは5秒ほどです。それでも入店待ちは7.1分、料理が届くまで4.5分で、サイトの試算 v2.7(入店待ち0.8分・料理1.0分)とは大きく開いています。これは Unity の作りを直す話ではなく、サイトと Unity のずれとして調べる対象なので、cs:139 で作りを固め、段階Bに進みました。
同じ cs:139 で⑦を1回回して(2309)、最後まで回り切ることを確かめています。
| ⑦ ロボット2台 | 1941(cs:135) | 2309(cs:139) | サイトの試算 |
|---|---|---|---|
| ロボットの往復 | 48回 | 97回 | ― |
| ロボットが運んだ割合 | 32% | 70% | 99% |
| 入店待ち | 1.8分 | 4.0分 | 1.6分 |
| 料理の待ち | 2.2分 | 3.9分 | 1.0分 |
| 3分を超えて届いた皿 | 19% | 60% | ― |
| 時間切れ/動けなくなった回数 | 6回/26回 | 5回/40回 | ― |
2309 の summary.json の「角で止まった時間の割合」は30%でしたが、この値は③の角の座標で数えているので、⑦では参考の値です。
段階Bの台帳と18回の回し方(cs:140)
台帳は /Volumes/KIOXIA/r2r2r-data/service_sim/unity/unity_ledger_v1.csv に置きました。Unity の出力の置き場所(service_sim/unity/)の中なので、置き場所の決まりは増やしていません。台帳の中身の決まりは、プロジェクトの data_manifest_rules.md に第10節として書きました。
- 1回 = 1行。行は足すだけで、書き換えない・消さない
- 止めた回・失敗した回も、status(completed/stopped/failed)を付けて1行残す
- 台帳の1行目(列の名前)とコードの列が1字でも違えば、書き足さない
- 列は49。回の識別(日時・出力のフォルダ・Unity の版・店の形の版・試算の版)、条件、Unity だけの決まりの入り切り、サイトと同じ定義の数字、同じ条件のサイトの試算の数字、Unity で測った4つの値、往復と止まり、逃がし弁、2分を過ぎて人が拾った皿、スタッフが譲った時間の割合
回すのは、③⑦ × ロボット0・1・2台 × 乱数の種0・1・2 の18回です。前は「よけ方の2通り」も回して36回にする予定でしたが、譲る順番がロボット>スタッフ>客と決まったので、2通り目は外しました。
試算の「3mごとに止まる起きやすさ」に当たる2つの値(pause_rate・stuck_rate)は、台帳では空欄にしています。3mという値は試算の中だけの設定で、Unity は読まない決まりにしているからです。割り出すのに要る素の数(止まった回数と走った距離)は summary.json にあるので、段階Cで計算します。
1回目(③ロボット2台 種0)の台帳の行を見て、49列がそろい、中身が summary.json と合っていることを確かめてから、残りを回しました。
段階Bの18回:ロボットなしでは試算とほぼ合い、ずれはロボットを入れたときだけ出た
18回すべて最後まで回り切り、台帳に18行(すべて completed)が入りました。実時間は1回8〜16分、合わせて3時間でした。
| 回 | 入店待ち | 料理の待ち | ロボットが運んだ割合 | 3分を超えた皿 | 往復/時間切れ | 2分を過ぎて人が拾った皿 |
|---|---|---|---|---|---|---|
| ③ 0台 種0 | 1.93分 | 0.96分 | ― | 0% | ― | ― |
| ③ 0台 種1 | 2.28分 | 0.80分 | ― | 0% | ― | ― |
| ③ 0台 種2 | 3.96分 | 0.91分 | ― | 0% | ― | ― |
| ③ 1台 種0 | 3.53分 | 3.85分 | 57% | 64% | 57/1 | 94 |
| ③ 1台 種1 | 1.58分 | 3.14分 | 75% | 51% | 70/0 | 45 |
| ③ 1台 種2 | 5.94分 | 3.82分 | 59% | 63% | 61/1 | 87 |
| ③ 2台 種0 | 2.89分 | 4.22分 | 71% | 55% | 99/7 | 61 |
| ③ 2台 種1 | 2.39分 | 4.43分 | 64% | 62% | 82/10 | 65 |
| ③ 2台 種2 | 9.04分 | 4.72分 | 68% | 60% | 91/7 | 67 |
| ⑦ 0台 種0 | 4.84分 | 1.12分 | ― | 2% | ― | ― |
| ⑦ 0台 種1 | 1.62分 | 1.00分 | ― | 1% | ― | ― |
| ⑦ 0台 種2 | 1.63分 | 1.11分 | ― | 3% | ― | ― |
| ⑦ 1台 種0 | 3.06分 | 3.83分 | 59% | 64% | 58/1 | 89 |
| ⑦ 1台 種1 | 9.06分 | 3.81分 | 62% | 65% | 71/1 | 94 |
| ⑦ 1台 種2 | 11.47分 | 3.58分 | 66% | 66% | 70/0 | 84 |
| ⑦ 2台 種0 | 15.07分 | 3.94分 | 75% | 59% | 116/9 | 69 |
| ⑦ 2台 種1 | 1.80分 | 3.04分 | 76% | 39% | 102/6 | 44 |
| ⑦ 2台 種2 | 12.67分 | 3.61分 | 80% | 51% | 118/6 | 52 |
ロボットなしの6回は、料理の待ちが0.8〜1.1分で、試算(0.65〜0.66分)との差は、3回の平均で0.2〜0.4分です。入店待ちは Unity の方が短めでした。人だけで回す部分の作りは、試算と大きくはずれていません。
ロボットを入れた12回は、料理の待ちが3.0〜4.7分で、3回とも近い値に収まっています。試算はロボット1台で2.0〜2.1分、2台で1.0〜1.05分です。試算ではロボットを1台から2台にすると料理の待ちが半分になりますが、Unity ではほとんど変わらないか、③では延びました。ロボットが運んだ割合も、試算の99%(2台)に対して64〜80%で、2分を過ぎて人が拾った皿が1回あたり44〜94皿あります。
入店待ちは、同じ条件でも回によって大きくぶれました。⑦ロボット2台では、1.8分の回と15.1分の回があります。3回の平均だけを見て結論を出せる値ではありません。
ロボットが1往復で走った距離を、動いていた時間で割った速さは、12回とも毎秒0.57〜0.58mでした。
次は段階C:ロボットが運んだ料理の待ちを分ける。押し直しの直しは急がない
段階Cでは、ロボットが運んだ料理の待ちを、料理が受け渡し口でロボットを待っていた時間と、運んでいる途中の時間に分けます。それを、試算が前提にしているロボットの速さ、止まる回数と長さ、動けなくなる割合と並べます。台帳と KIOXIA の出力だけでできる作業です。
18回は一度で最後まで回りましたが、作りには押し直したときの心配が3つ残っています。出力のフォルダ名に押した日の日付が入るので、日付が変わってから押し直すと、台帳の行と照らし合わせられず終わった回をもう一度回してしまうこと。台帳に書く前に Unity が落ちた回を押し直すと、同じ名前のフォルダに上書きするおそれがあること。そして「保留の変更あり」が run_info.json に記録されず空になっていたことです。直す依頼文(v7b)を作り、押し直しが要るときまでに Claude Code に送ります。
データとコードの置き場所
| もの | 場所 |
|---|---|
Unity の出力(段階Aの6回・段階Bの18回) | KIOXIA r2r2r-data/service_sim/unity/ の下(フォルダ名は上の表) |
| 段階Bの台帳 | KIOXIA r2r2r-data/service_sim/unity/unity_ledger_v1.csv |
| 段階Bの一覧のログ | KIOXIA r2r2r-data/service_sim/unity/run_all_log.txt |
| Unity の設計書・依頼文 | iCloud サービスロボット導入シミュレーション/unity/(unity_design_v0.md・claude_code_request_v6〜v7b) |
| Unity のコード | /Users/shimazueiichi/Robotics_UX/Robotics_UX_New/Assets/ServiceSim/(Unity Version Control cs:125〜cs:140) |
| 店の形のコード | GitHub PixelstoMotors/p2m-site の tools/sim_layouts/ |
| 店の形のデータ | GitHub PixelstoMotors/p2m-site の public/sim/layouts/(版 82023936eb99) |
| 試算 v2.6(公開) | GitHub PixelstoMotors/p2m-site の public/sim/serving-robot.html・serving-robot-params.json、Mac simulation/v2_6/ |
| 試算 v2.7(未公開) | GitHub PixelstoMotors/p2m-site の枝 wip/robot-first-v27、Mac simulation/v2_7/、Unity 用の条件は iCloud unity/site_copy_v27/ |
| 台帳の中身の決まり | プロジェクトの data_manifest_rules.md 第10節 |
回した記録のうち、人どうしの詰まりの記録(people_jams.csv、1回あたり2〜182KB)は、この記事では使っていないので載せていません。KIOXIA の同じフォルダにあります。それ以外の出力は、後ろにすべて載せます。
Claude Code への依頼文
Claude Code に送った文を、出した順にすべて載せます。最初に出した「同じ通路に2台を集めない」の文と、それに足す一言は、送る前に1つにまとめたので、まとめた文(1)だけを載せます。22時ごろからは、長い文をファイルにして Mac に置き、Claude Code には「このファイルを読んで、その通りにしてください」とだけ送っています。
1. 同じ通路に2台を集めない・新しい店の形で③⑦を建て直す(cs:125)
cs:124 で ③ を回しました(出力 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1135)。時間切れは51往復のうち16で、動けなくなった場所の1位は A01(左の通路)の入口での「もう1台のロボット」73回でした。2台が同じ通路の卓を受け持ち、入口で鉢合わせています。
今回入れるのは、次のAとBの2つだけです(人のよけ方は入れない)。

A. 同じ通路に2台を集めない
1. ロボットが料理を受け持つとき、ほかの台が向かっている、または中にいる細い通路(店の形の aisles)の卓は後に回す
2. 後に回せない料理しかないときは、待機場所で待つ(通路の入口では待たない)。通路が空いたら出る
3. 1往復で3卓をまとめるときも、ほかの台がいる通路の卓は入れない
4. この決まりは Unity だけの決まりとして RobotSpec の1か所にまとめ、入れる・入れないを切り替えられるようにする。どちらで回したかを run_info に残す。後に回した回数も summary に出す

B. 新しい店の形で③⑦を建て直す
サイトの店の形が新しくなりました(generation f282eaa6cb71。serving-robot-params.json の layout_generation も同じ)。
1. ③⑦の JSON を読み直して店を建て直す。変わったのは、レジとレジ内の向き・位置、会計に立つ点と並ぶ点、卓から卓への道順(routes.between)
2. 新しく robot_keepout(会計の列)が入った。ロボットの道順はこれをよけて作ってあるので、Unity では部屋や壁として建てない(人は通れる)。見せるための目印にするのはかまわない
3. 建て直したあと、レジ・並ぶ点・会計の列が JSON どおりの場所にあることを、真上からの Scene ビューの画面1枚で見せる

直したら Check-in して、③ を押すよう私に言ってください。前回(1135)と、動けなくなった回数・時間切れの往復・A01入口の止まり・レジの前の止まり・逃がし弁(あきらめた153・移した85・卓を空けた65)を比べます。
2. サイトのファイルは Mac に置いたものから写す
B の JSON はネットから取らなくて大丈夫です。サイトと同じファイルを Mac に置きました。ここから写してください。
~/Library/Mobile Documents/com~apple~CloudDocs/デスクトップ/ADAPT DESIGN/じぶんの/PixelstoMotors/デジタルツイン学習R2R2R/サービスロボット導入シミュレーション/unity/site_copy_f282eaa6cb71/
- summary.json
- serving-robot-params.json
- unity/p1_efficient_corner.json と unity/p5_crammed.json(ほかの店の分も入っているが、今回は使わない)
写したら、3つの版の番号(summary の generation、各店の JSON の meta.generation、params の layout_generation)がすべて f282eaa6cb71 でそろっていることを確かめてから、A と B を進めてください。
3. キッチンのモニターを足す
キッチンのモニターを足してください。見るためだけのもので、測る回(Run One・Run All・Site Run・検査)でも出します。

1. 場所:キッチンの屋根の上に、真上から読める板を1枚置く。店の形の JSON のキッチンの部屋(rect)から決め、店ごとに手で置かない
2. 中身(言葉は記録 trips.csv・stops.csv・summary.json と同じものだけを使う。画面にだけある数字を作らない)
   - ロボット1台ごと:いまの仕事(料理を運ぶ→卓の番号/戻る/待機)、止まっていればその理由(人・もう1台のロボット・通路の順番待ちなど stops.csv の原因と同じ言葉)と止まっている秒数
   - スタッフ1人ごと:いまの仕事(案内・片付け・配膳・会計・助けに行く・待つ など、記録と同じ言葉)
   - 店:経過時間、入口で待つ組、空き卓、同じ通路を避けて後に回した料理の数
3. 書き換えは、シミュレーションの時間で1秒に1回。当たり判定・NavMesh・ロボットのセンサー・人がよける処理には一切入れない
4. 切り替え:出す・出さないを1か所(既定は出す)で切り替えられるようにし、どちらで回したかを run_info に残す
5. 確かめ:③を、モニターありとなしで1回ずつ回し、倍速(現実の1秒でシミュレーションが何秒進んだか)を並べて報告する。落ちる割合が大きければ、既定を「出さない」にして報告する
6. LABEL_RULES.md に、モニターの決まり(中身・言葉は記録と同じ・測る回でも出す・切り替えの場所)を書いてから作る
7. 真上からの画面を1枚、モニターが読める大きさで screens/ に置く

直したら Check-in してください。
4. 人のよけ方に「店員優先の版」を足す(cs:126)
人のよけ方に「店員優先の版」を足してください。既定は今のよけ方のままで、切り替えで選べるようにします。

1. 店員:ロボットが近づいたら必ず道を空ける。通路の脇か通路の入口まで下がり、ロボットが通り過ぎるまで待つ(20秒で諦めない)。ただし、相手のロボットが別の理由で止まったまま60秒たったら、回り道をする(逃げ道。回数を記録する)
2. 客:ロボットの前で長くて5秒止まる。そのあと、別の道があれば回り道、なければロボットの横を詰めて通る(ロボットとのすき間は10cmまで)
3. 配膳・下げ膳で卓の前に止まっているロボットは、人にとって「よけて通る物」として扱う(客は回り道か、横を詰めて通る)
4. 立ち往生を助けに行く店員は、これまでどおり、その台をよけない
5. 5秒・10cm・60秒は Unity だけの仮の値として PeopleSpec の1か所にまとめる。切り替えも同じ所に置き、どちらで回したかを run_info に残す。60秒の逃げ道を使った回数は summary に出す
6. 確かめ:③を、店員優先の版で1回回して、前回と、受け渡し口のまわり(x 12.5〜15.8・z 4.5〜7)の止まりの回数と時間、全体の動けなくなった回数・時間切れの往復を並べて報告する

あわせて、先に送ったキッチンのモニターも入れてください。モニターにはスタッフ・客がいま「ロボットを待っている」ことも出してください(記録と同じ言葉で)。
直したら Check-in して、③ を押すよう私に言ってください。
5. 固定の前に見た目を2つ直す(cs:127)
cs:126 の作りで、③を店員優先の版で回しました(出力 …_1536)。結果を見て、Unity の作りはここで固定します。固定の前に、見た目だけ2つ直してください(シミュレーションの動きは変えない)。
1. キッチンのモニターの文字が小さすぎて、真上からの画面で読めない。キッチンの屋根の幅いっぱいに広がる大きさにする(lineHeightM を上げる)。直したら、真上からの画面を1枚 screens/ に置く
2. 回し始めに Console へ「人のよけ方: 店員優先の版/今のよけ方」が出ていなかった。回し始めの行に必ず出るようにする
直したら Check-in して、Check-in の番号を教えてください。それを固定した版の番号にします。PeopleSpec の staffFirstYield は off のままにしてください。
6. 編集中にモニターが出ない(cs:128)
cs:127 で Build Store を押したら、Console に「キッチンの部屋が見つからないので、キッチンのモニターは出しません(店の形の rooms に「キッチン」が要ります)」と出て(KitchenMonitor.cs:113、Update の75行から)、モニターが出ませんでした。真上の画面(top_w120_people.png)も前と1バイトも同じで、モニターは写っていません。
店の形の JSON(p1_efficient_corner・p5_crammed)には rooms に「キッチン」(kind back、rect [16.3, 6.5, 21.6, 13.8])が入っています。前の Play の回ではキッチンの屋根に何か出ていたので、編集中だけキッチンを探せていないと思います。
1. 編集中に、キッチンの部屋をどこから探しているかを確かめて、Build Store のあとでも見つかるように直す
2. 真上の画面を書き出すときに、モニターが写るようにする(書き出すカメラの写す範囲・書き出す順番)
3. シミュレーションの動きは変えない
直したら Check-in して、番号を教えてください。それを固定版にします。
7. モニターの字が小さい・読みにくい(cs:129)
cs:128 でモニターは出ました。向きは正しく読めます。ただ3つ直してください(動きは変えない)。
1. 文字の幅がキッチンの屋根の半分ほどしかない。fillRatio 0.92 に合わせる直しが効いていないので、実際の文字の広がりで合わせ直す処理が編集中・書き出し前にも走るようにする。屋根の幅(x)と奥行き(z)の両方に収まる大きさのうち、大きい方にする
2. 灰色の屋根に細い白い字で読みにくい。文字の後ろに、キッチンの屋根より少し小さい濃い色の板(当たりなし)を敷き、文字を太く・はっきりさせる
3. 場所の名前「厨房」の札がモニターに重なる。モニターを出すときは、キッチンの場所の名前の札を屋根の端に寄せる
直したら Check-in して番号を教えてください。私が Build Store を押して真上の画面を確かめます。
8. 大きさが変わらない原因を記録で確かめる(送る前に次の9に替わった)
cs:129 で Setup → Build Store を押しましたが、変わったのは「厨房」の札の位置だけでした。文字の大きさは屋根の幅の3分の1ほどのまま、後ろの濃い板も出ていません。
推測で直す前に、原因を記録で確かめてください。
1. FitText が呼ばれるたびに、Console に「屋根の幅・奥行き/文字の広がり(bounds の幅・奥行き)/characterSize」を1行出す
2. Backing を作るところで、作れたか・作れなかったときの理由(マテリアルがない など)を Console に出す
3. その出力を見てから直す。シミュレーションの動きは変えない
直したら Check-in して番号を教えてください。
9. モニターを吹き出しにする(cs:131)
キッチンのモニターを、屋根の上の板(TextMesh+後ろの板)から、ほかの吹き出しと同じ作りに変えてください。カメラの向きを変えても正面を向き、画面の上で読める大きさにするためです。
1. 吹き出しは1つ。置く場所はキッチンの部屋の真ん中の上。中身は今のモニターと同じ(言葉は記録と同じものだけ・書き換えは店の中の0.5秒ごと)
2. 見た目は、ほかの吹き出し(「スタッフ×2 待機」など)と同じ形・同じ字の大きさの決め方にそろえる。行が多いので、左寄せの複数行にする
3. 測る回でも出す(頭の上の字幕を測る回で切る B11 とは別に、このモニターの吹き出し1つだけは出す)。切り替えは今と同じ ExperimentPlan.showKitchenMonitor の1か所
4. 屋根の上の TextMesh・後ろの板(Backing・Mat_MonitorBoard)・大きさを合わせる処理(FitText)は外す。「厨房」の札は元の場所に戻す
5. LABEL_RULES.md の「キッチンのモニター」の節を、吹き出しにしたことに合わせて直してから作る
6. シミュレーションの動きは変えない
直したら Check-in して番号を教えてください。それを固定版にします。
10. モニターを画面に貼るパネルにする(cs:132)
キッチンのモニターの吹き出しが大きすぎて、通路やほかの札に重なります。店の上に浮かべるのをやめ、Scene ビューの画面に貼り付けるパネルに変えてください。
1. Scene ビューの左上に、画面に貼り付けたパネルとして出す(カメラを回してもズームしても、画面の上の位置は変わらない)
2. 見出し「キッチンのモニター」を掴んでドラッグすると動かせる。動かした位置は次に Unity を開いたときも覚えておく(EditorPrefs など)。画面の外に出たら、画面の中に戻す
3. 見出しを押すと、たためる・開ける
4. 字の大きさは、ほかの札(「パントリー」など)と同じくらいにする。中身・書き換え(0.5秒ごと)・言葉は今と同じ
5. 測る回でも出す。切り替えは今と同じ ExperimentPlan.showKitchenMonitor の1か所
6. LABEL_RULES.md の「キッチンのモニター」の節を、画面に貼り付けるパネルにしたことに合わせて直してから作る
7. シミュレーションの動きは変えない
直したら Check-in して番号を教えてください。それを固定版にします。
11. 10 に足した2行
8. パネルの上をクリック・ドラッグしても、後ろにある物(卓・人・ロボット)が選ばれたり動いたりしないようにする
9. 掴んで動かす作りがうまくいかないときは、別のやり方で作り込まずに、先に報告する
12. パネルの左端の線だけを消す(cs:133)
キッチンのモニターのパネルの、左端の白い線だけを消してください。それ以外は何も変えないでください。
直したら Check-in して番号を教えてください。
13. 床の水色をサイトの図面から塗る(14 の B に入れて送った)
Scene の床の水色(ロボットが入れる床)が、いまは使っていない NavMesh の形を塗っているため、ロボットが道順で入る細い通路(⑦の A01〜A03 など)が塗られず、入れないように見えます。見た目だけ直してください(動きは変えない)。
1. 床の色を NavMesh からではなく、サイトの JSON から決める。水色=ふだん走る床(routes の use=normal の道でロボットの体が通る範囲)、濃い水色=細い通路(aisles の区画と use=narrow の道でロボットの体が通る範囲)
2. 卓の横などに塗り残しが出ないよう、ロボットの体(半径0.25m)が通る範囲いっぱいまで塗る
3. 凡例の言葉を「ロボットがふだん走る床」「細い通路(狭い道で入る)」に直す
4. LABEL_RULES.md の床の色の節を直してから作る
直したら Check-in して番号を教えてください。
14. ⑦を新しい店の形(0.95m)で建て直す・床の色(cs:134)
サイトの店の形と条件が新しくなりました(版 82023936eb99)。ネットから取らず、Mac に置いたここから写してください。
~/Library/Mobile Documents/com~apple~CloudDocs/デスクトップ/ADAPT DESIGN/じぶんの/PixelstoMotors/デジタルツイン学習R2R2R/サービスロボット導入シミュレーション/unity/site_copy_82023936eb99/
(summary.json・serving-robot-params.json・unity/p1_efficient_corner.json・unity/p5_crammed.json)
変わったのは⑦だけです:細い通路3本を0.8m→0.95mにした(島を右へずらした。卓と席は同じ。細い通路の24卓は今までどおり狭い道で入る)。③は版の番号だけ変わり、形は同じです。

A. 写して、3つの版の番号がすべて 82023936eb99 でそろっていることを確かめ、③⑦を建て直す。シミュレーションの動きは cs:133 のまま変えない
B. 床の水色(見た目だけ。動きは変えない):いまは使っていない NavMesh の形を塗っているため、ロボットが道順で入る細い通路が塗られず、入れないように見える。床の色をサイトの JSON から決める。水色=ふだん走る床(routes の use=normal の道でロボットの体が通る範囲)、濃い水色=細い通路(aisles の区画と use=narrow の道でロボットの体が通る範囲)。ロボットの体(半径0.25m)が通る範囲いっぱいまで塗る。凡例は「ロボットがふだん走る床」「細い通路(狭い道で入る)」。LABEL_RULES.md の床の色の節を直してから作る
(B をすでに入れていれば、A だけでかまいません)
直したら Check-in して番号を教えてください。私が ⑦ を建てて、真上の画面を確かめます。
15. ⑦を建てるのに失敗した原因を調べる(cs:135)
cs:134 で Setup → JSON Store / ⑦ p5_crammed を押したら、建てるのに失敗しました。Console の最後の方はこうです。
- StoreLayout_p5_crammed: JSON と合わないものが 1 件あるので建てませんでした
- StoreLayout が部品の一覧を作れませんでした(席が0)
- 焼く形が見つかりません。先に Build Store を実行してください
- NullReferenceException: ServiceSimMenu.CheckNavMeshSurface
床の色の板だけが出ています。
1. ~/Library/Logs/Unity/Editor.log の今回の分から、「合わないもの」が何だったかを確かめる(⑦の通路を0.95mに広げたので、0.8mを前提にした値がどこかに残っている可能性があります)
2. 原因を報告し、直すのは Unity の中の古い値・確かめ方だけにする。サイトの JSON は正なので変えない。シミュレーションの動きも変えない
3. 建てるのに失敗したときに NullReferenceException で落ちないようにする
直したら Check-in して番号を教えてください。
16. 保留の変更の仕分け
Unity Version Control の保留中の変更(Pending Changes)が37件たまっています。段階B(台帳)に入る前に整理してください。固定版は cs:135 です(動きは cs:126 から変えていない)。
1. まず一覧を出し、1件ずつ「入れる/元に戻す/Check-out を外すだけ」に分けて、理由と一緒に報告する。私が見てから実行する(先に Check in・Undo しない)
2. 分け方の決まり
   - .git/index は Unity の管理に入れない(元に戻すか、管理の外に出す)。ほかにも Unity と関係ないファイルがあれば同じ
   - 中身が変わっていない Check-out(prefab など)は、Check-out を外すだけ
   - PeopleSpec.asset・RobotSpec.asset・ExperimentPlan.asset は、固定版の値と比べて違う所を書き出す。staffFirstYield は off、oneRobotPerAisle は on、showKitchenMonitor は on が正。回したときに入ったサイトの値(1時間あたりの組数など)が残っていれば元に戻す
   - StoreLayout_p5_crammed.asset の通路幅 0.95 は入れる(サイトの JSON と同じ)
3. シーンに保存していない変更があれば、何が変わっているかを書く(保存するかは私が決める)
4. シミュレーションの動きは変えない
17. 仕分けのとおりに整理する(cs:136)
仕分けのとおりで進めてください。順番はこうします。
1. D:ignore.conf に .git と Assets/ServiceSim/Store/old~ を足し、cm remove --nodisk .git(ディスクの .git は消さない)。Mat_MonitorBoard.mat は入れずに置いたままでよい
2. B-1:NavMeshAreas.asset を戻す。増え続ける件は別件として記録だけ残す
3. C:中身が同じ3件を一覧から外す
4. B-2 と E-3 は Unity の画面の操作なので、私がやる手順を短く書いてください(StoreLayout_Family の3項目を Inspector で直す → Use Store Layout/Family → ExperimentRunner の runLabel と _queue を空にする → Clear Built Store → 保存)。ExperimentRunner.monitor は、モニターのパネルが回しているときに本物の数字を出すのに要るなら繋ぐ(見た目だけ)
5. 私が4を終えたら、差分が A と E-1 だけになっていることを確かめてから Check in し、番号を教えてください。動きは cs:135 から変わらないことも書いてください
18. 料理の割り当てを試算 v2.7 にそろえる(cs:137)
料理の割り当ての決まりを、サイトの試算 v2.7 にそろえてください(回し方の決まりはサイトが正)。
新しい決まり:
- 料理ができたら、まずロボットを待つ。スタッフは料理を持たず、案内・片付け・会計を続ける
- 受け渡し口で robot_first_wait_s(120秒)待ってもロボットが受け持たなければ、そこからはロボットとスタッフのうち先に空いた方が運ぶ
- 割れ物を人が運ぶ設定(fragile_by=staff)と、ロボット0台のときは、今までどおりスタッフが運ぶ
- 同じ通路に2台を集めない決まり(oneRobotPerAisle)で後に回した料理も、待った時間は料理ができた時から数える

1. 条件のファイルを、Mac に置いたここから写す:
   ~/Library/Mobile Documents/com~apple~CloudDocs/デスクトップ/ADAPT DESIGN/じぶんの/PixelstoMotors/デジタルツイン学習R2R2R/サービスロボット導入シミュレーション/unity/site_copy_v27/serving-robot-params.json
   店の形の版は 82023936eb99 のまま(JSON は写し直さなくてよい)。common の robot_first_wait_s(role site_rule)を読んで使い、値を手で写さない
2. 皿ごとの記録(dishes.csv など)に、誰が運んだか・受け渡し口で待った秒数・2分を過ぎて人が拾ったかを残す。summary に「2分を過ぎて人が拾った皿」の数を出す
3. キッチンのモニターに「受け渡し口でロボットを待っている皿 N」を出す(言葉は記録と同じ)
4. ほかの動き(よけ方・通路・立ち往生の助け方など)は変えない
5. 直したら Check-in して番号を教えてください。それを新しい固定版にします。私が ③ を回し、前の回(1311)と、ロボットが運んだ料理の割合・料理が届くまでの時間・入店待ちを比べます
19. 譲る順番を決め、譲る側は道から横へどく(cs:138):claude_code_request_v6_yield.md
# 依頼 v6:譲る順番を決め、譲る側は「道から横へどく」(2026-10-23)

いまの固定版は cs:137。

受け渡し口と客席をつなぐ角(x 10.5〜13.5・z 3.5〜5.8)で、ロボットと人が向かい合って止まり、溜まっています。前の2回(1311・1536)で、ロボットが止まった時間の約3分の1がこの角でした。今の決まりは、ロボットも人も相手が動くのを待つ作りなので、譲る順番を決めて、譲る側が「道から横へどく」ようにしてください。

1. 譲る順番を1か所(RobotSpec か PeopleSpec)に決める:ロボット>スタッフ>客。立ち往生を助けに行くスタッフは今までどおり例外
2. スタッフ:ロボットが近づいたら必ず譲る(staffFirstYield の動きを既定 on にする)。その場で下がるのではなく、ロボットの道(サイトの routes の線)から横へ0.6m以上どいた、通れる床の点で待つ。そういう点がなければ、来た道を戻って通路の外で待つ
3. ロボットどうし:番号の小さい台が先。大きい台は後ろへ下がるのではなく、相手の道から横へ0.6m以上どいた点で待ち、相手が通り過ぎたら出る。どく点がなければ、手前の分かれ道の外で待つ
4. 客:今の店員優先の版のまま(長くて5秒止まり、回り道か横を詰めて通る)
5. 誰が誰に譲ったかを記録する(yields.csv:時刻・譲った側・相手・場所・待った秒数)。summary に、譲った回数と、角(上の範囲)での止まりの回数・時間を出す
6. 0.6m・待つ上限などの値は Unity だけの仮の値として1か所にまとめる。ほかの動き(料理の割り当て・通路の決まり・立ち往生の助け方)は変えない

直したら Check-in して番号を教えてください。私が ③ を回し、1311・1536 と、角の止まり・動けなくなった回数・時間切れの往復を比べます。
20. スタッフが譲るのは進む先にいるときだけ(cs:139):claude_code_request_v6b_yield_only_in_path.md
# 依頼 v6b:スタッフが譲るのは「ロボットの進む先にいるときだけ」にする(2026-10-23)

いまの固定版は cs:138。③を回した結果(出力 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227):

- 角の止まりは、ロボットが止まった時間の 32〜47% → 4% に減った(譲る順番は効いた)
- ロボットが運んだ料理は 35% → 75%、往復は 46 → 92 回
- しかしスタッフが譲った回数が 13,173 回、譲って待った時間の合計が 19,535 秒(約5.4時間)。スタッフ4人×207分の約4割が「譲っている時間」になり、案内・片付けが遅れて、入店待ちが 4.3分 → 11.4分、逃がし弁も増えた(あきらめた199・移した87・卓を空けた77)
- 譲った1回の待ちは中央値0.05秒で、ほとんどは「近くにロボットがいただけ」で譲っている

直すのは、スタッフが譲る条件だけです。

1. スタッフが譲るのは、次の両方のときだけにする
   - ロボットが動いていて、スタッフがロボットの「これから進む道」(サイトの routes の線の、ロボットの今の位置から先の 2.0m 分)から横に 0.6m+体の半径 以内にいる
   - ロボットがスタッフの方へ近づいている(離れていくロボット・止まっているロボットには譲らない。止まっているロボットは、今までどおり「よけて通る物」)
2. 譲るときの動き(道から横へ0.6m以上どく、どく点がなければ通路の外へ戻る)は cs:138 のまま
3. ロボットどうし・客の決まりは変えない。料理の割り当て・通路の決まり・立ち往生の助け方も変えない
4. 2.0m・0.6m は Unity だけの仮の値として RobotSpec の1か所にまとめる(yieldApproachM は使わなくなるなら外すか、意味を書き直す)
5. summary に、スタッフが譲った回数・合計秒数・スタッフの時間に占める割合を出す

直したら Check-in して番号を教えてください。私が ③ を回し、2227 と、スタッフが譲った回数と時間・入店待ち・角の止まり・ロボットが運んだ割合を比べます。
21. 段階B:まとめて回して台帳に1行ずつ残す(cs:140):claude_code_request_v7_stageB.md
# 依頼 v7:段階B — まとめて回して台帳に1行ずつ残す(2026-10-23)

固定版は cs:139(この依頼の前の Unity の作り)。この依頼で入れるのは「まとめて回す仕組み」と「台帳への書き出し」だけで、シミュレーションの動きは1行も変えない。

## 1. 回すもの(18回)

- 条件:serving-robot-params.json の unity_conditions の6つ(③ fam_p1・⑦ fam_p5 × ロボット0・1・2台、スタッフ4人、1時間42組、上げ膳だけ)
- 乱数の種:0・1・2
- 決まりは固定版のまま(staffFirstYield on・譲る順番 on・同じ通路に2台を集めない on・料理はロボット優先 120秒)。条件ごとに .asset を書き換えたら、回し終わりに必ず元に戻す(途中で止めても戻す)
- 回す順番:③ロボット2台 種0 → ⑦ロボット2台 種0 → 残りを条件・種の順に。最初の2回で失敗したら、残りは回さずに止める
- 途中で止めても、もう一度押せば台帳を見て「まだ回していない回」だけ続きから回す

メニューは ServiceSim / Stage B / Run All(18回)。押す前に、KIOXIA が付いているか・台帳のヘッダが合っているかを確かめ、合わなければ回し始めない。

## 2. 台帳

- 実体:/Volumes/KIOXIA/r2r2r-data/service_sim/unity/unity_ledger_v1.csv(MASTER の保存先「service_sim/unity/」の中。新しい置き場所は作らない)
- 1回 = 1行・追記のみ。既存の行を書き換えない・消さない。同じ出力フォルダの行を2度書かない(出力フォルダ名が照合キー)
- 1回終わるごとに、その回の summary.json から写して1行足す。止めた回・失敗した回も status を付けて1行残す
- 追記ガード:実体のヘッダとコードの列の並びが違えば追記しない
- 列(この順。名前を変えるときは先に私に聞く)
  timestamp, run_folder, status(completed/stopped/failed), unity_cs, layout_generation, params_model,
  store, staff, robots, arrivals_per_h, mode, trays, fragile_by, seed,
  staff_first_yield, yield_order_enabled, one_robot_per_aisle, robot_first_wait_s,
  everyone_left, total_minutes, wall_seconds,
  entry_wait_mean, staff_wait_mean, dish_wait_mean, cold_share, robot_share, staff_util, robot_util, walk_km_per_staff,
  site_entry_wait_mean, site_staff_wait_mean, site_dish_wait_mean, site_robot_share,
  robot_speed_mps, pause_rate, pause_s_mean, stuck_rate,
  trips, timeouts, stuck_count, stop_s_total, corner_stop_time_share,
  gave_up, warped, table_freed, rescues,
  late_staff_dishes, staff_yield_share_of_staff_time,
  ledger_schema_version(=1)
- site_* は params の unity_conditions の site_result(同じ条件のサイトの試算)から写す
- robot_speed_mps・pause_rate・pause_s_mean・stuck_rate は、サイトの試算と同じ定義で Unity が測った値(定義は params の common の role unity_measures の説明に合わせる。合わせ方が分からない値は空欄にして報告する)
- unity_cs は回し始めの Unity Version Control の changeset 番号(保留中の変更があれば status に関係なく run_info に「保留あり」と書く)

## 3. 回しっぱなしにするための作り

- 1回ごとに Play を出入りして、前の回の人・ロボット・NavMesh を持ち越さない
- 1回の上限は今までどおり(シミュレーション600分)。実時間で1回40分を超えたら、その回は stopped で台帳に残して次へ進む
- Mac がスリープしないように、回している間は caffeinate などでスリープを止める(回し終わったら戻す)
- 全部終わったら Console と run_all_log.txt(service_sim/unity/ に置く)に、18回それぞれの status・実時間・入店待ち・ロボットが運んだ割合の一覧を出す

## 4. 変えないもの

シミュレーションの動き(料理の割り当て・譲り方・通路・立ち往生の助け方・NavMesh・センサー)。店の形の JSON と params。

直したら Check-in して番号を教えてください。私が1回目(③ロボット2台 種0)の台帳の行を確かめてから、残りを夜に回してもらいます。
22. 段階Bの押し直しを安全にする(まだ送っていない):claude_code_request_v7b_stageB_resume.md
# 依頼 v7b:段階Bの押し直しを安全にする(2026-10-24)

固定版 cs:140 の段階B(18回)は全部 completed で終わった。押し直したときの3点だけ直す。シミュレーションの動き・台帳の列は変えない。

1. 押し直しの照らし合わせを、出力フォルダ名(日付入り)ではなく「店・ロボット台数・種」で行う。台帳に同じ条件・同じ種の行があれば、日付が違っても回さない
2. 書き出す先のフォルダが既にあるときは、そこに書かない(上書きしない)。末尾に _2、_3 … を付けた新しいフォルダに書く
3. run_info.json の pending_changes が空になっていた(保留が2件あったはず)。保留の数を正しく書く。数え方が分からなければ「不明」と書く

台帳の既存の18行と、出力フォルダは触らない。直したら Check-in して番号を教えてください。
19〜22 で Claude Code に打った一言(例:21)
unity/claude_code_request_v7_stageB.md を読んで、その通りにしてください
Claude Code の報告
この記事のコード・ログ・データは、1ファイルずつ下に置いています。全文はリンク先にあります。
ファイルの一覧(229本)
01_sec18.txt ― 20:36 保留の変更の仕分け(ファイル)・15,704字
02_sec18.txt ― 21:06 整理の1〜3の報告(ファイル)・3,611字
03_sec18.txt ― 21:55 cs:137 の報告(ファイル)・3,445字
04_sec18.txt ― 23:48 cs:140 の報告(ファイル)・3,476字
05_sec19.txt ― コミット e5209a1 2026-10-23 12:22:06 +0900 店の形:③⑥⑦のレジを縦向きにし、会計に立つ点・並ぶ点とロボットの道の距離の確かめを足す(作業中・②は未決)・4,151字
06_sec19.txt ― コミット 0401560 2026-10-23 12:36:09 +0900 店の形:会計の列をロボットの道にしない(人は通れる)。②は列の前を横切らず、レジ横を回る(作業中・公開前)・10,865字
07_sec19.txt ― コミット 2ab87bd 2026-10-23 17:51:43 +0900 店の形:⑦の細い通路を0.8mから0.9mに(島を右へずらす・卓と席は同じ)。作業中・公開前・3,106字
08_sec19.txt ― コミット 9e1ecf9 2026-10-23 18:27:49 +0900 店の形:⑦の細い通路を0.95mに(島を右へずらす・卓と席は同じ)。試算を v2.6 に(⑦だけ回し直し、ページの平面図もいまの店の形に)。公開前・7,843字
09_tools_sim_layouts_famires_v3.py.txt ― tools/sim_layouts/famires_v3.py(main・版 82023936eb99 の時点)・50,378字
10_tools_sim_layouts_famires_gen2.py.txt ― tools/sim_layouts/famires_gen2.py(main・版 82023936eb99 の時点)・20,539字
11_tools_sim_layouts_unity_export.py.txt ― tools/sim_layouts/unity_export.py(main・版 82023936eb99 の時点)・24,575字
12_tools_sim_layouts_test_famires_v3.py.txt ― tools/sim_layouts/test_famires_v3.py(main・版 82023936eb99 の時点)・20,413字
13_tools_sim_layouts_README.md ― tools/sim_layouts/README.md(main・版 82023936eb99 の時点)・6,691字
14_wip_robot-first-v27.txt ― 枝 wip/robot-first-v27(試算 v2.7・未公開)の serving-robot-params.json の差分・5,284字
15_simulation_v2_6_build_page_v26.py.txt ― simulation/v2_6/build_page_v26.py・4,595字
16_sec20.txt ― haizen_sim.py の v2.6 → v2.7 の差分・3,218字
17_simulation_v2_7_haizen_sim.py.txt ― simulation/v2_7/haizen_sim.py(v2.7・全文)・31,396字
18_simulation_v2_7_build_page_v27.py.txt ― simulation/v2_7/build_page_v27.py・5,030字
19_Assets_ServiceSim_Editor_ServiceSimLabels.cs.txt ― Assets/ServiceSim/Editor/ServiceSimLabels.cs・35,486字
20_Assets_ServiceSim_Editor_ServiceSimLedger.cs.txt ― Assets/ServiceSim/Editor/ServiceSimLedger.cs・9,467字
21_Assets_ServiceSim_Editor_ServiceSimLegend.cs.txt ― Assets/ServiceSim/Editor/ServiceSimLegend.cs・7,781字
22_Assets_ServiceSim_Editor_ServiceSimMenu.cs.txt ― Assets/ServiceSim/Editor/ServiceSimMenu.cs・62,883字
23_Assets_ServiceSim_Editor_ServiceSimSetup.cs.txt ― Assets/ServiceSim/Editor/ServiceSimSetup.cs・54,380字
24_Assets_ServiceSim_Editor_ServiceSimStage2.cs.txt ― Assets/ServiceSim/Editor/ServiceSimStage2.cs・9,874字
25_Assets_ServiceSim_Editor_ServiceSimStageB.cs.txt ― Assets/ServiceSim/Editor/ServiceSimStageB.cs・29,957字
26_Assets_ServiceSim_Experiment_ExperimentPlan.cs.txt ― Assets/ServiceSim/Experiment/ExperimentPlan.cs・6,257字
27_Assets_ServiceSim_Experiment_ExperimentRunner.cs.txt ― Assets/ServiceSim/Experiment/ExperimentRunner.cs・47,715字
28_Assets_ServiceSim_Experiment_SiteValues.cs.txt ― Assets/ServiceSim/Experiment/SiteValues.cs・12,775字
29_Assets_ServiceSim_Experiment_TripLogger.cs.txt ― Assets/ServiceSim/Experiment/TripLogger.cs・71,810字
30_Assets_ServiceSim_LABEL_RULES.md ― Assets/ServiceSim/LABEL_RULES.md・5,671字
31_Assets_ServiceSim_People_PeopleSpec.cs.txt ― Assets/ServiceSim/People/PeopleSpec.cs・9,078字
32_Assets_ServiceSim_People_PersonRobotYield.cs.txt ― Assets/ServiceSim/People/PersonRobotYield.cs・34,120字
33_Assets_ServiceSim_People_StaffAgent.cs.txt ― Assets/ServiceSim/People/StaffAgent.cs・17,657字
34_Assets_ServiceSim_Robot_RobotSpec.cs.txt ― Assets/ServiceSim/Robot/RobotSpec.cs・7,699字
35_Assets_ServiceSim_Robot_ServingRobotController.cs.txt ― Assets/ServiceSim/Robot/ServingRobotController.cs・67,775字
36_Assets_ServiceSim_Robot_YieldSide.cs.txt ― Assets/ServiceSim/Robot/YieldSide.cs・3,666字
37_Assets_ServiceSim_Service_ServiceOps.cs.txt ― Assets/ServiceSim/Service/ServiceOps.cs・58,949字
38_Assets_ServiceSim_Service_ServiceSpec.cs.txt ― Assets/ServiceSim/Service/ServiceSpec.cs・6,754字
39_Assets_ServiceSim_Store_FloorPaint.cs.txt ― Assets/ServiceSim/Store/FloorPaint.cs・11,863字
40_Assets_ServiceSim_Store_JsonStoreLayout.cs.txt ― Assets/ServiceSim/Store/JsonStoreLayout.cs・32,090字
41_Assets_ServiceSim_Store_KitchenMonitor.cs.txt ― Assets/ServiceSim/Store/KitchenMonitor.cs・8,755字
42_Assets_ServiceSim_Store_RouteBook.cs.txt ― Assets/ServiceSim/Store/RouteBook.cs・4,764字
43_Assets_ServiceSim_Store_StoreBuilder.cs.txt ― Assets/ServiceSim/Store/StoreBuilder.cs・21,622字
44_Assets_ServiceSim_Store_StorePlan.cs.txt ― Assets/ServiceSim/Store/StorePlan.cs・11,714字
45_unity_unity_design_v0.md ― unity/unity_design_v0.md・13,761字
46_unity_ledger_v1.csv ― unity_ledger_v1.csv・5,551字
47_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_summary.json ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/summary.json・5,252字
48_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_trips.csv ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/trips.csv・8,665字
49_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_stops.csv ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/stops.csv・62,434字
50_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_give_ups.csv ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/give_ups.csv・17,679字
51_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_groups.csv ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/groups.csv・8,571字
52_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_contacts.csv ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/contacts.csv・3,963字
53_s0_1311_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311_conditions.json ― 1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/conditions.json・9,179字
54_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_summary.json ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/summary.json・5,311字
55_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_trips.csv ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/trips.csv・10,086字
56_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_stops.csv ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/stops.csv・69,960字
57_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_give_ups.csv ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/give_ups.csv・22,742字
58_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_groups.csv ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/groups.csv・9,621字
59_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_contacts.csv ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/contacts.csv・6,561字
60_s0_1536_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536_conditions.json ― 1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/conditions.json・9,332字
61_s0_1941_20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941_summary.json ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/summary.json・5,280字
62_sec24.csv ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/trips.csv・8,322字
63_sec24.csv ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/stops.csv・53,840字
64_sec24.csv ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/give_ups.csv・7,888字
65_sec24.csv ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/groups.csv・7,755字
66_s0_1941_20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941_conditions.json ― 1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/conditions.json・9,312字
67_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_summary.json ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/summary.json・5,796字
68_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_trips.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/trips.csv・16,505字
69_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_stops.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/stops.csv・84,242字
70_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_dishes.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/dishes.csv・20,735字
71_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_yields.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/yields.csv・1,061,871字
72_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_give_ups.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/give_ups.csv・28,669字
73_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_groups.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/groups.csv・9,295字
74_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_contacts.csv ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/contacts.csv・11,434字
75_s0_2227_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227_conditions.json ― 2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/conditions.json・9,586字
76_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_summary.json ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/summary.json・5,937字
77_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_trips.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/trips.csv・15,444字
78_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_stops.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/stops.csv・68,044字
79_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_dishes.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/dishes.csv・20,603字
80_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_yields.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/yields.csv・99,598字
81_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_give_ups.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/give_ups.csv・17,194字
82_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_groups.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/groups.csv・9,537字
83_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_contacts.csv ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/contacts.csv・7,336字
84_s0_2253_20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253_conditions.json ― 2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253 / 20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/conditions.json・9,587字
85_s0_2309_20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309_summary.json ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/summary.json・5,918字
86_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/trips.csv・15,725字
87_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/stops.csv・58,275字
88_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/dishes.csv・20,259字
89_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/yields.csv・190,533字
90_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/give_ups.csv・11,775字
91_sec24.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/groups.csv・9,139字
92_s0_2309_20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309_contacts.csv ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/contacts.csv・5,514字
93_s0_2309_20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309_conditions.json ― 2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309 / 20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/conditions.json・9,566字
94_1023_stageB_fam_p1_r0_s0_20261023_stageB_fam_p1_r0_s0_summary.json ― 段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0 / 20261023_stageB_fam_p1_r0_s0/summary.json・4,486字
95_1023_stageB_fam_p1_r0_s0_20261023_stageB_fam_p1_r0_s0_dishes.csv ― 段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0 / 20261023_stageB_fam_p1_r0_s0/dishes.csv・17,388字
96_1023_stageB_fam_p1_r0_s0_20261023_stageB_fam_p1_r0_s0_give_ups.csv ― 段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0 / 20261023_stageB_fam_p1_r0_s0/give_ups.csv・3,367字
97_1023_stageB_fam_p1_r0_s0_20261023_stageB_fam_p1_r0_s0_groups.csv ― 段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0 / 20261023_stageB_fam_p1_r0_s0/groups.csv・8,588字
98_1023_stageB_fam_p1_r0_s0_20261023_stageB_fam_p1_r0_s0_conditions.json ― 段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0 / 20261023_stageB_fam_p1_r0_s0/conditions.json・9,587字
99_1023_stageB_fam_p1_r0_s1_20261023_stageB_fam_p1_r0_s1_summary.json ― 段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1 / 20261023_stageB_fam_p1_r0_s1/summary.json・4,483字
100_1023_stageB_fam_p1_r0_s1_20261023_stageB_fam_p1_r0_s1_dishes.csv ― 段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1 / 20261023_stageB_fam_p1_r0_s1/dishes.csv・17,766字
101_1023_stageB_fam_p1_r0_s1_20261023_stageB_fam_p1_r0_s1_give_ups.csv ― 段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1 / 20261023_stageB_fam_p1_r0_s1/give_ups.csv・3,284字
102_1023_stageB_fam_p1_r0_s1_20261023_stageB_fam_p1_r0_s1_groups.csv ― 段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1 / 20261023_stageB_fam_p1_r0_s1/groups.csv・8,453字
103_1023_stageB_fam_p1_r0_s1_20261023_stageB_fam_p1_r0_s1_conditions.json ― 段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1 / 20261023_stageB_fam_p1_r0_s1/conditions.json・9,587字
104_1023_stageB_fam_p1_r0_s2_20261023_stageB_fam_p1_r0_s2_summary.json ― 段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2 / 20261023_stageB_fam_p1_r0_s2/summary.json・4,485字
105_1023_stageB_fam_p1_r0_s2_20261023_stageB_fam_p1_r0_s2_dishes.csv ― 段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2 / 20261023_stageB_fam_p1_r0_s2/dishes.csv・19,009字
106_1023_stageB_fam_p1_r0_s2_20261023_stageB_fam_p1_r0_s2_give_ups.csv ― 段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2 / 20261023_stageB_fam_p1_r0_s2/give_ups.csv・3,375字
107_1023_stageB_fam_p1_r0_s2_20261023_stageB_fam_p1_r0_s2_groups.csv ― 段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2 / 20261023_stageB_fam_p1_r0_s2/groups.csv・9,104字
108_1023_stageB_fam_p1_r0_s2_20261023_stageB_fam_p1_r0_s2_conditions.json ― 段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2 / 20261023_stageB_fam_p1_r0_s2/conditions.json・9,587字
109_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_summary.json ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/summary.json・6,129字
110_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_trips.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/trips.csv・9,992字
111_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_stops.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/stops.csv・31,287字
112_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_dishes.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/dishes.csv・20,042字
113_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_yields.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/yields.csv・100,718字
114_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_give_ups.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/give_ups.csv・9,608字
115_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_groups.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/groups.csv・9,285字
116_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_contacts.csv ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/contacts.csv・5,026字
117_1023_stageB_fam_p1_r1_s0_20261023_stageB_fam_p1_r1_s0_conditions.json ― 段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0 / 20261023_stageB_fam_p1_r1_s0/conditions.json・9,587字
118_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_summary.json ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/summary.json・6,077字
119_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_trips.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/trips.csv・11,517字
120_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_stops.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/stops.csv・31,114字
121_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_dishes.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/dishes.csv・16,463字
122_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_yields.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/yields.csv・44,179字
123_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_give_ups.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/give_ups.csv・6,201字
124_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_groups.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/groups.csv・7,761字
125_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_contacts.csv ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/contacts.csv・4,212字
126_1023_stageB_fam_p1_r1_s1_20261023_stageB_fam_p1_r1_s1_conditions.json ― 段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1 / 20261023_stageB_fam_p1_r1_s1/conditions.json・9,587字
127_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_summary.json ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/summary.json・6,137字
128_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_trips.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/trips.csv・10,504字
129_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_stops.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/stops.csv・33,983字
130_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_dishes.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/dishes.csv・19,645字
131_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_yields.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/yields.csv・24,002字
132_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_give_ups.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/give_ups.csv・7,394字
133_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_groups.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/groups.csv・9,006字
134_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_contacts.csv ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/contacts.csv・3,040字
135_1023_stageB_fam_p1_r1_s2_20261023_stageB_fam_p1_r1_s2_conditions.json ― 段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2 / 20261023_stageB_fam_p1_r1_s2/conditions.json・9,587字
136_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_summary.json ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/summary.json・6,353字
137_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_trips.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/trips.csv・15,852字
138_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_stops.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/stops.csv・67,031字
139_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_dishes.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/dishes.csv・18,968字
140_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_yields.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/yields.csv・173,092字
141_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_give_ups.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/give_ups.csv・15,242字
142_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_groups.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/groups.csv・8,773字
143_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_contacts.csv ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/contacts.csv・5,669字
144_1023_stageB_fam_p1_r2_s0_20261023_stageB_fam_p1_r2_s0_conditions.json ― 段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0 / 20261023_stageB_fam_p1_r2_s0/conditions.json・9,587字
145_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_summary.json ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/summary.json・6,326字
146_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_trips.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/trips.csv・13,376字
147_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_stops.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/stops.csv・63,321字
148_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_dishes.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/dishes.csv・16,785字
149_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_yields.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/yields.csv・43,170字
150_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_give_ups.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/give_ups.csv・11,104字
151_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_groups.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/groups.csv・7,822字
152_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_contacts.csv ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/contacts.csv・5,865字
153_1023_stageB_fam_p1_r2_s1_20261023_stageB_fam_p1_r2_s1_conditions.json ― 段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1 / 20261023_stageB_fam_p1_r2_s1/conditions.json・9,587字
154_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_summary.json ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/summary.json・6,363字
155_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_trips.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/trips.csv・15,668字
156_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_stops.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/stops.csv・88,322字
157_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_dishes.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/dishes.csv・19,387字
158_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_yields.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/yields.csv・358,461字
159_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_give_ups.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/give_ups.csv・16,892字
160_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_groups.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/groups.csv・9,008字
161_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_contacts.csv ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/contacts.csv・8,347字
162_1023_stageB_fam_p1_r2_s2_20261023_stageB_fam_p1_r2_s2_conditions.json ― 段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2 / 20261023_stageB_fam_p1_r2_s2/conditions.json・9,587字
163_1023_stageB_fam_p5_r0_s0_20261023_stageB_fam_p5_r0_s0_summary.json ― 段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0 / 20261023_stageB_fam_p5_r0_s0/summary.json・4,508字
164_1023_stageB_fam_p5_r0_s0_20261023_stageB_fam_p5_r0_s0_dishes.csv ― 段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0 / 20261023_stageB_fam_p5_r0_s0/dishes.csv・19,780字
165_1023_stageB_fam_p5_r0_s0_20261023_stageB_fam_p5_r0_s0_give_ups.csv ― 段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0 / 20261023_stageB_fam_p5_r0_s0/give_ups.csv・4,906字
166_1023_stageB_fam_p5_r0_s0_20261023_stageB_fam_p5_r0_s0_groups.csv ― 段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0 / 20261023_stageB_fam_p5_r0_s0/groups.csv・8,967字
167_1023_stageB_fam_p5_r0_s0_20261023_stageB_fam_p5_r0_s0_conditions.json ― 段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0 / 20261023_stageB_fam_p5_r0_s0/conditions.json・9,566字
168_1023_stageB_fam_p5_r0_s1_20261023_stageB_fam_p5_r0_s1_summary.json ― 段階B ⑦・ロボット0台・種1(cs:140):20261023_stageB_fam_p5_r0_s1 / 20261023_stageB_fam_p5_r0_s1/summary.json・4,501字
169_1023_stageB_fam_p5_r0_s1_20261023_stageB_fam_p5_r0_s1_dishes.csv ― 段階B ⑦・ロボット0台・種1(cs:140):20261023_stageB_fam_p5_r0_s1 / 20261023_stageB_fam_p5_r0_s1/dishes.csv・15,372字
170_1023_stageB_fam_p5_r0_s1_20261023_stageB_fam_p5_r0_s1_groups.csv ― 段階B ⑦・ロボット0台・種1(cs:140):20261023_stageB_fam_p5_r0_s1 / 20261023_stageB_fam_p5_r0_s1/groups.csv・7,325字
171_1023_stageB_fam_p5_r0_s1_20261023_stageB_fam_p5_r0_s1_conditions.json ― 段階B ⑦・ロボット0台・種1(cs:140):20261023_stageB_fam_p5_r0_s1 / 20261023_stageB_fam_p5_r0_s1/conditions.json・9,566字
172_1023_stageB_fam_p5_r0_s2_20261023_stageB_fam_p5_r0_s2_summary.json ― 段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2 / 20261023_stageB_fam_p5_r0_s2/summary.json・4,474字
173_1023_stageB_fam_p5_r0_s2_20261023_stageB_fam_p5_r0_s2_dishes.csv ― 段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2 / 20261023_stageB_fam_p5_r0_s2/dishes.csv・16,733字
174_1023_stageB_fam_p5_r0_s2_20261023_stageB_fam_p5_r0_s2_give_ups.csv ― 段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2 / 20261023_stageB_fam_p5_r0_s2/give_ups.csv・3,828字
175_1023_stageB_fam_p5_r0_s2_20261023_stageB_fam_p5_r0_s2_groups.csv ― 段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2 / 20261023_stageB_fam_p5_r0_s2/groups.csv・7,872字
176_1023_stageB_fam_p5_r0_s2_20261023_stageB_fam_p5_r0_s2_conditions.json ― 段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2 / 20261023_stageB_fam_p5_r0_s2/conditions.json・9,566字
177_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_summary.json ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/summary.json・6,112字
178_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_trips.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/trips.csv・10,216字
179_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_stops.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/stops.csv・32,323字
180_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_dishes.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/dishes.csv・19,897字
181_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_yields.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/yields.csv・77,361字
182_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_give_ups.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/give_ups.csv・8,866字
183_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_groups.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/groups.csv・9,086字
184_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_contacts.csv ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/contacts.csv・4,097字
185_1023_stageB_fam_p5_r1_s0_20261023_stageB_fam_p5_r1_s0_conditions.json ― 段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0 / 20261023_stageB_fam_p5_r1_s0/conditions.json・9,566字
186_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_summary.json ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/summary.json・6,133字
187_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_trips.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/trips.csv・12,216字
188_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_stops.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/stops.csv・34,317字
189_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_dishes.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/dishes.csv・22,543字
190_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_yields.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/yields.csv・221,037字
191_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_give_ups.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/give_ups.csv・11,585字
192_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_groups.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/groups.csv・10,086字
193_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_contacts.csv ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/contacts.csv・4,062字
194_1023_stageB_fam_p5_r1_s1_20261023_stageB_fam_p5_r1_s1_conditions.json ― 段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1 / 20261023_stageB_fam_p5_r1_s1/conditions.json・9,566字
195_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_summary.json ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/summary.json・6,115字
196_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_trips.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/trips.csv・12,101字
197_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_stops.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/stops.csv・29,565字
198_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_dishes.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/dishes.csv・22,517字
199_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_yields.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/yields.csv・96,035字
200_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_give_ups.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/give_ups.csv・9,026字
201_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_groups.csv ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/groups.csv・10,468字
202_1023_stageB_fam_p5_r1_s2_20261023_stageB_fam_p5_r1_s2_conditions.json ― 段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2 / 20261023_stageB_fam_p5_r1_s2/conditions.json・9,566字
203_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_summary.json ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/summary.json・6,355字
204_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_trips.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/trips.csv・19,258字
205_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_stops.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/stops.csv・72,161字
206_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_dishes.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/dishes.csv・24,910字
207_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_yields.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/yields.csv・291,288字
208_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_give_ups.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/give_ups.csv・19,714字
209_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_groups.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/groups.csv・11,158字
210_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_contacts.csv ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/contacts.csv・7,216字
211_1023_stageB_fam_p5_r2_s0_20261023_stageB_fam_p5_r2_s0_conditions.json ― 段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0 / 20261023_stageB_fam_p5_r2_s0/conditions.json・9,566字
212_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_summary.json ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/summary.json・6,315字
213_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_trips.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/trips.csv・16,350字
214_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_stops.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/stops.csv・74,782字
215_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_dishes.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/dishes.csv・16,500字
216_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_yields.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/yields.csv・176,460字
217_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_give_ups.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/give_ups.csv・8,322字
218_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_groups.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/groups.csv・7,579字
219_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_contacts.csv ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/contacts.csv・4,583字
220_1023_stageB_fam_p5_r2_s1_20261023_stageB_fam_p5_r2_s1_conditions.json ― 段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1 / 20261023_stageB_fam_p5_r2_s1/conditions.json・9,566字
221_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_summary.json ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/summary.json・6,357字
222_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_trips.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/trips.csv・20,138字
223_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_stops.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/stops.csv・96,485字
224_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_dishes.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/dishes.csv・23,174字
225_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_yields.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/yields.csv・232,612字
226_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_give_ups.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/give_ups.csv・14,211字
227_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_groups.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/groups.csv・10,765字
228_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_contacts.csv ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/contacts.csv・8,122字
229_1023_stageB_fam_p5_r2_s2_20261023_stageB_fam_p5_r2_s2_conditions.json ― 段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2 / 20261023_stageB_fam_p5_r2_s2/conditions.json・9,566字
Claude Code から返ってきた報告を、時刻の順にすべて載せます。チャットに貼った報告と、ファイルで渡した報告があります。
13:10 cs:125 の報告(ファイル)
A と B を cs:125 で入れました。版は先に確かめ、3つとも f282eaa6cb71
  でそろっていました(summary の6店すべて/③⑦の meta.generation/params の
  layout_generation)。

  A. 同じ通路に2台を集めない
  料理を受け持つ前に「ほかの台が押さえている通路」を作り、その通路の卓を飛ばしま
  す。押さえているとみなすのは〈まだ届けていない卓の通路〉と〈いま体がその通路の
  区画の中にある台の通路〉です。1往復で3卓まとめるときも1皿ごとに同じ判定をするの
  で入りません。
  後に回せる料理が無ければ受け持たず、台は Idle のまま → 待機場所へ下がります(通
  路の入口では待ちません)。通路が空けば次のコマで出ます。
  切り替えは RobotSpec.oneRobotPerAisle(既定 on)の1か所。どちらで回したかは
  run_info.json の one_robot_per_aisle、後に回した回数は summary.json の
  aisle_deferrals(1皿につき1回だけ数えます)と Console に出します。

  B. 新しい店の形
  4ファイルを写し、.asset の fetchedAt を「2026-10-23 13:00:00 JST(版
  f282eaa6cb71)」に直しました。前の版との差は(③⑦とも同じ):

  ┌───────────────┬──────────────────────┬───────────────────────────────────┐
  │               │          旧          │                新                 │
  ├───────────────┼──────────────────────┼───────────────────────────────────┤
  │               │ rect                 │ rect [3.3,0.4,4.0,2.9] / point    │
  │ レジ          │ [3.3,2.2,6.1,2.9] /  │ (2.9,1.65)                        │
  │               │ point (4.7,3.3)      │                                   │
  ├───────────────┼──────────────────────┼───────────────────────────────────┤
  │               │ rect                 │ rect [4.0,0.4,4.9,2.9] / point    │
  │ レジ内        │ [3.3,1.3,6.1,2.2] /  │ (4.45,1.65)                       │
  │               │ point (4.7,1.75)     │                                   │
  ├───────────────┼──────────────────────┼───────────────────────────────────┤
  │ 並ぶ点        │ 2つ                  │ 3つ                               │
  │               │ (4.7,3.8)(4.7,4.3)   │ (2.4,1.65)(1.9,1.65)(1.4,1.65)    │
  ├───────────────┼──────────────────────┼───────────────────────────────────┤
  │               │                      │ 1件・会計の列・rect               │
  │ robot_keepout │ なし                 │ [1.15,1.15,3.3,2.15](2.15×1.00   │
  │               │                      │ m)                               │
  └───────────────┴──────────────────────┴───────────────────────────────────┘

  routes.between は作り直されています(本数は 861 のまま)。from_pass
  の点と卓の止まる位置は 42卓すべて前と同じでした。

  robot_keepout は部屋や壁として建てず、床に印だけ出します(当たりなし・厚み 0.02
  m。NavMesh・センサー・真上の重なりの確かめには入りません)。JSON
  の数字で先に確かめたこと:並ぶ点3つはすべて keepout の中、そして from_pass
  42本・between 861本のうち keepout を通る道は
  0本でした(サイトがよけて作ってあるので Unity で建てる必要がありません)。

  押す順番(コンパイルが終わってから)
  1. ServiceSim/Build Store — B の3番の画面が出ます。screens/ の
  …_top_w120_people.png
  で、レジが左下の縦向きに、並ぶ点3つが横一列に、会計の列が赤い半透明の板として
  JSON どおりの場所にあるか見てください。store_report.txt
  の「ロボットが通らない所 (robot_keepout): 1 → 会計の列」と「届かない卓 0 /
  42」も確かめてください(レジが動いたので、ここは念のため見たいです)
  2. ServiceSim/Site Run/③ スタッフ4人・ロボット2台

  前回(1135)と比べるのは、動けなくなった回数・時間切れの往復・A01入口の止まり・
  レジの前の止まり・逃がし弁(あきらめた153/移した85/卓を空けた65)です。あわせ
  て Console の「同じ通路を避けて後に回した N 回」も見てください(0 だと A
  が働いていません)。
14:57 cs:126 の報告(チャット)
cs:126 で入れました。両方とも、先に LABEL_RULES.md に決まりを書いてから作ってい
  ます(「キッチンのモニター」「人のよけ方の版」の2節)。

  店員優先の版(切り替え。既定は今のよけ方)
  1. 店員は、入口で待つ・通路の中で下がる のどちらもロボットが通り過ぎるまで待ち
  ます(20秒で諦めません)。逃げ道は、相手のロボットが別の理由で止まったまま
  60秒たったら回り道(立ち往生中は「60秒+待った分」として数えます)。回数は
  summary.json の robot_stuck_detours。
  2. 客は長くて
  5秒止まり、過ぎたら回り道、道が無ければ「詰めて通る」に入って空けるすき間を
  0.30 m → 0.10 m にします。次の行動で元に戻ります。
  3. 卓の前に止まっているロボットも同じ道を通るので、客は回り道か横を詰めて通りま
  す(止まったままでも人は進めます)。
  4. 立ち往生を助けに行く店員は、これまでどおりその台をよけません。
  5. 5秒・10cm・60秒と切り替えは PeopleSpec
  の「店員優先の版」の欄1か所。どちらで回したかは run_info.json と summary.json
  の staff_first_yield に残します。

  キッチンのモニター
  キッチンの部屋の真ん中・壁の高さ+0.2 m
  に、真上から読める向きで出します。出す内容は、ロボット(台ごとに仕事+「一時停
  止:(理由)」)/スタッフ(仕事ごとの人数)/ロボット待ち スタッフ N 人 / 客
  N 人(回り道 N 人)/組・皿/逃がし弁・立ち往生。言葉は記録と同じものだけです。
  書き換えは店の中の 0.5 秒ごと、切り替えは
  ExperimentPlan.showKitchenMonitor、測る回でも出します。当たり判定は持ちません。

  2点だけ申し送りです。
  - スタッフの仕事は記録では「料理」ですが、LABEL_RULES
  の表では「配膳」なので、モニターだけ「配膳」に直して出します(CSV
  の言葉は過去の記録と比べるため変えません)。
  - 「ロボット待ち」だけは客も人数で数えます(立っている1人の状態なので)。LABEL_
  RULES にもそう書きました。

  押してください(コンパイルが終わってから)
  1. ServiceSim/Setup — モニターの入れ物をシーンに作ります(今回だけ必要です)
  2. ServiceSim/Site Run/③ スタッフ4人・ロボット2台

  6番の確かめは店員優先の版で回す必要があるので、PeopleSpec.asset の
  staffFirstYield を on にしてから押してください(既定は off
  のままにしてあります)。Console の「人のよけ方:
  店員優先の版」で入っているか分かります。

  回し終わったら出力フォルダを教えてください。前回(1135)と並べて、受け渡し口の
  まわり(x 12.5〜15.8・z 4.5〜7)の止まりの回数と時間/全体の動けなくなった回数
  /時間切れの往復を表にして報告します。

  モニターについては、文字が四角になるか、上下さかさまか、大きすぎ/小さすぎだっ
  たら教えてください(順に、フォント名の追加・flip を on・lineHeightM
  で直します)。
16:08 cs:127 の報告(チャット)
⏺ 見た目だけ2つ直して cs:127 で入れました。

  1. モニターの大きさ — 文字の大きさを、できた文字の実際の広がりからキッチンの屋
  根の幅に合わせて自分で決めるようにしました(fitToKitchenWidth 既定
  on、幅に占める割合 fillRatio
  0.92)。行数や文の長さが変わっても読める大きさになります。lineHeightM
  の初期値も 0.34 → 0.9 m に上げました(合わせる前の目安)。
  あわせて、編集中(Build Store のあと)も出すようにしました。中身は「見本」で、
  回すと本物の数字に変わります。モニターは Play
  中しか動かない作りだったので、これを入れないと真上の画面に写りませんでした。

  2. 回し始めの行 — 「回し始め …」の行に、次を必ず出すようにしました(前は回し終
  わりの行にしかありませんでした)。

  人のよけ方: 店員優先の版 / 今のよけ方
  同じ通路に2台を集めない: 入れた / 入れない
  戻りの線: 使う / 使わない
  キッチンのモニター: 出す / 出さない

  PeopleSpec.staffFirstYield は off
  に戻しました(既定は今のよけ方)。シミュレーションの動き(止まる決まり・道の選
  び方・人のよけ方の中身)は1行も変えていません。

  固定する版の番号:cs:127 です。

  ひとつだけ、私からはできないことが残っています。真上からの画面(screens/)は私
  が Unity を動かせないため出せません。 ServiceSim/Build Store
  を押していただければ、screens/{日付}_family_v0_top_w120_people.png
  にモニター入りの真上の画面が出ます。それで

  - 文字が屋根の幅いっぱいに広がって読めるか
  - 上下さかさまでないか(さかさまなら KitchenMonitor.flip を on にしてください)
  - 文字が四角になっていないか(なっていたらフォント名を足します)

  を確かめてください。直しが要るようでしたら、その分だけ入れて番号を更新します。
  読めていれば cs:127 が固定版です。
16:18 cs:128 の報告(チャット)
cs:128 です。

  原因:キッチンの部屋は店を建てたあとでないと分かりません(StoreBuilder.Plan
  が持っています)。[ExecuteAlways] にしたことで編集中の Update が Build Store
  より先にも走り、そのとき部屋が見つからず、警告を出して show を off
  に固定していました。そのあと Build Store で建てても off のままなので出ません。
  真上の画面が前と1バイトも同じだったのは、板が1つも作られていなかったからです。

  1. 探すところ — 見つからないときは何もせずに戻るようにしました(show を off
  にしません)。毎コマ見直すので、Build Store
  で建てたあとは見つかります。警告は回しているときだけ1回出します。

  2. 真上の画面に写るようにする — Build Store が、真上の画面を撮る前に
  RefreshNow() を呼ぶようにしました(編集中の Update
  を待ちません)。参照も入れ直します。カメラは y=60・下向き・near 0.1・far 80
  で、板は y=2.9(壁とキッチンの箱は 2.7)なので範囲に入り、隠れません。

  あわせて2点、確かめているうちに見つけた間違いも直しました。
  - 向き:TextMesh の字はその物の −Z の側から読めます(既定のカメラが +Z
  を向いて読むのと同じ)。真上のカメラは見下ろすので −Z
  を上に向ける必要があり、LookRotation(Vector3.down, Vector3.forward)
  にしました。前は Vector3.up を向けていたので、裏側から見る形になっていました(
  出ていても鏡文字だったはずです)。
  - 大きさ:transform
  を拡大するのをやめ、文字の大きさ(characterSize)で合わせます。まず〈いちばん長
  い行の文字数(全角1・半角0.5)〉から見込みで決めるので、撮るのと同じコマでもだ
  いたいの大きさになります。そのあと文字の実際の広がりで直します。

  シミュレーションの動きは1行も変えていません。staffFirstYield は off
  のままです。

  ServiceSim/Build Store を押してください。
  screens/{日付}_family_v0_top_w120_people.png にモニターが写るはずです(中身は「
  見本」の文字で、回すと本物の数字になります)。もし

  - 鏡文字・上下さかさま → KitchenMonitor.flip を on
  - 大きすぎ/小さすぎ → fillRatio(既定 0.92)
  - 文字が四角 → フォント名を足します

  のどれかなら教えてください。読めていれば cs:128 が固定版です。
16:32 cs:129 の報告(チャット)
cs:129 です。

  1. 大きさ — 合わせる処理を FitText
  に切り出し、文字を入れるたびに毎回走るようにしました。前は「文字数が変わったと
  きだけ」の見込みで止まっていたので半分ほどの大きさでした。
  - (1) 文が変わったときだけ、フォントの字幅(Font.GetCharacterInfo の advance)
  から見込みを立てます。書き出しと同じコマでも、だいたいの大きさになります
  - (2) できた文字の実際の広がり(Renderer の
  bounds)で直します。編集中も回しているときも、呼ばれるたびに走ります

  屋根の幅(x)と奥行き(z)の両方に収まる大きさのうち大きい方(=
  2つの制限の小さい方)にしています。大きさは transform ではなく characterSize
  で変えます。

  2. 後ろの板と太字 — Backing(当たり判定なしの板)を、屋根のふちから 0.4 m
  内側に、文字より 0.05 m 下に敷きました。色は Mat_MonitorBoard(濃い灰。Setup
  が作って入れます)。文字は Bold にしました。

  3. 「厨房」の札 — モニターを出しているときだけ、札の場所を屋根の北のふち(z
  の大きい側・0.2 m
  内側)に寄せました。出していないときは今までどおり床の真ん中です。store_report
  の「場所の名前」も同じ場所になります(同じ処理を通ります)。

  シミュレーションの動きは1行も変えていません。Backing は当たり判定を持たないので
  、NavMesh・センサー・真上の重なりの確かめにも入りません。

  ServiceSim/Setup → ServiceSim/Build Store の順に押してください。
  後ろの板のマテリアル(Mat_MonitorBoard)は Setup が作るので、今回は Setup
  も必要です。

  真上の画面で、文字が屋根の幅いっぱいまで広がっているか、濃い板の上で読めるか、
  「厨房」の札が板から外れているかを確かめてください。まだ小さい/大きいようなら
  fillRatio(既定 0.92)で調整できます。読めていれば cs:129 が固定版です。
16:53 cs:131 の報告(チャット)
cs:131 です。先に LABEL_RULES.md
  の「キッチンのモニター」の節を吹き出し向けに書き直してから作りました。

  1・2. 吹き出し1つ、ほかの吹き出しと同じ作り
  ServiceSimLabels.DrawKitchenMonitor
  が、キッチンの部屋の真ん中の上に1つ出します。新しい MultiLineLabel
  が、帯の形・字の大きさ・左端の色を既存の Label と同じ決め方で描きます(行が多い
  ので左寄せの複数行、左端の色はロボットと同じ白)。重なり避けも共用します。カメ
  ラの向きを変えても正対し、ズームしても字の大きさは変わりません。中身と 0.5
  秒ごとの書き換えは前と同じです。

  3. 測る回でも出す — OnSceneGui
  は測る回のときこのモニターだけを描いて戻ります。頭の上の字幕を切る B11
  はそのままです。切り替えは今までどおり ExperimentPlan.showKitchenMonitor
  の1か所です。

  4. 前の作りを外した — KitchenMonitor から TextMesh・後ろの板・FitText・フォント
  の用意・RefreshNow・設定の版・記録を削除し、いまは文を作るだけ(Text と
  TryAnchor)になりました。[ExecuteAlways] も外し、Mat_MonitorBoard
  はファイルごと消しました。シーンに残っている Board・Backing は RemoveOldBoards
  が Setup と Build Store
  のときに片付けます。「厨房」の札は床の真ん中に戻しました。

  1点、先にお伝えしておきます。 Scene ビューの表示になったので、カメラから書き出
  す画(top_*.png)には写りません(吹き出しは Handles の GUI
  で、カメラのレンダリングには入らないためです)。LABEL_RULES.md
  にもそう書きました。Scene
  ビューで見るぶんには、回している最中もそのまま読めます。

  確かめ方:ServiceSim/Setup → ServiceSim/Build Store を押すと、Scene
  ビューのキッチンの上に「見本」の吹き出しが出ます(回すと本物の数字になります)
  。前の板(屋根の上の文字と濃い板)が消えていることも、そこで分かります。
  読めていれば cs:131 が固定版です。もし吹き出しがほかの札と重なって読みにくいよ
  うなら、KitchenMonitor.heightAboveRoof(既定 0.6 m)を上げれば離せます。
17:01 cs:132 の報告(チャット)
cs:132 です。LABEL_RULES.md の節をパネル向けに書き直してから作りました。

  1. 画面に貼り付けるパネル1つ — Scene ビューの画面に直接描きます。カメラを回して
  もズームしても位置は変わりません。はじめは左上(ふちから 8 点)。
  2. 見出しを掴んで動かす — 動かした位置は EditorPrefs(ServiceSim.MonitorX / Mon
  itorY)に覚えます。画面の大きさが変わっても、描くたびに画面の中へ収め直します。
  3. 見出しを押すとたためる — 動かさずに押したときだけ切り替えます(ドラッグと区
  別)。たたみ方も覚えます。見出しに ▼ / ▶ が出ます。
  4. 字の大きさは場所の名前の札と同じ(PlaceFontSize)。文は左寄せの複数行、帯は
  ほかの吹き出しと同じ濃い半透明、左端は白。中身・0.5
  秒ごとの書き換え・言葉は今までと同じです。
  5. 測る回でも出します。切り替えは ExperimentPlan.showKitchenMonitor
  の1か所のままです。
  6. パネルの上のクリックとドラッグは、ここで受け取って先へ渡しません(Event.Use
  )。後ろの卓・人・ロボットは選ばれません。見出しの外(文の上)を押したときも、
  受け取るだけで何もしません。

  あわせて、店の上に浮かべる作り(MultiLineLabel・TryAnchor・heightAboveRoof)を
  外しました。KitchenMonitor は文を作るだけになりました。パネルはほかの札の重なり
  避けには入れていません(重なったらパネルを動かしてください)。カメラから書き出
  す画(top_*.png)には写りません。

  シミュレーションの動きは1行も変えていません。

  確かめ方:Scene ビューを表示すると、左上にパネルが出ます(店を建てたあと・回し
  ていないあいだは「見本」の文字、回すと本物の数字)。見出しのドラッグ・クリック
  でたたむ/開く、Unity を開き直しても位置が残ることを見てください。

  項目9のとおり先にお伝えします。掴んで動かす作りは、Unity の Scene
  ビューのイベントを横取りする(Event.Use())やり方で入れました。
  これが効かない(ドラッグしても動かない、または後ろの物が選ばれてしまう)場合は
  、別のやり方(SceneView.AddOverlayWindow や Overlay 属性など)を自分で試して作
  り込むことはせず、そのまま報告します。動かなかったらその旨だけ教えてください。

  問題なければ cs:132 が固定版です。
17:22 cs:133 の報告(チャット)
cs:133 です。

  左端の色の帯(4 点・白)を描いていた1行を削除しました。ほかは何も変えていません
  (帯の色・見出しの下の線・字の大きさ・場所・掴んで動かす・たたむ・中身・0.5
  秒ごとの書き換え・測る回でも出すこと)。

  1点だけ添えると、LABEL_RULES.md に「左端の色はロボットと同じ白」と書いてあった
  ので、その1行だけは外したことに合わせて直しました(記録が実物と食い違わないよう
  にするためです)。見た目の変更はご指示の1点だけです。
18:45 cs:134 の報告(チャット)
cs:134 です。B は入っていなかったので A・B 両方やりました。

  A. 写し直し — 3つの版はすべて 82023936eb99 でそろっていました(summary
  の6店/③⑦の meta.generation/params の
  layout_generation)。4ファイルを写し、fetchedAt を3つとも直しました。

  JSON を読んで差を数えた結果:③は形がまったく同じ(aisles・stop・席の点・footpri
  nt・use の数すべて一致)。⑦は細い通路が 0.8 → 0.95 m(A01 x 1.20–2.15/A02
  4.65–5.60/A03 8.10–9.05、入口も右へ)。狭い道で入る卓は 24 卓のままです。
  1点補足すると、島を右へずらした結果 卓の footprint が 26 卓・席の点が 26
  卓・止まる位置が 30 卓動いています(数と並びは同じ)。⑦の過去の回と数字を比べる
  ときは、店の形が変わった版である点を見てください。シミュレーションの動きは
  cs:133 のままです。

  B. 床の色 — 先に LABEL_RULES.md に「床の色」の節を作ってから実装しました(その
  節が無かったので新設です)。NavMesh の形は見ず、サイトの JSON から決めます。

  - 水色 = 道順(from_pass + between)に沿って、ロボットの体(半径 0.25
  m)が通る範囲。点から線分までの距離で塗るので、中心線だけでなく体の幅いっぱいま
  で塗ります
  - 濃い水色 = aisles の区画(区画いっぱい)
  - 置いてあるものの下は塗らず、重なるところは濃い水色を出します

  ご指示の文から1つだけ変えました(理由つき)。 ご指示は「濃い水色=区画と
  use=narrow の道で体が通る範囲」でしたが、そのとおりに作ると狭い道の多くが広い通
  路を経由するため、⑦が 水色 8.6 m² / 濃い水色 79.1 m²
  となり、ほとんどの床が「細い通路」に見えてしまいます(JSON
  の数字で先に計算しました)。狭い道が狭いのは通路の中だけなので、狭い道も「床」
  として水色に塗り、濃い水色は通路の区画だけにしました。結果:

  ┌─────┬─────────┬──────────────────────────┐
  │     │  水色   │         濃い水色         │
  ├─────┼─────────┼──────────────────────────┤
  │ ③   │ 58.4 m² │ 30.1 m²(1.2 m × 3 本)  │
  ├─────┼─────────┼──────────────────────────┤
  │ ⑦   │ 64.1 m² │ 23.5 m²(0.95 m × 3 本) │
  └─────┴─────────┴──────────────────────────┘

  A01
  の下・中・上がすべて濃い水色に塗られることも確かめました。この決め方と理由は
  LABEL_RULES.md にも書いています。凡例は「ロボットがふだん走る床」「細い通路(狭
  い道で入る)」にし、Mat_PeopleFloor を濃い水色に変えました。

  押す順番:ServiceSim/Setup(Mat_PeopleFloor の色を変えたので一度必要です)→
  ServiceSim/JSON Store/⑦ p5_crammed を建てて確かめる。真上の画面で、細い通路3本
  が濃い水色に塗られていることと、store_report の床の節の数字(水色 ≒ 64 m² /
  濃い水色 ≒ 23 m²)を見てください。
19:12 cs:135 の報告(チャット)
cs:135 です。

  1. 原因(Editor.log の 209855 行で確定) — ご推測のとおりでした。

  細い通路の幅が .asset と JSON で違います: .asset 0.8 m / JSON 0.95 m
  (aisleWidthOptions を JSON の幅だけにしてください)

  StoreLayout_p5_crammed.asset の aisleWidthOptions が 0.8
  のまま残っていました。JsonStoreLayout
  はこれを「合わないもの」として建てずに止める作りだったので、席 0
  のまま先へ進み、焼いていない NavMesh を調べた CheckNavMeshSurface が
  NullReferenceException で落ちていました。
  床の色の板だけ出ていたのは、塗り分けが NavMesh を見なくなった(cs:134
  でサイトの JSON から塗るようにした)ためで、建てる前でも出てしまうからです。

  2. 直したこと(Unity の中の古い値と確かめ方だけ)
  - StoreLayout_p5_crammed.asset の幅を 0.8 → 0.95 にしました(③は 1.2 で JSON
  と一致、確認済み)
  - 幅の確かめ方を変えました。JSON が正なので、.asset の値が違っても止めず、JSON
  の幅を .asset に入れて先へ進む(Console に「細い通路の幅を JSON に合わせました:
  .asset 0.8 m → JSON 0.95 m」と出ます)。サイトが通路の幅を変えるたびに古い値で
  止まるのを無くすためです。店の形(卓・通路の区画・道順)は JSON
  のままで何も変えません

  3. 落ちないようにした
  - BuildStore:builder.Build() のあと Plan が null
  なら、確かめも撮るのもやめて戻る
  - Measure:ある幅で建てられなかったら、その幅の測りを飛ばす
  - CheckNavMeshSurface と CheckNoGoRooms:三角形が無いときは「NavMesh
  が焼けていません(調べていません)」を返す(配列を触らない)

  サイトの JSON
  は1バイトも変えていません。シミュレーションの動きも変えていません。

  ServiceSim/JSON Store/⑦ p5_crammed を建てて確かめる
  をもう一度押してください(Setup は不要です)。見ていただきたいのは、

  - 「合わないもの: なし」で建つこと
  - 真上の画面で、細い通路3本が濃い水色に塗られていること
  - store_report の床の節が 水色 ≒ 64 m² / 濃い水色 ≒ 23 m²(0.95 m × 3
  本)になっていること
  - 道順の確かめが 42/42(つながらない区間 0)であること — 通路が 0.95 m
  に広がったので、前より余裕が増えているはずです
20:36 保留の変更の仕分け(ファイル)
調べ終わりました。Check in も Undo も実行していません。 以下が仕分けです。

  ---
  置き場所と今の状態

  /Users/shimazueiichi/Robotics_UX/Robotics_UX_New
  cs:135@Robotics_UX_New@studio_unity148@unity (head)   ←
作業コピーは固定版そのもの21:06 整理の1〜3の報告(ファイル)
1〜3 まで完了しました。

  1. D ― .git を管理の外へ ✅

  ignore.conf に2行追記しました(末尾):
  .git
  /Assets/ServiceSim/Store/old~
→ これだけで Private 13件のうち11件(.git/objects 6件・old~21:39 cs:136 の報告(ファイル)
完了しました。

  Check in: cs:136

  Created changeset
  cs:136@br:/main@Robotics_UX_New/Robotics_UX_New@studio_unity148@unity
  保留中の変更: 37 → 0 件
  (残るのは Mat_MonitorBoard.mat / .meta の Private 2件 =
  ご指示どおり置いたまま)

  .git はディスク上そのままです ― 145 MB、git log も通ります(1b9dc25 [DAY148]
  GridAngleScannerのpickHeightUnityを0.027fに変更)。

  入れ直す前に1回止まりました

  最初の cm ci は PlaceNameLabels.cs
  がディスク上で消えているだけ(削除が未登録)で中断し、何も入らずに cs:135
  のままでした。--all を付けて削除も含めて入れ直し、cs:136 になっています。

  ---
  動きは cs:135 から変わっていません

  根拠を項目別に ―

  確認: PeopleSpec.asset
  結果: cs:135 と完全同一(staffFirstYield: 0 ✓)
  ────────────────────────────────────────
  確認: ExperimentPlan.asset
  結果: cs:135 と完全同一(showKitchenMonitor: 1 ✓)
  ────────────────────────────────────────
  確認: NavMeshAreas.asset
  結果: cs:135 と完全同一(New Agent 0件)
  ────────────────────────────────────────
  確認: RobotSpec.asset
  結果: 差は3行。followSiteRoutes: 1 / waypointReachDistance: 0.25 /
  routePointSnapM: 0.1 = すべて C# の初期値。oneRobotPerAisle: 1 ✓
  ────────────────────────────────────────
  確認: ServiceSpec.asset
  結果: 差は3行(既定値)。arrivalsPerHour: 0 なので arrivalsPerHourByCrowd(25 /

  35 / 45)がそのまま効きます
  ────────────────────────────────────────
  確認: StoreLayout_Grid.asset
  結果: 差は3行(showFloorPaint ほか既定値)
  ────────────────────────────────────────
  確認: StoreLayout_p5_crammed.asset
  結果: 差は3行(既定値)。aisleWidthOptions: [0.95] / aisleWidthIndex: 0 は
  cs:135 のまま=サイトの JSON(0.95)と一致
  ────────────────────────────────────────
  確認: StoreLayout_Family.asset
  結果: 固定版の4値を復帰:aisleWidthIndex: 2 / deliveryOffsetFromAisleCenter:
  0.15 / benchDepth: 0.45 / registerSize: {x: 1, y:
  0.5}。残る36行は台本の作り直し(項目の入れ替え)と C# 既定のみ
  ────────────────────────────────────────
  確認: Tag 7種
  結果: SimTags.cs の記述どおり
  NavMesh・センサー・よける処理・形の確かめに効きません
  ────────────────────────────────────────
  確認: シーン
  結果: 配線(ServiceOps / GroupManager / JamWatcher / KitchenMonitor
  ほか)とカメラの画角だけ。建てた店912個は入っていません

  全アセットについて「C#
  の既定でも固定版でもない値」を機械的に洗い出し、外れ値はゼロでした(唯一の
  registerSize は 1.0 に戻済み)。

  ---
  持ち越し2件

  1. NavMesh の種類が増え続ける … NavMeshBaker.cs の BakePeople が
  NavMesh.CreateSettings() を呼ぶのに _peopleTypeId
  が場面に保存されない欄なので、Editor を開き直すたびに1つ溜まります。別件として
  記録済み(navmesh-agenttype-leak)。次に気づいたら cm undochange
  ProjectSettings/NavMeshAreas.asset で戻せます。
  2. 回すと StoreLayout_Family の2値が再び書き換わる … ExperimentRunner.cs:235 が
  aisleWidthIndex、:244 が deliveryOffsetFromAisleCenter を上書きします(:1038
  で戻す作りですが、途中で止めると残る)。StoreBuilder.SetAisleWidthIndex()
  も同じ欄を書きます。段階Bで回したあとは、この2行を見てから入れるのが安全です。

  段階B(台帳)に進めます。
21:55 cs:137 の報告(ファイル)
新しい固定版は cs:137 です。(1件も保留なし。Mat_MonitorBoard は Private
  のまま)

  1. 条件のファイル

  Assets/ServiceSim/Experiment/serving-robot-params.json   v2.4 → v2.7
  meta.layout_generation  82023936eb99  ← 店の形の JSON
と一致(写し直していません)22:23 cs:138 の報告(ファイル)
新しい固定版は cs:138 です。(保留は Mat_MonitorBoard の Private 2件だけ)

  指示書(claude_code_request_v6_yield.md)も読みましたが、会話でいただいた内容と
  同じでした。

  角で溜まっていた理由

  調べて分かったことを先に。角(x 10.5〜13.5・z 3.5〜5.8)は細い通路の外です。
  前のよけ方は
  - 「細い通路に入る前」
  - 「細い通路の中で向かい合ったとき」

  の2つだけで動く作りで、広い所では 0.3 m
  横に寄るだけ(KeepClear)でした。角では譲る仕組みが1つも動いていませんでした。
  だから向かい合ったまま止まっていた、というのが溜まりの原因です。

  1. 譲る順番 ― RobotSpec の1か所

  RankRobot = 0  >  RankStaff = 1  >  RankGuest = 2
  RobotSpec.RankOf(PersonKind) で引く
  立ち往生を助けに行くスタッフは今までどおり例外(PersonRobotYield.ignoreRobot →
  Watches() で相手から外す)。

  2. スタッフ

  - PeopleSpec.staffFirstYield を既定 on に(C# と .asset の両方)
  - 新しい Mode.StepAside。どこでも見ます ― ロボットの外周から 1.5 m
  まで近づいて向かい合ったら譲る
  - どく先は、相手の道(CurrentLegSegment=サイトの routes の線)から横へ 0.6 m
  +体の半径 以上どいた、人が通れる床の点。NavMesh
  へ寄せたあとも横の距離を再確認します
  - その点が無ければ、来た道を戻って通路の外(通路の中なら相手と反対側の出口の外
  、通路の外なら来た向きへ下がって道から離れた点)

  3. ロボットどうし

  番号の小さい台が先(前と同じ)。大きい台は後ろへ下がるのをやめ、相手の道から横
  へ 0.6 m 以上どいた点で待ち、通り過ぎたら出ます。どく点が無ければ手前の分かれ道
  (道順の1つ前の点)の外。

  4. 客

  変えていません(ShouldStepAsideFor はスタッフ以外で false
  を返します)。店員優先の版のまま=長くて5秒止まり、回り道か横を詰めて通る。

  5. 記録

  yields.csv(新)
  condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,
  waited_s,stepped_aside,passed
  ロボットどうし・スタッフ・客(入口で待つ/下がる/回り道)をすべて1行ずつ残しま
  す。stepped_aside が 1 なら道から 0.6 m どけた、0
  なら来た道へ戻った/よけ場所へ下がった。

  summary.json の sim_like
  yields / yields_by_robot / yields_by_staff / yields_by_guest
  yields_stepped_aside / yields_in_corner / yields_passed
  yield_wait_s / yield_wait_mean_s
  corner_stops / corner_stop_s
  corner_stop_count_share / corner_stop_time_share   ← 1311・1536
  の「約3分の1」と直接比べられます
  corner_range                                        ← 使った範囲も残します

  6. 値は1か所(RobotSpec)

  yieldOrderEnabled   true
  yieldSideClearM     0.6    道から横へどく最小の距離
  yieldSideSearchM    2.5    どく点を探す広さ
  yieldSideStepM      0.2    探す刻み
  yieldSideWaitMaxSec 30     どいて待つ上限
  yieldApproachM      1.5    どき始める近さ
  corner 範囲         x 10.5-13.5 / z 3.5-5.8
  yieldOrderEnabled を外せば前の作りに戻ります(前後を比べる用)。

  変えていないもの:料理の割り当て(PutDish・ReleaseDishesToStaff・PickBatch)/
  通路の決まり(oneRobotPerAisle・UpdateAisleYielding)/立ち往生の助け方/NavMes
  h・前のセンサー・経路の引き方。ServiceSpec.cs・SiteValues.cs・KitchenMonitor.cs
  は1行も触っていません(保留なしで確認済み)。

  2点、お伝えしておきます

  1. staffFirstYield を off → on にしました。 cs:135〜137 では「off
  が正」と確かめていた値です。今回のご指示(既定
  on)で意図的に変えています。回し方が前の2回と変わる所なので、1311・1536
  と比べるときは「よけ方の版が違う」ことを前提にしてください(summary.json の
  staff_first_yield と run_info に残ります)。
  2. Unity 本体はまだ再コンパイルしていません。 Unity 同梱の Roslyn + Unity
  の参照アセンブリで2つに分けて通し、エラー・警告ゼロでしたが、Editor
  にフォーカスが当たっていないため Unity 側のコンパイルは走っていません。一度
  Unity に切り替えてから回してください。

  新しいファイル Assets/ServiceSim/Robot/YieldSide.cs は .meta
  も作って一緒に入れました(既存の guid 328 件と重ならないことを確認済み)。

  ③ を回したあと、corner_stop_time_share・stuck(動けなくなった回数)・timeout(
  時間切れの往復)と、yields.csv の stepped_aside が 1
  の割合を見ると、どく点が実際に見つかっているかが分かります。
22:50 cs:139 の報告(ファイル)
新しい固定版は cs:139 です。(保留は Mat_MonitorBoard の Private 2件だけ)

  2227 の数字を自分で確かめました

  直す前に yields.csv を数えました。指示書の診断どおりです。

  ┌──────────────────────┬────────────────────────────────────────────────────┐
  │                      │                                                    │
  ├──────────────────────┼────────────────────────────────────────────────────┤
  │ 譲り全体             │ 13,569 回(スタッフ 13,173・ロボット 136・客 260) │
  ├──────────────────────┼────────────────────────────────────────────────────┤
  │ スタッフの合計       │ 19,535 秒 / 平均 1.48 秒 / 中央値 0.050 秒       │
  ├──────────────────────┼────────────────────────────────────────────────────┤
  │ 0.2 秒未満の割合     │ 91.6%                                              │
  ├──────────────────────┼────────────────────────────────────────────────────┤
  │ スタッフが横へどけた │ 9,734 回(残り 3,439 は通路の外へ戻った)          │
  └──────────────────────┴────────────────────────────────────────────────────┘

  cs:138 の条件は「外周から 1.5 m に近づいたら譲る」だったので、ただのすれ違いで
  も譲っていたのが数字に出ています。

  1. 直した条件(ShouldStepAsideFor)

  スタッフが譲るのは次の両方のときだけにしました。

  - ロボットが動いていて、自分がその「これから進む道」から横に 0.6 m +
  体の半径(0.2 m)以内にいる
    - 「これから進む道」= サイトの routes の線の、ロボットの今の位置から先
  yieldPathAheadM(2.0 m)分
    - 曲がり角をまたぐので、折れ線として見ます(PathAhead →
  LateralDistanceToPath)
  - ロボットが自分の方へ近づいている(SpeedMps > stoppedSpeedEpsilon かつ
  向きが自分の方)

  離れていくロボット・止まっているロボットには譲りません(止まっている台は今まで
  どおり「よけて通る物」)。

  あわせて2つ直しました:
  - いちばん近い1台だけを見るのをやめ、全台を見るようにしました。止まっている台が
  近いと、その後ろから来る動いている台を見落とすためです
  - 譲りをやめる見方も同じにそろえました(道の上から外れた/もう近づいてこない)
  。すぐ解けて入り直さないよう robotPassedClearM だけゆるめています

  2〜3. 変えていないもの

  譲るときの動き(道から横へ 0.6 m どく、無ければ通路の外へ戻る)は cs:138
  のまま。ロボットどうし・客の決まり、料理の割り当て・通路の決まり・立ち往生の助
  け方も触っていません。差分を関数単位で突き合わせて確認済み(該当差分 0 行)。

  4. 値は RobotSpec の1か所

  yieldPathAheadM  = 2.0   ← 新。進む先を何 m 見るか
  yieldSideClearM  = 0.6   ← 前から。横の距離/どく距離
  yieldApproachM           ← 使わなくなったので外しました
  yieldApproachM は RobotSpec.asset に書かれていなかった(Unity が未再保存で C#
  の既定値のまま動いていた)ので、外しても値の持ち越しはありません。

  5. summary に足したもの

  staff_yields                        スタッフが譲った回数
  staff_yield_wait_s                  合計秒数
  staff_yield_mean_s                  1回の平均
  staff_yield_share_of_staff_time     スタッフの時間に占める割合
  staff_time_total_s                  その分母(staff_time_s
  の合計=人数×回した秒数)
  2227 の値に当てると 19,535 ÷(4人×207分×60秒)= 約 39%
  で、指示書の「約4割」と一致します。回したあとはここを直接見比べられます。

  回す前に

  Unity 同梱の Roslyn + Unity
  の参照アセンブリで2つに分けて通し、エラー・警告ゼロです。ただし Unity
  本体はまだ再コンパイルしていません(Editor
  にフォーカスが当たっていないため)。一度 Unity に切り替えてから回してください。

  ③ のあと、staff_yield_share_of_staff_time・entry_wait_mean・corner_stop_time_sh
  are・robot_share の4つを 2227
  と並べると、「譲りすぎを削って、角の効きを保てたか」が一目で分かります。
23:48 cs:140 の報告(ファイル)
新しい固定版は cs:140 です。(保留は Mat_MonitorBoard の Private 2件だけ)

  1. 回すもの ― ServiceSim / Stage B /

  ┌────────────────────────────┬───────────────────────────────┐
  │          メニュー          │           すること            │
  ├────────────────────────────┼───────────────────────────────┤
│ Run All(18回) │ 条件6つ × 種 0・1・2 │店の形と試算のコード(p2m-site)
店の形を直した5つのコミットの差分(tools/sim_layouts/ と public/sim/serving-robot-params.json)と、直したあとのファイルの全文です。図面のデータ(public/sim/layouts/)と試算ページの数字の行(public/sim/serving-robot.html の const D、1行で約430万字)は、コードが書き出したものなので差分を載せていません。どちらもサイトにある公開中のファイルが全文です( https://pixelstomotors.com/sim/layouts/summary.json ・ https://pixelstomotors.com/sim/serving-robot.html )。
コミット e5209a1 2026-10-23 12:22:06 +0900 店の形:③⑥⑦のレジを縦向きにし、会計に立つ点・並ぶ点とロボットの道の距離の確かめを足す(作業中・②は未決)
diff --git a/tools/sim_layouts/famires_gen2.py b/tools/sim_layouts/famires_gen2.py
index 93b5b2f..a7dba5a 100644
--- a/tools/sim_layouts/famires_gen2.py
+++ b/tools/sim_layouts/famires_gen2.py
@@ -172,7 +172,8 @@ def p1_efficient_corner():
     rooms += [toilet]
     walls += twalls
rooms += [dict(label="待合", rect=[0.0, 0.9, 0.5, 3.3], kind="guest"),コミット 0401560 2026-10-23 12:36:09 +0900 店の形:会計の列をロボットの道にしない(人は通れる)。②は列の前を横切らず、レジ横を回る(作業中・公開前)
diff --git a/tools/sim_layouts/famires_v3.py b/tools/sim_layouts/famires_v3.py
index 816f6de..89e8738 100644
--- a/tools/sim_layouts/famires_v3.py
+++ b/tools/sim_layouts/famires_v3.py
@@ -15,6 +15,10 @@ codex の2回目の検証(review_result_v3.md)を受けて直したこと(
 - 2人席:止まってよいのは、椅子の側とテーブルの横(ベンチの横は使わない)
 - 待機場所:1台分が0.8×0.8m以上か、台数が正しいかを確かめる。1台ずつ、ほかの台が止まったままで受け渡し口の前まで出られるかを確かめる
コミット 77f79f1 2026-10-23 12:42:54 +0900 店の形:レジで通路を狭くしない(③⑥⑦はレジを縦向きに、会計の列はロボットの道にしない)。卓までの距離は6店とも変わらず、試算は版の番号だけ更新
diff --git a/public/sim/serving-robot-params.json b/public/sim/serving-robot-params.json
index bd2c962..68e97d3 100644
--- a/public/sim/serving-robot-params.json
+++ b/public/sim/serving-robot-params.json
@@ -4,7 +4,7 @@
   "model": "v2.4",
   "reps": 40,
   "ng_min": 10,
-  "layout_generation": "9628954a582f",
+  "layout_generation": "f282eaa6cb71",
   "source": "p2m-site の public/sim/serving-robot.html と同じ試算(haizen_sim.py)と結果(results.json)",
   "roles": {
    "unity_measures": "Unity で測ってサイトに戻すための仮の値。Unity は読まない",
diff --git a/tools/sim_layouts/README.md b/tools/sim_layouts/README.md
index bfc7331..82d97a8 100644
--- a/tools/sim_layouts/README.md
+++ b/tools/sim_layouts/README.md
@@ -31,6 +31,7 @@
 - スタッフが待つ点:パントリー(と接する壁)の客席側の辺にそって壁から0.25m、0.6mおき。外側にロボットのふだんの道(1.0m)が残る所だけ。受け渡し口に近い順に6つ(仮の規則)
 - 並ぶ点・立つ点は、障害物から0.25m未満の所と細い通路には置かない
 - ロボットの道順(`routes`):受け渡し口の前→各卓の止まる位置(`from_pass`)と、卓→卓(`between`。"T01|T02" は T01 から T02、逆向きは点を逆にたどる)。ふだん走らせる幅の道で行けるならその道、行けなければ通れる幅の道(試算と同じ規則。`use` が normal か narrow。試算の卓の分け方と一致することをテストで確かめる)。マス目の最短の道を、通れる範囲でまっすぐにつないだ曲がり角の点の並び。Unity のロボットはこの点を順にたどる(Unity で道を決めない)。2026-10-22、Unity で狭い通路の区画を NavMesh に書き込んだら NavMesh が壊れたため、この形にした
+- 会計の列(`robot_keepout`):ロボットの道にしない矩形。人は通れるので、Unity では部屋や壁として建てない(道順はこれをよけて作ってある)
 - まだないもの:② の4人席・丸テーブル・6人の長テーブルの椅子と座る位置(parts が null)、人がロボットをよける逃げ場(refuges)

 ## 動かし方
@@ -103,6 +104,15 @@ python3 test_famires_v3.py         # 確かめの仕組みそのものを確か
 - layout・analysis・summary には同じ版の番号(`generation`:作り方のコード・記憶の店の原本・設定から決まる)を入れる。読む側(サイトの試算・Unity)は、summary と各ファイルの `generation` が同じかを確かめてから使う。公開はサイトの git の commit 単位なので、公開されるのは常に1つの版の一式
 - 出力先は `--out フォルダ` で替えられる

+## 決まり(2026-10-23 エイイチと決めたこと:レジのまわり)
+
+- レジの向きは店ごとに違ってよい。ただし、レジの台・店員の立つ所・会計で並ぶ所で通路を狭くしない
+- 会計に立つ点とレジに並ぶ点は、ロボットの道(受け渡し口から卓・卓から卓、ふだんの道も狭い道も)から0.75m以上(人がロボットをよける距離と同じ)。`famires_v3.check_register_clear` で確かめ、違反があれば出力しない
+- 会計の列(レジの客の側、カウンターの真ん中から幅1.0m・長さ2.15m)は、ロボットの道にしない。人は通れる(部屋や壁ではない)。レジ横はロボットが通ってよい。`famires_v3.checkout_keepout` で作り、Unity 用の JSON には `robot_keepout` として書き出す
+- ③⑥⑦は、レジを縦向きにし、客は入口の側に立って入口へ向かって並ぶ形に直した(前はレジに並ぶ列が客席の下の通路のまん中にあり、Unity で人が立ち止まる止まりの1位だった)
+- ②は記憶どおりのレジのまま(入口の前から少しパントリー寄り、客は入口の方に並ぶ)。入口の左右の卓を移るロボットは、会計の列の前を横切らずレジ横を回る
+- 6店とも、卓までの距離・止まる位置・卓の分け方は変わっていない(サイトの試算は計算し直していない。`serving-robot-params.json` は版の番号だけ新しくした)。変わったのは卓から卓への道だけ
+
 ## まだ入っていないこと

 - 厨房の中の人の動き(扉・作業通路・下げ膳の返却口)
コミット 2ab87bd 2026-10-23 17:51:43 +0900 店の形:⑦の細い通路を0.8mから0.9mに(島を右へずらす・卓と席は同じ)。作業中・公開前
diff --git a/tools/sim_layouts/README.md b/tools/sim_layouts/README.md
index 82d97a8..23fed62 100644
--- a/tools/sim_layouts/README.md
+++ b/tools/sim_layouts/README.md
@@ -24,7 +24,7 @@
 `unity_export.py` が、店の形と解析から決まった規則で作る(規則はファイルの先頭に書いた)。`famires_v3.py` を回すと一緒に出る。Unity はこれを読んで店を建て、店の形を自分で作らない。試算(haizen_sim.py)はこれを使わない。

- 卓の数・止まる位置・卓までの距離は analysis と同じ(テストで確かめる)。版の番号(generation)も同じコミット 9e1ecf9 2026-10-23 18:27:49 +0900 店の形:⑦の細い通路を0.95mに(島を右へずらす・卓と席は同じ)。試算を v2.6 に(⑦だけ回し直し、ページの平面図もいまの店の形に)。公開前
diff --git a/public/sim/serving-robot-params.json b/public/sim/serving-robot-params.json
index 68e97d3..c5b4e6f 100644
--- a/public/sim/serving-robot-params.json
+++ b/public/sim/serving-robot-params.json
@@ -4,7 +4,7 @@
   "model": "v2.4",
   "reps": 40,
"ng_min": 10,tools/sim_layouts/famires_v3.py(main・版 82023936eb99 の時点)
"""ファミレスの店の形 第3版:決まりの確かめ方とロボットの届き方を作り直した版。

codex の敵対的検証(review_result.md)を受けて直したこと
- ロボットの通れる幅は機種の公表値(初期値 BellaBot 80cm)。本体の幅とは別に扱う
- 「ふだん走らせる幅」(初期値 1.0m)を別に持ち、卓を3つに分ける
    ロボットが届く卓/狭い道なら届く卓/人が運ぶ卓(ロボットから受け取って人が運ぶ)
- 届くかは、卓の「座る側(開いた側)」の前で止まれるかで判定する。背中側・壁側・仕切り越しは数えない
- 幅の判定は、マス目の中心から障害物までの距離で行い、2つの細かさで同じ結果になるかを毎回確かめるtools/sim_layouts/famires_gen2.py(main・版 82023936eb99 の時点)
"""ファミレスの店の形 第2版:席を「列」で置く。

決まり(2026-10-21 エイイチと決めたこと)
- 基本は4人掛けの背中合わせのソファの列(島)。壁ぞいはソファの片側の列
- 狭い所は2人席で埋める
- 家族・団体用に6人のブース(L字ソファ・6人ボックス)を入れる
- 店の色は2つ
効率重視型:仕切り壁なし・通路は狭め(1.2m)・2人席多めtools/sim_layouts/unity_export.py(main・版 82023936eb99 の時点)
"""Unity が店を建てるための細かい形を、店の形(layout)と解析(analysis)から決まった規則で作る。

2026-10-22 エイイチと決めた「何について正か」による(README)。Unity は店の形を自分で作らず、ここで書き出したものを読む。
サイトの試算(haizen_sim.py)はこれを使わない。数字(卓の数・卓までの距離・止まる位置)は analysis と同じものをそのまま渡す。

書き出すもの(public/sim/layouts/unity/{名前}.json)
- outer_walls:外壁(入口を空けた矩形の並び。外形の外側に壁の厚みぶん)
- floor:床を敷く矩形(建物の外を除く)tools/sim_layouts/test_famires_v3.py(main・版 82023936eb99 の時点)
"""famires_v3 の確かめ(codex の反例を含む)。使い方: python3 test_famires_v3.py"""
import copy
import famires_v3 as v
import famires_gen2 as gen

ok = True
tools/sim_layouts/README.md(main・版 82023936eb99 の時点)
# ファミレスの店の形(サービスロボット導入シミュレーション・配膳ロボットの試算用)

このフォルダの店の形が、サイトの試算と Unity の共通の元になる。Unity は `public/sim/layouts/` の JSON を読んで店を建てる。直すときは、ここ(サイト側)を先に直す。

## 何について正か(2026-10-22 エイイチと決めた)

| 何について | 正 | 扱い |
|---|---|---|枝 wip/robot-first-v27(試算 v2.7・未公開)の serving-robot-params.json の差分
diff --git a/public/sim/serving-robot-params.json b/public/sim/serving-robot-params.json
index c5b4e6f..1a36bb0 100644
--- a/public/sim/serving-robot-params.json
+++ b/public/sim/serving-robot-params.json
@@ -1,7 +1,7 @@
 {
  "meta": {
"schema_version": "serving-robot-params/0.1",枝 wip/robot-first-v27 で変えたファイル
 public/sim/serving-robot-params.json | 150 ++++++++++++++++++-----------------
 public/sim/serving-robot.html        |   6 +-
 2 files changed, 80 insertions(+), 76 deletions(-)

38194de 2026-10-23 21:05:15 +0900 配膳ロボットの試算 v2.7:料理をロボット優先に(2分待ってもロボットが来なければスタッフが運ぶ)。全条件を回し直した。公開前
試算 v2.6・v2.7 の作業フォルダのファイル(Mac simulation/)
simulation/v2_6/README.md
# 配膳ロボットの試算 v2.6(2026-10-23)

試算のモデルは v2.4 のまま(`haizen_sim.py` は v2.4・v2.5 と同じ。COMMON の `model` も "v2.4")。
店の形(`layouts/`)を直した版に入れ替え、⑦(fam_p5)だけ回し直した版。

## 店の形で変わったこと(正は p2m-site の `public/sim/layouts/`。版の番号 generation = 9628954a582f → f282eaa6cb71 → 82023936eb99)

- レジで通路を狭くしない(エイイチと決めた)。会計に立つ点・レジに並ぶ点は、ロボットの道から0.75m以上。会計の列(幅1.0m・長さ2.15m)はロボットの道にしない(人は通れる)
- ③⑥⑦はレジを縦向きにし、客は入口の側に立って入口へ並ぶ形にした。②は記憶どおりのレジのまま、ロボットが会計の列の前を横切らないようにした
- ⑦の細い通路を0.8mから0.95mにした(島を右へずらす。卓と席は同じ)。Unity でロボットがほとんど動けず、右端の列の横に詰めた分の余りがあったため。1.0m(ふだん走らせる幅)より狭いので、細い通路の24卓は狭い道で入るまま

レジの直し(f282eaa6cb71)では卓までの距離が変わらなかったので、試算は回し直さなかった。ただし、そのときページの平面図を作り直し忘れていたので、今回の作り直しで一緒に直した。

距離が変わったのは ⑦ だけ(30卓。卓までの平均 11.04m → 10.85m)。②〜⑥は卓・距離・止まる位置が前と同じ。

## v2.5 と比べた結果(compare_v25_v26.txt)

- 16,425条件の並びは同じ。⑦ 以外の14,892条件は、数字がすべて v2.5 と同じ(前の結果をそのまま使った)
- ⑦ の1,533条件は全部回し直した。入店待ちの差は平均 −0.06分(−5.4〜+3.9分)
- 店が回らないの数は、⑦ が204 → 203、全体が3,007 → 3,006

## ページの作り方

公開中のページ(p2m-site の `public/sim/serving-robot.html`)には、後から手で足した「費用の欄」がある。なので、ページ全体を作り直さず、作ったページの `const D = …;` の1行と見出しの版だけを公開中のページに入れる。

```
python3 build_page_v26.py results.json page_v26.template.html serving-robot.v26.html --into <公開中の serving-robot.html>
node test_page_v26.js serving-robot.v26.html     # 全部の組み合わせを描いて例外がないか(費用の欄のため、仮の DOM に addEventListener などを足した)
python3 export_params.py results.json serving-robot-params.json
```

## ファイル

- `haizen_sim.py`:試算のモデル(v2.4 と同じ)
- `results.json`:総当たりの結果(16,425条件×40回)
- `layouts/`:店の形と解析結果と summary(p2m-site の public/sim/layouts/ の写し)
- `build_page_v26.py`・`page_v26.template.html`・`test_page_v26.js`:ページの作り方と確かめ
- `serving-robot.v26.html`:作ったページ(p2m-site の `public/sim/serving-robot.html` に入れた)
- `serving-robot-params.json`:Unity が読む条件(p2m-site の `public/sim/serving-robot-params.json` に入れた)
- `compare_v25_v26.txt`:v2.5 と比べた結果

v2_5/ より前は前の版。公開済みの記事の数字は前の版のまま。
simulation/v2_6/compare_v25_v26.txt
v2.5 と v2.6 の比較(⑦ の細い通路を0.8mから0.95mに広げたため、⑦(fam_p5)だけ回し直した)
条件の数 16425 16425 並びが同じ True
⑦ 以外で数字が変わった条件 0 / 14892
⑦ の条件 1533 変わった条件 1533
⑦ の卓の数 42 -> 42  卓までの平均 11.04 -> 10.85
⑦ の店が回らない 204 -> 203  全体 3007 -> 3006
⑦ entry_wait_mean : 差の平均 -0.062  最小 -5.365  最大 +3.869
⑦ staff_wait_mean : 差の平均 -0.051  最小 -4.481  最大 +3.048
⑦ dish_wait_mean : 差の平均 -0.007  最小 -0.120  最大 +0.036
⑦ robot_share : 差の平均 +0.001  最小 -0.024  最大 +0.026
simulation/v2_6/build_page_v26.py
"""試算の結果(results.json)から、公開用の試算ページ(serving-robot.html)を作る(v2.6)。

使い方: python3 build_page_v26.py results.json page_v26.template.html <出力先>
  v2.6:試算のモデルは v2.4 のまま。店の形を直した版に入れ替え(③⑥⑦のレジの向き・会計の列・⑦の細い通路0.95m)、⑦だけ回し直した。
  公開中のページには、後から手で足した「費用の欄」があるので、ページ全体を置き換えず、
  作ったページの「const D = …;」の1行と見出しの版だけを公開中のページに入れる(--into 公開中のページ)。
  v2.5:試算のモデルは v2.4 のまま、店の形(layouts/)を直した版に入れ替え、② 定番の郊外型だけ回し直した。
店の形の版(generation)がそろっているか、試算に使った卓までの距離が店の形の距離と同じかを確かめてから作る。simulation/v2_6/test_page_v26.js
// 作り直したページを、簡易の DOM で全組み合わせ描画して、データ欠けや例外がないか確かめる
// v2.6:公開中のページに後から足した費用の欄のため、仮の DOM に addEventListener などを足した
// 使い方: node test_page_v23.js <ページ>(v2.3:図面のある店を含む全部の店)
const fs = require("fs");
const h = fs.readFileSync(process.argv[2], "utf8");
const scripts = h.split("<script>").slice(1).map(x => x.split("</script>")[0]);
let js = scripts.find(x => x.includes("const D ="));
js = js.replace(/buildStores\(\);\s*buildLayouts\(\);\s*buildControls\(\);\s*render\(\);\s*$/, "");
js += `;let n=0, ng=0, notes=0;
for (const st of Object.keys(STORES)) { state.store = st; const s = STORES[st];
  for (const sf of s.staff_all) for (const rb of ROBOTS_ALL) for (const md of ["serve","bus","patrol"]) for (const c of [0,1,2]) for (const tr of [1,3]) for (const fb of ["any","staff"]) {
    Object.assign(state, {staff: sf, robots: rb, mode: md, crowd: c, trays: tr, fb: fb, cbase: s.staff_all[1 + (n % (s.staff_all.length - 1))], crob: 1 + (n % 6)});
    buildStores(); buildLayouts(); buildControls(); render(); n++;
    if (/店が回らない/.test(document.getElementById("kpis").innerHTML)) ng++;
    if (!document.getElementById("robot-note").hidden) notes++;
  } }
console.log("rendered", n, "/ 回らないが出た画面", ng, "/ 5台以上の注意", notes);`;
const els = {};
const mk = () => ({ innerHTML: "", textContent: "", onchange: null, onclick: null, hidden: false, style: {}, className: "",
  after() {}, querySelector() { return null; }, setAttribute() {}, addEventListener() {}, appendChild() {}, classList: { add() {}, remove() {}, toggle() {} } });
global.document = { getElementById: id => els[id] || (els[id] = mk()), querySelectorAll: () => [], querySelector: () => null,
  createElement: () => mk(), addEventListener() {} };
new Function(js)();
haizen_sim.py の v2.6 → v2.7 の差分
--- /tmp/claude-0/-home-claude/2afc91f9-ca44-5f2d-a1f2-8ded1ee7eedd/scratchpad/v2_6/haizen_sim.py	2026-10-23 18:12:52.750476718 +0900
+++ /tmp/claude-0/-home-claude/2afc91f9-ca44-5f2d-a1f2-8ded1ee7eedd/scratchpad/v2_7/haizen_sim.py	2026-10-23 20:26:49.112509336 +0900
@@ -94,7 +94,8 @@
     "warmup_min": 60,         # 回るかの確かめで、数えない慣らしの時間(分)
     "util_sample_s": 10,      # 手がふさがっている人数・台数を数える間隔(秒)
     "max_extra_min": 600,     # 数える時間のあと、追いかけるのを打ち切る上限(分)。店が回らない条件の保険
-    "model": "v2.4",          # モデルの版(前の版の結果を使い回さないための印)
+ "robot_first_wait_s": 120, # v2.7 ロボット優先:料理はロボットを待つ。これだけ待っても来なければスタッフが運ぶ(秒)simulation/v2_7/haizen_sim.py(v2.7・全文)
"""
サービスロボット導入シミュレーション #1 配膳ロボット(試作 v2.4)

v2.4 で直したこと(2026-10-22。動画の台本を codex で検証したときに見つかった2点。直し方はエイイチと決めた)
  1. 入店待ちの終わりを「案内されて卓に着いたとき」にした。v2.3 までは、案内したスタッフが説明(guide_s)を
     終えて受け渡し口まで戻るときまで数えていた。説明の時間と戻りの時間は、スタッフの手がふさがる時間には
     これまでどおり入れ、お客さんの流れ(注文を待つ)もこれまでどおりスタッフが戻ってから進める。
2. 「下げ膳にも使う」(bus)で、ロボットがスタッフより先に卓へ行き、皿を載せる前に帰っていたのを直した。simulation/v2_7/run_shard.py
"""v2.7 の総当たりを分けて回す(Mac と作業用の計算機で並べて回すため)。
使い方: python3 run_shard.py <受け持つ番号(カンマ区切り)> <いくつに分けるか> <出力.json> [<プロセス数>] [<打ち切る秒>]
条件の並びは haizen_sim.conditions() と同じ。i 番目の条件を i % n が受け持つ番号に入る組が回す。
途中経過は <出力.json>.partial に残し、もう一度動かすと続きから回す。打ち切る秒を過ぎたら、そこまでを残して止まる。
"""
import json, os, sys, time
from multiprocessing import Pool
import haizen_sim as h
ks = {int(x) for x in sys.argv[1].split(",")}
n, out = int(sys.argv[2]), sys.argv[3]
procs = int(sys.argv[4]) if len(sys.argv) > 4 else None
limit = float(sys.argv[5]) if len(sys.argv) > 5 else 1e18
t0 = time.time()
conds = [c for i, c in enumerate(h.conditions()) if i % n in ks]
done = {}
if os.path.exists(out + ".partial"):
    done = {h.key(r): r for r in json.load(open(out + ".partial"))}
todo = [c for c in conds if h.key(c) not in done]
print(len(conds), "conditions,", len(todo), "to run", flush=True)

def save():
    json.dump(list(done.values()), open(out + ".partial.tmp", "w")); os.replace(out + ".partial.tmp", out + ".partial")

pool = Pool(procs)
try:
    for i, r in enumerate(pool.imap_unordered(h.run_condition, todo, chunksize=1), 1):
        done[h.key(r)] = r
        if i % 100 == 0:
            save()
        if time.time() - t0 > limit:
            break
finally:
    pool.terminate()
save()
if all(h.key(c) in done for c in conds):
    json.dump([done[h.key(c)] for c in conds], open(out, "w"))
    print("written", len(conds), flush=True)
else:
    print("partial", sum(h.key(c) in done for c in conds), "/", len(conds), flush=True)
simulation/v2_7/build_page_v27.py
"""試算の結果(results.json)から、公開用の試算ページ(serving-robot.html)を作る(v2.7)。

使い方: python3 build_page_v27.py results.json page_v27.template.html <出力先> --into <公開中の serving-robot.html>
  v2.7:料理をロボット優先にした(2分待ってもロボットが来なければスタッフが運ぶ)。全条件を回し直した。
  --into のとき、const D の1行と見出しの版に加えて、前提の一覧の「配膳の分担」の1行も入れ替える。
  v2.6:試算のモデルは v2.4 のまま。店の形を直した版に入れ替え(③⑥⑦のレジの向き・会計の列・⑦の細い通路0.95m)、⑦だけ回し直した。
  公開中のページには、後から手で足した「費用の欄」があるので、ページ全体を置き換えず、
作ったページの「const D = …;」の1行と見出しの版だけを公開中のページに入れる(--into 公開中のページ)。simulation/v2_7/test_page_v27.js
// 作り直したページを、簡易の DOM で全組み合わせ描画して、データ欠けや例外がないか確かめる
// v2.6:公開中のページに後から足した費用の欄のため、仮の DOM に addEventListener などを足した
// 使い方: node test_page_v23.js <ページ>(v2.3:図面のある店を含む全部の店)
const fs = require("fs");
const h = fs.readFileSync(process.argv[2], "utf8");
const scripts = h.split("<script>").slice(1).map(x => x.split("</script>")[0]);
let js = scripts.find(x => x.includes("const D ="));
js = js.replace(/buildStores\(\);\s*buildLayouts\(\);\s*buildControls\(\);\s*render\(\);\s*$/, "");
js += `;let n=0, ng=0, notes=0;
for (const st of Object.keys(STORES)) { state.store = st; const s = STORES[st];
  for (const sf of s.staff_all) for (const rb of ROBOTS_ALL) for (const md of ["serve","bus","patrol"]) for (const c of [0,1,2]) for (const tr of [1,3]) for (const fb of ["any","staff"]) {
    Object.assign(state, {staff: sf, robots: rb, mode: md, crowd: c, trays: tr, fb: fb, cbase: s.staff_all[1 + (n % (s.staff_all.length - 1))], crob: 1 + (n % 6)});
    buildStores(); buildLayouts(); buildControls(); render(); n++;
    if (/店が回らない/.test(document.getElementById("kpis").innerHTML)) ng++;
    if (!document.getElementById("robot-note").hidden) notes++;
  } }
console.log("rendered", n, "/ 回らないが出た画面", ng, "/ 5台以上の注意", notes);`;
const els = {};
const mk = () => ({ innerHTML: "", textContent: "", onchange: null, onclick: null, hidden: false, style: {}, className: "",
  after() {}, querySelector() { return null; }, setAttribute() {}, addEventListener() {}, appendChild() {}, classList: { add() {}, remove() {}, toggle() {} } });
global.document = { getElementById: id => els[id] || (els[id] = mk()), querySelectorAll: () => [], querySelector: () => null,
  createElement: () => mk(), addEventListener() {} };
new Function(js)();
simulation/v2_7/compare_v26_v27.txt
v2.6 と v2.7 の比較(料理をロボット優先にした。2分待ってもロボットが来なければスタッフが運ぶ)。全条件を回し直した
条件の数 16425 16425 並びが同じ True
ロボット0台の条件 225 数字が変わった 0
店が回らない 全体 3006 -> 2955
ロボットあり robot_share        v2.6平均 0.694 -> v2.7平均 0.845  差の平均 +0.151  最小 -0.003 最大 +0.810
ロボットあり dish_wait_mean     v2.6平均 0.592 -> v2.7平均 1.011  差の平均 +0.419  最小 -0.409 最大 +2.032
ロボットあり cold_share         v2.6平均 0.014 -> v2.7平均 0.037  差の平均 +0.023  最小 -0.014 最大 +0.447
ロボットあり entry_wait_mean    v2.6平均 9.272 -> v2.7平均 9.227  差の平均 -0.046  最小 -17.622 最大 +7.464
ロボットあり staff_wait_mean    v2.6平均 6.500 -> v2.7平均 6.347  差の平均 -0.153  最小 -12.284 最大 +5.204
ロボットあり staff_util         v2.6平均 0.551 -> v2.7平均 0.533  差の平均 -0.017  最小 -0.164 最大 +0.028
ロボットあり robot_util         v2.6平均 0.441 -> v2.7平均 0.491  差の平均 +0.050  最小 -0.023 最大 +0.254
ロボットあり walk_km_per_staff  v2.6平均 2.314 -> v2.7平均 2.144  差の平均 -0.171  最小 -2.131 最大 +0.747
fam_p1 例 ('fam_p1', 4, 2, 42, 'serve', 3, 'any') {'robot_share': (0.726, 0.991), 'dish_wait_mean': (0.457, 1.01), 'cold_share': (0.0, 0.014), 'entry_wait_mean': (1.019, 0.834)}
fam_p5 例 ('fam_p5', 4, 2, 42, 'serve', 3, 'any') {'robot_share': (0.731, 0.99), 'dish_wait_mean': (0.481, 1.05), 'cold_share': (0.0, 0.016), 'entry_wait_mean': (1.416, 1.591)}
family 例 ('family', 3, 2, 35, 'serve', 3, 'any') {'robot_share': (0.799, 0.995), 'dish_wait_mean': (0.643, 1.025), 'cold_share': (0.001, 0.013), 'entry_wait_mean': (4.122, 3.156)}
Unity のコード(cs:140 の時点)
/Users/shimazueiichi/Robotics_UX/Robotics_UX_New/Assets/ServiceSim/ のうち、この記事の作業(cs:125〜cs:140)で書き換わったファイルの全文です。prefab・マテリアル・.meta は載せていません。
Assets/ServiceSim/Editor/ServiceSimLabels.cs
using System.Collections.Generic;
using UnityEditor;
using UnityEngine;

namespace ServiceSim.EditorTools
{
    /// <summary>
/// 人とロボットが「いま何をしているか」を、頭の上に1行で出す(Scene ビューだけ)。Assets/ServiceSim/Editor/ServiceSimLedger.cs
using System;
using System.Collections.Generic;
using System.Globalization;
using System.IO;
using System.Text;
using UnityEngine;

namespace ServiceSim.EditorToolsAssets/ServiceSim/Editor/ServiceSimLegend.cs
using System.Reflection;
using UnityEditor;
using UnityEngine;

namespace ServiceSim.EditorTools
{
    /// <summary>
/// 真上の画面の隅に出す「色の意味」の凡例(見た目だけ)。Assets/ServiceSim/Editor/ServiceSimMenu.cs
using System;
using System.Collections.Generic;
using System.Globalization;
using System.IO;
using System.Text;
using UnityEditor;
using UnityEditor.SceneManagement;
using UnityEngine;Assets/ServiceSim/Editor/ServiceSimSetup.cs
using System;
using System.Collections.Generic;
using System.IO;
using UnityEditor;
using UnityEditor.SceneManagement;
using UnityEngine;
using UnityEngine.AI;
using UnityEngine.SceneManagement;Assets/ServiceSim/Editor/ServiceSimStage2.cs
using System;
using System.Collections.Generic;
using System.IO;
using UnityEditor;
using UnityEditor.SceneManagement;
using UnityEngine;
using UnityEngine.SceneManagement;
Assets/ServiceSim/Editor/ServiceSimStageB.cs
using System;
using System.Collections.Generic;
using System.Globalization;
using System.IO;
using System.Text;
using UnityEditor;
using UnityEditor.SceneManagement;
using UnityEngine;Assets/ServiceSim/Experiment/ExperimentPlan.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 9d7ca72301ae84dbd8937d681f3df43d, type: 3}
  m_Name: ExperimentPlan
  m_EditorClassIdentifier:
  runName: family_v0
  aisleWidthIndices: 000000000100000002000000
  crowdLevels: 000000000100000002000000
  robotCounts: 0100000002000000
  tripsPerCondition: 100
  seeds: 0000000001000000020000000300000004000000
  timeScale: 1
  kioxiaVolumePath: /Volumes/KIOXIA
  kioxiaOutputRoot: /Volumes/KIOXIA/r2r2r-data/service_sim/unity
  trialAisleWidthIndex: 1
  trialCrowd: 1
  trialRobots: 2
  trialSeed: 0
  trialTrips: 20
  trialTimeScaleFast: 10
  trialCaptureDeltaTime: 0.02
  trialMaxWallSeconds: 2400
  trialOutputRoot: /Users/shimazueiichi/ServiceSim_tmp
  measureMinutes: 120
  warmupMinutes: 15
  measureCaptureDeltaTime: 0.05
  referenceCaptureDeltaTime: 0.02
  disableRenderingWhileRunning: 0
  showLabelsWhileRunning: 0
  showKitchenMonitor: 1
  stage3OutputRoot: /Users/shimazueiichi/ServiceSim_tmp/stage3
  stage3Resume: 1
  screenshotDir: "/Users/shimazueiichi/Library/Mobile Documents/com~apple~CloudDocs/\u30C7\u30B9\u30AF\u30C8\u30C3\u30D7/ADAPT
    DESIGN/\u3058\u3076\u3093\u306E/PixelstoMotors/\u30C7\u30B8\u30BF\u30EB\u30C4\u30A4\u30F3\u5B66\u7FD2R2R2R/\u30B5\u30FC\u30D3\u30B9\u30ED\u30DC\u30C3\u30C8\u5C0E\u5165\u30B7\u30DF\u30E5\u30EC\u30FC\u30B7\u30E7\u30F3/unity/screens"
  screenshotWidth: 1920
  screenshotHeight: 1080
Assets/ServiceSim/Experiment/ExperimentPlan.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// 回す条件と、書き出す場所。実験に関する数字と場所はすべてこの .asset に置く。
/// 条件を順に回すのは ExperimentRunner(段階2で作る)。Assets/ServiceSim/Experiment/ExperimentRunner.cs
using System.Collections.Generic;
using System.IO;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
/// 条件を回して記録する。1回の Play の中で、条件を順に通せる(段階3の Run All)。Assets/ServiceSim/Experiment/SimParams.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: edb06b3fbd714f289d7487e59b3a49b3, type: 3}
  m_Name: SimParams
  m_EditorClassIdentifier:
  paramsJson: {fileID: 4900000, guid: 7c1a9b5e4d2f4a6ca1b3e8d0f5c27a94, type: 3}
  fetchedAt: 2026-10-23 17:00:00 JST(版 82023936eb99)
  sourceUrl: https://pixelstomotors.com/sim/serving-robot-params.json
Assets/ServiceSim/Experiment/SiteValues.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// サイトの試算の値(SimParams)を、その回だけ ServiceSpec / PeopleSpec / RobotSpec に入れる。
///Assets/ServiceSim/Experiment/TripLogger.cs
using System;
using System.Collections.Generic;
using System.Globalization;
using System.IO;
using System.Text;
using UnityEngine;

namespace ServiceSimAssets/ServiceSim/LABEL_RULES.md
# ServiceSim 表示のルール

## 対象
Scene ビューに出す文字、store_report、Console。
CSV に書く値の言葉は対象外(過去の記録と比べられなくなるため。変えるときは対応表を作ってから別に行う)。

## 場所の名前
- 動かないものにだけ付ける:入口・風除室・待合・レジ・レジの内側・厨房・受け渡し口・返却口・パントリー・ドリンクバー・トイレAssets/ServiceSim/People/PeopleSpec.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 485ae95cc6b11479eaf59a14275b67cb, type: 3}
  m_Name: PeopleSpec
  m_EditorClassIdentifier:
  personRadius: 0.2
  personHeight: 1.7
  seatedBodyHeight: 1.35
  seatedSeatHeight: 0.45
  staffCount: 2
  staffSpeed: 1
  staffTaskWeights:
  - 1
  - 1
  - 1
  - 1
  - 1
  staffDwellAtPassSec: 3
  staffDwellAtTableSec: 5
  staffDwellAtReturnSec: 5
  staffDwellAtPantrySec: 5
  staffDwellAtWaitingSec: 5
  staffDwellAtRegisterSec: 30
  guestCountByCrowd: 010000000400000008000000
  guestSpeed: 0.8
  guestTripWeights:
  - 1
  - 1
  - 1
  guestDwellAtPoiSec: 10
  guestDwellAtRegisterSec: 20
  guestDwellAtTableSec: 30
  warmupOccupancy: 0.8
  jamNarrowAfterSec: 1
  jamNarrowRadius: 0.12
  jamBackOffAfterSec: 3
  jamStuckSpeed: 0.05
  waitingCountByCrowd: 000000000200000005000000
  waitingShuffleSec: 25
  chairPullHoldSec: 30
  chairPullDistance: 0.3
  chairPullIdleMeanIntervalSec: 1800
  guestGiveUpSec: 60
  guestWarpHomeSec: 60
  staffGiveUpSec: 60
  staffGiveUpMaxTries: 3
  registerBackArea: 3
  avoidancePriority: 50
  avoidanceQuality: 3
  acceleration: 2
  angularSpeedDegPerSec: 360
  stoppingDistance: 0.3
  robotYieldEnabled: 1
  robotAisleLookAheadM: 3
  robotAisleMarginM: 0.3
  robotDetourExtraMaxM: 5
  robotFaceToFaceM: 1.5
  robotKeepClearM: 0.3
  robotSideStepM: 0.5
  robotBackOffSearchM: 4
  robotPassedClearM: 0.5
  robotYieldMaxSec: 20
  robotCarelessChance: 0.02
  robotContactGapM: 0.1
  robotNudgeSpeedMps: 0.5
  staffFirstYield: 1
  staffFirstGuestStopSec: 5
  staffFirstSqueezeGapM: 0.1
  staffFirstRobotStuckSec: 60
Assets/ServiceSim/People/PeopleSpec.cs
using UnityEngine;
using UnityEngine.AI;

namespace ServiceSim
{
    /// <summary>混み具合の3段階</summary>
    public enum CrowdLevel
{Assets/ServiceSim/People/PersonRobotYield.cs
using System.Collections.Generic;
using UnityEngine;
using UnityEngine.AI;

namespace ServiceSim
{
    /// <summary>
/// 人がロボットをよける。スタッフと歩く客に付ける。Assets/ServiceSim/People/StaffAgent.cs
using System.Collections.Generic;
using UnityEngine;
using UnityEngine.AI;

namespace ServiceSim
{
    /// <summary>
/// スタッフ1人。確率で仕事を選ぶのではなく、そのときに起きている仕事をAssets/ServiceSim/Robot/RobotSpec.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 6b50de1a9617a4ad5b687f834c80800b, type: 3}
  m_Name: RobotSpec
  m_EditorClassIdentifier:
  diameter: 0.5
  height: 1.2
  maxSpeed: 0.6
  acceleration: 1
  deceleration: 1
  turnSpeedDegPerSec: 180
  sensorRange: 0.6
  sensorWidth: 0.5
  sensorHeight: 1.2
  resumeAfterClearSec: 1
  replanAfterStoppedSec: 10
  stuckAfterStoppedSec: 60
  stuckRecoveryWaitSec: 15
  maxTripSec: 600
  aisleYielding: 1
  aisleWaitMaxSec: 20
  aisleWaitSetbackM: 0.9
  aisleWaitSideM: 0.6
  robotYieldAfterSec: 2
  robotYieldMaxSec: 20
  robotYieldClearM: 0.6
  robotYieldBackM: 0.9
  useReturnLine: 1
  passReturnOffsetM: 1
  passReturnSeparationM: 1
  passReturnKeepAwayM: 0.6
  passReturnCheckStepM: 0.05
  oneRobotPerAisle: 1
  tableDwellSec: 25
  arriveRadius: 0.25
  cornerReachDistance: 0.12
  stoppedSpeedEpsilon: 0.02
  clearanceProbeHeight: 0.3
  clearanceProbeRange: 3
  pathBlockSearchRadius: 2
  avoidancePriority: 0
  repathRetrySec: 1
  noPathForceReplanSec: 10
  escapeToAisleEntranceOnPartialPath: 1
  followSiteRoutes: 1
  waypointReachDistance: 0.25
  routePointSnapM: 0.1
Assets/ServiceSim/Robot/RobotSpec.cs
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// 配膳ロボットの数字。ロボットに関する数字はすべてこの .asset に置く。
    /// </summary>
[CreateAssetMenu(menuName = "ServiceSim/Robot Spec", fileName = "RobotSpec")]Assets/ServiceSim/Robot/ServingRobotController.cs
using System;
using System.Collections.Generic;
using UnityEngine;
using UnityEngine.AI;

namespace ServiceSim
{
/// <summary>Assets/ServiceSim/Robot/YieldSide.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// 譲る側が「相手の道から横へどく」ための形の計算(2026-10-23 エイイチと決めた)。
///Assets/ServiceSim/Service/ServiceOps.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>料理1皿</summary>
    public class DishOrder
{Assets/ServiceSim/Service/ServiceSpec.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 678ac8a5ea67d4f8c89127fd97fb60a1, type: 3}
  m_Name: ServiceSpec
  m_EditorClassIdentifier:
  arrivalsPerHourByCrowd: 19000000230000002d000000
  peakMinutes: 120
  arrivalsPerHour: 0
  rescueSec: 15
  maxExtraMin: 600
  groupSizeWeights:
  - 0.2
  - 0.35
  - 0.2
  - 0.25
  guideSec: 45
  paySec: 90
  callSec: 30
  registerCrowdRadiusM: 2
  payAtRegisterByOne: 1
  registerPayOffSpotM: 0.1
  callRate: 0.6
  firstDish1CookMin: {x: 5, y: 8, z: 12}
  firstDish2CookMin: {x: 8, y: 12, z: 18}
  fragilePerGroup: 0.5
  fragileCookMin: {x: 2, y: 4, z: 7}
  fragileByRobot: 1
  coldMin: 3
  trays: 3
  robotHandoffSec: 25
  staffPlaceSec: 10
  eatMin: {x: 20, y: 30, z: 45}
  drinkTripsPerPerson: 1.5
  drinkBarSec: 20
  toiletTripsPerGroup: 0.3
  toiletSec: 180
  clearSec: 40
  wipeSec: 40
  busTrips: 2
  waitingVisibleMax: 8
  tableStuckFreeSec: 600
Assets/ServiceSim/Service/ServiceSpec.cs
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// 店の回し方の数字。試算(haizen_sim.py の COMMON と STORES["family"])と同じ値にそろえる。
    /// 店の運営に関する数字はすべてこの .asset に置く。
///Assets/ServiceSim/Store/FloorPaint.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// 床の塗り分け(見た目だけ。2026-10-23 に決め直した)。
///Assets/ServiceSim/Store/JsonStoreLayout.cs
using System;
using System.Collections.Generic;
using System.Globalization;
using System.Text;
using UnityEngine;

namespace ServiceSim
{Assets/ServiceSim/Store/KitchenMonitor.cs
using System.Collections.Generic;
using System.Text;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
/// キッチンのモニター(2026-10-23 エイイチと決めた。設計書 v0 の 0 章)。Assets/ServiceSim/Store/RouteBook.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
    /// ロボットの道順(v5b)。サイトが決めた曲がり角の点の並びを持つ。
///Assets/ServiceSim/Store/StoreBuilder.cs
using System;
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>
/// StoreLayout が作った部品の一覧(StorePlan)を見て、床・壁・卓・椅子・ベンチ・Assets/ServiceSim/Store/StoreLayout_Family.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 6f4fb03fd01dc4444ba2b4e5f289aee3, type: 3}
  m_Name: StoreLayout_Family
  m_EditorClassIdentifier:
  aisleWidthOptions:
  - 0.8
  - 1
  - 1.2
  aisleWidthIndex: 2
  deliveryOffsetFromAisleCenter: 0.15
  aisleEntranceSetback: 0.8
  aisleEntranceSideOffset: 0.45
  wallHeight: 2.4
  wallThickness: 0.15
  floorThickness: 0.2
  showAisleMarks: 1
  aisleMarkThickness: 0.02
  showFloorPaint: 1
  floorPaintCellSize: 0.05
  floorPaintHeight: 0.03
  navAgentRadius: 0.25
  navAgentHeight: 1.2
  navAgentClimb: 0.2
  navAgentSlope: 10
  navVoxelSize: 0.05
  navMinRegionArea: 0.3
  navBoundsPadding: 1
  mainAisleWidth: 1.6
  crossAisleWidth: 1.2
  kitchenDepthX: 10
  serviceStripDepth: 0.8
  toiletSize: {x: 3, y: 4}
  toiletDoorWidthZ: 1
  passFromNorthZ: 1.5
  passWindowLengthZ: 1.2
  pantryFromNorthZ: 2.5
  pantryLengthZ: 4.5
  returnFromNorthZ: 8
  returnWindowLengthZ: 1
  wallBoothCount: 8
  boothTableSize: {x: 1.4, y: 0.75}
  benchDepth: 0.45
  benchSeatHeight: 0.45
  benchBackThickness: 0.1
  benchHeight: 1.1
  benchSeatGapX: 0.05
  benchSeatPadThickness: 0.02
  wallTableSize: {x: 0.7, y: 0.6}
  wallTableGapX: 0.6
  wallTableCountFromNarrowestAisle: 1
  seatApproachGapZ: 0.3
  islandColumns: 3
  islandTablesPerColumn: 3
  islandTableSize: {x: 0.75, y: 1.2}
  islandTableGapZ: 0.1
  chairDepth: 0.45
  chairWidth: 0.45
  chairHeight: 0.45
  tableHeight: 0.72
  dividerHeight: 1.1
  entranceWidthX: 2
  vestibuleDepthZ: 1.2
  waitingDepthZ: 0
  registerSize: {x: 1, y: 0.5}
  registerQueueCount: 3
  registerQueuePitch: 0.5
  registerBackDepthZ: 1.2
  registerBackMinOpenZ: 0.7
  drinkBarSize: {x: 3.6, y: 0.7}
  counterHeight: 1
  approachGap: 0.6
  waitingStandCount: 8
  waitingStandAreaM2: 0.5
  robotStandbyCount: 2
  robotStandbySideOffset: 0.4
  robotStandbyFromPassZ: 1.6
  robotStandbyPitchZ: 0.8
  robotStandbyMinClearX: 0.55
  staffStandbyCount: 2
  staffStandbyFromPassZ: 0.45
  staffStandbyPitchX: 0.6
  staffStandbySideOffset: 0.4
  drinkBarStandCount: 4
  drinkBarStandDepthZ: 1.5
  drinkBarQueueCount: 3
  drinkBarQueuePitch: 0.5
  drinkBarQueueDepthZ: 0.6
  drinkBarAisleClearZ: 0.1
Assets/ServiceSim/Store/StoreLayout_Grid.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: a69ee8612d7ba42369abb20536652cc9, type: 3}
  m_Name: StoreLayout_Grid
  m_EditorClassIdentifier:
  aisleWidthOptions:
  - 0.8
  - 1
  - 1.2
  aisleWidthIndex: 2
  deliveryOffsetFromAisleCenter: 0.15
  aisleEntranceSetback: 0.8
  aisleEntranceSideOffset: 0.45
  wallHeight: 2.4
  wallThickness: 0.15
  floorThickness: 0.2
  showAisleMarks: 1
  aisleMarkThickness: 0.02
  showFloorPaint: 1
  floorPaintCellSize: 0.05
  floorPaintHeight: 0.03
  navAgentRadius: 0.25
  navAgentHeight: 1.2
  navAgentClimb: 0.2
  navAgentSlope: 10
  navVoxelSize: 0.05
  navMinRegionArea: 0.3
  navBoundsPadding: 1
  tableCount: 35
  branchAisleCenterZ:
  - 4.9
  - 9.3
  - 13.7
  unitsPerBranchSide: 6
  unitPitchX: 1.4
  firstUnitCenterX: 1.35
  drinkBarSlotIndex: 35
  mainAisleWidth: 1.5
  rearCrossAisle: 0
  tableSize: {x: 1.2, y: 0.72, z: 0.8}
  chairSize: {x: 0.45, y: 0.45, z: 0.4}
  chairOffsetX: 0.3
  boothDividerHeight: 1.2
  passCounterSize: {x: 1.6, y: 1, z: 0.5}
  passPoint: {x: 0, y: 0, z: 0.15}
  registerCounterSize: {x: 2, y: 1, z: 0.6}
  registerCenterX: 2.4
  toiletBlockSize: {x: 2.4, y: 2.4, z: 1.6}
  toiletCenterX: 7.6
  poiApproachGap: 0.7
  drinkBarHeight: 1.1
  frontPocketDepth: 3.4
Assets/ServiceSim/Store/StoreLayout_p1_efficient_corner.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 290f4a1a37804297962e9248caa661ce, type: 3}
  m_Name: StoreLayout_p1_efficient_corner
  m_EditorClassIdentifier:
  aisleWidthOptions:
  - 1.2
  aisleWidthIndex: 0
  deliveryOffsetFromAisleCenter: 0
  aisleEntranceSetback: 0.8
  aisleEntranceSideOffset: 0.45
  wallHeight: 2.7
  wallThickness: 0.15
  floorThickness: 0.2
  showAisleMarks: 1
  aisleMarkThickness: 0.02
  showFloorPaint: 1
  floorPaintCellSize: 0.05
  floorPaintHeight: 0.03
  navAgentRadius: 0.25
  navAgentHeight: 1.2
  navAgentClimb: 0.2
  navAgentSlope: 10
  navVoxelSize: 0.05
  navMinRegionArea: 0.3
  navBoundsPadding: 1
  layoutJson: {fileID: 4900000, guid: 2154377bd0d440b69bac2e9493720fa7, type: 3}
  summaryJson: {fileID: 4900000, guid: 4525eb25b69c4468aadbce9a96430dd9, type: 3}
  layoutFileName: p1_efficient_corner
  fetchedAt: "2026-10-23 17:00:00 JST\uFF08\u7248 82023936eb99\uFF09"
  sourceUrl: https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json
  benchBackThickness: 0.08
  benchSeatInset: 0.03
  keepoutMarkThickness: 0.02
Assets/ServiceSim/Store/StoreLayout_p5_crammed.asset
%YAML 1.1
%TAG !u! tag:unity3d.com,2011:
--- !u!114 &11400000
MonoBehaviour:
  m_ObjectHideFlags: 0
  m_CorrespondingSourceObject: {fileID: 0}
  m_PrefabInstance: {fileID: 0}
  m_PrefabAsset: {fileID: 0}
  m_GameObject: {fileID: 0}
  m_Enabled: 1
  m_EditorHideFlags: 0
  m_Script: {fileID: 11500000, guid: 290f4a1a37804297962e9248caa661ce, type: 3}
  m_Name: StoreLayout_p5_crammed
  m_EditorClassIdentifier:
  aisleWidthOptions:
  - 0.95
  aisleWidthIndex: 0
  deliveryOffsetFromAisleCenter: 0
  aisleEntranceSetback: 0.8
  aisleEntranceSideOffset: 0.45
  wallHeight: 2.7
  wallThickness: 0.15
  floorThickness: 0.2
  showAisleMarks: 1
  aisleMarkThickness: 0.02
  showFloorPaint: 1
  floorPaintCellSize: 0.05
  floorPaintHeight: 0.03
  navAgentRadius: 0.25
  navAgentHeight: 1.2
  navAgentClimb: 0.2
  navAgentSlope: 10
  navVoxelSize: 0.05
  navMinRegionArea: 0.3
  navBoundsPadding: 1
  layoutJson: {fileID: 4900000, guid: a434eab598f04c4bbc7dd5b140c3a21f, type: 3}
  summaryJson: {fileID: 4900000, guid: 4525eb25b69c4468aadbce9a96430dd9, type: 3}
  layoutFileName: p5_crammed
  fetchedAt: "2026-10-23 17:00:00 JST\uFF08\u7248 82023936eb99\uFF09"
  sourceUrl: https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json
  benchBackThickness: 0.08
  benchSeatInset: 0.03
  keepoutMarkThickness: 0.02
Assets/ServiceSim/Store/StorePlan.cs
using System.Collections.Generic;
using UnityEngine;

namespace ServiceSim
{
    /// <summary>席の種類</summary>
    public enum SeatKind
{Unity の設計書(unity_design_v0.md)
unity/unity_design_v0.md
# 配膳ロボット:通路で何が起きるかを Unity で測る(設計 v0)

作成:2026-10-20
対象:サービスロボット導入シミュレーション(配膳ロボット)
実装:Claude Code(Unity)/設計・結果の読み込み・試算への反映:Claude

## 0. 何について正か(2026-10-22 エイイチと決めた)
段階Bの台帳と一覧のログ
unity_ledger_v1.csv
timestamp,run_folder,status,unity_cs,layout_generation,params_model,store,staff,robots,arrivals_per_h,mode,trays,fragile_by,seed,staff_first_yield,yield_order_enabled,one_robot_per_aisle,robot_first_wait_s,everyone_left,total_minutes,wall_seconds,entry_wait_mean,staff_wait_mean,dish_wait_mean,cold_share,robot_share,staff_util,robot_util,walk_km_per_staff,site_entry_wait_mean,site_staff_wait_mean,site_dish_wait_mean,site_robot_share,robot_speed_mps,pause_rate,pause_s_mean,stuck_rate,trips,timeouts,stuck_count,stop_s_total,corner_stop_time_share,gave_up,warped,table_freed,rescues,late_staff_dishes,staff_yield_share_of_staff_time,ledger_schema_version
2026-10-24T00:03:37,20261023_stageB_fam_p1_r2_s0,completed,cs:140,82023936eb99,v2.7,fam_p1,4,2,42,serve,3,any,0,1,1,1,120,1,179.5543,787.0753,2.892,1.6328,4.2197,0.5507,0.7053,0.8095,0.7073,2.5281,0.8336,0.559,1.0102,0.9914,0.5734,,5.1598,,99,7,55,5118.954,0.2212,100,59,35,55,61,0.0616,1
2026-10-24T00:21:58,20261023_stageB_fam_p5_r2_s0,completed,cs:140,82023936eb99,v2.7,fam_p5,4,2,42,serve,3,any,0,1,1,1,120,1,216.8588,968.6135,15.0673,3.9569,3.9381,0.5882,0.7463,0.7428,0.7209,3.0054,1.5915,1.0166,1.0497,0.9898,0.5776,,4.794,,116,9,61,5484.75,0.1488,106,107,45,61,69,0.0676,1
2026-10-24T00:33:37,20261023_stageB_fam_p1_r0_s0,completed,cs:140,82023936eb99,v2.7,fam_p1,4,0,42,serve,1,any,0,1,1,1,120,1,179.9344,694.309,1.9311,0.7289,0.9608,0,0,0.742,0,3.0918,3.1814,2.8545,0.653,0,0,,0,,0,0,0,0,0,10,11,22,0,0,0,1
2026-10-24T00:42:09,20261023_stageB_fam_p1_r0_s1,completed,cs:140,82023936eb99,v2.7,fam_p1,4,0,42,serve,1,any,1,1,1,1,120,1,171.637,507.5364,2.2816,1.0721,0.8046,0,0,0.758,0,3.1089,3.1814,2.8545,0.653,0,0,,0,,0,0,0,0,0,9,11,22,0,0,0,1
2026-10-24T00:51:32,20261023_stageB_fam_p1_r0_s2,completed,cs:140,82023936eb99,v2.7,fam_p1,4,0,42,serve,1,any,2,1,1,1,120,1,181.8777,558.8922,3.9575,2.1577,0.913,0,0,0.7676,0,3.2595,3.1814,2.8545,0.653,0,0,,0,,0,0,0,0,0,7,14,22,0,0,0,1
2026-10-24T01:01:20,20261023_stageB_fam_p1_r1_s0,completed,cs:140,82023936eb99,v2.7,fam_p1,4,1,42,serve,3,any,0,1,1,1,120,1,190.4947,583.2244,3.5292,1.6372,3.8528,0.6376,0.5688,0.7286,0.7901,2.7416,1.6401,1.189,2.0398,0.7252,0.5796,,6.1226,,57,1,20,2254.078,0.0157,58,43,23,20,94,0.0446,1
2026-10-24T01:10:23,20261023_stageB_fam_p1_r1_s1,completed,cs:140,82023936eb99,v2.7,fam_p1,4,1,42,serve,3,any,1,1,1,1,120,1,179.0147,538.8367,1.5759,0.3513,3.1393,0.5056,0.75,0.6575,0.7625,2.5104,1.6401,1.189,2.0398,0.7252,0.5802,,4.3264,,70,0,5,1117.942,0.2593,37,37,6,5,45,0.0375,1run_all_log.txt
=== 2026-10-24 02:54:55 段階B(Unity cs:140)===
[ServiceSim] 段階B:ぜんぶ終わりました
  回した: 18 / 18 回
  台帳: /Volumes/KIOXIA/r2r2r-data/service_sim/unity/unity_ledger_v1.csv
  一覧(出力フォルダ / status / 実時間 / 入店待ち / ロボットが運んだ割合):
    1. 20261023_stageB_fam_p1_r2_s0 / completed / 実時間 13.2 分 / 入店待ち 2.892 分 / ロボットが運んだ割合 0.7053
    2. 20261023_stageB_fam_p5_r2_s0 / completed / 実時間 18.4 分 / 入店待ち 15.0673 分 / ロボットが運んだ割合 0.7463
    3. 20261023_stageB_fam_p1_r0_s0 / completed / 実時間 11.7 分 / 入店待ち 1.9311 分 / ロボットが運んだ割合 0
    4. 20261023_stageB_fam_p1_r0_s1 / completed / 実時間 8.5 分 / 入店待ち 2.2816 分 / ロボットが運んだ割合 0
    5. 20261023_stageB_fam_p1_r0_s2 / completed / 実時間 9.4 分 / 入店待ち 3.9575 分 / ロボットが運んだ割合 0
    6. 20261023_stageB_fam_p1_r1_s0 / completed / 実時間 9.8 分 / 入店待ち 3.5292 分 / ロボットが運んだ割合 0.5688
    7. 20261023_stageB_fam_p1_r1_s1 / completed / 実時間 9.1 分 / 入店待ち 1.5759 分 / ロボットが運んだ割合 0.75
    8. 20261023_stageB_fam_p1_r1_s2 / completed / 実時間 9.2 分 / 入店待ち 5.9371 分 / ロボットが運んだ割合 0.5935
    9. 20261023_stageB_fam_p1_r2_s1 / completed / 実時間 9.1 分 / 入店待ち 2.3919 分 / ロボットが運んだ割合 0.6448
    10. 20261023_stageB_fam_p1_r2_s2 / completed / 実時間 10.0 分 / 入店待ち 9.0378 分 / ロボットが運んだ割合 0.6825
    11. 20261023_stageB_fam_p5_r0_s0 / completed / 実時間 8.7 分 / 入店待ち 4.8394 分 / ロボットが運んだ割合 0
    12. 20261023_stageB_fam_p5_r0_s1 / completed / 実時間 8.2 分 / 入店待ち 1.6157 分 / ロボットが運んだ割合 0
    13. 20261023_stageB_fam_p5_r0_s2 / completed / 実時間 8.9 分 / 入店待ち 1.6289 分 / ロボットが運んだ割合 0
    14. 20261023_stageB_fam_p5_r1_s0 / completed / 実時間 9.1 分 / 入店待ち 3.0575 分 / ロボットが運んだ割合 0.5899
    15. 20261023_stageB_fam_p5_r1_s1 / completed / 実時間 10.7 分 / 入店待ち 9.0647 分 / ロボットが運んだ割合 0.6179
    16. 20261023_stageB_fam_p5_r1_s2 / completed / 実時間 10.5 分 / 入店待ち 11.4668 分 / ロボットが運んだ割合 0.6585
    17. 20261023_stageB_fam_p5_r2_s1 / completed / 実時間 9.5 分 / 入店待ち 1.7955 分 / ロボットが運んだ割合 0.7569
    18. 20261023_stageB_fam_p5_r2_s2 / completed / 実時間 10.8 分 / 入店待ち 12.6712 分 / ロボットが運んだ割合 0.7953
回した記録
回ごとの出力のファイルです(people_jams.csv を除く)。
1311(cs:125・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 13:24:58",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.7397, "dish_wait_p90": 10.3976, "cold_share": 0.4527, "seat_wait_mean": 1.711, "turn_mean": 7.252, "robot_share": 0.3483, "robot_dishes": 70, "staff_dishes": 131, "requeued_dishes": 4, "groups": 81, "people_jams": 1460, "robot_blocked_jams": 1405, "robot_blocked_jam_share": 0.9623, "chair_pulls": 167, "robot_contacts": 56, "robot_yield_waits": 166, "robot_yield_wait_s": 1029.729, "robot_yield_detours": 4, "register_crowd_max": 10, "register_crowd_mean": 2.5949, "register_pay_count": 78, "register_pay_not_at_back": 0, "register_pay_off_spot": 8, "register_pay_offset_mean_m": 0.0207, "register_pay_offset_max_m": 0.289, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 37, "drink_bar_gave_up": 7, "drink_bar_wait_mean": 0.6458, "drink_bar_wait_p90": 1.003, "gave_up": 123, "warped": 57, "table_freed": 43, "people_jam_total_s": 4807.236, "walkers_mean": 9.5047, "measured_minutes": 195.3863},
  "site_metrics": {"entry_wait_mean": 4.2537, "full_wait_mean": 0.0376, "staff_wait_mean": 3.0124, "blocked_wait_mean": 1.6735, "guide_wait_mean": 1.3389, "seat_wait_mean": 1.711, "dish_wait_mean": 3.7397, "dish_wait_p90": 10.3976, "cold_share": 0.4527, "turn_mean": 7.252, "walk_km_per_staff": 2.7476, "staff_util": 0.7874, "robot_util": 0.5667, "robot_share": 0.3483, "rescues": 64, "pauses": 307, "groups": 81},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 195.3863, "everyone_left": true, "aisle_deferrals": 19, "rescues_done": 58, "rescue_wait_s": 2562.661, "gave_up": 123, "warped": 57, "table_freed": 43},
"site_result": {"dish_wait_mean": 0.4568, "dish_wait_p90": 0.8167, "cold_share": 0, "seat_wait_mean": 0.6083, "turn_mean": 4.3928, "walk_km_per_staff": 1.872, "staff_util": 0.6436, "robot_util": 0.4764, "robot_share": 0.7257, "robot_bus_share": 0, "collects": 0, "rescues": 1.475, "pauses": 41.625, "fragile_robot": 31.9, "groups": 82.1, "entry_wait_mean": 1.0194, "blocked_wait_mean": 0.5116, "guide_wait_mean": 0.2337, "staff_wait_mean": 0.7453, "full_wait_mean": 0.0967},20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 13:24:58",
  "condition_id": "fam_p1_s4_r2_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 46,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "sim_seconds": 11723.18,
  "wall_seconds": 795.8144,
  "speedup": 14.7311,
  "frame_delta_s": {"count": 235006, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 235006, "mean": 0.0142, "min": 0, "p50": 0, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 235006, "mean": 0.0598, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 22.1732},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 68979,
  "people_frames_over_005m_ratio": 0.2935,
  "chair_pulls": 167,
  "chair_pulls_by_reason": {"座る": 19, "食事中": 38, "ドリンクバー": 42, "戻って座る": 29, "トイレ": 1, "会計": 19, "退店": 19}
}
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,0,1,1,34,9.5125,21.2,3.8,3,0.95;1.2;1.65,0,0,0,1,0.1969,0,34,0,,,0,0.5467,0,0,0,0,3,0,3.8
fam_p1_s4_r2_a42,1.2,normal,2,0,1,2,10,21.7876,600.027,560.6866,6,0.95;0.95;2.75;48.0496;3.2;56.5994,1,1,0,1,0.0074,1,10,1,1413.373,1459.668,0,0.5538,5,148.0044,0,0,11,0,412.7458
fam_p1_s4_r2_a42,1.2,normal,2,0,1,3,37,11.1625,26.2999,5.05,5,0.95;1.55;1.1;0.95;0.5,0,0,0,1,0.196,0,37,1,2185.427,2811.187,0,0.5253,0,0,0,0,5,0,5.05
fam_p1_s4_r2_a42,1.2,normal,2,0,2,4,12,25.8027,600.027,553.3384,8,0.95;17.05;17.65;2.75;1.6;51.5495;32.6998;0.9,1,1,0,1,0.1722,1,12,0,,,0,0.5527,3,248.1105,0,0,11,0,305.2974
fam_p1_s4_r2_a42,1.2,normal,2,0,1,5,6,34.9352,325.794,265.2088,5,0.95;8.65;55.9994;1.25;1.7,1,0,0,1,-0.1086,0,6,1,2706.685,2894.518,0,0.5766,2,76.5501,0,0,7,0,188.6482
fam_p1_s4_r2_a42,1.2,normal,2,0,2,6,16,43.0449,244.4603,164.7054,15,0.95;5.35;2.6;2.45;3.4;2.8;1.85;20.45;2.85;3.2;3.2;3.55;2.8;2.05;2.35,1,0,0,1,-0.1078,1,16,1,2228.619,2983.305,0,0.5397,1,44.7996,0,0,16,0,119.8993
fam_p1_s4_r2_a42,1.2,normal,2,0,2,7,41,28.1276,471.3084,415.922,16,0.95;13.75;0.7;0.95;0.45;2.6;2.8;2.8;2.8;2.8;2.65;2.8;3.7;1.15;1.2;1.5,1,0,0,1,-0.2454,1,41,1,2963.436,3253.068,0,0.5078,4,132.1535,0,0,20,0,283.797520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,0,1,1,1413.2,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,1418.55,15.4629,5.0228,,0,スタッフとすれ違った,Staff03,0,1.2,自分で動き出した,275,275,275,0.25,0,0,0.95,0,15.538;5.965,15.238;2.188,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,1420.4,15.4532,4.9007,,0,お客さんとすれ違った,Guest(Clone),0,1.65,自分で動き出した,275,275,275,0.7,0,0,0.95,0,15.538;5.965,15.238;2.188,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2184.5,16.8535,5.8276,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.854;5.828,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2190.7,14.2103,5.2374,,0,スタッフとすれ違った,Staff02,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,15.523;5.932,12.463;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2203.8,7.455,4.3364,,0,お客さんとすれ違った,Guest(Clone),0,2.75,自分で動き出した,228.6659,21.3692,21.3692,1.5,0,0,1.25,0,12.659;4.416,5.863;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2244.8,7.305,4.4676,,0,スタッフとすれ違った,Staff03,0,48.0496,経路を引き直した,275,241.8792,241.8792,47.0996,0,0,0.95,4,7.305;4.468,12.463;4.312,PathComplete,2,0.02520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/dishes.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,0,7327.169,143,10,1,0,6678.214,648.9551,1,打ち切り
fam_p1_s4_r2_a42,0,8660.392,175,19,2,0,7873.626,786.7651,1,打ち切り
fam_p1_s4_r2_a42,0,8660.392,176,19,2,0,7890.61,769.7817,1,打ち切り
fam_p1_s4_r2_a42,0,8660.392,177,25,2,0,7976.523,683.8687,1,打ち切り
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,0,2090.934,客,ドリンクバー,8,1.912,10.513,2.2,8.3152,A01,60,移した
fam_p1_s4_r2_a42,0,2292.131,スタッフ,料理を運ぶ,12,5.613,10.513,8.0315,4.6,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2357.544,スタッフ,料理を運ぶ,12,5.613,10.513,12.3719,4.6,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2430.115,スタッフ,料理を運ぶ,14,5.613,6.812,6.3998,4.5186,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2459.694,スタッフ,料理を運ぶ,11,15.3,5.95,10.9928,4.5964,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2483.968,客,ドリンクバー,6,1.912,6.812,2.0064,5.7561,A01,60,移した
fam_p1_s4_r2_a42,0,2494.228,スタッフ,料理を運ぶ,14,5.613,6.812,12.3719,4.6,,60.0494,あきらめた20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.0727,3329.768,3329.793,3452.012,3452.012,1.0442,0,Done
fam_p1_s4_r2_a42,0,2,3,0,0,95.8213,95.8213,161.5753,2456.397,2456.441,2557.039,2557.039,1.0959,0,Done
fam_p1_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,171.2258,2846.665,2846.672,3093.312,3093.312,1.1367,0,Done
fam_p1_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,408.2438,3114.183,3114.183,3338.852,3338.852,1.2347,0,Done
fam_p1_s4_r2_a42,0,5,1,0,0,424.5898,424.5898,499.3716,2884.93,2884.959,3183.5,3183.5,1.2464,0,Done
fam_p1_s4_r2_a42,0,6,4,0,0,434.8373,434.8373,504.5703,3518.351,3518.377,3722.576,3722.576,1.1622,0,Done
fam_p1_s4_r2_a42,0,7,1,0,0,485.9749,485.9749,563.306,2684.71,2684.714,2850.475,2850.475,1.2889,0,Done20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,0,2455.24,12.1649,4.6,,,スタッフ:Staff04,0,1,9.9628
fam_p1_s4_r2_a42,0,2615.096,11.3094,3.9352,,,客:Guest(Clone),1,1,9.7615
fam_p1_s4_r2_a42,0,2817.693,14.7731,5.8025,,,スタッフ:Staff01,0,1,9.7175
fam_p1_s4_r2_a42,0,2914.988,9.1223,4.8295,A03,,客:Guest(Clone),0,1,9.0562
fam_p1_s4_r2_a42,0,2954.327,9.1235,4.8335,A03,,スタッフ:Staff01,0,1,9.4644
fam_p1_s4_r2_a42,0,3018.639,8.9945,4.8165,A03,,客:Guest(Clone),0,2,9.8292
fam_p1_s4_r2_a42,0,3041.862,8.9062,4.8314,A03,,スタッフ:Staff01,0,2,9.988720261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1311/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 13:24:59",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":29208},"summaryJson":{"instanceID":29202},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 13:00:00 JST(版 f282eaa6cb71)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},1536(cs:126・③・ロボット2台・店員優先):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 15:52:02",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.851, "dish_wait_p90": 10.3785, "cold_share": 0.441, "seat_wait_mean": 8.0638, "turn_mean": 7.3655, "robot_share": 0.3755, "robot_dishes": 86, "staff_dishes": 143, "requeued_dishes": 5, "groups": 91, "people_jams": 2172, "robot_blocked_jams": 2100, "robot_blocked_jam_share": 0.9669, "chair_pulls": 183, "robot_contacts": 94, "robot_yield_waits": 461, "robot_yield_wait_s": 1247.492, "robot_yield_detours": 8, "register_crowd_max": 11, "register_crowd_mean": 3.0586, "register_pay_count": 85, "register_pay_not_at_back": 0, "register_pay_off_spot": 18, "register_pay_offset_mean_m": 0.0511, "register_pay_offset_max_m": 0.2953, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 33, "drink_bar_gave_up": 4, "drink_bar_wait_mean": 0.5975, "drink_bar_wait_p90": 1.0017, "gave_up": 155, "warped": 71, "table_freed": 63, "people_jam_total_s": 5047.076, "walkers_mean": 11.6789, "measured_minutes": 194.7289},
  "site_metrics": {"entry_wait_mean": 10.8722, "full_wait_mean": 3.6106, "staff_wait_mean": 6.0375, "blocked_wait_mean": 4.4532, "guide_wait_mean": 1.5843, "seat_wait_mean": 8.0638, "dish_wait_mean": 3.851, "dish_wait_p90": 10.3785, "cold_share": 0.441, "turn_mean": 7.3655, "walk_km_per_staff": 2.7058, "staff_util": 0.8648, "robot_util": 0.6614, "robot_share": 0.3755, "rescues": 83, "pauses": 333, "groups": 91},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 194.7289, "everyone_left": true, "aisle_deferrals": 27, "staff_first_yield": true, "robot_stuck_detours": 241, "rescues_done": 77, "rescue_wait_s": 2871.66, "gave_up": 155, "warped": 71, "table_freed": 63},
"site_result": {"dish_wait_mean": 0.4568, "dish_wait_p90": 0.8167, "cold_share": 0, "seat_wait_mean": 0.6083, "turn_mean": 4.3928, "walk_km_per_staff": 1.872, "staff_util": 0.6436, "robot_util": 0.4764, "robot_share": 0.7257, "robot_bus_share": 0, "collects": 0, "rescues": 1.475, "pauses": 41.625, "fragile_robot": 31.9, "groups": 82.1, "entry_wait_mean": 1.0194, "blocked_wait_mean": 0.5116, "guide_wait_mean": 0.2337, "staff_wait_mean": 0.7453, "full_wait_mean": 0.0967},20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 15:52:02",
  "condition_id": "fam_p1_s4_r2_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 55,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "staff_first_yield": true,
  "sim_seconds": 11683.74,
  "wall_seconds": 943.983,
  "speedup": 12.3771,
  "frame_delta_s": {"count": 234214, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 234214, "mean": 0.0114, "min": 0, "p50": 0, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 234214, "mean": 0.0629, "min": 0, "p50": 0.0488, "p90": 0.05, "p99": 0.05, "max": 22.5693},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 66511,
  "people_frames_over_005m_ratio": 0.284,
  "chair_pulls": 183,
  "chair_pulls_by_reason": {"座る": 19, "食事中": 39, "ドリンクバー": 44, "戻って座る": 39, "トイレ": 7, "会計": 18, "退店": 17}
}
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,0,1,1,34,9.5125,21.25,3.75,3,0.95;1.25;1.55,0,0,0,1,0.2,0,34,0,,,0,0.5436,0,0,0,0,3,0,3.75
fam_p1_s4_r2_a42,1.2,normal,2,0,1,2,10,1.23,600.027,596.8278,2,0.95;0.6,1,1,0,1,-0.0967,0,10,1,1413.373,1459.719,0,0.3845,7,175.0061,0,0,9,0,421.8956
fam_p1_s4_r2_a42,1.2,normal,2,0,2,3,37,19.5,53.8995,17.55,7,0.95;2.6;2.8;2.8;2.8;2.8;2.8,0,0,0,1,0.1655,1,37,0,,,0,0.5365,0,0,0,0,7,0,17.55
fam_p1_s4_r2_a42,1.2,normal,2,0,2,4,6,36.9051,410.3233,345.989,7,0.95;3;10.45;2.8;8.05;44.5996;9.45,1,0,0,1,-0.2056,1,6,1,2706.735,2785.762,0,0.5736,3,86.5507,0,0,10,0,259.4478
fam_p1_s4_r2_a42,1.2,normal,2,0,1,5,10,37.8626,462.2107,395.9268,5,3.25;2.75;20.7;0.75;1.15,1,0,0,1,-0.08,1,10;15;17,1,2184.876,-1,1,0.5712,2,247.2605,0,0,7,0,148.6987
fam_p1_s4_r2_a42,1.2,normal,2,0,1,6,41,50.8645,129.7033,41.8997,5,0.95;0.5;2.2;13.15;25.0999,0,0,0,1,0.0305,0,41;12,3,2184.876;2678.758;2722.2,3323.487;3323.487;3323.487,0,0.5793,0,0,0,0,5,0,41.8999
fam_p1_s4_r2_a42,1.2,normal,2,0,1,7,23,29.7003,78.9002,27.1999,3,0.95;1.05;25.1999,0,0,0,1,0.1088,0,23;25;21,2,3276.141;3299.513,3503.462;3503.462,0,0.5745,0,0,0,0,3,0,27.199920261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,0,1,1,1413.2,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,1418.55,15.4629,5.0228,,0,スタッフとすれ違った,Staff03,0,1.25,自分で動き出した,275,275,275,0.3,0,0,0.95,0,15.538;5.965,15.238;2.188,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,1420.85,15.439,4.7213,,0,お客さんとすれ違った,Guest(Clone),0,1.55,自分で動き出した,275,275,275,0.6,0,0,0.95,0,15.538;5.965,15.238;2.188,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2183.95,16.8535,5.8276,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.854;5.828,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2186.6,16.1656,5.8818,,0,スタッフとすれ違った,Staff04,0,0.6,自分で動き出した,275,37.0131,37.0131,0,0,0,0.6,0,16.854;5.828,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2188.65,15.6273,5.9242,,0,スタッフとすれ違った,Staff02,0,60.0494,動けなくなった,275,32.7577,32.7577,60.0494,0,0,0,5,15.627;5.924,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,2,2279.8,15.6273,5.9242,,0,人が立ち止まっていた,Staff02,0,60.0494,動けなくなった,275,32.7577,32.7577,60.0494,0,0,0,5,15.627;5.924,15.3;5.95,PathComplete,2,0.02520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/dishes.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,0,2785.562,41,10,1,0,2184.876,600.686,1,打ち切り
fam_p1_s4_r2_a42,0,5948.028,117,12,1,0,5182.978,765.0498,1,打ち切り
fam_p1_s4_r2_a42,0,6570.188,136,8,2,0,5839.503,730.6846,1,打ち切り
fam_p1_s4_r2_a42,0,8015.47,166,19,1,0,7417.714,597.7559,1,打ち切り
fam_p1_s4_r2_a42,0,9093.892,197,25,1,0,8496.136,597.7559,1,打ち切り
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,0,2091.235,客,ドリンクバー,8,1.912,10.513,2.2,8.3054,A01,60,移した
fam_p1_s4_r2_a42,0,2233.123,スタッフ,料理を運ぶ,12,15.3,5.95,14.9304,6.1665,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2260.3,スタッフ,料理を運ぶ,34,15.3,5.95,15.1656,5.3482,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2261.15,スタッフ,料理を運ぶ,10,15.3,5.95,14.8888,5.861,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2293.282,スタッフ,呼び出し,40,21.362,2.188,14.9652,6.2491,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2320.458,スタッフ,料理を運ぶ,12,15.3,5.95,14.9615,5.6003,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,2321.309,スタッフ,料理を運ぶ,9,15.3,5.95,14.9304,6.1379,,60.0494,あきらめた20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,0,1,4,0,0,56.4194,56.4194,119.1727,3329.868,3329.893,3553.061,3553.061,1.0459,0,Done
fam_p1_s4_r2_a42,0,2,3,0,0,95.8213,95.8213,161.5753,2456.397,2456.441,2558.24,2558.24,1.0959,0,Done
fam_p1_s4_r2_a42,0,3,4,0,0,103.0217,103.0217,171.3759,2846.814,2846.822,3053.073,3053.073,1.1392,0,Done
fam_p1_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,408.2438,3114.232,3114.233,3366.529,3366.529,1.2347,0,Done
fam_p1_s4_r2_a42,0,5,1,0,0,424.5898,424.5898,499.4216,2884.98,2885.009,3203.42,3203.42,1.2472,0,Done
fam_p1_s4_r2_a42,0,6,4,0,0,434.8373,434.8373,504.7703,3518.601,3518.627,3823.625,3823.625,1.1655,0,Done
fam_p1_s4_r2_a42,0,7,1,0,0,485.9749,485.9749,563.4059,2685.861,2685.865,2897.321,2897.321,1.2905,0,Done20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,0,2402.188,15.1864,6.25,,,スタッフ:Staff03,0,1,9.8225
fam_p1_s4_r2_a42,0,2546.829,15.3,5.95,,,スタッフ:Staff01,0,1,-12.1676
fam_p1_s4_r2_a42,0,2610.942,15.3,5.95,,,スタッフ:Staff04,0,1,-12.1676
fam_p1_s4_r2_a42,0,2749.177,15.3,5.95,,,スタッフ:Staff01,0,1,-12.1676
fam_p1_s4_r2_a42,0,2785.612,14.8527,5.9045,,,スタッフ:Staff04,0,1,-0.0352
fam_p1_s4_r2_a42,0,2808.584,5.7681,4.8865,A02,,客:Guest(Clone),0,1,9.0387
fam_p1_s4_r2_a42,0,2852.978,5.4525,4.7904,,,スタッフ:Staff03,0,1,9.478720261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_1536/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 15:52:02",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":29208},"summaryJson":{"instanceID":29202},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 13:00:00 JST(版 f282eaa6cb71)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},1941(cs:135・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 19:54:16",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 2.2392, "dish_wait_p90": 5.0635, "cold_share": 0.1885, "seat_wait_mean": 0, "turn_mean": 4.8234, "robot_share": 0.3246, "robot_dishes": 62, "staff_dishes": 129, "requeued_dishes": 5, "groups": 73, "people_jams": 382, "robot_blocked_jams": 286, "robot_blocked_jam_share": 0.7487, "chair_pulls": 158, "robot_contacts": 27, "robot_yield_waits": 139, "robot_yield_wait_s": 951.8911, "robot_yield_detours": 2, "register_crowd_max": 9, "register_crowd_mean": 2.3443, "register_pay_count": 73, "register_pay_not_at_back": 0, "register_pay_off_spot": 6, "register_pay_offset_mean_m": 0.0171, "register_pay_offset_max_m": 0.2845, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 13, "drink_bar_gave_up": 4, "drink_bar_wait_mean": 0.5264, "drink_bar_wait_p90": 0.9419, "gave_up": 40, "warped": 46, "table_freed": 15, "people_jam_total_s": 978.5964, "walkers_mean": 8.3248, "measured_minutes": 182.4529},
  "site_metrics": {"entry_wait_mean": 1.806, "full_wait_mean": 0, "staff_wait_mean": 0.5941, "blocked_wait_mean": 0, "guide_wait_mean": 0.5941, "seat_wait_mean": 0, "dish_wait_mean": 2.2392, "dish_wait_p90": 5.0635, "cold_share": 0.1885, "turn_mean": 4.8234, "walk_km_per_staff": 2.9419, "staff_util": 0.7263, "robot_util": 0.3581, "robot_share": 0.3246, "rescues": 26, "pauses": 294, "groups": 73},
  "site_run": {"site_run": true, "condition_id": "fam_p5_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 182.4529, "everyone_left": true, "aisle_deferrals": 7, "staff_first_yield": false, "robot_stuck_detours": 0, "rescues_done": 25, "rescue_wait_s": 943.3589, "gave_up": 40, "warped": 46, "table_freed": 15},
"site_result": {"dish_wait_mean": 0.481, "dish_wait_p90": 0.8814, "cold_share": 0.0001, "seat_wait_mean": 0.9795, "turn_mean": 4.5091, "walk_km_per_staff": 1.9533, "staff_util": 0.6561, "robot_util": 0.4897, "robot_share": 0.7311, "robot_bus_share": 0, "collects": 0, "rescues": 1.425, "pauses": 40.525, "fragile_robot": 31.85, "groups": 82.925, "entry_wait_mean": 1.4157, "blocked_wait_mean": 0.842, "guide_wait_mean": 0.2535, "staff_wait_mean": 1.0954, "full_wait_mean": 0.1375},20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 19:54:16",
  "condition_id": "fam_p5_s4_r2_a42",
  "store_kind": "StoreLayout_p5_crammed",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 0.95,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 48,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "staff_first_yield": false,
  "sim_seconds": 10947.17,
  "wall_seconds": 752.5099,
  "speedup": 14.5476,
  "frame_delta_s": {"count": 219425, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 219425, "mean": 0.0203, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 219425, "mean": 0.0588, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.2371},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 66920,
  "people_frames_over_005m_ratio": 0.305,
  "chair_pulls": 158,
  "chair_pulls_by_reason": {"座る": 17, "食事中": 36, "ドリンクバー": 35, "戻って座る": 34, "トイレ": 3, "会計": 16, "退店": 17}
}
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r2_a42,0.95,normal,2,0,1,1,34,9.48,19.7,2.8,2,0.95;1.85,0,0,0,1,0.1664,0,34,0,,,0,0.5609,0,0,0,0,2,0,2.8
fam_p5_s4_r2_a42,0.95,normal,2,0,1,2,9,24.3602,45.3996,3.15,3,0.95;1.35;0.85,0,0,0,1,0.1672,0,9,1,1413.123,1457.917,0,0.5766,0,0,1,0,3,0,3.15
fam_p5_s4_r2_a42,0.95,normal,2,0,1,3,14,28.0227,89.2008,38.8497,7,0.95;1;1.05;1.85;1.35;31.3998;1.25,0,0,0,1,0.1566,0,14,1,2055.049,2125.568,0,0.5565,0,0,1,0,7,0,38.8498
fam_p5_s4_r2_a42,0.95,normal,2,0,1,4,19,21.1501,38.6497,2.3,2,0.95;1.35,0,0,0,1,0.1987,0,19,1,2577.359,2691.72,0,0.5819,0,0,1,0,2,0,2.3
fam_p5_s4_r2_a42,0.95,normal,2,0,2,5,39,18.4,33.3998,1.65,2,0.95;0.7,0,0,0,1,0.5618,0,39,0,,,0,0.5795,0,0,0,0,2,0,1.65
fam_p5_s4_r2_a42,0.95,normal,2,0,1,6,17,35.3702,60.4494,0.95,1,0.95,0,0,0,0,2.0739,0,17,1,3155.073,3218.835,0,0.5945,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,0,1,7,18,17.46,32.5998,2.4,2,0.95;1.45,0,0,0,1,0.3,0,18,1,3377.79,3463.373,0,0.5781,0,0,1,0,2,0,2.420261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r2_a42,0,1,1,1412.95,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,1,1418.95,15.4321,4.634,,0,スタッフとすれ違った,Staff03,0,1.85,自分で動き出した,275,275,275,0.9,0,0,0.95,0,15.538;5.965,15.238;2.188,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,2,2054.25,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,2,2073.35,6.5708,4.4259,,0,スタッフとすれ違った,Staff03,0,1.35,自分で動き出した,275,12.4094,12.4094,0.4,0,0,0.95,0,11.835;4.485,5.413;4.413,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,2,2076.8,5.6423,4.4221,,0,お客さんとすれ違った,Guest(Clone),0,0.85,自分で動き出した,275,16.7521,16.7521,0,0,0,0.85,0,5.656;4.416,5.238;4.612,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,3,2576.05,16.8497,5.8241,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.85;5.824,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,3,2583.6,13.3831,5.0844,,0,スタッフとすれ違った,Staff01,0,1,自分で動き出した,275,275,275,0.05,0,0,0.95,0,15.549;5.93,11.663;4.413,PathComplete,2,0.02520261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/dishes.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r2_a42,0,5039.441,86,6,1,0,4343.122,696.3193,1,打ち切り
fam_p5_s4_r2_a42,0,5039.441,88,4,1,0,4398.853,640.5879,1,打ち切り
fam_p5_s4_r2_a42,0,6715.12,122,6,2,1,6067.26,647.8594,1,打ち切り
fam_p5_s4_r2_a42,0,6715.12,124,7,2,0,6082.7,632.4199,1,打ち切り
fam_p5_s4_r2_a42,0,6721.943,125,40,1,1,6124.187,597.7559,1,打ち切り
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r2_a42,0,1476.185,客,ドリンクバー,4,1.763,10.312,1.8382,5.1076,A01,60,移した
fam_p5_s4_r2_a42,0,2103.647,客,ドリンクバー,7,1.763,8.662,1.9,8.2255,A01,60,移した
fam_p5_s4_r2_a42,0,2275.965,客,ドリンクバー,2,1.763,6.613,1.8222,5.6024,A01,60,移した
fam_p5_s4_r2_a42,0,2330.168,客,ドリンクバー,4,1.763,10.312,8.4708,4.4002,,60,移した
fam_p5_s4_r2_a42,0,2678.257,客,ドリンクバー,9,5.212,4.962,11.9191,4.6306,,60,移した
fam_p5_s4_r2_a42,0,2679.809,客,ドリンクバー,3,1.763,8.462,1.8612,6.1224,A01,60,移した
fam_p5_s4_r2_a42,0,2932.455,客,ドリンクバー,4,1.763,10.312,1.7704,9.7774,A01,60,移した20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.2227,3330.268,3330.293,3487.247,3487.247,1.0467,0,Done
fam_p5_s4_r2_a42,0,2,3,2,4,95.8213,95.8213,161.2752,2456.447,2456.491,2557.94,2557.94,1.0909,0,Done
fam_p5_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,171.1758,2847.964,2847.973,2982.654,2982.654,1.1359,0,Done
fam_p5_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,407.9939,3690.515,3690.545,3961.009,3961.009,1.2305,0,Done
fam_p5_s4_r2_a42,0,5,1,35,2,424.5898,424.5898,499.2216,2884.98,2885.009,3084.704,3084.704,1.2439,0,Done
fam_p5_s4_r2_a42,0,6,4,4,4,434.8373,434.8373,504.5203,3518.601,3518.627,3690.445,3690.445,1.1614,0,Done
fam_p5_s4_r2_a42,0,7,1,36,2,485.9749,485.9749,563.106,2685.761,2685.765,2786.963,2786.963,1.2855,0,Done20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r2_a42,0,3959.958,5.859,4.55,,,客:Guest(Clone),0,1,9.8342
fam_p5_s4_r2_a42,0,4176.375,5.2075,10.7203,A02,,客:Guest(Clone),0,1,-0.1692
fam_p5_s4_r2_a42,0,4389.988,3.8773,4.24,,,スタッフ:Staff01,1,1,9.7319
fam_p5_s4_r2_a42,0,5003.432,14.8122,5.7558,,,スタッフ:Staff01,0,2,7.5002
fam_p5_s4_r2_a42,0,5007.765,14.8221,5.6952,,,スタッフ:Staff02,0,2,9.1625
fam_p5_s4_r2_a42,0,5058.167,4.95,4.977,A02,,スタッフ:Staff02,0,1,9.9294
fam_p5_s4_r2_a42,0,5159.869,2.4138,4.55,,,スタッフ:Staff01,0,1,7.0909
fam_p5_s4_r2_a42,0,5175.258,2.3496,4.1329,,,スタッフ:Staff02,0,1,8.8964
fam_p5_s4_r2_a42,0,5209.823,13.9119,5.0887,,,スタッフ:Staff03,0,2,9.8141
fam_p5_s4_r2_a42,0,5470.152,12.2512,4.0393,,,客:Guest(Clone),1,1,9.6884
fam_p5_s4_r2_a42,0,6546.282,16.2604,2.867,,,スタッフ:Staff03,0,1,9.5827
fam_p5_s4_r2_a42,0,6585.876,16.4628,1.93,,,スタッフ:Staff02,0,1,9.0076
fam_p5_s4_r2_a42,0,6602.212,17.5594,2.1313,,,スタッフ:Staff02,1,2,9.1212
fam_p5_s4_r2_a42,0,6721.744,15.497,3.5901,,,客:Guest(Clone),1,2,9.0924
fam_p5_s4_r2_a42,0,6726.077,16.4873,3.6391,,,スタッフ:Staff03,0,2,9.5403
fam_p5_s4_r2_a42,0,6817.319,1.5242,8.9217,A01,,スタッフ:Staff02,0,2,9.2688
fam_p5_s4_r2_a42,0,6882.364,8.8104,4.5465,,,客:Guest(Clone),0,2,9.0841
fam_p5_s4_r2_a42,0,6965.836,5.8001,4.55,,,スタッフ:Staff03,0,1,9.8966
fam_p5_s4_r2_a42,0,7140.75,10.653,4.0835,,,スタッフ:Staff03,1,2,9.5588
fam_p5_s4_r2_a42,0,7578.932,14.6234,6.2483,,,スタッフ:Staff03,0,2,8.9881
fam_p5_s4_r2_a42,0,7874.174,1.7373,5.0264,A01,,客:Guest(Clone),0,1,-0.0566
fam_p5_s4_r2_a42,0,7937.277,16.9565,5.3056,,,スタッフ:Staff01,1,1,8.1607
fam_p5_s4_r2_a42,0,7949.778,9.2461,4.55,,,スタッフ:Staff03,0,2,9.7022
fam_p5_s4_r2_a42,0,8130.818,5.212,4.962,A02,,スタッフ:Staff01,0,2,9.7495
fam_p5_s4_r2_a42,0,8168.918,5.1233,5.1688,A02,,客:Guest(Clone),0,2,-0.157
fam_p5_s4_r2_a42,0,8197.009,17.0374,5.317,,,客:Guest(Clone),1,1,9.2226
fam_p5_s4_r2_a42,0,8389.753,13.7428,7.2762,,,スタッフ:Staff02,0,1,9.965
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_1941/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 19:54:17",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},2227(cs:138・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 22:39:47",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 5.2073, "dish_wait_p90": 9.8408, "cold_share": 0.7733, "seat_wait_mean": 8.6653, "turn_mean": 8.7138, "robot_share": 0.7511, "robot_dishes": 169, "staff_dishes": 56, "requeued_dishes": 3, "late_staff_dishes": 56, "late_staff_share": 0.2489, "robot_first_wait_s": 120, "yields": 13569, "yields_by_robot": 136, "yields_by_staff": 13173, "yields_by_guest": 260, "yields_stepped_aside": 9784, "yields_in_corner": 1997, "yields_passed": 963, "yield_wait_s": 21526.62, "yield_wait_mean_s": 1.5865, "corner_stops": 45, "corner_stop_s": 261.5986, "corner_stop_count_share": 0.0893, "corner_stop_time_share": 0.0417, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 88, "people_jams": 640, "robot_blocked_jams": 606, "robot_blocked_jam_share": 0.9469, "chair_pulls": 164, "robot_contacts": 165, "robot_yield_waits": 13450, "robot_yield_wait_s": 20355.23, "robot_yield_detours": 9, "register_crowd_max": 10, "register_crowd_mean": 2.6837, "register_pay_count": 84, "register_pay_not_at_back": 7, "register_pay_off_spot": 28, "register_pay_offset_mean_m": 0.7602, "register_pay_offset_max_m": 12.5246, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 37, "drink_bar_gave_up": 8, "drink_bar_wait_mean": 0.6642, "drink_bar_wait_p90": 1.003, "gave_up": 199, "warped": 87, "table_freed": 77, "people_jam_total_s": 728.6966, "walkers_mean": 11.1097, "measured_minutes": 206.8589},
  "site_metrics": {"entry_wait_mean": 11.443, "full_wait_mean": 4.1932, "staff_wait_mean": 5.8542, "blocked_wait_mean": 4.472, "guide_wait_mean": 1.3822, "seat_wait_mean": 8.6653, "dish_wait_mean": 5.2073, "dish_wait_p90": 9.8408, "cold_share": 0.7733, "turn_mean": 8.7138, "walk_km_per_staff": 2.1693, "staff_util": 0.8687, "robot_util": 0.6852, "robot_share": 0.7511, "rescues": 46, "pauses": 458, "groups": 88},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 206.8589, "everyone_left": true, "aisle_deferrals": 50, "staff_first_yield": true, "robot_stuck_detours": 12117, "rescues_done": 43, "rescue_wait_s": 1491.758, "gave_up": 199, "warped": 87, "table_freed": 77},
"site_result": {"dish_wait_mean": 1.0102, "dish_wait_p90": 2.0803, "cold_share": 0.014, "seat_wait_mean": 0.4546, "turn_mean": 3.5399, "walk_km_per_staff": 1.6027, "staff_util": 0.6158, "robot_util": 0.6013, "robot_share": 0.9914, "robot_bus_share": 0, "collects": 0, "rescues": 1.6, "pauses": 44.2, "fragile_robot": 41.9, "groups": 83.275, "entry_wait_mean": 0.8336, "blocked_wait_mean": 0.3575, "guide_wait_mean": 0.2015, "staff_wait_mean": 0.559, "full_wait_mean": 0.0971},20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 22:39:47",
  "condition_id": "fam_p1_s4_r2_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 92,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "staff_first_yield": true,
  "sim_seconds": 12411.53,
  "wall_seconds": 744.2545,
  "speedup": 16.6765,
  "frame_delta_s": {"count": 248827, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 248827, "mean": 0.0183, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 248827, "mean": 0.0556, "min": 0, "p50": 0.04, "p90": 0.05, "p99": 0.05, "max": 21.7245},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 49816,
  "people_frames_over_005m_ratio": 0.2002,
  "chair_pulls": 164,
  "chair_pulls_by_reason": {"座る": 17, "食事中": 38, "ドリンクバー": 39, "戻って座る": 32, "トイレ": 4, "会計": 17, "退店": 17}
}
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,0,1,1,3,38.3101,77.2001,12.25,2,7.4;4.85,0,0,0,1,0.35,1,3,0,,,0,0.5898,0,0,0,0,2,0,12.25
fam_p1_s4_r2_a42,1.2,normal,2,0,2,2,2,37.1251,146.5543,82.2004,4,0.95;2.7;2.5;0.95,1,0,0,1,0.0017,1,2;1,0,,,0,0.5769,1,15.05,0,0,5,0,67.1494
fam_p1_s4_r2_a42,1.2,normal,2,0,1,3,1,30.9003,72.8499,19.15,4,0.95;4.4;0.65;13.15,0,0,0,1,0.332,1,1,1,535.8627,638.0877,0,0.5754,0,0,0,0,4,0,19.15
fam_p1_s4_r2_a42,1.2,normal,2,0,1,4,34,9.45,50.6995,33.2998,3,3.8;1.35;28.1499,0,0,0,1,-0.007,0,34,1,706.9209,804.797,0,0.5431,0,0,0,0,3,0,33.2999
fam_p1_s4_r2_a42,1.2,normal,2,0,2,5,3,39.66,240.4101,172.6559,3,1.85;17.4;12.95,1,0,0,1,0,1,3,2,569.4045;551.059,803.2474;803.2474,0,0.5854,1,80.4003,0,0,4,0,92.2494
fam_p1_s4_r2_a42,1.2,normal,2,0,1,6,35,9.42,48.6995,30.7998,4,0.95;27.8499;1.05;0.95,0,0,0,1,0.1325,1,35,1,921.1186,996.8501,0,0.5263,0,0,0,0,4,0,30.7999
fam_p1_s4_r2_a42,1.2,normal,2,0,2,7,36,47.1472,88.0508,7.2,4,0.95;3.05;2.65;0.55,0,0,0,1,0.0638,1,36;4,1,715.9187,1068.687,0,0.5831,0,0,0,0,4,0,7.220261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,0,1,1,535.95,16.9,6.05,,0,分からない,,0,7.4,自分で動き出した,275,275,275,6.15,0,0,1.25,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,620.45,10.0485,4.362,,0,もう1台のロボット,ServingRobot02,0,4.85,自分で動き出した,18.8092,231.2592,18.8092,3.9,0,0,0.95,0,2.055;4.533,12.388;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,606.75,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,620.45,10.7707,4.39,,0,もう1台のロボット,ServingRobot01,0,2.7,自分で動き出した,234.0106,16.0017,16.0017,1.75,0,0,0.95,0,10.771;4.39,10.771;3.462,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,714.4,12.9453,4.4651,,0,もう1台のロボット,ServingRobot01,0,2.5,自分で動き出した,275,275,275,1.55,0,0,0.95,0,12.945;4.465,13.316;3.823,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,720.35,14.413,4.2838,,0,人が立ち止まっていた,Staff02,0,60.0494,動けなくなった,275,271.2823,271.2823,59.9994,0,0,0.05,5,14.413;4.284,17.7;4.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,795.45,14.413,4.2838,,0,スタッフとすれ違った,Staff02,0,0.95,自分で動き出した,275,271.2823,271.2823,0,0,0,0.95,0,14.413;4.284,17.7;4.95,PathComplete,2,0.02520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r2_a42,0,1,3,3,0,535.8627,535.9127,638.0877,ロボット,0.05,102.175,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,3,2,2,0,569.4045,606.6954,803.2474,ロボット,37.2909,196.552,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,2,1,1,0,551.059,606.6954,803.2474,ロボット,55.6364,196.552,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,4,1,1,0,706.9209,706.9709,804.797,ロボット,0.05,97.8261,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,7,34,4,0,921.1186,921.1686,996.8501,ロボット,0.05,75.6815,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,6,2,2,0,860.2335,980.2542,1068.237,スタッフ,120.0207,87.9824,0,0,0,1,1,1
fam_p1_s4_r2_a42,0,5,3,3,0,715.9187,803.2974,1068.687,ロボット,87.3787,265.3896,0,0,0,1,0,020261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r2_a42,0,0.02,スタッフ:Staff01,1,ロボット1号機,15.2028,5.3034,,,0,30.0498,1,0
fam_p1_s4_r2_a42,0,0.02,スタッフ:Staff02,1,ロボット1号機,15.3505,5.5063,,,0,30.0498,1,0
fam_p1_s4_r2_a42,0,0.02,スタッフ:Staff04,1,ロボット1号機,15.5939,5.7531,,,0,30.0498,1,0
fam_p1_s4_r2_a42,0,30.1198,スタッフ:Staff01,1,ロボット1号機,15.9748,5.0506,,,0,27.8499,1,1
fam_p1_s4_r2_a42,0,30.1198,スタッフ:Staff02,1,ロボット1号機,16.0389,5.446,,,0,30.0498,1,0
fam_p1_s4_r2_a42,0,30.1198,スタッフ:Staff04,1,ロボット1号機,15.9846,5.8423,,,0,30.0498,1,0
fam_p1_s4_r2_a42,0,60.2194,スタッフ:Staff02,1,ロボット1号機,16.0342,5.4478,,,0,30.0498,1,020261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,0,2007.453,17,38,1,0,1406.767,600.686,1,打ち切り
fam_p1_s4_r2_a42,0,4973.201,97,15,1,1,4375.445,597.7559,1,打ち切り
fam_p1_s4_r2_a42,0,7044.03,143,8,1,0,6392.734,651.2959,1,打ち切り
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,0,796.649,スタッフ,案内,38,19.162,2.188,12.5428,3.6181,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,815.9443,スタッフ,案内,40,0.9,2.1,14.6509,5.624,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,923.368,スタッフ,立ち往生を動かす,0,16.8756,6.0142,16.0695,5.9909,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1237.402,スタッフ,案内,8,0.9,2.1,2.4942,4.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1248.663,客,ドリンクバー,1,1.912,4.762,5.3624,4.6208,,60,移した
fam_p1_s4_r2_a42,0,1249.163,スタッフ,案内,9,0.9,2.1,3.1852,3.5148,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1266.38,客,ドリンクバー,3,1.912,8.462,4.4869,4.326,,60,移した20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,0,1,4,0,0,56.4194,56.4194,118.3726,2483.966,2483.968,2676.155,2676.155,1.0326,0,Done
fam_p1_s4_r2_a42,0,2,3,0,0,95.8213,95.8213,163.1754,3368.463,3368.481,3803.255,3803.255,1.1226,0,Done
fam_p1_s4_r2_a42,0,3,4,0,0,103.0217,103.0217,171.1758,3024.138,3101.27,3370.282,3370.282,1.1359,0,Done
fam_p1_s4_r2_a42,0,4,2,0,0,334.1619,334.1619,408.2938,3492.067,3826.027,4073.819,4073.819,1.2355,0,Done
fam_p1_s4_r2_a42,0,5,1,0,0,424.5898,424.5898,499.5215,3977.375,3977.375,4163.675,4163.675,1.2489,0,Done
fam_p1_s4_r2_a42,0,6,4,0,0,434.8373,434.8373,504.9202,3493.491,3668.674,3893.443,3893.443,1.168,0,Done
fam_p1_s4_r2_a42,0,7,1,36,2,485.9749,485.9749,569.8044,3356.911,3356.919,3713.067,3713.067,1.3972,0,Done20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,0,747.311,14.1882,3.7836,,,スタッフ:Staff01,0,2,9.8348
fam_p1_s4_r2_a42,0,763.2072,14.1566,4.7604,,,スタッフ:Staff01,0,2,9.1188
fam_p1_s4_r2_a42,0,909.1715,17.4382,5.3079,,,スタッフ:Staff03,0,2,9.4923
fam_p1_s4_r2_a42,0,927.3171,15.3785,5.5289,,,スタッフ:Staff02,1,1,8.3554
fam_p1_s4_r2_a42,0,946.8623,16.0459,5.6047,,,スタッフ:Staff02,0,1,9.7739
fam_p1_s4_r2_a42,0,1196.662,12.5429,3.7527,,,スタッフ:Staff02,0,2,9.6869
fam_p1_s4_r2_a42,0,1235.3,2.5658,4.55,,,スタッフ:Staff01,0,1,9.524420261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2227/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 22:39:48",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldApproachM":1.5,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},2253(cs:139・③・ロボット2台):20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 23:06:27",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 4.5201, "dish_wait_p90": 8.0161, "cold_share": 0.6116, "seat_wait_mean": 5.1486, "turn_mean": 6.8019, "robot_share": 0.6786, "robot_dishes": 152, "staff_dishes": 72, "requeued_dishes": 5, "late_staff_dishes": 72, "late_staff_share": 0.3214, "robot_first_wait_s": 120, "yields": 1275, "yields_by_robot": 90, "yields_by_staff": 933, "yields_by_guest": 252, "yields_stepped_aside": 378, "yields_in_corner": 496, "yields_passed": 688, "yield_wait_s": 4416.298, "yield_wait_mean_s": 3.4638, "staff_yields": 933, "staff_yield_wait_s": 2545.745, "staff_yield_mean_s": 2.7286, "staff_yield_share_of_staff_time": 0.054, "staff_time_total_s": 47184.04, "corner_stops": 49, "corner_stop_s": 657.5948, "corner_stop_count_share": 0.1186, "corner_stop_time_share": 0.1224, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 90, "people_jams": 910, "robot_blocked_jams": 872, "robot_blocked_jam_share": 0.9582, "chair_pulls": 175, "robot_contacts": 105, "robot_yield_waits": 1182, "robot_yield_wait_s": 3181.779, "robot_yield_detours": 14, "register_crowd_max": 12, "register_crowd_mean": 2.6195, "register_pay_count": 87, "register_pay_not_at_back": 2, "register_pay_off_spot": 32, "register_pay_offset_mean_m": 0.2584, "register_pay_offset_max_m": 12.5246, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 35, "drink_bar_gave_up": 6, "drink_bar_wait_mean": 0.5136, "drink_bar_wait_p90": 0.9071, "gave_up": 109, "warped": 65, "table_freed": 44, "people_jam_total_s": 1827.444, "walkers_mean": 10.5814, "measured_minutes": 196.4538},
  "site_metrics": {"entry_wait_mean": 7.1148, "full_wait_mean": 1.1491, "staff_wait_mean": 4.7063, "blocked_wait_mean": 3.9995, "guide_wait_mean": 0.7068, "seat_wait_mean": 5.1486, "dish_wait_mean": 4.5201, "dish_wait_p90": 8.0161, "cold_share": 0.6116, "turn_mean": 6.8019, "walk_km_per_staff": 2.6768, "staff_util": 0.7867, "robot_util": 0.6794, "robot_share": 0.6786, "rescues": 54, "pauses": 359, "groups": 90},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 196.4538, "everyone_left": true, "aisle_deferrals": 40, "staff_first_yield": true, "robot_stuck_detours": 470, "rescues_done": 53, "rescue_wait_s": 2327.81, "gave_up": 109, "warped": 65, "table_freed": 44},
"site_result": {"dish_wait_mean": 1.0102, "dish_wait_p90": 2.0803, "cold_share": 0.014, "seat_wait_mean": 0.4546, "turn_mean": 3.5399, "walk_km_per_staff": 1.6027, "staff_util": 0.6158, "robot_util": 0.6013, "robot_share": 0.9914, "robot_bus_share": 0, "collects": 0, "rescues": 1.6, "pauses": 44.2, "fragile_robot": 41.9, "groups": 83.275, "entry_wait_mean": 0.8336, "blocked_wait_mean": 0.3575, "guide_wait_mean": 0.2015, "staff_wait_mean": 0.559, "full_wait_mean": 0.0971},20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 23:06:27",
  "condition_id": "fam_p1_s4_r2_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 92,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "staff_first_yield": true,
  "sim_seconds": 11787.23,
  "wall_seconds": 776.4467,
  "speedup": 15.181,
  "frame_delta_s": {"count": 236292, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 236292, "mean": 0.0178, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 236292, "mean": 0.0592, "min": 0, "p50": 0.0482, "p90": 0.05, "p99": 0.05, "max": 21.4251},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 61203,
  "people_frames_over_005m_ratio": 0.259,
  "chair_pulls": 175,
  "chair_pulls_by_reason": {"座る": 19, "食事中": 39, "ドリンクバー": 40, "戻って座る": 39, "会計": 17, "退店": 16, "トイレ": 5}
}
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,0,1,1,3,38.3101,71.5498,6.6,2,0.95;5.65,0,0,0,1,0.5307,1,3,0,,,0,0.5898,0,0,0,0,2,0,6.6
fam_p1_s4_r2_a42,1.2,normal,2,0,2,2,2,36.8251,67.1995,4.45,2,0.95;3.5,0,0,0,1,0.5393,1,2;1,0,,,0,0.5869,0,0,0,0,2,0,4.45
fam_p1_s4_r2_a42,1.2,normal,2,0,1,3,1,30.9003,58.9494,5.8,3,0.95;4.15;0.7,0,0,0,1,0.1318,1,1,1,536.9124,633.4888,0,0.5814,0,0,0,0,3,0,5.8
fam_p1_s4_r2_a42,1.2,normal,2,0,2,4,3,40.71,74.0999,4.6,3,0.95;2.65;1,0,0,0,1,0.4785,1,3,2,567.9048;552.5586,718.5181;718.5181,0,0.5858,0,0,0,0,3,0,4.6
fam_p1_s4_r2_a42,1.2,normal,2,0,1,5,2,34.5302,59.0494,0.95,1,0.95,0,0,0,0,0.9996,0,2,1,708.4205,792.4,0,0.5943,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,0,2,6,34,11.04,19.9,0.95,1,0.95,0,0,0,0,1.877,0,34,1,716.9684,834.2398,0,0.5826,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,0,1,7,35,9.42,17.2,0.95,1,0.95,0,0,0,0,1.9264,0,35,1,858.7338,942.8133,0,0.5797,0,0,0,0,1,0,0.9520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,0,1,1,537,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,615.05,10.0485,4.362,,0,もう1台のロボット,ServingRobot02,0,5.65,自分で動き出した,18.8092,231.2592,18.8092,4.7,0,0,0.95,0,2.055;4.533,12.388;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,601.35,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,615.05,10.7707,4.39,,0,もう1台のロボット,ServingRobot01,0,3.5,自分で動き出した,234.0106,16.0017,16.0017,2.4,0,0,1.1,0,10.771;4.39,10.771;3.462,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,708.55,16.8515,5.8239,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.824,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,761.85,2.6119,4.5162,,0,もう1台のロボット,ServingRobot02,0,4.15,自分で動き出した,3.3874,275,3.3874,3.2,0,0,0.95,0,2.064;4.528,12.463;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,784.05,13.0917,4.4954,,0,スタッフとすれ違った,Staff02,0,0.7,自分で動き出した,275,275,275,0,0,0,0.7,0,12.225;4.317,15.3;4.95,PathComplete,2,0.02520261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r2_a42,0,1,3,3,0,536.9124,536.9624,633.4888,ロボット,0.05,96.5264,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,3,2,2,0,567.9048,601.2967,718.5181,ロボット,33.3919,117.2214,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,2,1,1,0,552.5586,601.2967,718.5181,ロボット,48.7381,117.2214,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,4,1,1,0,708.4205,708.4705,792.4,ロボット,0.05,83.9295,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,5,3,3,0,716.9684,735.164,834.2398,ロボット,18.1956,99.0758,0,0,0,0,0,1
fam_p1_s4_r2_a42,0,6,2,2,0,858.7338,858.7838,942.8133,ロボット,0.05,84.0295,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,7,34,4,0,921.1186,921.1686,966.0576,ロボット,0.05,44.889,0,0,0,0,0,020261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r2_a42,0,614.0436,スタッフ:Staff02,1,ロボット1号機,12.3922,4.5382,,,1,1,1,1
fam_p1_s4_r2_a42,0,616.443,ロボット2号機,0,ロボット1号機,10.7707,4.39,,,1,5.4,1,1
fam_p1_s4_r2_a42,0,644.7361,スタッフ:Staff01,1,ロボット2号機,0.8,2.0335,,,0,47.6496,0,1
fam_p1_s4_r2_a42,0,712.1696,スタッフ:Staff01,1,ロボット1号機,12.8853,5.1837,,,1,4.25,1,1
fam_p1_s4_r2_a42,0,762.9072,ロボット2号機,0,ロボット1号機,3.157,4.32,,,0,5,1,1
fam_p1_s4_r2_a42,0,782.1525,スタッフ:Staff02,1,ロボット1号機,14.9,4.7708,,,0,1.85,1,1
fam_p1_s4_r2_a42,0,810.8955,スタッフ:Staff01,1,ロボット2号機,6.4605,3.6476,,,0,3.5,1,120261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,0,2017.513,19,5,1,0,1383.294,634.2188,1,打ち切り
fam_p1_s4_r2_a42,0,3552.56,61,20,2,0,2795.522,757.0386,1,打ち切り
fam_p1_s4_r2_a42,0,3552.56,62,25,2,0,2936.409,616.1511,1,打ち切り
fam_p1_s4_r2_a42,0,3552.56,63,22,2,0,2948.271,604.2896,1,打ち切り
fam_p1_s4_r2_a42,0,3580.037,65,4,1,1,2974.747,605.2905,1,打ち切り
20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,0,1508.316,客,ドリンクバー,4,1.912,10.312,12.6045,4.1042,,60,移した
fam_p1_s4_r2_a42,0,1639.544,スタッフ,立ち往生を動かす,0,17.0704,2.6103,16.5585,2.5873,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1699.703,スタッフ,立ち往生を動かす,0,16.999,2.4518,16.5404,2.4017,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1759.861,スタッフ,立ち往生を動かす,0,16.9695,2.3281,16.5801,2.1827,,60.0494,移した
fam_p1_s4_r2_a42,0,1785.586,スタッフ,料理を運ぶ,5,15.3,5.95,18.0948,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1845.745,スタッフ,料理を運ぶ,5,15.3,5.95,18.1461,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1895.093,スタッフ,立ち往生を動かす,0,17.0291,2.5302,16.5188,2.5365,,60.0494,あきらめた20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.8727,2471.569,2494.478,2590.171,2590.171,1.0576,0,Done
fam_p1_s4_r2_a42,0,2,3,0,0,95.8213,95.8213,161.6753,3625.609,3625.632,3933.332,3933.332,1.0976,0,Done
fam_p1_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,172.2259,3027.749,3027.798,3130.899,3130.899,1.1534,0,Done
fam_p1_s4_r2_a42,0,4,2,0,0,334.1619,334.1619,408.2938,3904.237,3904.253,4266.024,4266.024,1.2355,0,Done
fam_p1_s4_r2_a42,0,5,1,35,2,424.5898,424.5898,499.5215,3385.25,3601.458,3843.144,3843.144,1.2489,0,Done
fam_p1_s4_r2_a42,0,6,4,0,0,434.8373,434.8373,504.9202,3301.795,4134.191,4445.52,4445.52,1.168,0,Done
fam_p1_s4_r2_a42,0,7,1,36,2,485.9749,485.9749,563.6059,2724.849,2724.853,2854.479,2854.479,1.2939,0,Done20261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,0,977.7548,11.482,4.0613,,,スタッフ:Staff01,0,2,8.8155
fam_p1_s4_r2_a42,0,1759.861,16.9695,2.3281,,,スタッフ:Staff01,0,2,-13.0867
fam_p1_s4_r2_a42,0,1784.335,18.1811,2.55,,,スタッフ:Staff03,0,1,9.4571
fam_p1_s4_r2_a42,0,2015.361,17.0021,2.4609,,,スタッフ:Staff03,0,2,-20.5651
fam_p1_s4_r2_a42,0,2201.592,7.4425,4.0322,,,スタッフ:Staff01,0,1,9.3938
fam_p1_s4_r2_a42,0,2420.406,5.8,4.9958,A02,,スタッフ:Staff02,0,2,9.1715
fam_p1_s4_r2_a42,0,2507.09,11.5353,4.0039,,,スタッフ:Staff01,0,1,8.262320261023_p1_efficient_corner_fam_p1_s4_r2_a42_s0_2253/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 23:06:28",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},2309(cs:139・⑦・ロボット2台):20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 23:21:46",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.8707, "dish_wait_p90": 6.634, "cold_share": 0.5973, "seat_wait_mean": 2.2596, "turn_mean": 4.5899, "robot_share": 0.7014, "robot_dishes": 155, "staff_dishes": 66, "requeued_dishes": 4, "late_staff_dishes": 66, "late_staff_share": 0.2986, "robot_first_wait_s": 120, "yields": 2438, "yields_by_robot": 62, "yields_by_staff": 2239, "yields_by_guest": 137, "yields_stepped_aside": 298, "yields_in_corner": 89, "yields_passed": 532, "yield_wait_s": 4683.596, "yield_wait_mean_s": 1.9211, "staff_yields": 2239, "staff_yield_wait_s": 2819.901, "staff_yield_mean_s": 1.2594, "staff_yield_share_of_staff_time": 0.0656, "staff_time_total_s": 42987.54, "corner_stops": 53, "corner_stop_s": 1178.589, "corner_stop_count_share": 0.1485, "corner_stop_time_share": 0.3043, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 87, "people_jams": 521, "robot_blocked_jams": 465, "robot_blocked_jam_share": 0.8925, "chair_pulls": 159, "robot_contacts": 79, "robot_yield_waits": 2383, "robot_yield_wait_s": 3285.53, "robot_yield_detours": 7, "register_crowd_max": 10, "register_crowd_mean": 2.376, "register_pay_count": 73, "register_pay_not_at_back": 1, "register_pay_off_spot": 18, "register_pay_offset_mean_m": 0.1951, "register_pay_offset_max_m": 10.9333, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 33, "drink_bar_gave_up": 8, "drink_bar_wait_mean": 0.7699, "drink_bar_wait_p90": 1.003, "gave_up": 63, "warped": 54, "table_freed": 34, "people_jam_total_s": 874.2451, "walkers_mean": 9.6537, "measured_minutes": 178.979},
  "site_metrics": {"entry_wait_mean": 3.9928, "full_wait_mean": 0.8286, "staff_wait_mean": 1.9111, "blocked_wait_mean": 1.431, "guide_wait_mean": 0.4801, "seat_wait_mean": 2.2596, "dish_wait_mean": 3.8707, "dish_wait_p90": 6.634, "cold_share": 0.5973, "turn_mean": 4.5899, "walk_km_per_staff": 2.7563, "staff_util": 0.7615, "robot_util": 0.6403, "robot_share": 0.7014, "rescues": 40, "pauses": 317, "groups": 87},
  "site_run": {"site_run": true, "condition_id": "fam_p5_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 178.979, "everyone_left": true, "aisle_deferrals": 28, "staff_first_yield": true, "robot_stuck_detours": 1796, "rescues_done": 39, "rescue_wait_s": 1440.105, "gave_up": 63, "warped": 54, "table_freed": 34},
"site_result": {"dish_wait_mean": 1.0497, "dish_wait_p90": 2.1196, "cold_share": 0.0157, "seat_wait_mean": 1.191, "turn_mean": 3.9675, "walk_km_per_staff": 1.6822, "staff_util": 0.6219, "robot_util": 0.6062, "robot_share": 0.9898, "robot_bus_share": 0, "collects": 0, "rescues": 1.575, "pauses": 43.25, "fragile_robot": 42.05, "groups": 84.4, "entry_wait_mean": 1.5915, "blocked_wait_mean": 0.7992, "guide_wait_mean": 0.2173, "staff_wait_mean": 1.0166, "full_wait_mean": 0.3917},20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/run_info.json
{
  "run_label": "site_v5",
  "written_at": "2026-10-23 23:21:46",
  "condition_id": "fam_p5_s4_r2_a42",
  "store_kind": "StoreLayout_p5_crammed",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 0.95,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 2,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 97,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "staff_first_yield": true,
  "sim_seconds": 10738.74,
  "wall_seconds": 762.8122,
  "speedup": 14.0778,
  "frame_delta_s": {"count": 215240, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 215240, "mean": 0.0191, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 215240, "mean": 0.0611, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.5693},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 62602,
  "people_frames_over_005m_ratio": 0.2908,
  "chair_pulls": 159,
  "chair_pulls_by_reason": {"座る": 19, "食事中": 40, "ドリンクバー": 35, "戻って座る": 25, "トイレ": 7, "会計": 17, "退店": 16}
}
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r2_a42,0.95,normal,2,0,1,1,3,38.3101,72.3498,7.4,2,0.95;6.45,0,0,0,1,0.3044,1,3,0,,,0,0.5898,0,0,1,0,2,0,7.4
fam_p5_s4_r2_a42,0.95,normal,2,0,2,2,2,36.8551,70.0497,6.7,3,0.95;4.25;1.5,0,0,0,1,0.2015,1,2;1,0,,,0,0.5818,0,0,1,0,3,0,6.7
fam_p5_s4_r2_a42,0.95,normal,2,0,1,3,1,30.9903,58.5994,5.85,2,0.95;4.9,0,0,0,1,0.3,1,1,1,535.8627,633.2389,0,0.5875,0,0,1,0,2,0,5.85
fam_p5_s4_r2_a42,0.95,normal,2,0,2,4,3,40.5,73.6999,4.55,3,0.95;2.7;0.9,0,0,0,1,0.1242,1,3,2,567.5049;551.9088,720.2676;720.2676,0,0.5857,0,0,1,0,3,0,4.55
fam_p5_s4_r2_a42,0.95,normal,2,0,1,5,2,34.5602,59.0994,0.95,1,0.95,0,0,0,0,0.3665,0,2,1,707.7707,791.4003,0,0.5943,0,0,1,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,0,2,6,34,11.04,19.9,0.95,1,0.95,0,0,0,0,1.8748,0,34,1,715.9187,858.3839,0,0.5826,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,0,1,7,35,9.42,17.2,0.95,1,0.95,0,0,0,0,1.8655,0,35,1,858.3339,942.4634,0,0.5797,0,0,0,0,1,0,0.9520261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r2_a42,0,1,1,535.95,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,1,613.9,9.9748,4.4422,,0,もう1台のロボット,ServingRobot02,0,6.45,自分で動き出した,10.7894,239.2553,10.7894,5.5,0,0,0.95,0,1.869;4.627,11.663;4.413,PathComplete,3,0.025
fam_p5_s4_r2_a42,0,2,2,600.25,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,2,2,613.9,10.6933,4.4889,,0,もう1台のロボット,ServingRobot01,0,4.25,自分で動き出した,243.8956,6.1157,6.1157,2.75,0,0,1.5,0,10.693;4.489,10.693;3.563,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,2,2,621.65,9.6325,3.8784,,0,人が立ち止まっていた,Staff02,0,1.5,自分で動き出した,183.6672,67.5228,67.5228,0.55,0,0,0.95,0,9.635;3.878,1.788;4.612,PathComplete,3,0.025
fam_p5_s4_r2_a42,0,1,3,707.9,16.8547,5.8278,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.828,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,3,773.5,9.8795,4.4437,,0,もう1台のロボット,ServingRobot02,0,4.9,自分で動き出した,10.6361,239.4083,10.6361,3.95,0,0,0.95,0,1.904;4.603,11.663;4.413,PathComplete,3,0.02520261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r2_a42,0,1,3,3,0,535.8627,535.9127,633.2389,ロボット,0.05,97.3262,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,3,2,2,0,567.5049,600.197,720.2676,ロボット,32.692,120.0707,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,2,1,1,0,551.9088,600.197,720.2676,ロボット,48.2882,120.0707,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,4,1,1,0,707.7707,707.8207,791.4003,ロボット,0.05,83.5796,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,5,3,3,0,715.9187,759.708,858.3839,ロボット,43.7893,98.6759,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,6,2,2,0,858.3339,858.3839,942.4634,ロボット,0.05,84.0795,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,7,34,4,0,920.8187,920.8687,965.7577,ロボット,0.05,44.889,0,0,0,0,0,020261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r2_a42,0,613.4937,スタッフ:Staff02,1,ロボット1号機,12.1911,5.1843,,,1,0.4,1,1
fam_p5_s4_r2_a42,0,615.2933,ロボット2号機,0,ロボット1号機,10.6933,4.4889,,,1,6.25,1,1
fam_p5_s4_r2_a42,0,618.5425,スタッフ:Staff02,1,ロボット2号機,8.759,3.5983,,,0,3.1,1,1
fam_p5_s4_r2_a42,0,623.1414,スタッフ:Staff02,1,ロボット2号機,7.5374,3.5214,,,0,3.6,1,1
fam_p5_s4_r2_a42,0,644.4362,スタッフ:Staff01,1,ロボット2号機,0.8,2.0331,,,0,49.3495,0,1
fam_p5_s4_r2_a42,0,700.4725,スタッフ:Staff04,1,ロボット2号機,9.1349,4.1216,,,0,4.45,1,1
fam_p5_s4_r2_a42,0,712.3196,スタッフ:Staff01,1,ロボット1号機,12.3279,5.2423,,,1,4.35,1,120261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r2_a42,0,1998.694,19,41,2,0,1340.152,658.5425,1,打ち切り
fam_p5_s4_r2_a42,0,1998.694,21,6,2,0,1386.998,611.6968,1,打ち切り
fam_p5_s4_r2_a42,0,1998.694,20,5,2,0,1383.644,615.05,1,打ち切り
fam_p5_s4_r2_a42,0,7435.793,175,18,2,0,6838.038,597.7559,1,打ち切り
20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r2_a42,0,1563.219,スタッフ,立ち往生を動かす,0,19.9019,2.2985,19.4771,2.3085,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1623.328,スタッフ,立ち往生を動かす,0,19.8977,2.2552,19.4932,2.1399,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1796.647,スタッフ,立ち往生を動かす,0,19.9213,2.4013,19.4999,2.4872,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1856.756,スタッフ,立ち往生を動かす,0,19.9008,2.2896,19.4946,2.1223,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1870.319,スタッフ,料理を運ぶ,39,20.263,2.188,20.1262,1.5678,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1937.935,スタッフ,料理を運ぶ,39,20.263,2.188,20.117,1.5674,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,2256.696,客,ドリンクバー,4,1.763,10.312,6.7865,4.0686,,60,移した20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.2227,2888.754,2888.763,3076.746,3076.746,1.0467,0,Done
fam_p5_s4_r2_a42,0,2,3,2,4,95.8213,95.8213,161.2752,2967.573,2967.59,3179.346,3179.346,1.0909,0,Done
fam_p5_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,171.1758,2427.404,2507.291,2670.199,2670.199,1.1359,0,Done
fam_p5_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,407.9939,3286.517,3341.104,3535.844,3535.844,1.2305,0,Done
fam_p5_s4_r2_a42,0,5,1,35,2,424.5898,424.5898,499.2216,3273.117,3332.145,3433.945,3433.945,1.2439,0,Done
fam_p5_s4_r2_a42,0,6,4,4,4,434.8373,434.8373,504.5203,2756.216,2872.847,2975.247,2975.247,1.1614,0,Done
fam_p5_s4_r2_a42,0,7,1,36,2,485.9749,485.9749,563.106,4083.59,4083.628,4398.206,4398.206,1.2855,0,Done20261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r2_a42,0,2010.806,19.5334,1.8518,,,スタッフ:Staff04,0,2,8.487
fam_p5_s4_r2_a42,0,2194.686,9.3256,4.0694,,,客:Guest(Clone),1,2,8.9271
fam_p5_s4_r2_a42,0,2264.704,5.7451,4.2318,,,スタッフ:Staff04,0,1,9.6095
fam_p5_s4_r2_a42,0,2327.015,5.7959,4.2789,,,スタッフ:Staff04,0,1,9.3921
fam_p5_s4_r2_a42,0,2328.316,6.6218,4.1369,,,スタッフ:Staff01,0,2,9.5175
fam_p5_s4_r2_a42,0,2347.435,5.3065,4.0827,,,スタッフ:Staff01,0,1,9.4838
fam_p5_s4_r2_a42,0,2363.851,4.8412,4.5594,,,スタッフ:Staff01,0,1,8.74320261023_p5_crammed_fam_p5_s4_r2_a42_s0_2309/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-23 23:21:47",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット0台・種0(cs:140):20261023_stageB_fam_p1_r0_s0
20261023_stageB_fam_p1_r0_s0/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:33:36",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 0.9608, "dish_wait_p90": 1.754, "cold_share": 0, "seat_wait_mean": 0.3244, "turn_mean": 6.0981, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 196, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 43210.55, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 81, "people_jams": 72, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 167, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 9, "register_crowd_mean": 2.2788, "register_pay_count": 79, "register_pay_not_at_back": 0, "register_pay_off_spot": 24, "register_pay_offset_mean_m": 0.0656, "register_pay_offset_max_m": 0.2957, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 30, "drink_bar_gave_up": 10, "drink_bar_wait_mean": 0.6527, "drink_bar_wait_p90": 0.9745, "gave_up": 10, "warped": 11, "table_freed": 22, "people_jam_total_s": 75.2, "walkers_mean": 8.5354, "measured_minutes": 179.9344},
  "site_metrics": {"entry_wait_mean": 1.9311, "full_wait_mean": 0, "staff_wait_mean": 0.7289, "blocked_wait_mean": 0.3244, "guide_wait_mean": 0.4045, "seat_wait_mean": 0.3244, "dish_wait_mean": 0.9608, "dish_wait_p90": 1.754, "cold_share": 0, "turn_mean": 6.0981, "walk_km_per_staff": 3.0918, "staff_util": 0.742, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 81},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 179.9344, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 10, "warped": 11, "table_freed": 22},
"site_result": {"dish_wait_mean": 0.653, "dish_wait_p90": 1.3663, "cold_share": 0.0004, "seat_wait_mean": 2.602, "turn_mean": 9.4605, "walk_km_per_staff": 2.7655, "staff_util": 0.7511, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 84.2, "entry_wait_mean": 3.1814, "blocked_wait_mean": 2.4548, "guide_wait_mean": 0.3997, "staff_wait_mean": 2.8545, "full_wait_mean": 0.1472},20261023_stageB_fam_p1_r0_s0/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 00:33:36",
  "condition_id": "fam_p1_s4_r0_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 0,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 0,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 10796.07,
  "wall_seconds": 694.309,
  "speedup": 15.5494,
  "frame_delta_s": {"count": 216391, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 216391, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
  "people_step_m": {"count": 216391, "mean": 0.0621, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 21.669},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 76381,
  "people_frames_over_005m_ratio": 0.353,
  "chair_pulls": 167,
  "chair_pulls_by_reason": {"座る": 18, "食事中": 38, "トイレ": 4, "ドリンクバー": 39, "戻って座る": 34, "会計": 16, "退店": 18}
}
20261023_stageB_fam_p1_r0_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p1_r0_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p1_r0_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r0_a42,0,1,3,3,0,536.9124,536.9124,567.205,スタッフ,0,30.2926,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,2,1,1,0,552.5586,552.5586,579.602,スタッフ,0,27.0434,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,3,2,2,0,567.9048,567.9048,597.1977,スタッフ,0,29.2929,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,4,1,1,0,708.4205,708.4205,736.1138,スタッフ,0,27.6932,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,5,3,3,0,716.9684,716.9684,750.6102,スタッフ,0,33.6418,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,6,2,2,0,858.7338,858.7338,887.7767,スタッフ,0,29.0429,0,0,1,0,0,0
fam_p1_s4_r0_a42,0,7,34,4,0,921.1186,921.1186,937.5146,スタッフ,0,16.396,0,0,1,0,0,020261023_stageB_fam_p1_r0_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p1_r0_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p1_r0_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r0_a42,0,1914.262,客,ドリンクバー,3,1.912,8.462,1.9849,6.769,A01,60,移した
fam_p1_s4_r0_a42,0,2089.783,客,ドリンクバー,8,1.912,10.513,2.2083,4.6917,A01,60,移した
fam_p1_s4_r0_a42,0,2330.568,客,ドリンクバー,4,1.912,10.312,1.925,9.8899,A01,60,移した
fam_p1_s4_r0_a42,0,2932.856,客,ドリンクバー,4,1.912,10.312,1.9606,8.6521,A01,60,移した
fam_p1_s4_r0_a42,0,3106.225,客,ドリンクバー,8,1.912,10.513,2.15,8.2416,A01,60,移した
fam_p1_s4_r0_a42,0,3185.602,客,ドリンクバー,8,1.912,10.513,1.9303,9.8449,A01,60,移した
fam_p1_s4_r0_a42,0,3374.737,客,ドリンクバー,7,18.8,3.9,1.912,8.662,A01,0,あきらめた20261023_stageB_fam_p1_r0_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r0_a42,0,1,4,1,4,56.4194,56.4194,119.8727,3330.868,3330.894,3433.244,3433.244,1.0576,0,Done
fam_p1_s4_r0_a42,0,2,3,2,4,95.8213,95.8213,161.6753,2456.797,2456.841,2570.452,2570.452,1.0976,0,Done
fam_p1_s4_r0_a42,0,3,4,3,4,103.0217,103.0217,172.2259,2847.964,2847.973,2950.623,2950.623,1.1534,0,Done
fam_p1_s4_r0_a42,0,4,2,34,2,334.1619,334.1619,408.2938,3433.448,3433.494,3626.683,3626.683,1.2355,0,Done
fam_p1_s4_r0_a42,0,5,1,35,2,424.5898,424.5898,499.5215,2885.23,2885.259,3053.724,3053.724,1.2489,0,Done
fam_p1_s4_r0_a42,0,6,4,4,4,434.8373,434.8373,504.9202,3519.001,3519.028,3807.059,3807.059,1.168,0,Done
fam_p1_s4_r0_a42,0,7,1,36,2,485.9749,485.9749,563.6059,2685.511,2685.514,2791.968,2791.968,1.2939,0,Done20261023_stageB_fam_p1_r0_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p1_r0_s0/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:33:36",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット0台・種1(cs:140):20261023_stageB_fam_p1_r0_s1
20261023_stageB_fam_p1_r0_s1/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:42:08",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 0.8046, "dish_wait_p90": 1.4218, "cold_share": 0, "seat_wait_mean": 0.7186, "turn_mean": 4.1832, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 200, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 41220.02, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 80, "people_jams": 21, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 156, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 9, "register_crowd_mean": 2.4119, "register_pay_count": 75, "register_pay_not_at_back": 0, "register_pay_off_spot": 13, "register_pay_offset_mean_m": 0.0368, "register_pay_offset_max_m": 0.2723, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 27, "drink_bar_gave_up": 9, "drink_bar_wait_mean": 0.7375, "drink_bar_wait_p90": 0.996, "gave_up": 9, "warped": 11, "table_freed": 22, "people_jam_total_s": 22.05, "walkers_mean": 8.9458, "measured_minutes": 171.637},
  "site_metrics": {"entry_wait_mean": 2.2816, "full_wait_mean": 0, "staff_wait_mean": 1.0721, "blocked_wait_mean": 0.7186, "guide_wait_mean": 0.3535, "seat_wait_mean": 0.7186, "dish_wait_mean": 0.8046, "dish_wait_p90": 1.4218, "cold_share": 0, "turn_mean": 4.1832, "walk_km_per_staff": 3.1089, "staff_util": 0.758, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 80},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 171.637, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 9, "warped": 11, "table_freed": 22},
"site_result": {"dish_wait_mean": 0.653, "dish_wait_p90": 1.3663, "cold_share": 0.0004, "seat_wait_mean": 2.602, "turn_mean": 9.4605, "walk_km_per_staff": 2.7655, "staff_util": 0.7511, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 84.2, "entry_wait_mean": 3.1814, "blocked_wait_mean": 2.4548, "guide_wait_mean": 0.3997, "staff_wait_mean": 2.8545, "full_wait_mean": 0.1472},20261023_stageB_fam_p1_r0_s1/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 00:42:08",
  "condition_id": "fam_p1_s4_r0_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 0,
  "seed": 1,
  "trips_requested": 0,
  "trips_done": 0,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 10298.22,
  "wall_seconds": 507.5364,
  "speedup": 20.2906,
  "frame_delta_s": {"count": 206395, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 206395, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
  "people_step_m": {"count": 206395, "mean": 0.0632, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 21.5713},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 76847,
  "people_frames_over_005m_ratio": 0.3723,
  "chair_pulls": 156,
  "chair_pulls_by_reason": {"座る": 18, "食事中": 24, "ドリンクバー": 41, "トイレ": 6, "戻って座る": 39, "会計": 14, "退店": 14}
}
20261023_stageB_fam_p1_r0_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p1_r0_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p1_r0_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r0_a42,1,1,34,1,0,571.9539,571.9539,588.3499,スタッフ,0,16.396,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,2,35,2,0,806.0467,806.0467,823.4924,スタッフ,0,17.4457,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,3,36,3,0,860.5334,860.5334,877.6292,スタッフ,0,17.0958,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,4,35,2,0,878.2291,878.2291,895.7748,スタッフ,0,17.5457,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,6,37,5,0,940.014,940.014,959.3093,スタッフ,0,19.2953,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,5,1,4,0,938.5643,938.5643,969.6567,スタッフ,0,31.0924,0,0,1,0,0,0
fam_p1_s4_r0_a42,1,7,36,3,0,991.3015,991.3015,1007.797,スタッフ,0,16.496,0,0,1,0,0,020261023_stageB_fam_p1_r0_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p1_r0_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p1_r0_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r0_a42,1,2525.809,客,ドリンクバー,4,1.912,10.312,2.0363,8.635,A01,60,移した
fam_p1_s4_r0_a42,1,2661.191,客,トイレ,38,19.162,2.188,18.834,2.2238,,60,移した
fam_p1_s4_r0_a42,1,3059.88,客,ドリンクバー,2,18.8,3.9,1.912,6.613,A01,0,あきらめた
fam_p1_s4_r0_a42,1,3306.72,客,ドリンクバー,4,18.8,3.9,1.912,10.312,A01,0,あきらめた
fam_p1_s4_r0_a42,1,3322.085,客,ドリンクバー,12,18.8,3.9,5.613,10.513,A02,0,あきらめた
fam_p1_s4_r0_a42,1,3418.88,客,ドリンクバー,11,18.8,3.9,5.613,8.662,A02,0,あきらめた
fam_p1_s4_r0_a42,1,3438.049,客,ドリンクバー,18,18.8,3.9,9.312,4.962,A03,0,あきらめた20261023_stageB_fam_p1_r0_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r0_a42,1,1,1,34,2,43.2696,43.2696,117.2726,2529.06,2529.062,2637.117,2637.117,1.2334,0,Done
fam_p1_s4_r0_a42,1,2,2,35,2,175.5261,175.5261,250.9807,2734.01,2734.012,2853.328,2853.328,1.2576,0,Done
fam_p1_s4_r0_a42,1,3,2,36,2,194.3773,194.3773,271.4272,3229.127,3229.145,3334.448,3334.448,1.2842,0,Done
fam_p1_s4_r0_a42,1,4,3,1,4,396.7966,396.7966,460.781,3440.945,3489.399,3617.824,3617.824,1.0664,0,Done
fam_p1_s4_r0_a42,1,5,1,37,2,437.2867,437.2867,519.0668,3360.211,3360.223,3514.823,3514.823,1.363,0,Done
fam_p1_s4_r0_a42,1,6,4,2,4,704.7714,704.7714,769.2057,3769.007,3769.021,4007.905,4007.905,1.0739,0,Done
fam_p1_s4_r0_a42,1,7,2,38,2,724.3167,724.3167,806.2466,3770.057,3770.073,4103.461,4103.461,1.3655,0,Done20261023_stageB_fam_p1_r0_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p1_r0_s1/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:42:08",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット0台・種2(cs:140):20261023_stageB_fam_p1_r0_s2
20261023_stageB_fam_p1_r0_s2/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:51:31",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 0.913, "dish_wait_p90": 1.6519, "cold_share": 0, "seat_wait_mean": 2.3212, "turn_mean": 4.7928, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 214, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 43677, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 86, "people_jams": 48, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 192, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 9, "register_crowd_mean": 2.5443, "register_pay_count": 83, "register_pay_not_at_back": 0, "register_pay_off_spot": 17, "register_pay_offset_mean_m": 0.0439, "register_pay_offset_max_m": 0.2975, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 33, "drink_bar_gave_up": 7, "drink_bar_wait_mean": 0.6204, "drink_bar_wait_p90": 0.8914, "gave_up": 7, "warped": 14, "table_freed": 22, "people_jam_total_s": 50, "walkers_mean": 9.549, "measured_minutes": 181.8777},
  "site_metrics": {"entry_wait_mean": 3.9575, "full_wait_mean": 0.6124, "staff_wait_mean": 2.1577, "blocked_wait_mean": 1.7088, "guide_wait_mean": 0.4489, "seat_wait_mean": 2.3212, "dish_wait_mean": 0.913, "dish_wait_p90": 1.6519, "cold_share": 0, "turn_mean": 4.7928, "walk_km_per_staff": 3.2595, "staff_util": 0.7676, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 86},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 181.8777, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 7, "warped": 14, "table_freed": 22},
"site_result": {"dish_wait_mean": 0.653, "dish_wait_p90": 1.3663, "cold_share": 0.0004, "seat_wait_mean": 2.602, "turn_mean": 9.4605, "walk_km_per_staff": 2.7655, "staff_util": 0.7511, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 84.2, "entry_wait_mean": 3.1814, "blocked_wait_mean": 2.4548, "guide_wait_mean": 0.3997, "staff_wait_mean": 2.8545, "full_wait_mean": 0.1472},20261023_stageB_fam_p1_r0_s2/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 00:51:31",
  "condition_id": "fam_p1_s4_r0_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 0,
  "seed": 2,
  "trips_requested": 0,
  "trips_done": 0,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 10912.66,
  "wall_seconds": 558.8922,
  "speedup": 19.5255,
  "frame_delta_s": {"count": 218732, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 218732, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
  "people_step_m": {"count": 218732, "mean": 0.0644, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 21.6718},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 78740,
  "people_frames_over_005m_ratio": 0.36,
  "chair_pulls": 192,
  "chair_pulls_by_reason": {"座る": 21, "食事中": 50, "ドリンクバー": 48, "トイレ": 5, "戻って座る": 29, "会計": 19, "退店": 20}
}
20261023_stageB_fam_p1_r0_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p1_r0_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p1_r0_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r0_a42,2,1,34,1,0,458.9315,458.9315,475.0775,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,2,35,2,0,582.0014,582.0014,598.1475,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,3,1,4,0,619.0424,619.0424,645.5359,スタッフ,0,26.4935,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,4,36,3,0,679.6276,679.6276,696.1235,スタッフ,0,16.496,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,5,38,6,0,729.6154,729.6154,748.2108,スタッフ,0,18.5955,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,6,34,1,0,771.3052,771.3052,787.4512,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p1_s4_r0_a42,2,7,39,7,0,829.6409,829.6409,849.3361,スタッフ,0,19.6952,0,0,1,0,0,020261023_stageB_fam_p1_r0_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p1_r0_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p1_r0_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r0_a42,2,3152.27,客,ドリンクバー,4,1.912,10.312,1.9774,7.6011,A01,60,移した
fam_p1_s4_r0_a42,2,3351.814,客,ドリンクバー,7,1.912,8.662,2.15,8.1742,A01,60,移した
fam_p1_s4_r0_a42,2,3650.906,客,ドリンクバー,7,1.912,8.662,2.15,6.4565,A01,60,移した
fam_p1_s4_r0_a42,2,3801.203,客,ドリンクバー,12,18.8,3.9,5.613,10.513,A02,0,あきらめた
fam_p1_s4_r0_a42,2,3848.549,客,ドリンクバー,8,1.912,10.513,1.9526,9.0478,A01,60,移した
fam_p1_s4_r0_a42,2,3863.814,客,ドリンクバー,4,1.912,10.312,2.15,6.4951,A01,60,移した
fam_p1_s4_r0_a42,2,4059.905,客,ドリンクバー,8,1.912,10.513,2.0043,7.1328,A01,60,移した20261023_stageB_fam_p1_r0_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r0_a42,2,1,2,34,2,31.8198,31.8198,106.8719,2266.212,2266.255,2378.515,2378.515,1.2509,0,Done
fam_p1_s4_r0_a42,2,2,1,35,2,51.4195,51.4195,128.6232,2649.795,2649.83,2781.058,2781.058,1.2867,0,Done
fam_p1_s4_r0_a42,2,3,2,36,2,80.4203,80.4203,159.2251,3226.006,3226.042,3404.666,3404.666,1.3134,0,Done
fam_p1_s4_r0_a42,2,4,4,1,4,171.0758,171.0758,234.9797,2721.443,2721.449,2871.246,2871.246,1.0651,0,Done
fam_p1_s4_r0_a42,2,5,1,37,2,180.2264,180.2264,258.8303,3344.757,3344.758,3494.854,3494.854,1.3101,0,Done
fam_p1_s4_r0_a42,2,6,1,38,2,237.2799,237.2799,305.369,2568.866,2568.901,2670.099,2670.099,1.1348,0,Done
fam_p1_s4_r0_a42,2,7,2,39,2,252.6808,252.6808,333.762,2789.895,2789.916,2961.434,2961.434,1.3514,0,Done20261023_stageB_fam_p1_r0_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p1_r0_s2/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 00:51:31",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット1台・種0(cs:140):20261023_stageB_fam_p1_r1_s0
20261023_stageB_fam_p1_r1_s0/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 01:01:18",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.8528, "dish_wait_p90": 5.8184, "cold_share": 0.6376, "seat_wait_mean": 1.8187, "turn_mean": 4.6242, "robot_share": 0.5688, "robot_dishes": 124, "staff_dishes": 94, "requeued_dishes": 1, "late_staff_dishes": 94, "late_staff_share": 0.4312, "robot_first_wait_s": 120, "yields": 1275, "yields_by_robot": 0, "yields_by_staff": 1012, "yields_by_guest": 263, "yields_stepped_aside": 134, "yields_in_corner": 31, "yields_passed": 476, "yield_wait_s": 2868.624, "yield_wait_mean_s": 2.2499, "staff_yields": 1012, "staff_yield_wait_s": 2040.176, "staff_yield_mean_s": 2.016, "staff_yield_share_of_staff_time": 0.0446, "staff_time_total_s": 45746.27, "corner_stops": 20, "corner_stop_s": 35.4, "corner_stop_count_share": 0.1042, "corner_stop_time_share": 0.0157, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 88, "people_jams": 754, "robot_blocked_jams": 738, "robot_blocked_jam_share": 0.9788, "chair_pulls": 154, "robot_contacts": 71, "robot_yield_waits": 1270, "robot_yield_wait_s": 2804.16, "robot_yield_detours": 15, "register_crowd_max": 9, "register_crowd_mean": 2.5227, "register_pay_count": 84, "register_pay_not_at_back": 2, "register_pay_off_spot": 19, "register_pay_offset_mean_m": 0.2316, "register_pay_offset_max_m": 10.5065, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 40, "drink_bar_gave_up": 10, "drink_bar_wait_mean": 0.621, "drink_bar_wait_p90": 0.9965, "gave_up": 58, "warped": 43, "table_freed": 23, "people_jam_total_s": 1139.849, "walkers_mean": 9.6269, "measured_minutes": 190.4947},
  "site_metrics": {"entry_wait_mean": 3.5292, "full_wait_mean": 0.6447, "staff_wait_mean": 1.6372, "blocked_wait_mean": 1.174, "guide_wait_mean": 0.4632, "seat_wait_mean": 1.8187, "dish_wait_mean": 3.8528, "dish_wait_p90": 5.8184, "cold_share": 0.6376, "turn_mean": 4.6242, "walk_km_per_staff": 2.7416, "staff_util": 0.7286, "robot_util": 0.7901, "robot_share": 0.5688, "rescues": 20, "pauses": 172, "groups": 88},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 190.4947, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 683, "rescues_done": 20, "rescue_wait_s": 469.6485, "gave_up": 58, "warped": 43, "table_freed": 23},
"site_result": {"dish_wait_mean": 2.0398, "dish_wait_p90": 3.0695, "cold_share": 0.1266, "seat_wait_mean": 1.2236, "turn_mean": 4.1041, "walk_km_per_staff": 1.8926, "staff_util": 0.6456, "robot_util": 0.7497, "robot_share": 0.7252, "robot_bus_share": 0, "collects": 0, "rescues": 0.925, "pauses": 20.25, "fragile_robot": 30.4, "groups": 82.55, "entry_wait_mean": 1.6401, "blocked_wait_mean": 0.9494, "guide_wait_mean": 0.2395, "staff_wait_mean": 1.189, "full_wait_mean": 0.2742},20261023_stageB_fam_p1_r1_s0/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 01:01:18",
  "condition_id": "fam_p1_s4_r1_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 1,
  "seed": 0,
  "trips_requested": 0,
  "trips_done": 57,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 11429.68,
  "wall_seconds": 583.2244,
  "speedup": 19.5974,
  "frame_delta_s": {"count": 229113, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 229113, "mean": 0.013, "min": 0, "p50": 0, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 229113, "mean": 0.0609, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 21.8742},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 65344,
  "people_frames_over_005m_ratio": 0.2852,
  "chair_pulls": 154,
  "chair_pulls_by_reason": {"座る": 17, "食事中": 34, "ドリンクバー": 39, "戻って座る": 31, "トイレ": 3, "会計": 16, "退店": 14}
}
20261023_stageB_fam_p1_r1_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r1_a42,1.2,normal,1,0,1,1,3,38.3101,65.3494,0.95,1,0.95,0,0,0,0,0.3641,0,3,0,,,0,0.5949,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,0,1,2,2,34.5452,61.9493,3,2,0.95;2.05,0,0,0,1,-0.0009,0,2;1,1,536.9124,627.2903,0,0.586,0,0,0,0,2,0,3
fam_p1_s4_r1_a42,1.2,normal,1,0,1,3,1,38.2351,65.4994,0.95,1,0.95,0,0,0,0,1.6567,0,1;3,2,567.9048;552.5586,739.313;739.313,0,0.5923,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,0,1,4,2,34.5302,59.0494,0.95,1,0.95,0,0,0,0,0.4102,0,2,2,708.4205;716.9684,854.8848;854.8848,0,0.5943,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,0,1,5,34,9.975,18.4,0.95,1,0.95,0,0,0,0,1.8644,0,34;35,1,858.7338,942.8133,0,0.5716,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,0,1,6,4,41.9099,129.9033,58.9494,2,0.95;57.9994,0,0,0,1,0.0844,0,4,2,921.1186;934.3654,1011.297;1011.297,0,0.5907,0,0,0,0,2,0,58.9494
fam_p1_s4_r1_a42,1.2,normal,1,0,1,7,38,40.455,70.1997,1.4,2,0.95;0.45,0,0,0,1,0.7915,0,38;5,1,965.0079,1166.382,0,0.588,0,0,0,0,2,0,1.420261023_stageB_fam_p1_r1_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r1_a42,0,1,1,537,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,2,627.4,16.8515,5.8239,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.824,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,2,654.45,2.0533,4.6236,A01,0,人が立ち止まっていた,Staff01,0,2.05,自分で動き出した,180.8515,223.9753,180.8515,1.1,0,0,0.95,0,2.058;4.554,1.912;6.613,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,3,739.45,16.8527,5.825,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.853;5.825,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,4,858.9,16.8527,5.8249,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.853;5.825,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,5,943,16.8518,5.8242,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.824,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,0,1,6,1011.5,16.8532,5.8241,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.853;5.824,15.3;5.95,PathComplete,2,0.02520261023_stageB_fam_p1_r1_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r1_a42,0,1,3,3,0,536.9124,536.9624,627.2903,ロボット,0.05,90.3279,0,0,0,0,0,0
fam_p1_s4_r1_a42,0,3,2,2,0,567.9048,627.3403,739.313,ロボット,59.4355,111.9727,0,0,0,1,0,0
fam_p1_s4_r1_a42,0,2,1,1,0,552.5586,627.3403,739.313,ロボット,74.7817,111.9727,0,0,0,1,0,0
fam_p1_s4_r1_a42,0,4,1,1,0,708.4205,739.363,854.8848,ロボット,30.9424,115.5218,0,0,0,1,0,0
fam_p1_s4_r1_a42,0,5,3,3,0,716.9684,739.363,854.8848,ロボット,22.3945,115.5218,0,0,0,1,0,0
fam_p1_s4_r1_a42,0,6,2,2,0,858.7338,858.7838,942.8133,ロボット,0.05,84.0295,0,0,0,0,0,0
fam_p1_s4_r1_a42,0,7,34,4,0,921.1186,942.8633,1011.297,ロボット,21.7447,68.4333,0,0,0,0,0,020261023_stageB_fam_p1_r1_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r1_a42,0,613.9936,スタッフ:Staff02,1,ロボット1号機,12.3403,4.5136,,,1,4.5,1,1
fam_p1_s4_r1_a42,0,649.4849,スタッフ:Staff01,1,ロボット1号機,2.1298,4.8845,A01,,0,4.95,1,1
fam_p1_s4_r1_a42,0,654.4837,スタッフ:Staff01,1,ロボット1号機,2.15,5.0631,A01,,0,2.5,0,1
fam_p1_s4_r1_a42,0,657.0331,スタッフ:Staff01,1,ロボット1号機,2.15,7.2881,A01,,0,0.65,0,1
fam_p1_s4_r1_a42,0,658.8826,スタッフ:Staff01,1,ロボット1号機,2.145,7.8165,A01,,0,1.8,0,1
fam_p1_s4_r1_a42,0,662.3318,スタッフ:Staff01,1,ロボット1号機,2.1249,8.2826,A01,,0,1.35,0,1
fam_p1_s4_r1_a42,0,665.3311,スタッフ:Staff01,1,ロボット1号機,2.1191,8.2967,A01,,0,1.35,0,120261023_stageB_fam_p1_r1_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r1_a42,0,2093.687,18,39,1,0,1379.39,714.2969,1,打ち切り
20261023_stageB_fam_p1_r1_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r1_a42,0,1092.36,客,ドリンクバー,2,17.3,3.9,2.5777,4.539,,60,あきらめた
fam_p1_s4_r1_a42,0,1123.891,客,ドリンクバー,1,1.912,4.762,5.5917,4.4824,,60,移した
fam_p1_s4_r1_a42,0,1416.827,客,ドリンクバー,1,1.912,4.762,4.4341,4.474,,60,移した
fam_p1_s4_r1_a42,0,1516.124,スタッフ,料理を運ぶ,38,15.3,5.95,17.4767,2.55,,60.0494,あきらめた
fam_p1_s4_r1_a42,0,1576.282,スタッフ,案内,18,0.9,2.1,17.4767,2.55,,60.0494,あきらめた
fam_p1_s4_r1_a42,0,1636.441,スタッフ,案内,18,0.9,2.1,17.4767,2.55,,60.0494,あきらめた
fam_p1_s4_r1_a42,0,1687.09,スタッフ,料理を運ぶ,39,20.263,2.188,16.3625,2.9246,,60.0494,あきらめた20261023_stageB_fam_p1_r1_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r1_a42,0,1,4,1,4,56.4194,56.4194,119.8727,2334.03,2397.083,2496.73,2496.73,1.0576,0,Done
fam_p1_s4_r1_a42,0,2,3,2,4,95.8213,95.8213,161.6753,2430.474,2430.516,2599.03,2599.03,1.0976,0,Done
fam_p1_s4_r1_a42,0,3,4,3,4,103.0217,103.0217,172.2259,3048.394,3048.418,3149.617,3149.617,1.1534,0,Done
fam_p1_s4_r1_a42,0,4,2,34,2,334.1619,334.1619,408.2938,3329.361,3329.393,3430.591,3430.591,1.2355,0,Done
fam_p1_s4_r1_a42,0,5,1,35,2,424.5898,424.5898,499.5215,4009.05,4009.056,4324.594,4324.594,1.2489,0,Done
fam_p1_s4_r1_a42,0,6,4,4,4,434.8373,434.8373,504.9202,3680.622,3680.635,3938.437,3938.437,1.168,0,Done
fam_p1_s4_r1_a42,0,7,1,36,2,485.9749,485.9749,563.6059,4072.582,4072.618,4426.993,4426.993,1.2939,0,Done20261023_stageB_fam_p1_r1_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r1_a42,0,653.6839,2.15,4.9642,A01,,スタッフ:Staff01,0,1,8.8161
fam_p1_s4_r1_a42,0,1162.679,15.5348,4.4083,,,スタッフ:Staff04,0,1,9.8066
fam_p1_s4_r1_a42,0,1830.931,18.2695,2.55,,,スタッフ:Staff04,0,1,9.9692
fam_p1_s4_r1_a42,0,1947.294,18.2675,2.55,,,スタッフ:Staff01,0,1,9.8182
fam_p1_s4_r1_a42,0,1965.762,18.1502,2.55,,,スタッフ:Staff01,0,1,1.1959
fam_p1_s4_r1_a42,0,2041.036,18.1682,2.55,,,スタッフ:Staff01,0,1,2.427
fam_p1_s4_r1_a42,0,2100.894,16.7427,2.2146,,,スタッフ:Staff04,0,1,8.673520261023_stageB_fam_p1_r1_s0/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 01:01:19",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット1台・種1(cs:140):20261023_stageB_fam_p1_r1_s1
20261023_stageB_fam_p1_r1_s1/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 01:10:21",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.1393, "dish_wait_p90": 4.6728, "cold_share": 0.5056, "seat_wait_mean": 0, "turn_mean": 2.8174, "robot_share": 0.75, "robot_dishes": 135, "staff_dishes": 45, "requeued_dishes": 0, "late_staff_dishes": 45, "late_staff_share": 0.25, "robot_first_wait_s": 120, "yields": 558, "yields_by_robot": 0, "yields_by_staff": 374, "yields_by_guest": 184, "yields_stepped_aside": 218, "yields_in_corner": 72, "yields_passed": 483, "yield_wait_s": 2164.794, "yield_wait_mean_s": 3.8796, "staff_yields": 374, "staff_yield_wait_s": 1613.794, "staff_yield_mean_s": 4.315, "staff_yield_share_of_staff_time": 0.0375, "staff_time_total_s": 42980.66, "corner_stops": 30, "corner_stop_s": 289.8475, "corner_stop_count_share": 0.1546, "corner_stop_time_share": 0.2593, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 73, "people_jams": 363, "robot_blocked_jams": 344, "robot_blocked_jam_share": 0.9477, "chair_pulls": 180, "robot_contacts": 60, "robot_yield_waits": 561, "robot_yield_wait_s": 2162.584, "robot_yield_detours": 6, "register_crowd_max": 10, "register_crowd_mean": 2.1091, "register_pay_count": 71, "register_pay_not_at_back": 1, "register_pay_off_spot": 8, "register_pay_offset_mean_m": 0.1322, "register_pay_offset_max_m": 7.5505, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 20, "drink_bar_gave_up": 4, "drink_bar_wait_mean": 0.6609, "drink_bar_wait_p90": 0.9969, "gave_up": 37, "warped": 37, "table_freed": 6, "people_jam_total_s": 631.1496, "walkers_mean": 8.2257, "measured_minutes": 179.0147},
  "site_metrics": {"entry_wait_mean": 1.5759, "full_wait_mean": 0, "staff_wait_mean": 0.3513, "blocked_wait_mean": 0, "guide_wait_mean": 0.3513, "seat_wait_mean": 0, "dish_wait_mean": 3.1393, "dish_wait_p90": 4.6728, "cold_share": 0.5056, "turn_mean": 2.8174, "walk_km_per_staff": 2.5104, "staff_util": 0.6575, "robot_util": 0.7625, "robot_share": 0.75, "rescues": 5, "pauses": 189, "groups": 73},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 179.0147, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 5, "rescue_wait_s": 146.9505, "gave_up": 37, "warped": 37, "table_freed": 6},
"site_result": {"dish_wait_mean": 2.0398, "dish_wait_p90": 3.0695, "cold_share": 0.1266, "seat_wait_mean": 1.2236, "turn_mean": 4.1041, "walk_km_per_staff": 1.8926, "staff_util": 0.6456, "robot_util": 0.7497, "robot_share": 0.7252, "robot_bus_share": 0, "collects": 0, "rescues": 0.925, "pauses": 20.25, "fragile_robot": 30.4, "groups": 82.55, "entry_wait_mean": 1.6401, "blocked_wait_mean": 0.9494, "guide_wait_mean": 0.2395, "staff_wait_mean": 1.189, "full_wait_mean": 0.2742},20261023_stageB_fam_p1_r1_s1/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 01:10:21",
  "condition_id": "fam_p1_s4_r1_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 1,
  "seed": 1,
  "trips_requested": 0,
  "trips_done": 70,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 10740.88,
  "wall_seconds": 538.8367,
  "speedup": 19.9335,
  "frame_delta_s": {"count": 215283, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 215283, "mean": 0.0151, "min": 0, "p50": 0.02, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 215283, "mean": 0.0597, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 22.1732},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 61153,
  "people_frames_over_005m_ratio": 0.2841,
  "chair_pulls": 180,
  "chair_pulls_by_reason": {"座る": 20, "食事中": 32, "ドリンクバー": 48, "戻って座る": 35, "トイレ": 7, "会計": 19, "退店": 19}
}
20261023_stageB_fam_p1_r1_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r1_a42,1.2,normal,1,1,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.6619,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,1,1,2,35,9.42,17.2,0.95,1,0.95,0,0,0,0,0.3924,0,35,1,571.9539,614.2935,0,0.5797,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,1,1,3,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.8641,0,36,1,806.0467,848.2864,0,0.5814,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,1,1,4,35,9.48,17.3,0.95,1,0.95,0,0,0,0,2.2997,0,35,1,860.5334,904.2727,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,1,1,5,37,37.9651,105.9019,41.2497,2,0.95;40.2997,0,0,0,1,0.0258,0,37;1,1,878.2291,946.6124,0,0.5872,0,0,0,0,2,0,41.2497
fam_p1_s4_r1_a42,1.2,normal,1,1,1,6,34,11.415,20.8,0.95,1,0.95,0,0,0,0,1.5299,0,34;36,2,940.014;938.5643,1102.67;1102.67,0,0.5751,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,1,1,7,38,14.61,29.0998,3.1,3,0.95;1.7;0.45,0,0,0,1,0.0453,0,38,2,1044.363;991.3015,1173.639;1173.639,0,0.5619,0,0,0,0,3,0,3.120261023_stageB_fam_p1_r1_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r1_a42,1,1,1,572.05,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,2,806.2,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,3,860.7,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,4,904.45,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,5,946.8,16.8509,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,5,984.95,17.362,2.2913,,0,人が立ち止まっていた,Staff02,0,40.2997,経路を引き直した,66.9469,26.3274,26.3274,39.3497,0,0,0.95,4,17.362;2.291,2.312;4.312,PathComplete,2,0.025
fam_p1_s4_r1_a42,1,1,6,1102.8,16.8549,5.8262,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.826,15.3;5.95,PathComplete,2,0.02520261023_stageB_fam_p1_r1_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r1_a42,1,1,34,1,0,571.9539,572.0038,614.2935,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p1_s4_r1_a42,1,2,35,2,0,806.0467,806.0967,848.2864,ロボット,0.05,42.1897,0,0,0,0,0,0
fam_p1_s4_r1_a42,1,3,36,3,0,860.5334,860.5834,904.2727,ロボット,0.05,43.6893,0,0,0,0,0,0
fam_p1_s4_r1_a42,1,4,35,2,0,878.2291,904.3227,946.6124,ロボット,26.0936,42.2897,0,0,0,0,0,0
fam_p1_s4_r1_a42,1,6,37,5,0,940.014,946.6624,1102.67,ロボット,6.6484,156.0078,0,0,0,1,0,0
fam_p1_s4_r1_a42,1,5,1,4,0,938.5643,946.6624,1102.67,ロボット,8.098,156.0078,0,0,0,1,0,0
fam_p1_s4_r1_a42,1,8,34,1,0,1044.363,1102.72,1173.639,ロボット,58.3569,70.9192,0,0,0,1,0,020261023_stageB_fam_p1_r1_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r1_a42,1,810.0957,スタッフ:Staff02,1,ロボット1号機,16.2085,3.0065,,,0,4.55,1,1
fam_p1_s4_r1_a42,1,984.0532,スタッフ:Staff02,1,ロボット1号機,17.084,2.55,,,0,0.8,1,1
fam_p1_s4_r1_a42,1,1045.114,スタッフ:Staff01,1,ロボット1号機,2.9171,4.362,,,0,4.65,1,1
fam_p1_s4_r1_a42,1,1051.07,スタッフ:Staff03,1,ロボット1号機,1.1573,1.956,,,0,26.7499,0,1
fam_p1_s4_r1_a42,1,1243.608,スタッフ:Staff01,1,ロボット1号機,5.8029,4.4132,,,0,4.6,1,1
fam_p1_s4_r1_a42,1,1343.505,スタッフ:Staff01,1,ロボット1号機,17.0759,2.55,,,0,0.8,1,1
fam_p1_s4_r1_a42,1,1380.591,スタッフ:Staff01,1,ロボット1号機,15.8065,3.6427,,,0,2.15,1,120261023_stageB_fam_p1_r1_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p1_r1_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r1_a42,1,1023.294,スタッフ,案内,40,21.362,2.188,16.6678,2.5421,,60.0494,あきらめた
fam_p1_s4_r1_a42,1,1378.79,スタッフ,案内,41,22.463,2.188,16.6485,2.5508,,60.0494,あきらめた
fam_p1_s4_r1_a42,1,1747.299,客,ドリンクバー,39,17.3,3.9,20.1756,2.55,,60,あきらめた
fam_p1_s4_r1_a42,1,1913.461,スタッフ,呼び出し,39,20.263,2.188,18.0227,2.55,,60.0494,あきらめた
fam_p1_s4_r1_a42,1,1973.57,スタッフ,呼び出し,39,20.263,2.188,16.6774,2.5445,,60.0494,あきらめた
fam_p1_s4_r1_a42,1,2056.651,スタッフ,料理を運ぶ,4,15.3,5.95,14.0639,4.047,,60.0494,あきらめた
fam_p1_s4_r1_a42,1,2204.745,客,ドリンクバー,2,1.912,6.613,4.7272,4.2547,,60,移した20261023_stageB_fam_p1_r1_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r1_a42,1,1,1,34,2,43.2696,43.2696,117.2726,3081.973,3082.001,3183.2,3183.2,1.2334,0,Done
fam_p1_s4_r1_a42,1,2,2,35,2,175.5261,175.5261,250.9807,2497.801,2497.831,2604.285,2604.285,1.2576,0,Done
fam_p1_s4_r1_a42,1,3,2,36,2,194.3773,194.3773,271.4272,2642.17,2642.172,2745.973,2745.973,1.2842,0,Done
fam_p1_s4_r1_a42,1,4,3,1,4,396.7966,396.7966,460.781,3148.814,3148.816,3284.899,3284.899,1.0664,0,Done
fam_p1_s4_r1_a42,1,5,1,37,2,437.2867,437.2867,519.0668,3616.308,3616.323,3771.124,3771.124,1.363,0,Done
fam_p1_s4_r1_a42,1,6,4,2,4,704.7714,704.7714,769.4556,3291.293,3291.305,3394.256,3394.256,1.0781,0,Done
fam_p1_s4_r1_a42,1,7,2,38,2,724.3167,724.3167,806.1967,3566.821,3566.824,3669.775,3669.775,1.3647,0,Done20261023_stageB_fam_p1_r1_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r1_a42,1,984.2032,17.1036,2.55,,,スタッフ:Staff02,0,1,8.3826
fam_p1_s4_r1_a42,1,1181.497,16.5,3.5211,,,客:Guest(Clone),0,1,9.5973
fam_p1_s4_r1_a42,1,1343.605,17.1,2.55,,,スタッフ:Staff01,0,1,9.458
fam_p1_s4_r1_a42,1,1382.543,15.9927,2.741,,,スタッフ:Staff01,0,1,9.1227
fam_p1_s4_r1_a42,1,1918.616,17.3817,1.7477,,,スタッフ:Staff01,0,1,9.156
fam_p1_s4_r1_a42,1,2002.198,1.7987,5.2369,A01,,スタッフ:Staff04,0,1,8.8518
fam_p1_s4_r1_a42,1,2061.305,16.4397,5.57,,,スタッフ:Staff01,0,1,9.492120261023_stageB_fam_p1_r1_s1/conditions.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 01:10:22",
  "unity_version": "2022.3.62f3",
  "trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
  "settings": {
    "store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット1台・種2(cs:140):20261023_stageB_fam_p1_r1_s2
20261023_stageB_fam_p1_r1_s2/summary.json
{
  "run_name": "family_v0",
  "written_at": "2026-10-24 01:19:32",
  "note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
  "sim_like": {"dish_wait_mean": 3.8241, "dish_wait_p90": 5.9361, "cold_share": 0.6262, "seat_wait_mean": 4.3351, "turn_mean": 4.9603, "robot_share": 0.5935, "robot_dishes": 127, "staff_dishes": 87, "requeued_dishes": 3, "late_staff_dishes": 87, "late_staff_share": 0.4065, "robot_first_wait_s": 120, "yields": 304, "yields_by_robot": 0, "yields_by_staff": 225, "yields_by_guest": 79, "yields_stepped_aside": 151, "yields_in_corner": 36, "yields_passed": 266, "yield_wait_s": 1260.996, "yield_wait_mean_s": 4.148, "staff_yields": 225, "staff_yield_wait_s": 979.8459, "staff_yield_mean_s": 4.3549, "staff_yield_share_of_staff_time": 0.0226, "staff_time_total_s": 43302.45, "corner_stops": 23, "corner_stop_s": 200.6982, "corner_stop_count_share": 0.1095, "corner_stop_time_share": 0.1318, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 85, "people_jams": 190, "robot_blocked_jams": 169, "robot_blocked_jam_share": 0.8895, "chair_pulls": 176, "robot_contacts": 43, "robot_yield_waits": 302, "robot_yield_wait_s": 1232.277, "robot_yield_detours": 8, "register_crowd_max": 9, "register_crowd_mean": 2.5049, "register_pay_count": 81, "register_pay_not_at_back": 1, "register_pay_off_spot": 26, "register_pay_offset_mean_m": 0.2194, "register_pay_offset_max_m": 12.0287, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 21, "drink_bar_gave_up": 2, "drink_bar_wait_mean": 0.6876, "drink_bar_wait_p90": 0.9965, "gave_up": 36, "warped": 36, "table_freed": 23, "people_jam_total_s": 724.707, "walkers_mean": 10.3309, "measured_minutes": 180.2972},
  "site_metrics": {"entry_wait_mean": 5.9371, "full_wait_mean": 2.3802, "staff_wait_mean": 2.3347, "blocked_wait_mean": 1.9549, "guide_wait_mean": 0.3798, "seat_wait_mean": 4.3351, "dish_wait_mean": 3.8241, "dish_wait_p90": 5.9361, "cold_share": 0.6262, "turn_mean": 4.9603, "walk_km_per_staff": 2.5653, "staff_util": 0.7325, "robot_util": 0.7872, "robot_share": 0.5935, "rescues": 16, "pauses": 194, "groups": 85},
  "site_run": {"site_run": true, "condition_id": "fam_p1_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 180.2972, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 16, "rescue_wait_s": 420.4488, "gave_up": 36, "warped": 36, "table_freed": 23},
"site_result": {"dish_wait_mean": 2.0398, "dish_wait_p90": 3.0695, "cold_share": 0.1266, "seat_wait_mean": 1.2236, "turn_mean": 4.1041, "walk_km_per_staff": 1.8926, "staff_util": 0.6456, "robot_util": 0.7497, "robot_share": 0.7252, "robot_bus_share": 0, "collects": 0, "rescues": 0.925, "pauses": 20.25, "fragile_robot": 30.4, "groups": 82.55, "entry_wait_mean": 1.6401, "blocked_wait_mean": 0.9494, "guide_wait_mean": 0.2395, "staff_wait_mean": 1.189, "full_wait_mean": 0.2742},20261023_stageB_fam_p1_r1_s2/run_info.json
{
  "run_label": "stageB",
  "written_at": "2026-10-24 01:19:32",
  "condition_id": "fam_p1_s4_r1_a42",
  "store_kind": "StoreLayout_p1_efficient_corner",
  "time_mode": "FixedStep",
  "time_scale": 1,
  "capture_delta_time": 0.05,
  "aisle_width_m": 1.2,
  "delivery_offset_m": 0,
  "delivery_offset_used_m": 0,
  "crowd": "normal",
  "robots": 1,
  "seed": 2,
  "trips_requested": 0,
  "trips_done": 61,
  "stopped_early": false,
  "one_robot_per_aisle": true,
  "yield_order_enabled": true,
  "unity_cs": "cs:140",
  "pending_changes": "",
  "staff_first_yield": true,
  "sim_seconds": 10817.83,
  "wall_seconds": 546.3296,
  "speedup": 19.8009,
  "frame_delta_s": {"count": 216828, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
  "robot_step_m": {"count": 216828, "mean": 0.0142, "min": 0, "p50": 0, "p90": 0.03, "p99": 0.03, "max": 0.03},
  "people_step_m": {"count": 216828, "mean": 0.06, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.5693},
  "frames_over_005m": 0,
  "frames_over_005m_ratio": 0,
  "people_frames_over_005m": 63231,
  "people_frames_over_005m_ratio": 0.2916,
  "chair_pulls": 176,
  "chair_pulls_by_reason": {"座る": 19, "食事中": 45, "ドリンクバー": 34, "トイレ": 10, "戻って座る": 33, "退店": 19, "会計": 16}
}
20261023_stageB_fam_p1_r1_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r1_a42,1.2,normal,1,2,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.528,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,2,1,2,35,9.42,18.3,2.05,2,0.95;1.1,0,0,0,0,1.5276,0,35,1,458.9315,501.2711,0,0.5797,0,0,0,0,2,0,2.05
fam_p1_s4_r1_a42,1.2,normal,1,2,1,3,1,30.9003,52.9995,0.95,1,0.95,0,0,0,0,1.2485,0,1,1,582.0014,625.3408,0,0.5937,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,2,1,4,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.5274,0,36,1,619.0424,703.3718,0,0.5814,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,2,1,5,38,14.61,26.8499,1.4,2,0.95;0.45,0,0,0,1,1.8677,0,38,1,679.6276,747.1111,0,0.5741,0,0,0,0,2,0,1.4
fam_p1_s4_r1_a42,1.2,normal,1,2,1,6,34,9.45,17.25,0.95,1,0.95,0,0,0,0,1.8675,0,34,1,729.6154,798.9984,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r1_a42,1.2,normal,1,2,1,7,39,16.83,30.5498,1.4,2,0.95;0.45,0,0,0,1,1.5284,0,39,1,771.3052,841.2881,0,0.5774,0,0,0,0,2,0,1.420261023_stageB_fam_p1_r1_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r1_a42,2,1,1,459,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,2,582.1,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,2,616.45,15.8394,2.4362,,0,椅子・荷物・ベビーカー,Table35/Chair,0,1.1,自分で動き出した,275,275,275,0.15,0,0,0.95,0,15.839;2.436,15.3;4.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,3,625.45,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,4,703.5,16.8519,5.8242,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.824,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,5,747.25,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r1_a42,2,1,5,787.05,18.5359,2.2299,,0,椅子・荷物・ベビーカー,Table37/Chair,0,0.45,自分で動き出した,88.1099,32.0672,32.0672,0,0,0,0.45,0,18.925;2.212,16.738;2.312,PathComplete,2,0.02520261023_stageB_fam_p1_r1_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r1_a42,2,1,34,1,0,458.9315,458.9814,501.2711,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,2,35,2,0,582.0014,582.0514,625.3408,ロボット,0.05,43.2894,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,3,1,4,0,619.0424,625.3908,703.3718,ロボット,6.3485,77.981,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,4,36,3,0,679.6276,703.4218,747.1111,ロボット,23.7942,43.6893,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,5,38,6,0,729.6154,747.1611,798.9984,ロボット,17.5457,51.8373,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,6,34,1,0,771.3052,799.0484,841.2881,ロボット,27.7432,42.2397,0,0,0,0,0,0
fam_p1_s4_r1_a42,2,7,39,7,0,829.6409,841.3381,896.8745,ロボット,11.6971,55.5364,0,0,0,0,0,020261023_stageB_fam_p1_r1_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r1_a42,2,1220.035,スタッフ:Staff02,1,ロボット1号機,1.1856,2.0566,,,0,1.7,0,1
fam_p1_s4_r1_a42,2,1370.582,スタッフ:Staff01,1,ロボット1号機,0.9541,2.2967,,,0,4.05,0,1
fam_p1_s4_r1_a42,2,1380.792,スタッフ:Staff04,1,ロボット1号機,9.1766,4.523,,,0,4.6,1,1
fam_p1_s4_r1_a42,2,1800.051,客:Guest(Clone),2,ロボット1号機,5.0602,4.5219,,,0,5,0,0
fam_p1_s4_r1_a42,2,1805.906,客:Guest(Clone),2,ロボット1号機,5.0602,4.5263,,,0,5,0,0
fam_p1_s4_r1_a42,2,1811.762,客:Guest(Clone),2,ロボット1号機,5.0602,4.53,,,0,5,0,0
fam_p1_s4_r1_a42,2,1824.725,スタッフ:Staff01,1,ロボット1号機,7.8812,3.8314,,,0,2.65,1,120261023_stageB_fam_p1_r1_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r1_a42,2,7325.476,160,24,1,0,6611.675,713.8008,1,打ち切り
fam_p1_s4_r1_a42,2,7325.476,161,26,1,0,6612.821,712.6553,1,打ち切り
fam_p1_s4_r1_a42,2,7325.476,162,10,1,0,6629.057,696.4189,1,打ち切り
20261023_stageB_fam_p1_r1_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r1_a42,2,1639.394,客,トイレ,39,20.263,2.188,16.6748,2.5525,,60,移した
fam_p1_s4_r1_a42,2,1819.77,客,ドリンクバー,1,1.912,4.762,5.5602,4.5331,,60,移した
fam_p1_s4_r1_a42,2,2262.201,客,ドリンクバー,4,1.912,10.312,3.5726,12.486,,60,移した
fam_p1_s4_r1_a42,2,2684.914,客,ドリンクバー,9,5.613,4.962,8.2819,4.5329,,60,移した
fam_p1_s4_r1_a42,2,2761.739,客,トイレ,40,21.362,2.188,18.1363,2.3826,,60,移した
fam_p1_s4_r1_a42,2,3009.681,客,ドリンクバー,11,5.613,8.662,8.5098,4.548,,60,移した
fam_p1_s4_r1_a42,2,3130.699,スタッフ,呼び出し,17,5.613,13.888,8.5412,14.5006,,60.0494,あきらめた20261023_stageB_fam_p1_r1_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r1_a42,2,1,2,34,2,31.8198,31.8198,106.8719,3307.082,3307.121,3624.48,3624.48,1.2509,0,Done
fam_p1_s4_r1_a42,2,2,1,35,2,51.4195,51.4195,128.6232,3218.187,3218.234,3444.104,3444.104,1.2867,0,Done
fam_p1_s4_r1_a42,2,3,2,36,2,80.4203,80.4203,159.2251,2963.579,2963.586,3067.437,3067.437,1.3134,0,Done
fam_p1_s4_r1_a42,2,4,4,1,4,171.0758,171.0758,234.9797,3410.671,3410.672,3714.668,3714.668,1.0651,0,Done
fam_p1_s4_r1_a42,2,5,1,37,2,180.2264,180.2264,258.8303,3135.892,3135.904,3251.717,3251.717,1.3101,0,Done
fam_p1_s4_r1_a42,2,6,1,38,2,237.2799,237.2799,305.369,3144.487,3144.512,3353.917,3353.917,1.1348,0,Done
fam_p1_s4_r1_a42,2,7,2,39,2,252.6808,252.6808,333.762,3280.997,3281.045,3534.292,3534.292,1.3514,0,Done20261023_stageB_fam_p1_r1_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r1_a42,2,1983.279,16.9013,2.1787,,,客:Guest(Clone),0,1,-2.6812
fam_p1_s4_r1_a42,2,2750.177,11.5865,4.059,,,スタッフ:Staff03,0,1,9.9247
fam_p1_s4_r1_a42,2,3178.595,12.6,4.9402,,,スタッフ:Staff04,0,1,9.844
fam_p1_s4_r1_a42,2,3382.244,1.9115,8.6806,A01,,客:Guest(Clone),0,1,-0.0152
fam_p1_s4_r1_a42,2,3574.482,15.7837,4.3128,,,スタッフ:Staff02,0,1,9.9853
fam_p1_s4_r1_a42,2,4632.387,18.9441,2.5329,,,スタッフ:Staff02,1,1,9.9671
fam_p1_s4_r1_a42,2,4758.343,18.0132,2.1709,,,客:Guest(Clone),0,1,-0.042120261023_stageB_fam_p1_r1_s2/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:19:32",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット2台・種0(cs:140):20261023_stageB_fam_p1_r2_s0
20261023_stageB_fam_p1_r2_s0/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 00:03:35",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 4.2197, "dish_wait_p90": 8.1635, "cold_share": 0.5507, "seat_wait_mean": 0.8571, "turn_mean": 6.1583, "robot_share": 0.7053, "robot_dishes": 146, "staff_dishes": 61, "requeued_dishes": 2, "late_staff_dishes": 61, "late_staff_share": 0.2947, "robot_first_wait_s": 120, "yields": 2226, "yields_by_robot": 91, "yields_by_staff": 1879, "yields_by_guest": 256, "yields_stepped_aside": 319, "yields_in_corner": 673, "yields_passed": 649, "yield_wait_s": 4592.794, "yield_wait_mean_s": 2.0633, "staff_yields": 1879, "staff_yield_wait_s": 2655.547, "staff_yield_mean_s": 1.4133, "staff_yield_share_of_staff_time": 0.0616, "staff_time_total_s": 43124.71, "corner_stops": 68, "corner_stop_s": 1132.09, "corner_stop_count_share": 0.1671, "corner_stop_time_share": 0.2212, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 83, "people_jams": 691, "robot_blocked_jams": 676, "robot_blocked_jam_share": 0.9783, "chair_pulls": 153, "robot_contacts": 81, "robot_yield_waits": 2132, "robot_yield_wait_s": 3434.025, "robot_yield_detours": 11, "register_crowd_max": 10, "register_crowd_mean": 2.6866, "register_pay_count": 78, "register_pay_not_at_back": 2, "register_pay_off_spot": 16, "register_pay_offset_mean_m": 0.1858, "register_pay_offset_max_m": 5.8041, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 27, "drink_bar_gave_up": 6, "drink_bar_wait_mean": 0.7017, "drink_bar_wait_p90": 0.9965, "gave_up": 100, "warped": 59, "table_freed": 35, "people_jam_total_s": 1667.291, "walkers_mean": 9.3803, "measured_minutes": 179.5543},
"site_metrics": {"entry_wait_mean": 2.892, "full_wait_mean": 0, "staff_wait_mean": 1.6328, "blocked_wait_mean": 0.857, "guide_wait_mean": 0.7757, "seat_wait_mean": 0.8571, "dish_wait_mean": 4.2197, "dish_wait_p90": 8.1635, "cold_share": 0.5507, "turn_mean": 6.1583, "walk_km_per_staff": 2.5281, "staff_util": 0.8095, "robot_util": 0.7073, "robot_share": 0.7053, "rescues": 55, "pauses": 352, "groups": 83},
"site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 179.5543, "everyone_left": true, "aisle_deferrals": 45, "staff_first_yield": true, "robot_stuck_detours": 1458, "rescues_done": 54, "rescue_wait_s": 1869.998, "gave_up": 100, "warped": 59, "table_freed": 35},
"site_result": {"dish_wait_mean": 1.0102, "dish_wait_p90": 2.0803, "cold_share": 0.014, "seat_wait_mean": 0.4546, "turn_mean": 3.5399, "walk_km_per_staff": 1.6027, "staff_util": 0.6158, "robot_util": 0.6013, "robot_share": 0.9914, "robot_bus_share": 0, "collects": 0, "rescues": 1.6, "pauses": 44.2, "fragile_robot": 41.9, "groups": 83.275, "entry_wait_mean": 0.8336, "blocked_wait_mean": 0.3575, "guide_wait_mean": 0.2015, "staff_wait_mean": 0.559, "full_wait_mean": 0.0971},20261023_stageB_fam_p1_r2_s0/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 00:03:35",
"condition_id": "fam_p1_s4_r2_a42",
"store_kind": "StoreLayout_p1_efficient_corner",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 1.2,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 0,
"trips_requested": 0,
"trips_done": 99,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10773.26,
"wall_seconds": 787.0753,
"speedup": 13.6877,
"frame_delta_s": {"count": 215933, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 215933, "mean": 0.0171, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 215933, "mean": 0.0608, "min": 0, "p50": 0.0489, "p90": 0.05, "p99": 0.05, "max": 22.5693},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 57848,
"people_frames_over_005m_ratio": 0.2679,
"chair_pulls": 153,
"chair_pulls_by_reason": {"座る": 17, "食事中": 35, "ドリンクバー": 38, "戻って座る": 32, "会計": 13, "退店": 15, "トイレ": 3}
}
20261023_stageB_fam_p1_r2_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,0,1,1,3,38.3101,71.5498,6.6,2,0.95;5.65,0,0,0,1,0.5307,1,3,0,,,0,0.5898,0,0,0,0,2,0,6.6
fam_p1_s4_r2_a42,1.2,normal,2,0,2,2,2,36.8251,67.1995,4.45,2,0.95;3.5,0,0,0,1,0.5393,1,2;1,0,,,0,0.5869,0,0,0,0,2,0,4.45
fam_p1_s4_r2_a42,1.2,normal,2,0,1,3,1,30.9003,58.9494,5.8,3,0.95;4.15;0.7,0,0,0,1,0.1318,1,1,1,536.9124,633.4888,0,0.5814,0,0,0,0,3,0,5.8
fam_p1_s4_r2_a42,1.2,normal,2,0,2,4,3,40.71,74.0999,4.6,3,0.95;2.65;1,0,0,0,1,0.4785,1,3,2,567.9048;552.5586,718.5181;718.5181,0,0.5858,0,0,0,0,3,0,4.6
fam_p1_s4_r2_a42,1.2,normal,2,0,1,5,2,34.5302,59.0494,0.95,1,0.95,0,0,0,0,0.9996,0,2,1,708.4205,792.4,0,0.5943,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,0,2,6,34,11.04,19.9,0.95,1,0.95,0,0,0,0,1.877,0,34,1,716.9684,834.2398,0,0.5826,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,0,1,7,35,9.42,17.2,0.95,1,0.95,0,0,0,0,1.9264,0,35,1,858.7338,942.8133,0,0.5797,0,0,0,0,1,0,0.9520261023_stageB_fam_p1_r2_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,0,1,1,537,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,1,615.05,10.0485,4.362,,0,もう1台のロボット,ServingRobot02,0,5.65,自分で動き出した,18.8092,231.2592,18.8092,4.7,0,0,0.95,0,2.055;4.533,12.388;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,601.35,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,2,2,615.05,10.7707,4.39,,0,もう1台のロボット,ServingRobot01,0,3.5,自分で動き出した,234.0106,16.0017,16.0017,2.4,0,0,1.1,0,10.771;4.39,10.771;3.462,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,708.55,16.8515,5.8239,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.824,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,761.85,2.6119,4.5162,,0,もう1台のロボット,ServingRobot02,0,4.15,自分で動き出した,3.3874,275,3.3874,3.2,0,0,0.95,0,2.064;4.528,12.463;4.312,PathComplete,2,0.025
fam_p1_s4_r2_a42,0,1,3,784.05,13.0917,4.4954,,0,スタッフとすれ違った,Staff02,0,0.7,自分で動き出した,275,275,275,0,0,0,0.7,0,12.225;4.317,15.3;4.95,PathComplete,2,0.02520261023_stageB_fam_p1_r2_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r2_a42,0,1,3,3,0,536.9124,536.9624,633.4888,ロボット,0.05,96.5264,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,3,2,2,0,567.9048,601.2967,718.5181,ロボット,33.3919,117.2214,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,2,1,1,0,552.5586,601.2967,718.5181,ロボット,48.7381,117.2214,0,0,0,1,0,1
fam_p1_s4_r2_a42,0,4,1,1,0,708.4205,708.4705,792.4,ロボット,0.05,83.9295,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,5,3,3,0,716.9684,735.164,834.2398,ロボット,18.1956,99.0758,0,0,0,0,0,1
fam_p1_s4_r2_a42,0,6,2,2,0,858.7338,858.7838,942.8133,ロボット,0.05,84.0295,0,0,0,0,0,0
fam_p1_s4_r2_a42,0,7,34,4,0,921.1186,921.1686,966.0576,ロボット,0.05,44.889,0,0,0,0,0,020261023_stageB_fam_p1_r2_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r2_a42,0,614.0436,スタッフ:Staff02,1,ロボット1号機,12.3922,4.5382,,,1,1,1,1
fam_p1_s4_r2_a42,0,616.443,ロボット2号機,0,ロボット1号機,10.7707,4.39,,,1,5.4,1,1
fam_p1_s4_r2_a42,0,644.7361,スタッフ:Staff01,1,ロボット2号機,0.8,2.0335,,,0,47.6496,0,1
fam_p1_s4_r2_a42,0,712.1696,スタッフ:Staff01,1,ロボット1号機,12.8853,5.1837,,,1,4.25,1,1
fam_p1_s4_r2_a42,0,762.9072,ロボット2号機,0,ロボット1号機,3.157,4.32,,,0,5,1,1
fam_p1_s4_r2_a42,0,782.1525,スタッフ:Staff02,1,ロボット1号機,14.9,4.7708,,,0,1.85,1,1
fam_p1_s4_r2_a42,0,810.8955,スタッフ:Staff01,1,ロボット2号機,6.4605,3.6476,,,0,3.5,1,120261023_stageB_fam_p1_r2_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,0,2017.513,19,5,1,0,1383.294,634.2188,1,打ち切り
fam_p1_s4_r2_a42,0,6703.615,134,11,1,0,6105.859,597.7559,1,打ち切り
20261023_stageB_fam_p1_r2_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,0,1508.316,客,ドリンクバー,4,1.912,10.312,12.6045,4.1042,,60,移した
fam_p1_s4_r2_a42,0,1639.544,スタッフ,立ち往生を動かす,0,17.0704,2.6103,16.5585,2.5873,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1699.703,スタッフ,立ち往生を動かす,0,16.999,2.4518,16.5404,2.4017,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1759.861,スタッフ,立ち往生を動かす,0,16.9695,2.3281,16.5801,2.1827,,60.0494,移した
fam_p1_s4_r2_a42,0,1785.586,スタッフ,料理を運ぶ,5,15.3,5.95,18.0948,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1845.745,スタッフ,料理を運ぶ,5,15.3,5.95,18.1461,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,0,1895.093,スタッフ,立ち往生を動かす,0,17.0291,2.5302,16.5188,2.5365,,60.0494,あきらめた20261023_stageB_fam_p1_r2_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.8727,2471.569,2478.563,2579.761,2579.761,1.0576,0,Done
fam_p1_s4_r2_a42,0,2,3,0,0,95.8213,95.8213,161.6753,3625.609,3625.632,3826.528,3826.528,1.0976,0,Done
fam_p1_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,172.2259,3027.749,3027.798,3128.997,3128.997,1.1534,0,Done
fam_p1_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,408.2938,3904.237,3904.253,4206.557,4206.557,1.2355,0,Done
fam_p1_s4_r2_a42,0,5,1,35,2,424.5898,424.5898,499.5215,3385.25,3605.662,3736.34,3736.34,1.2489,0,Done
fam_p1_s4_r2_a42,0,6,4,4,4,434.8373,434.8373,504.9202,3301.795,3358.071,3459.069,3459.069,1.168,0,Done
fam_p1_s4_r2_a42,0,7,1,36,2,485.9749,485.9749,563.6059,2724.849,2724.853,2903.027,2903.027,1.2939,0,Done20261023_stageB_fam_p1_r2_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,0,977.7548,11.482,4.0613,,,スタッフ:Staff01,0,2,8.8155
fam_p1_s4_r2_a42,0,1759.861,16.9695,2.3281,,,スタッフ:Staff01,0,2,-13.0867
fam_p1_s4_r2_a42,0,1784.335,18.1811,2.55,,,スタッフ:Staff03,0,1,9.4571
fam_p1_s4_r2_a42,0,2015.361,17.0017,2.4599,,,スタッフ:Staff03,0,2,-16.962
fam_p1_s4_r2_a42,0,2201.592,7.4422,4.0321,,,スタッフ:Staff01,0,1,9.3946
fam_p1_s4_r2_a42,0,2271.711,12.1678,4.5333,,,スタッフ:Staff04,1,1,9.5557
fam_p1_s4_r2_a42,0,2440.375,5.8,5.112,A02,,スタッフ:Staff04,0,1,9.217220261023_stageB_fam_p1_r2_s0/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 00:03:36",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット2台・種1(cs:140):20261023_stageB_fam_p1_r2_s1
20261023_stageB_fam_p1_r2_s1/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:28:35",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 4.4348, "dish_wait_p90": 8.457, "cold_share": 0.623, "seat_wait_mean": 0.2946, "turn_mean": 4.6665, "robot_share": 0.6448, "robot_dishes": 118, "staff_dishes": 65, "requeued_dishes": 8, "late_staff_dishes": 65, "late_staff_share": 0.3552, "robot_first_wait_s": 120, "yields": 552, "yields_by_robot": 127, "yields_by_staff": 286, "yields_by_guest": 139, "yields_stepped_aside": 210, "yields_in_corner": 40, "yields_passed": 482, "yield_wait_s": 3039.088, "yield_wait_mean_s": 5.5056, "staff_yields": 286, "staff_yield_wait_s": 1475.743, "staff_yield_mean_s": 5.1599, "staff_yield_share_of_staff_time": 0.0345, "staff_time_total_s": 42808.96, "corner_stops": 27, "corner_stop_s": 334.4472, "corner_stop_count_share": 0.0712, "corner_stop_time_share": 0.0621, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 74, "people_jams": 1044, "robot_blocked_jams": 1001, "robot_blocked_jam_share": 0.9588, "chair_pulls": 151, "robot_contacts": 83, "robot_yield_waits": 427, "robot_yield_wait_s": 1815.296, "robot_yield_detours": 6, "register_crowd_max": 9, "register_crowd_mean": 2.2959, "register_pay_count": 70, "register_pay_not_at_back": 0, "register_pay_off_spot": 12, "register_pay_offset_mean_m": 0.0375, "register_pay_offset_max_m": 0.2905, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 22, "drink_bar_gave_up": 2, "drink_bar_wait_mean": 0.6825, "drink_bar_wait_p90": 1.0023, "gave_up": 74, "warped": 46, "table_freed": 21, "people_jam_total_s": 1893.489, "walkers_mean": 8.5081, "measured_minutes": 178.2278},
"site_metrics": {"entry_wait_mean": 2.3919, "full_wait_mean": 0, "staff_wait_mean": 1.1051, "blocked_wait_mean": 0.2946, "guide_wait_mean": 0.8105, "seat_wait_mean": 0.2946, "dish_wait_mean": 4.4348, "dish_wait_p90": 8.457, "cold_share": 0.623, "turn_mean": 4.6665, "walk_km_per_staff": 2.4884, "staff_util": 0.7517, "robot_util": 0.6753, "robot_share": 0.6448, "rescues": 62, "pauses": 317, "groups": 74},
"site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 178.2278, "everyone_left": true, "aisle_deferrals": 29, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 60, "rescue_wait_s": 2203.804, "gave_up": 74, "warped": 46, "table_freed": 21},
"site_result": {"dish_wait_mean": 1.0102, "dish_wait_p90": 2.0803, "cold_share": 0.014, "seat_wait_mean": 0.4546, "turn_mean": 3.5399, "walk_km_per_staff": 1.6027, "staff_util": 0.6158, "robot_util": 0.6013, "robot_share": 0.9914, "robot_bus_share": 0, "collects": 0, "rescues": 1.6, "pauses": 44.2, "fragile_robot": 41.9, "groups": 83.275, "entry_wait_mean": 0.8336, "blocked_wait_mean": 0.3575, "guide_wait_mean": 0.2015, "staff_wait_mean": 0.559, "full_wait_mean": 0.0971},20261023_stageB_fam_p1_r2_s1/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 01:28:35",
"condition_id": "fam_p1_s4_r2_a42",
"store_kind": "StoreLayout_p1_efficient_corner",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 1.2,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 1,
"trips_requested": 0,
"trips_done": 82,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10693.67,
"wall_seconds": 538.7911,
"speedup": 19.8475,
"frame_delta_s": {"count": 214335, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 214335, "mean": 0.0174, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 214335, "mean": 0.0578, "min": 0, "p50": 0.0492, "p90": 0.05, "p99": 0.05, "max": 21.9681},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 61144,
"people_frames_over_005m_ratio": 0.2853,
"chair_pulls": 151,
"chair_pulls_by_reason": {"座る": 17, "食事中": 33, "ドリンクバー": 41, "戻って座る": 24, "トイレ": 1, "会計": 18, "退店": 17}
}
20261023_stageB_fam_p1_r2_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,1,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.6614,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,1,1,2,35,9.42,17.2,0.95,1,0.95,0,0,0,0,0.3939,0,35,1,571.9539,614.2935,0,0.5797,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,1,1,3,36,10.32,20.05,1.75,2,0.95;0.8,0,0,0,1,1.8641,1,36,1,806.0467,848.2864,0,0.5639,0,0,0,0,2,0,1.75
fam_p1_s4_r2_a42,1.2,normal,2,1,2,4,35,11.07,19.95,0.95,1,0.95,0,0,0,0,1.8514,0,35,0,,,0,0.5826,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,1,2,5,37,13.95,26.1499,1.8,2,0.95;0.85,0,0,0,1,0.2517,0,37,1,878.2291,923.2181,0,0.5729,0,0,0,0,2,0,1.8
fam_p1_s4_r2_a42,1.2,normal,2,1,1,6,1,30.9003,52.9995,0.95,1,0.95,0,0,0,0,0.3541,0,1,1,860.5334,905.6224,0,0.5937,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,1,2,7,36,11.85,22.4999,1.65,2,0.95;0.7,0,0,0,1,0.1295,0,36,1,940.014,991.2015,0,0.5683,0,0,0,0,2,0,1.6520261023_stageB_fam_p1_r2_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,1,1,1,572.05,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,1,2,806.2,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,1,3,860.7,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,1,3,896.95,16.4921,2.561,,0,もう1台のロボット,ServingRobot02,0,0.8,自分で動き出した,275,28.52,28.52,0,0,0,0.8,0,16.566;2.413,15.3;4.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,2,4,878.4,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,2,5,940.2,17.6507,5.8081,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.651;5.808,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,1,2,5,980.05,17.1209,2.2825,,0,スタッフとすれ違った,Staff02,0,0.85,自分で動き出した,65.5161,26.9051,26.9051,0,0,0,0.85,0,17.839;2.227,16.738;2.312,PathComplete,2,0.02520261023_stageB_fam_p1_r2_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r2_a42,1,1,34,1,0,571.9539,572.0038,614.2935,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,2,35,2,0,806.0467,806.0967,848.2864,ロボット,0.05,42.1897,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,3,36,3,0,860.5334,860.5834,905.6224,ロボット,0.05,45.039,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,4,35,2,0,878.2291,878.2791,923.2181,ロボット,0.05,44.939,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,6,37,5,0,940.014,940.064,991.2015,ロボット,0.05,51.1375,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,5,1,4,0,938.5643,938.6143,1016.595,ロボット,0.05,77.981,0,0,0,0,0,0
fam_p1_s4_r2_a42,1,7,36,3,0,991.3015,991.3514,1038.858,ロボット,0.05,47.5065,0,0,0,0,0,020261023_stageB_fam_p1_r2_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r2_a42,1,809.9957,スタッフ:Staff02,1,ロボット1号機,16.1979,3.032,,,0,4.6,1,1
fam_p1_s4_r2_a42,1,943.1132,スタッフ:Staff01,1,ロボット1号機,12.4233,4.5505,,,1,4.4,1,1
fam_p1_s4_r2_a42,1,978.6545,スタッフ:Staff02,1,ロボット2号機,15.7739,2.5388,,,0,1.3,1,1
fam_p1_s4_r2_a42,1,980.804,スタッフ:Staff02,1,ロボット2号機,16.8913,1.5815,,,0,0.5,1,1
fam_p1_s4_r2_a42,1,992.3512,スタッフ:Staff02,1,ロボット2号機,17.0462,5.209,,,0,1.2,1,1
fam_p1_s4_r2_a42,1,994.4007,スタッフ:Staff02,1,ロボット2号機,16.5029,5.1436,,,0,0.1,1,1
fam_p1_s4_r2_a42,1,996.1003,スタッフ:Staff02,1,ロボット2号機,15.4835,5.2122,,,0,0.8,1,120261023_stageB_fam_p1_r2_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,1,2587.669,26,7,1,0,1943.841,643.8281,1,打ち切り
fam_p1_s4_r2_a42,1,5082.472,75,26,1,0,4484.716,597.7559,1,打ち切り
fam_p1_s4_r2_a42,1,5676.642,90,1,2,0,4967.822,708.8203,1,打ち切り
fam_p1_s4_r2_a42,1,5676.642,91,1,2,0,4968.619,708.0234,1,打ち切り
fam_p1_s4_r2_a42,1,5705.18,75,26,1,0,4484.716,1220.464,2,打ち切り
fam_p1_s4_r2_a42,1,7777.703,145,19,2,0,7143.141,634.5615,1,打ち切り
fam_p1_s4_r2_a42,1,7777.703,144,22,2,0,7122.821,654.8818,1,打ち切り
fam_p1_s4_r2_a42,1,7777.703,143,15,2,0,7120.181,657.5215,1,打ち切り
20261023_stageB_fam_p1_r2_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,1,1423.733,客,ドリンクバー,1,1.912,4.762,4.3411,4.4867,,60,移した
fam_p1_s4_r2_a42,1,1560.367,客,ドリンクバー,36,18.3,3.9,16.5551,2.5956,,60,あきらめた
fam_p1_s4_r2_a42,1,2008.254,客,ドリンクバー,1,1.912,4.762,11.3217,4.0372,,60,移した
fam_p1_s4_r2_a42,1,2125.318,スタッフ,立ち往生を動かす,0,10.6155,4.3739,11.0634,4.3947,,60.0494,あきらめた
fam_p1_s4_r2_a42,1,2266.656,スタッフ,立ち往生を動かす,0,10.6477,4.7909,10.9539,4.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,1,2408.044,スタッフ,立ち往生を動かす,0,10.6477,4.7909,10.962,4.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,1,2476.26,客,ドリンクバー,3,1.912,8.462,1.935,7.9862,A01,60,移した20261023_stageB_fam_p1_r2_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,1,1,1,0,0,43.2696,43.2696,117.2726,3035.952,3035.956,3255.971,3255.971,1.2334,0,Done
fam_p1_s4_r2_a42,1,2,2,35,2,175.5261,175.5261,250.9807,2418.159,2418.204,2526.559,2526.559,1.2576,0,Done
fam_p1_s4_r2_a42,1,3,2,36,2,194.3773,194.3773,271.4272,2894.765,2894.769,2995.967,2995.967,1.2842,0,Done
fam_p1_s4_r2_a42,1,4,3,1,4,396.7966,396.7966,460.781,3640.999,3700.154,3859.209,3859.209,1.0664,0,Done
fam_p1_s4_r2_a42,1,5,1,37,2,437.2867,437.2867,519.0668,3580.58,3580.588,3769.021,3769.021,1.363,0,Done
fam_p1_s4_r2_a42,1,6,4,2,4,704.7714,704.7714,769.4556,4273.249,4273.295,4565.798,4565.798,1.0781,0,Done
fam_p1_s4_r2_a42,1,7,2,38,2,724.3167,724.3167,806.0967,4352.573,4352.584,4692.452,4692.452,1.363,0,Done20261023_stageB_fam_p1_r2_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,1,1928.125,1.5517,4.7964,A01,,客:Guest(Clone),0,2,-0.2956
fam_p1_s4_r2_a42,1,2469.804,10.7584,4.0454,,,スタッフ:Staff03,1,1,9.8908
fam_p1_s4_r2_a42,1,2474.559,9.6115,4.1548,,,スタッフ:Staff04,1,2,9.7557
fam_p1_s4_r2_a42,1,2602.283,7.4442,4.0634,,,客:Guest(Clone),1,1,8.4308
fam_p1_s4_r2_a42,1,2662.392,4.3855,4.526,,,客:Guest(Clone),0,1,9.6188
fam_p1_s4_r2_a42,1,2685.765,14.283,4.1868,,,スタッフ:Staff04,0,1,9.2753
fam_p1_s4_r2_a42,1,2707.386,6.413,4.55,,,スタッフ:Staff02,0,2,9.533920261023_stageB_fam_p1_r2_s1/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:28:36",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ③・ロボット2台・種2(cs:140):20261023_stageB_fam_p1_r2_s2
20261023_stageB_fam_p1_r2_s2/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:38:33",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 4.7154, "dish_wait_p90": 10.8881, "cold_share": 0.6019, "seat_wait_mean": 6.0532, "turn_mean": 5.4023, "robot_share": 0.6825, "robot_dishes": 144, "staff_dishes": 67, "requeued_dishes": 3, "late_staff_dishes": 67, "late_staff_share": 0.3175, "robot_first_wait_s": 120, "yields": 4626, "yields_by_robot": 187, "yields_by_staff": 3951, "yields_by_guest": 488, "yields_stepped_aside": 440, "yields_in_corner": 741, "yields_passed": 1009, "yield_wait_s": 6394.604, "yield_wait_mean_s": 1.3823, "staff_yields": 3951, "staff_yield_wait_s": 3571.066, "staff_yield_mean_s": 0.9038, "staff_yield_share_of_staff_time": 0.0763, "staff_time_total_s": 46819.32, "corner_stops": 42, "corner_stop_s": 223.3491, "corner_stop_count_share": 0.0794, "corner_stop_time_share": 0.0381, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 85, "people_jams": 647, "robot_blocked_jams": 609, "robot_blocked_jam_share": 0.9413, "chair_pulls": 184, "robot_contacts": 120, "robot_yield_waits": 4444, "robot_yield_wait_s": 4939.911, "robot_yield_detours": 16, "register_crowd_max": 10, "register_crowd_mean": 2.7917, "register_pay_count": 77, "register_pay_not_at_back": 0, "register_pay_off_spot": 16, "register_pay_offset_mean_m": 0.0413, "register_pay_offset_max_m": 0.2961, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 26, "drink_bar_gave_up": 6, "drink_bar_wait_mean": 0.6455, "drink_bar_wait_p90": 0.9965, "gave_up": 113, "warped": 73, "table_freed": 33, "people_jam_total_s": 1575.372, "walkers_mean": 11.024, "measured_minutes": 194.9398},
"site_metrics": {"entry_wait_mean": 9.0378, "full_wait_mean": 2.8635, "staff_wait_mean": 4.8814, "blocked_wait_mean": 3.1896, "guide_wait_mean": 1.6918, "seat_wait_mean": 6.0532, "dish_wait_mean": 4.7154, "dish_wait_p90": 10.8881, "cold_share": 0.6019, "turn_mean": 5.4023, "walk_km_per_staff": 2.6938, "staff_util": 0.7672, "robot_util": 0.7023, "robot_share": 0.6825, "rescues": 55, "pauses": 474, "groups": 85},
"site_run": {"site_run": true, "condition_id": "fam_p1_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 194.9398, "everyone_left": true, "aisle_deferrals": 38, "staff_first_yield": true, "robot_stuck_detours": 3426, "rescues_done": 49, "rescue_wait_s": 2233.765, "gave_up": 113, "warped": 73, "table_freed": 33},
"site_result": {"dish_wait_mean": 1.0102, "dish_wait_p90": 2.0803, "cold_share": 0.014, "seat_wait_mean": 0.4546, "turn_mean": 3.5399, "walk_km_per_staff": 1.6027, "staff_util": 0.6158, "robot_util": 0.6013, "robot_share": 0.9914, "robot_bus_share": 0, "collects": 0, "rescues": 1.6, "pauses": 44.2, "fragile_robot": 41.9, "groups": 83.275, "entry_wait_mean": 0.8336, "blocked_wait_mean": 0.3575, "guide_wait_mean": 0.2015, "staff_wait_mean": 0.559, "full_wait_mean": 0.0971},20261023_stageB_fam_p1_r2_s2/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 01:38:33",
"condition_id": "fam_p1_s4_r2_a42",
"store_kind": "StoreLayout_p1_efficient_corner",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 1.2,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 2,
"trips_requested": 0,
"trips_done": 91,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 11696.39,
"wall_seconds": 593.7455,
"speedup": 19.6993,
"frame_delta_s": {"count": 234468, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 234468, "mean": 0.0174, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 234468, "mean": 0.0594, "min": 0, "p50": 0.0488, "p90": 0.05, "p99": 0.05, "max": 22.1595},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 62651,
"people_frames_over_005m_ratio": 0.2672,
"chair_pulls": 184,
"chair_pulls_by_reason": {"座る": 19, "食事中": 48, "ドリンクバー": 42, "トイレ": 8, "戻って座る": 38, "会計": 17, "退店": 12}
}
20261023_stageB_fam_p1_r2_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p1_s4_r2_a42,1.2,normal,2,2,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.528,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,2,1,2,35,9.42,18.3,2.05,2,0.95;1.1,0,0,0,0,1.5276,0,35,1,458.9315,501.2711,0,0.5797,0,0,0,0,2,0,2.05
fam_p1_s4_r2_a42,1.2,normal,2,2,2,3,1,32.5803,55.7994,0.95,1,0.95,0,0,0,0,1.6747,0,1,0,,,0,0.594,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,2,1,4,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.8641,0,36,1,582.0014,625.3408,0,0.5814,0,0,0,0,1,0,0.95
fam_p1_s4_r2_a42,1.2,normal,2,2,1,5,38,14.61,88.0008,61.4494,4,0.95;0.45;4.3;55.7494,0,0,0,1,1.5315,1,38,1,679.6276,723.3669,0,0.5503,0,0,0,0,4,0,61.4494
fam_p1_s4_r2_a42,1.2,normal,2,2,2,6,34,7.11,51.1995,36.7497,5,0.95;2.7;30.8998;0.8;1.4,0,0,0,1,1.8764,1,34,1,619.0923,699.9226,0,0.4921,0,0,0,0,5,0,36.7498
fam_p1_s4_r2_a42,1.2,normal,2,2,2,7,37,13.95,24.7499,0.95,1,0.95,0,0,0,0,1.5428,0,37,1,771.3052,847.5366,0,0.5861,0,0,0,0,1,0,0.9520261023_stageB_fam_p1_r2_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p1_s4_r2_a42,2,1,1,459,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,1,2,582.1,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,1,2,616.45,15.8394,2.4362,,0,椅子・荷物・ベビーカー,Table35/Chair,0,1.1,自分で動き出した,275,275,275,0.15,0,0,0.95,0,15.839;2.436,15.3;4.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,2,3,619.2,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,1,4,679.75,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,1,5,729.75,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p1_s4_r2_a42,2,1,5,769.55,18.5359,2.2299,,0,椅子・荷物・ベビーカー,Table37/Chair,0,0.45,自分で動き出した,88.1099,32.0672,32.0672,0,0,0,0.45,0,18.925;2.212,16.738;2.312,PathComplete,2,0.02520261023_stageB_fam_p1_r2_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p1_s4_r2_a42,2,1,34,1,0,458.9315,458.9814,501.2711,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,2,35,2,0,582.0014,582.0514,625.3408,ロボット,0.05,43.2894,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,3,1,4,0,619.0923,619.1423,699.9226,ロボット,0.05,80.7803,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,4,36,3,0,679.6276,679.6776,723.3669,ロボット,0.05,43.6893,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,5,38,6,0,729.6154,729.6653,842.6378,ロボット,0.05,112.9724,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,6,34,1,0,771.3052,771.3552,847.5366,ロボット,0.05,76.1814,0,0,0,0,0,0
fam_p1_s4_r2_a42,2,8,37,5,0,844.0374,847.5865,897.3244,ロボット,3.5491,49.7379,0,0,0,0,0,020261023_stageB_fam_p1_r2_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p1_s4_r2_a42,2,779.0033,ロボット2号機,0,ロボット1号機,15.4843,5.2347,,,0,30.0498,1,0
fam_p1_s4_r2_a42,2,836.1393,ロボット2号機,0,ロボット1号機,15.84,5.1811,,,0,6.15,1,1
fam_p1_s4_r2_a42,2,1000.499,ロボット2号機,0,ロボット1号機,18.0213,2.3732,,,0,2.45,1,1
fam_p1_s4_r2_a42,2,1005.498,ロボット2号機,0,ロボット1号機,18.0992,1.8215,,,0,2,1,1
fam_p1_s4_r2_a42,2,1010.047,ロボット2号機,0,ロボット1号機,18.3403,1.9861,,,0,2.55,1,1
fam_p1_s4_r2_a42,2,1015.246,ロボット2号機,0,ロボット1号機,18.3705,2.1699,,,0,3.15,1,1
fam_p1_s4_r2_a42,2,1021.144,ロボット2号機,0,ロボット1号機,18.1804,2.3263,,,0,2.6,1,120261023_stageB_fam_p1_r2_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p1_s4_r2_a42,2,1879.678,18,40,2,0,1236.351,643.3276,1,打ち切り
fam_p1_s4_r2_a42,2,1890.038,16,3,1,0,1189.755,700.2832,1,打ち切り
fam_p1_s4_r2_a42,2,2480.364,18,40,2,0,1236.351,1244.014,2,打ち切り
20261023_stageB_fam_p1_r2_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p1_s4_r2_a42,2,1580.336,スタッフ,立ち往生を動かす,0,17.0745,2.5,16.6797,2.4261,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1600.856,スタッフ,案内,8,0.9,2.1,18.2211,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1686.34,スタッフ,案内,10,0.9,2.1,18.072,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1746.498,スタッフ,案内,10,0.9,2.1,18.0592,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1791.993,スタッフ,料理を運ぶ,3,15.3,5.95,18.2219,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1898.246,スタッフ,呼び出し,1,1.912,4.762,17.6269,2.55,,60.0494,あきらめた
fam_p1_s4_r2_a42,2,1963.01,スタッフ,案内,13,0.9,2.1,17.6269,2.55,,60.0494,あきらめた20261023_stageB_fam_p1_r2_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p1_s4_r2_a42,2,1,2,0,0,31.8198,31.8198,106.8719,3313.331,3313.377,-1,3914.013,1.2509,0,Done
fam_p1_s4_r2_a42,2,2,1,35,2,51.4195,51.4195,128.6232,3656.837,3656.862,4115.763,4115.763,1.2867,0,Done
fam_p1_s4_r2_a42,2,3,2,36,2,80.4203,80.4203,159.2251,2829.843,2829.855,2931.454,2931.454,1.3134,0,Done
fam_p1_s4_r2_a42,2,4,4,0,0,171.0758,171.0758,235.0297,3150.736,3443.654,-1,4044.29,1.0659,0,Done
fam_p1_s4_r2_a42,2,5,1,37,2,180.2264,180.2264,259.1802,3762.435,3781.534,4143.006,4143.006,1.3159,0,Done
fam_p1_s4_r2_a42,2,6,1,0,0,237.2799,237.2799,305.369,3234.354,3234.4,-1,3835.036,1.1348,0,Done
fam_p1_s4_r2_a42,2,7,2,0,0,252.6808,252.6808,333.712,3247.637,3247.663,-1,3848.299,1.3505,0,Done20261023_stageB_fam_p1_r2_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p1_s4_r2_a42,2,1368.329,16.3497,2.7056,,,スタッフ:Staff02,0,2,7.4723
fam_p1_s4_r2_a42,2,1396.957,16.7604,2.226,,,スタッフ:Staff02,0,2,7.5851
fam_p1_s4_r2_a42,2,1407.017,16.8552,1.9983,,,スタッフ:Staff02,0,2,9.5781
fam_p1_s4_r2_a42,2,1418.628,16.8206,2.1585,,,スタッフ:Staff02,0,2,8.8245
fam_p1_s4_r2_a42,2,1430.74,16.9597,2.266,,,客:Guest(Clone),0,2,9.2265
fam_p1_s4_r2_a42,2,1488.897,16.3518,2.7593,,,スタッフ:Staff02,0,2,9.2929
fam_p1_s4_r2_a42,2,1525.733,18.2513,2.55,,,スタッフ:Staff02,0,1,9.465320261023_stageB_fam_p1_r2_s2/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:38:34",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[1.2000000476837159],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":35064},"summaryJson":{"instanceID":13240},"layoutFileName":"p1_efficient_corner","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p1_efficient_corner.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット0台・種0(cs:140):20261023_stageB_fam_p5_r0_s0
20261023_stageB_fam_p5_r0_s0/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:47:15",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 1.1201, "dish_wait_p90": 2.1438, "cold_share": 0.0225, "seat_wait_mean": 2.9882, "turn_mean": 5.2266, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 222, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 41403.97, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 85, "people_jams": 54, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 156, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 10, "register_crowd_mean": 2.8822, "register_pay_count": 81, "register_pay_not_at_back": 0, "register_pay_off_spot": 16, "register_pay_offset_mean_m": 0.0463, "register_pay_offset_max_m": 0.2907, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 33, "drink_bar_gave_up": 9, "drink_bar_wait_mean": 0.639, "drink_bar_wait_p90": 0.9055, "gave_up": 9, "warped": 23, "table_freed": 31, "people_jam_total_s": 56.75, "walkers_mean": 10.2209, "measured_minutes": 172.4048},
"site_metrics": {"entry_wait_mean": 4.8394, "full_wait_mean": 1.5201, "staff_wait_mean": 2.1071, "blocked_wait_mean": 1.4681, "guide_wait_mean": 0.639, "seat_wait_mean": 2.9882, "dish_wait_mean": 1.1201, "dish_wait_p90": 2.1438, "cold_share": 0.0225, "turn_mean": 5.2266, "walk_km_per_staff": 3.2197, "staff_util": 0.7948, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 85},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 172.4048, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 9, "warped": 23, "table_freed": 31},
"site_result": {"dish_wait_mean": 0.6572, "dish_wait_p90": 1.3761, "cold_share": 0.0012, "seat_wait_mean": 3.775, "turn_mean": 10.152, "walk_km_per_staff": 2.8551, "staff_util": 0.7522, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 85.625, "entry_wait_mean": 4.3607, "blocked_wait_mean": 3.568, "guide_wait_mean": 0.4037, "staff_wait_mean": 3.9717, "full_wait_mean": 0.207},20261023_stageB_fam_p5_r0_s0/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 01:47:15",
"condition_id": "fam_p5_s4_r0_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 0,
"seed": 0,
"trips_requested": 0,
"trips_done": 0,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10344.29,
"wall_seconds": 517.3931,
"speedup": 19.9931,
"frame_delta_s": {"count": 207320, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 207320, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
"people_step_m": {"count": 207320, "mean": 0.0644, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.2371},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 74062,
"people_frames_over_005m_ratio": 0.3572,
"chair_pulls": 156,
"chair_pulls_by_reason": {"座る": 18, "食事中": 33, "トイレ": 6, "ドリンクバー": 35, "戻って座る": 31, "会計": 16, "退店": 17}
}
20261023_stageB_fam_p5_r0_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p5_r0_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p5_r0_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r0_a42,0,1,3,3,0,535.8627,535.8627,566.3052,スタッフ,0,30.4426,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,2,1,1,0,551.9088,551.9088,579.1521,スタッフ,0,27.2434,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,3,2,2,0,567.5049,567.5049,596.5479,スタッフ,0,29.0429,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,4,1,1,0,707.7707,707.7707,735.6139,スタッフ,0,27.8432,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,5,3,3,0,715.9187,715.9187,750.7102,スタッフ,0,34.7915,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,6,2,2,0,858.3339,858.3339,887.5268,スタッフ,0,29.1929,0,0,1,0,0,0
fam_p5_s4_r0_a42,0,7,34,4,0,920.8187,920.8187,937.1147,スタッフ,0,16.296,0,0,1,0,0,020261023_stageB_fam_p5_r0_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p5_r0_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p5_r0_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r0_a42,0,1914.362,客,ドリンクバー,3,1.763,8.462,1.8143,6.2822,A01,60,移した
fam_p5_s4_r0_a42,0,2153.295,客,ドリンクバー,8,1.763,10.513,1.7966,7.9291,A01,60,移した
fam_p5_s4_r0_a42,0,2330.318,客,ドリンクバー,4,1.763,10.312,7.4568,4.2476,,60,移した
fam_p5_s4_r0_a42,0,2915.088,客,ドリンクバー,6,18.8,3.9,1.763,6.812,A01,0,あきらめた
fam_p5_s4_r0_a42,0,3247.763,客,ドリンクバー,8,1.763,10.513,1.6619,8.4665,A01,60,移した
fam_p5_s4_r0_a42,0,3269.034,客,ドリンクバー,8,18.8,3.9,1.763,10.513,A01,0,あきらめた
fam_p5_s4_r0_a42,0,3272.737,客,ドリンクバー,7,1.763,8.662,1.8821,6.2687,A01,60,移した20261023_stageB_fam_p5_r0_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r0_a42,0,1,4,1,4,56.4194,56.4194,119.2227,3330.368,3330.394,3497.907,3497.907,1.0467,0,Done
fam_p5_s4_r0_a42,0,2,3,2,4,95.8213,95.8213,161.2752,2456.547,2456.591,2569.251,2569.251,1.0909,0,Done
fam_p5_s4_r0_a42,0,3,4,3,4,103.0217,103.0217,171.1758,2848.064,2848.073,2953.876,2953.876,1.1359,0,Done
fam_p5_s4_r0_a42,0,4,2,34,2,334.1619,334.1619,407.9939,3433.197,3433.244,3701.155,3701.155,1.2305,0,Done
fam_p5_s4_r0_a42,0,5,1,35,2,424.5898,424.5898,499.2216,2884.93,2884.959,3044.064,3044.064,1.2439,0,Done
fam_p5_s4_r0_a42,0,6,4,4,4,434.8373,434.8373,504.5203,3518.751,3518.777,3881.531,3881.531,1.1614,0,Done
fam_p5_s4_r0_a42,0,7,1,36,2,485.9749,485.9749,563.106,2685.661,2685.665,2809.936,2809.936,1.2855,0,Done20261023_stageB_fam_p5_r0_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p5_r0_s0/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:47:15",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット0台・種1(cs:140):20261023_stageB_fam_p5_r0_s1
20261023_stageB_fam_p5_r0_s1/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:55:25",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 1.0004, "dish_wait_p90": 1.9807, "cold_share": 0.0116, "seat_wait_mean": 0, "turn_mean": 4.7399, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 173, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 39270.93, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 69, "people_jams": 146, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 140, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 9, "register_crowd_mean": 2.2391, "register_pay_count": 67, "register_pay_not_at_back": 0, "register_pay_off_spot": 12, "register_pay_offset_mean_m": 0.0448, "register_pay_offset_max_m": 0.2998, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 28, "drink_bar_gave_up": 7, "drink_bar_wait_mean": 0.6378, "drink_bar_wait_p90": 0.9216, "gave_up": 10, "warped": 12, "table_freed": 14, "people_jam_total_s": 153.0002, "walkers_mean": 8.1532, "measured_minutes": 163.5246},
"site_metrics": {"entry_wait_mean": 1.6157, "full_wait_mean": 0, "staff_wait_mean": 0.4105, "blocked_wait_mean": 0, "guide_wait_mean": 0.4105, "seat_wait_mean": 0, "dish_wait_mean": 1.0004, "dish_wait_p90": 1.9807, "cold_share": 0.0116, "turn_mean": 4.7399, "walk_km_per_staff": 2.8176, "staff_util": 0.7173, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 69},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 163.5246, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 10, "warped": 12, "table_freed": 14},
"site_result": {"dish_wait_mean": 0.6572, "dish_wait_p90": 1.3761, "cold_share": 0.0012, "seat_wait_mean": 3.775, "turn_mean": 10.152, "walk_km_per_staff": 2.8551, "staff_util": 0.7522, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 85.625, "entry_wait_mean": 4.3607, "blocked_wait_mean": 3.568, "guide_wait_mean": 0.4037, "staff_wait_mean": 3.9717, "full_wait_mean": 0.207},20261023_stageB_fam_p5_r0_s1/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 01:55:25",
"condition_id": "fam_p5_s4_r0_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 0,
"seed": 1,
"trips_requested": 0,
"trips_done": 0,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 9811.478,
"wall_seconds": 485.9518,
"speedup": 20.1902,
"frame_delta_s": {"count": 196622, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 196622, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
"people_step_m": {"count": 196622, "mean": 0.0611, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.5693},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 68751,
"people_frames_over_005m_ratio": 0.3497,
"chair_pulls": 140,
"chair_pulls_by_reason": {"座る": 16, "食事中": 29, "ドリンクバー": 39, "トイレ": 1, "戻って座る": 24, "会計": 16, "退店": 15}
}
20261023_stageB_fam_p5_r0_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p5_r0_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p5_r0_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r0_a42,1,1,34,1,0,571.7039,571.7039,587.95,スタッフ,0,16.246,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,2,35,2,0,805.5468,805.5468,822.9926,スタッフ,0,17.4457,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,3,36,3,0,860.1335,860.1335,878.1291,スタッフ,0,17.9956,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,4,35,2,0,877.7292,877.7292,895.5748,スタッフ,0,17.8456,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,6,37,5,0,938.5143,938.5143,957.2098,スタッフ,0,18.6954,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,5,1,4,0,937.5146,937.5146,968.607,スタッフ,0,31.0924,0,0,1,0,0,0
fam_p5_s4_r0_a42,1,7,36,3,0,990.9016,990.9016,1007.398,スタッフ,0,16.496,0,0,1,0,0,020261023_stageB_fam_p5_r0_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p5_r0_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p5_r0_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r0_a42,1,1593.349,スタッフ,料理を運ぶ,41,22.463,2.188,21.2,3.5392,,60.0494,あきらめた
fam_p5_s4_r0_a42,1,1599.205,スタッフ,料理を運ぶ,40,15.3,5.95,16.965,5.5145,,60.0494,あきらめた
fam_p5_s4_r0_a42,1,2796.823,客,ドリンクバー,8,1.763,10.513,1.7833,9.0255,A01,60,移した
fam_p5_s4_r0_a42,1,2884.458,スタッフ,料理を運ぶ,16,5.212,10.513,5.042,8.0817,A02,60.0494,あきらめた
fam_p5_s4_r0_a42,1,3596.703,客,ドリンクバー,16,18.8,3.9,5.212,10.513,A02,0,あきらめた
fam_p5_s4_r0_a42,1,3622.829,客,ドリンクバー,8,18.8,3.9,1.763,10.513,A01,0,あきらめた
fam_p5_s4_r0_a42,1,3630.386,客,ドリンクバー,8,1.763,10.513,1.8058,8.4435,A01,60,移した
fam_p5_s4_r0_a42,1,4058.504,客,ドリンクバー,7,1.763,8.662,1.8279,7.7771,A01,60,移した
fam_p5_s4_r0_a42,1,5227.254,組,会計,17,5.113,13.888,5.113,13.888,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,5684.76,組,片付け,14,5.212,6.812,5.212,6.812,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,5774.508,組,片付け,11,5.212,8.662,5.212,8.662,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,5864.256,組,片付け,13,5.212,4.962,5.212,4.962,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,5954.004,組,片付け,15,5.212,8.662,5.212,8.662,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6088.577,組,片付け,18,8.662,4.962,8.662,4.962,A03,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6295.266,客,ドリンクバー,3,1.763,8.462,1.9,6.5202,A01,60,移した
fam_p5_s4_r0_a42,1,6297.458,客,ドリンクバー,4,1.763,10.312,1.8931,6.479,A01,60,移した
fam_p5_s4_r0_a42,1,6323.555,組,片付け,22,8.888,12.688,8.888,12.688,A03,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6356.227,客,ドリンクバー,3,1.763,8.462,1.7838,7.5037,A01,60,移した
fam_p5_s4_r0_a42,1,6592.799,組,片付け,23,8.662,4.962,8.662,4.962,A03,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6682.547,組,片付け,20,8.662,8.662,8.662,8.662,A03,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6789.528,客,ドリンクバー,40,18.8,3.9,21.362,2.188,,0,あきらめた
fam_p5_s4_r0_a42,1,6802.875,客,ドリンクバー,29,18.8,3.9,12.338,8.662,,0,あきらめた
fam_p5_s4_r0_a42,1,6834.85,客,ドリンクバー,11,18.8,3.9,5.212,8.662,A02,0,あきらめた
fam_p5_s4_r0_a42,1,6845.807,組,片付け,25,8.662,8.662,8.662,8.662,A03,600.027,卓を空けた
fam_p5_s4_r0_a42,1,6902.435,客,ドリンクバー,8,1.763,10.513,1.8039,7.2219,A01,60,移した
fam_p5_s4_r0_a42,1,7196.382,客,ドリンクバー,5,18.8,3.9,1.763,4.962,A01,0,あきらめた
fam_p5_s4_r0_a42,1,7472.649,客,ドリンクバー,10,18.8,3.9,5.212,6.812,A02,0,あきらめた
fam_p5_s4_r0_a42,1,7672.416,客,ドリンクバー,8,1.763,10.513,1.8903,5.0091,A01,60,移した
fam_p5_s4_r0_a42,1,7736.166,客,ドリンクバー,6,1.763,6.812,1.9338,4.5788,,60,移した
fam_p5_s4_r0_a42,1,7983.645,客,ドリンクバー,8,1.763,10.513,1.83,6.067,A01,60,移した
fam_p5_s4_r0_a42,1,8006.107,客,ドリンクバー,8,1.763,10.513,1.8357,8.4333,A01,60,移した
fam_p5_s4_r0_a42,1,8316.889,組,会計,7,1.763,8.662,1.763,8.662,A01,600.027,卓を空けた
fam_p5_s4_r0_a42,1,8381.087,組,会計,12,5.212,10.513,5.212,10.513,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,8428.949,組,会計,9,5.212,4.962,5.212,4.962,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,8461.422,組,会計,10,5.212,6.812,5.212,6.812,A02,600.027,卓を空けた
fam_p5_s4_r0_a42,1,8658.798,客,ドリンクバー,16,5.212,10.513,5.2111,10.0397,A02,60,移した
20261023_stageB_fam_p5_r0_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r0_a42,1,1,1,34,2,43.2696,43.2696,117.0225,3009.526,3009.531,3110.479,3110.479,1.2292,0,Done
fam_p5_s4_r0_a42,1,2,2,35,2,175.5261,175.5261,250.4807,2390.516,2390.527,2491.976,2491.976,1.2492,0,Done
fam_p5_s4_r0_a42,1,3,2,36,2,194.3773,194.3773,271.0273,2863.305,2863.338,2985.507,2985.507,1.2775,0,Done
fam_p5_s4_r0_a42,1,4,3,1,4,396.7966,396.7966,459.7313,3583.543,3635.491,3829.23,3829.23,1.0489,0,Done
fam_p5_s4_r0_a42,1,5,1,37,2,437.2867,437.2867,517.5671,3547.028,3547.055,3739.042,3739.042,1.338,0,Done
fam_p5_s4_r0_a42,1,6,4,2,4,704.7714,704.7714,768.8558,3708.958,3708.963,4009.606,4009.606,1.0681,0,Done
fam_p5_s4_r0_a42,1,7,2,38,2,724.3167,724.3167,805.9967,3515.885,3515.925,3637.493,3637.493,1.3613,0,Done20261023_stageB_fam_p5_r0_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p5_r0_s1/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 01:55:25",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット0台・種2(cs:140):20261023_stageB_fam_p5_r0_s2
20261023_stageB_fam_p5_r0_s2/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:04:20",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 1.1089, "dish_wait_p90": 2.0162, "cold_share": 0.0266, "seat_wait_mean": 0, "turn_mean": 6.3915, "robot_share": 0, "robot_dishes": 0, "staff_dishes": 188, "requeued_dishes": 0, "late_staff_dishes": 0, "late_staff_share": 0, "robot_first_wait_s": 120, "yields": 0, "yields_by_robot": 0, "yields_by_staff": 0, "yields_by_guest": 0, "yields_stepped_aside": 0, "yields_in_corner": 0, "yields_passed": 0, "yield_wait_s": 0, "yield_wait_mean_s": 0, "staff_yields": 0, "staff_yield_wait_s": 0, "staff_yield_mean_s": 0, "staff_yield_share_of_staff_time": 0, "staff_time_total_s": 42011.32, "corner_stops": 0, "corner_stop_s": 0, "corner_stop_count_share": 0, "corner_stop_time_share": 0, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 74, "people_jams": 67, "robot_blocked_jams": 0, "robot_blocked_jam_share": 0, "chair_pulls": 152, "robot_contacts": 0, "robot_yield_waits": 0, "robot_yield_wait_s": 0, "robot_yield_detours": 0, "register_crowd_max": 8, "register_crowd_mean": 2.4861, "register_pay_count": 74, "register_pay_not_at_back": 0, "register_pay_off_spot": 0, "register_pay_offset_mean_m": 0, "register_pay_offset_max_m": 0, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 38, "drink_bar_gave_up": 5, "drink_bar_wait_mean": 0.6364, "drink_bar_wait_p90": 0.9692, "gave_up": 6, "warped": 19, "table_freed": 24, "people_jam_total_s": 70.25, "walkers_mean": 8.6468, "measured_minutes": 174.9274},
"site_metrics": {"entry_wait_mean": 1.6289, "full_wait_mean": 0, "staff_wait_mean": 0.4422, "blocked_wait_mean": 0, "guide_wait_mean": 0.4422, "seat_wait_mean": 0, "dish_wait_mean": 1.1089, "dish_wait_p90": 2.0162, "cold_share": 0.0266, "turn_mean": 6.3915, "walk_km_per_staff": 2.9547, "staff_util": 0.7291, "robot_util": 0, "robot_share": 0, "rescues": 0, "pauses": 0, "groups": 74},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r0_a42", "arrivals_minutes": 120, "total_minutes": 174.9274, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 0, "rescues_done": 0, "rescue_wait_s": 0, "gave_up": 6, "warped": 19, "table_freed": 24},
"site_result": {"dish_wait_mean": 0.6572, "dish_wait_p90": 1.3761, "cold_share": 0.0012, "seat_wait_mean": 3.775, "turn_mean": 10.152, "walk_km_per_staff": 2.8551, "staff_util": 0.7522, "robot_util": 0, "robot_share": 0, "robot_bus_share": 0, "collects": 0, "rescues": 0, "pauses": 0, "fragile_robot": 0, "groups": 85.625, "entry_wait_mean": 4.3607, "blocked_wait_mean": 3.568, "guide_wait_mean": 0.4037, "staff_wait_mean": 3.9717, "full_wait_mean": 0.207},20261023_stageB_fam_p5_r0_s2/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:04:20",
"condition_id": "fam_p5_s4_r0_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 0,
"seed": 2,
"trips_requested": 0,
"trips_done": 0,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10495.64,
"wall_seconds": 530.9297,
"speedup": 19.7684,
"frame_delta_s": {"count": 210359, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 210359, "mean": 0, "min": 0, "p50": 0, "p90": 0, "p99": 0, "max": 0},
"people_step_m": {"count": 210359, "mean": 0.0624, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 21.6844},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 71066,
"people_frames_over_005m_ratio": 0.3378,
"chair_pulls": 152,
"chair_pulls_by_reason": {"座る": 18, "食事中": 37, "ドリンクバー": 38, "トイレ": 4, "戻って座る": 21, "会計": 16, "退店": 18}
}
20261023_stageB_fam_p5_r0_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
20261023_stageB_fam_p5_r0_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
20261023_stageB_fam_p5_r0_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r0_a42,2,1,34,1,0,458.5815,458.5815,474.7276,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,2,35,2,0,581.7015,581.7015,597.8475,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,3,1,4,0,618.5425,618.5425,645.186,スタッフ,0,26.6435,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,4,36,3,0,679.6276,679.6276,696.1235,スタッフ,0,16.496,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,5,38,6,0,729.8653,729.8653,748.4608,スタッフ,0,18.5955,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,6,34,1,0,770.9553,770.9553,787.1013,スタッフ,0,16.1461,0,0,1,0,0,0
fam_p5_s4_r0_a42,2,7,39,7,0,829.191,829.191,848.8862,スタッフ,0,19.6952,0,0,1,0,0,020261023_stageB_fam_p5_r0_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
20261023_stageB_fam_p5_r0_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p5_r0_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r0_a42,2,1718.621,客,ドリンクバー,3,1.763,8.462,1.784,7.5034,A01,60,移した
fam_p5_s4_r0_a42,2,2819.145,客,ドリンクバー,8,1.763,10.513,1.8066,10.1666,A01,60,移した
fam_p5_s4_r0_a42,2,3145.763,客,ドリンクバー,3,1.763,8.462,1.8362,6.6131,A01,60,移した
fam_p5_s4_r0_a42,2,3152.52,客,ドリンクバー,4,1.763,10.312,1.8006,7.5359,A01,60,移した
fam_p5_s4_r0_a42,2,3192.159,客,ドリンクバー,3,1.763,8.462,1.8298,6.2737,A01,60,移した
fam_p5_s4_r0_a42,2,3211.077,客,ドリンクバー,2,1.763,6.613,1.9125,4.5984,,60,移した
fam_p5_s4_r0_a42,2,3351.214,客,ドリンクバー,7,1.763,8.662,1.7601,8.175,A01,60,移した20261023_stageB_fam_p5_r0_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r0_a42,2,1,2,34,2,31.8198,31.8198,106.5219,2265.863,2265.905,2378.365,2378.365,1.245,0,Done
fam_p5_s4_r0_a42,2,2,1,35,2,51.4195,51.4195,128.3232,2649.495,2649.529,2780.657,2780.657,1.2817,0,Done
fam_p5_s4_r0_a42,2,3,2,36,2,80.4203,80.4203,159.2251,3225.606,3225.641,3411.323,3411.323,1.3134,0,Done
fam_p5_s4_r0_a42,2,4,4,1,4,171.0758,171.0758,234.4797,2721.092,2721.099,2870.845,2870.845,1.0567,0,Done
fam_p5_s4_r0_a42,2,5,1,37,2,180.2264,180.2264,258.7803,3344.707,3344.708,3501.51,3501.51,1.3092,0,Done
fam_p5_s4_r0_a42,2,6,1,38,2,237.2799,237.2799,305.6189,2569.116,2569.151,2670.099,2670.099,1.139,0,Done
fam_p5_s4_r0_a42,2,7,2,39,2,252.6808,252.6808,333.3121,2788.795,2788.815,2961.033,2961.033,1.3439,0,Done20261023_stageB_fam_p5_r0_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
20261023_stageB_fam_p5_r0_s2/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:04:21",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット1台・種0(cs:140):20261023_stageB_fam_p5_r1_s0
20261023_stageB_fam_p5_r1_s0/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:13:27",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.829, "dish_wait_p90": 5.4148, "cold_share": 0.6406, "seat_wait_mean": 1.1555, "turn_mean": 4.9825, "robot_share": 0.5899, "robot_dishes": 128, "staff_dishes": 89, "requeued_dishes": 0, "late_staff_dishes": 89, "late_staff_share": 0.4101, "robot_first_wait_s": 120, "yields": 981, "yields_by_robot": 0, "yields_by_staff": 749, "yields_by_guest": 232, "yields_stepped_aside": 199, "yields_in_corner": 102, "yields_passed": 441, "yield_wait_s": 2575.449, "yield_wait_mean_s": 2.6253, "staff_yields": 749, "staff_yield_wait_s": 1717.842, "staff_yield_mean_s": 2.2935, "staff_yield_share_of_staff_time": 0.041, "staff_time_total_s": 41938.43, "corner_stops": 11, "corner_stop_s": 63.0995, "corner_stop_count_share": 0.055, "corner_stop_time_share": 0.055, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 86, "people_jams": 339, "robot_blocked_jams": 311, "robot_blocked_jam_share": 0.9174, "chair_pulls": 151, "robot_contacts": 58, "robot_yield_waits": 985, "robot_yield_wait_s": 2564.026, "robot_yield_detours": 9, "register_crowd_max": 10, "register_crowd_mean": 2.5519, "register_pay_count": 81, "register_pay_not_at_back": 1, "register_pay_off_spot": 29, "register_pay_offset_mean_m": 0.2079, "register_pay_offset_max_m": 10.8752, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 43, "drink_bar_gave_up": 11, "drink_bar_wait_mean": 0.6276, "drink_bar_wait_p90": 0.9965, "gave_up": 43, "warped": 49, "table_freed": 23, "people_jam_total_s": 370.1008, "walkers_mean": 9.6111, "measured_minutes": 174.6253},
"site_metrics": {"entry_wait_mean": 3.0575, "full_wait_mean": 0.0614, "staff_wait_mean": 1.7612, "blocked_wait_mean": 1.0941, "guide_wait_mean": 0.667, "seat_wait_mean": 1.1555, "dish_wait_mean": 3.829, "dish_wait_p90": 5.4148, "cold_share": 0.6406, "turn_mean": 4.9825, "walk_km_per_staff": 2.7368, "staff_util": 0.7726, "robot_util": 0.7943, "robot_share": 0.5899, "rescues": 9, "pauses": 191, "groups": 86},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 174.6253, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 403, "rescues_done": 8, "rescue_wait_s": 401.8561, "gave_up": 43, "warped": 49, "table_freed": 23},
"site_result": {"dish_wait_mean": 2.097, "dish_wait_p90": 3.1635, "cold_share": 0.1431, "seat_wait_mean": 0.8897, "turn_mean": 4.3635, "walk_km_per_staff": 1.9834, "staff_util": 0.6504, "robot_util": 0.7491, "robot_share": 0.7197, "robot_bus_share": 0, "collects": 0, "rescues": 0.85, "pauses": 20.2, "fragile_robot": 31.675, "groups": 83.525, "entry_wait_mean": 1.3295, "blocked_wait_mean": 0.7256, "guide_wait_mean": 0.2571, "staff_wait_mean": 0.9827, "full_wait_mean": 0.1641},20261023_stageB_fam_p5_r1_s0/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:13:27",
"condition_id": "fam_p5_s4_r1_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 1,
"seed": 0,
"trips_requested": 0,
"trips_done": 58,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10477.52,
"wall_seconds": 543.262,
"speedup": 19.2863,
"frame_delta_s": {"count": 209995, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 209995, "mean": 0.0141, "min": 0, "p50": 0, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 209995, "mean": 0.0643, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.1158},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 61928,
"people_frames_over_005m_ratio": 0.2949,
"chair_pulls": 151,
"chair_pulls_by_reason": {"座る": 18, "食事中": 30, "ドリンクバー": 36, "戻って座る": 28, "トイレ": 6, "会計": 17, "退店": 16}
}
20261023_stageB_fam_p5_r1_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r1_a42,0.95,normal,1,0,1,1,3,38.3101,65.3494,0.95,1,0.95,0,0,0,0,0.2813,0,3,0,,,0,0.5949,0,0,1,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,0,1,2,2,34.5752,61.9493,2.95,2,0.95;2,0,0,0,1,-0.0043,0,2;1,1,535.8627,626.2406,0,0.586,0,0,1,1,1,2,0.95
fam_p5_s4_r1_a42,0.95,normal,1,0,1,3,1,38.2651,65.5494,0.95,1,0.95,0,0,0,0,1.0121,0,1;3,2,567.5049;551.9088,738.2632;738.2632,0,0.5923,0,0,1,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,0,1,4,2,34.5602,59.0994,0.95,1,0.95,0,0,0,0,0.3877,0,2,2,707.7707;715.9187,853.885;853.885,0,0.5943,0,0,1,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,0,1,5,34,9.975,18.4,0.95,1,0.95,0,0,0,0,1.8655,0,34;35,1,858.3339,942.4634,0,0.5716,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,0,1,6,4,41.9399,76.8001,4.7,4,0.95;1.5;1.15;1.1,0,0,0,1,0.2081,0,4,2,920.8187;934.0654,1010.947;1010.947,0,0.5817,0,0,1,0,4,0,4.7
fam_p5_s4_r1_a42,0.95,normal,1,0,1,7,36,14.595,27.0999,1.4,2,0.95;0.45,0,0,0,1,0.4721,0,36;38,1,964.608,1112.88,0,0.5679,0,0,0,0,2,0,1.420261023_stageB_fam_p5_r1_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r1_a42,0,1,1,535.95,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,0,1,2,626.35,16.8547,5.8278,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.828,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,0,1,2,653.5,1.9101,4.7152,A01,1,人が立ち止まっていた,Staff01,0,2,自分で動き出した,46.2242,84.665,46.2242,1.05,0,0,0.95,0,1.925;4.579,1.763;6.613,PathComplete,3,0.025
fam_p5_s4_r1_a42,0,1,3,738.4,16.8551,5.8281,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.828,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,0,1,4,858.5,16.8552,5.8282,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.828,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,0,1,5,942.65,16.8538,5.8274,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.854;5.827,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,0,1,6,1011.15,16.8532,5.8242,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.853;5.824,15.3;5.95,PathComplete,2,0.02520261023_stageB_fam_p5_r1_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r1_a42,0,1,3,3,0,535.8627,535.9127,626.2406,ロボット,0.05,90.3279,0,0,0,0,0,0
fam_p5_s4_r1_a42,0,3,2,2,0,567.5049,626.2906,738.2632,ロボット,58.7856,111.9727,0,0,0,1,0,0
fam_p5_s4_r1_a42,0,2,1,1,0,551.9088,626.2906,738.2632,ロボット,74.3818,111.9727,0,0,0,1,0,0
fam_p5_s4_r1_a42,0,4,1,1,0,707.7707,738.3132,853.885,ロボット,30.5425,115.5718,0,0,0,1,0,0
fam_p5_s4_r1_a42,0,5,3,3,0,715.9187,738.3132,853.885,ロボット,22.3945,115.5718,0,0,0,1,0,0
fam_p5_s4_r1_a42,0,6,2,2,0,858.3339,858.3839,942.4634,ロボット,0.05,84.0795,0,0,0,0,0,0
fam_p5_s4_r1_a42,0,7,34,4,0,920.8187,942.5134,1010.947,ロボット,21.6947,68.4333,0,0,0,0,0,020261023_stageB_fam_p5_r1_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r1_a42,0,613.4437,スタッフ:Staff02,1,ロボット1号機,12.1738,5.191,,,1,3.45,1,1
fam_p5_s4_r1_a42,0,648.6851,スタッフ:Staff01,1,ロボット1号機,1.7344,4.7921,A01,,0,4.8,1,1
fam_p5_s4_r1_a42,0,653.5339,スタッフ:Staff01,1,ロボット1号機,1.9,5.213,A01,,0,2.4,0,1
fam_p5_s4_r1_a42,0,655.9833,スタッフ:Staff01,1,ロボット1号機,1.8841,7.3524,A01,,0,0.6,0,1
fam_p5_s4_r1_a42,0,657.7329,スタッフ:Staff01,1,ロボット1号機,1.8831,7.875,A01,,0,1.8,0,1
fam_p5_s4_r1_a42,0,661.1821,スタッフ:Staff01,1,ロボット1号機,1.8703,8.3148,A01,,0,1.35,0,1
fam_p5_s4_r1_a42,0,664.1813,スタッフ:Staff01,1,ロボット1号機,1.8646,8.3096,A01,,0,1.35,0,120261023_stageB_fam_p5_r1_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p5_r1_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r1_a42,0,1599.855,客,ドリンクバー,1,1.763,4.762,5.2641,3.8488,,60,移した
fam_p5_s4_r1_a42,0,1751.403,客,ドリンクバー,3,17.3,3.9,12.3429,3.8884,,60,あきらめた
fam_p5_s4_r1_a42,0,1957.554,客,ドリンクバー,2,1.763,6.613,1.5664,6.0959,A01,60,移した
fam_p5_s4_r1_a42,0,1985.531,客,ドリンクバー,38,18.8,3.9,19.162,2.188,,0,あきらめた
fam_p5_s4_r1_a42,0,2033.478,客,ドリンクバー,3,1.763,8.462,1.7166,6.0711,A01,60,移した
fam_p5_s4_r1_a42,0,2262.352,スタッフ,料理を運ぶ,11,15.3,5.95,5.5857,4.5035,,60.0494,あきらめた
fam_p5_s4_r1_a42,0,2358.395,客,ドリンクバー,6,1.763,6.812,6.671,3.8452,,60,移した20261023_stageB_fam_p5_r1_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r1_a42,0,1,4,1,4,56.4194,56.4194,119.2227,2333.03,2402.889,2496.08,2496.08,1.0467,0,Done
fam_p5_s4_r1_a42,0,2,3,2,4,95.8213,95.8213,161.2752,2430.124,2430.165,2603.534,2603.534,1.0909,0,Done
fam_p5_s4_r1_a42,0,3,4,3,4,103.0217,103.0217,171.1758,3047.394,3047.417,3142.51,3142.51,1.1359,0,Done
fam_p5_s4_r1_a42,0,4,2,34,2,334.1619,334.1619,407.9939,3371.106,3371.133,3488.047,3488.047,1.2305,0,Done
fam_p5_s4_r1_a42,0,5,1,35,2,424.5898,424.5898,499.2216,3493.101,3493.102,3717.371,3717.371,1.2439,0,Done
fam_p5_s4_r1_a42,0,6,4,4,4,434.8373,434.8373,504.5203,4017.549,4064.109,4420.518,4420.518,1.1614,0,Done
fam_p5_s4_r1_a42,0,7,1,36,2,485.9749,485.9749,563.106,3723.116,3723.127,3852.503,3852.503,1.2855,0,Done20261023_stageB_fam_p5_r1_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r1_a42,0,653.184,1.9,5.213,A01,,スタッフ:Staff01,0,1,8.5304
fam_p5_s4_r1_a42,0,696.7234,1.5187,5.4947,A01,,スタッフ:Staff01,0,1,9.3692
fam_p5_s4_r1_a42,0,729.3154,12.2913,3.9921,,,スタッフ:Staff01,0,1,8.8484
fam_p5_s4_r1_a42,0,1707.71,1.5296,8.9167,A01,,客:Guest(Clone),0,1,9.8865
fam_p5_s4_r1_a42,0,1747.099,8.9515,4.0078,,,客:Guest(Clone),0,1,9.9238
fam_p5_s4_r1_a42,0,2314.102,5.79,4.5482,,,スタッフ:Staff02,1,1,9.3881
fam_p5_s4_r1_a42,0,2407.693,5.2145,4.8819,A02,,スタッフ:Staff04,0,1,8.607620261023_stageB_fam_p5_r1_s0/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:13:28",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット1台・種1(cs:140):20261023_stageB_fam_p5_r1_s1
20261023_stageB_fam_p5_r1_s1/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:24:08",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.8111, "dish_wait_p90": 5.7478, "cold_share": 0.6463, "seat_wait_mean": 7.0182, "turn_mean": 6.1382, "robot_share": 0.6179, "robot_dishes": 152, "staff_dishes": 94, "requeued_dishes": 1, "late_staff_dishes": 94, "late_staff_share": 0.3821, "robot_first_wait_s": 120, "yields": 2839, "yields_by_robot": 0, "yields_by_staff": 2560, "yields_by_guest": 279, "yields_stepped_aside": 211, "yields_in_corner": 74, "yields_passed": 583, "yield_wait_s": 3219.434, "yield_wait_mean_s": 1.134, "staff_yields": 2560, "staff_yield_wait_s": 2367.006, "staff_yield_mean_s": 0.9246, "staff_yield_share_of_staff_time": 0.0481, "staff_time_total_s": 49197.57, "corner_stops": 18, "corner_stop_s": 200.7483, "corner_stop_count_share": 0.0841, "corner_stop_time_share": 0.1584, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 95, "people_jams": 726, "robot_blocked_jams": 688, "robot_blocked_jam_share": 0.9477, "chair_pulls": 199, "robot_contacts": 58, "robot_yield_waits": 2845, "robot_yield_wait_s": 3186.583, "robot_yield_detours": 10, "register_crowd_max": 9, "register_crowd_mean": 2.7665, "register_pay_count": 92, "register_pay_not_at_back": 0, "register_pay_off_spot": 13, "register_pay_offset_mean_m": 0.034, "register_pay_offset_max_m": 0.275, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 39, "drink_bar_gave_up": 16, "drink_bar_wait_mean": 0.6274, "drink_bar_wait_p90": 0.9965, "gave_up": 56, "warped": 60, "table_freed": 35, "people_jam_total_s": 786.3948, "walkers_mean": 10.7722, "measured_minutes": 204.855},
"site_metrics": {"entry_wait_mean": 9.0647, "full_wait_mean": 3.0797, "staff_wait_mean": 4.7009, "blocked_wait_mean": 3.9385, "guide_wait_mean": 0.7623, "seat_wait_mean": 7.0182, "dish_wait_mean": 3.8111, "dish_wait_p90": 5.7478, "cold_share": 0.6463, "turn_mean": 6.1382, "walk_km_per_staff": 2.8305, "staff_util": 0.7322, "robot_util": 0.7773, "robot_share": 0.6179, "rescues": 9, "pauses": 205, "groups": 95},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 204.855, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 2144, "rescues_done": 9, "rescue_wait_s": 477.1989, "gave_up": 56, "warped": 60, "table_freed": 35},
"site_result": {"dish_wait_mean": 2.097, "dish_wait_p90": 3.1635, "cold_share": 0.1431, "seat_wait_mean": 0.8897, "turn_mean": 4.3635, "walk_km_per_staff": 1.9834, "staff_util": 0.6504, "robot_util": 0.7491, "robot_share": 0.7197, "robot_bus_share": 0, "collects": 0, "rescues": 0.85, "pauses": 20.2, "fragile_robot": 31.675, "groups": 83.525, "entry_wait_mean": 1.3295, "blocked_wait_mean": 0.7256, "guide_wait_mean": 0.2571, "staff_wait_mean": 0.9827, "full_wait_mean": 0.1641},20261023_stageB_fam_p5_r1_s1/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:24:08",
"condition_id": "fam_p5_s4_r1_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 1,
"seed": 1,
"trips_requested": 0,
"trips_done": 71,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 12291.3,
"wall_seconds": 636.6443,
"speedup": 19.3064,
"frame_delta_s": {"count": 246413, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 246413, "mean": 0.0148, "min": 0, "p50": 0.005, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 246413, "mean": 0.0623, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 22.3113},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 67844,
"people_frames_over_005m_ratio": 0.2753,
"chair_pulls": 199,
"chair_pulls_by_reason": {"座る": 22, "食事中": 37, "ドリンクバー": 52, "戻って座る": 42, "会計": 20, "退店": 20, "トイレ": 6}
}
20261023_stageB_fam_p5_r1_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r1_a42,0.95,normal,1,1,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.6613,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,1,1,2,35,9.42,17.2,0.95,1,0.95,0,0,0,0,0.3905,0,35,1,571.7039,614.0436,0,0.5797,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,1,1,3,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.8641,0,36,1,805.5468,847.7865,0,0.5814,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,1,1,4,35,9.48,17.3,0.95,1,0.95,0,0,0,0,2.2997,0,35,1,860.1335,903.8728,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,1,1,5,37,38.1151,67.1995,2.3,2,0.95;1.35,0,0,0,1,-0.0003,0,37;1,1,877.7292,946.2125,0,0.5873,0,0,1,0,2,0,2.3
fam_p5_s4_r1_a42,0.95,normal,1,1,1,6,34,11.415,20.8,0.95,1,0.95,0,0,0,0,1.527,0,34;36,2,938.6643;937.3646,1063.532;1063.532,0,0.5751,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,1,1,7,38,14.61,26.8499,1.4,2,0.95;0.45,0,0,0,1,0.8693,0,38,2,1044.113;990.9016,1134.501;1134.501,0,0.5741,0,0,0,0,2,0,1.420261023_stageB_fam_p5_r1_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r1_a42,1,1,1,571.8,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,2,805.7,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,3,860.3,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,4,904.05,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,5,946.4,16.8509,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,5,984.55,17.3622,2.2933,,0,スタッフとすれ違った,Staff02,0,1.35,自分で動き出した,67.2012,26.155,26.155,0.4,0,0,0.95,0,17.838;2.227,2.062;4.413,PathComplete,2,0.025
fam_p5_s4_r1_a42,1,1,6,1063.7,16.8517,5.8257,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.826,15.3;5.95,PathComplete,2,0.02520261023_stageB_fam_p5_r1_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r1_a42,1,1,34,1,0,571.7039,571.7539,614.0436,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p5_s4_r1_a42,1,2,35,2,0,805.5468,805.5968,847.7865,ロボット,0.05,42.1897,0,0,0,0,0,0
fam_p5_s4_r1_a42,1,3,36,3,0,860.1335,860.1835,903.8728,ロボット,0.05,43.6893,0,0,0,0,0,0
fam_p5_s4_r1_a42,1,4,35,2,0,877.7292,903.9228,946.2125,ロボット,26.1936,42.2897,0,0,0,0,0,0
fam_p5_s4_r1_a42,1,6,37,5,0,938.6643,946.2625,1063.532,ロボット,7.5981,117.2695,0,0,0,1,0,0
fam_p5_s4_r1_a42,1,5,1,4,0,937.3646,946.2625,1063.532,ロボット,8.8978,117.2695,0,0,0,1,0,0
fam_p5_s4_r1_a42,1,8,34,1,0,1044.113,1063.582,1134.501,ロボット,19.469,70.9192,0,0,0,0,0,020261023_stageB_fam_p5_r1_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r1_a42,1,809.7458,スタッフ:Staff02,1,ロボット1号機,16.2292,2.9764,,,0,4.45,1,1
fam_p5_s4_r1_a42,1,983.6533,スタッフ:Staff02,1,ロボット1号機,17.0839,2.55,,,0,0.8,1,1
fam_p5_s4_r1_a42,1,1029.048,スタッフ:Staff01,1,ロボット1号機,0.8315,2.2428,,,0,9.3,0,1
fam_p5_s4_r1_a42,1,1231.846,スタッフ:Staff01,1,ロボット1号機,0.9715,2.2874,,,0,27.2499,0,1
fam_p5_s4_r1_a42,1,1338.7,スタッフ:Staff01,1,ロボット1号機,11.6525,4.5501,,,1,4.3,1,1
fam_p5_s4_r1_a42,1,1348.41,スタッフ:Staff01,1,ロボット1号機,8.582,3.7025,,,0,0.15,1,1
fam_p5_s4_r1_a42,1,1528.085,スタッフ:Staff01,1,ロボット1号機,5.3004,4.737,,,0,4.65,1,120261023_stageB_fam_p5_r1_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r1_a42,1,5979.006,123,8,1,0,5196.027,782.9795,1,打ち切り
20261023_stageB_fam_p5_r1_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r1_a42,1,2246.436,客,ドリンクバー,3,18.3,3.9,1.5765,9.1469,A01,60,あきらめた
fam_p5_s4_r1_a42,1,2253.993,客,ドリンクバー,8,19.3,3.9,1.6619,7.629,A01,60,あきらめた
fam_p5_s4_r1_a42,1,2279.018,客,ドリンクバー,3,17.3,3.9,2.0144,4.4849,,60,あきらめた
fam_p5_s4_r1_a42,1,2393.63,客,ドリンクバー,3,1.763,8.462,1.8786,6.3029,A01,60,移した
fam_p5_s4_r1_a42,1,2407.743,客,ドリンクバー,9,18.8,3.9,5.212,4.962,A02,0,あきらめた
fam_p5_s4_r1_a42,1,2409.996,客,ドリンクバー,6,18.8,3.9,1.763,6.812,A01,0,あきらめた
fam_p5_s4_r1_a42,1,2410.046,客,ドリンクバー,2,18.8,3.9,1.763,6.613,A01,0,あきらめた20261023_stageB_fam_p5_r1_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r1_a42,1,1,1,34,2,43.2696,43.2696,117.0225,2907.41,2907.431,3008.379,3008.379,1.2292,0,Done
fam_p5_s4_r1_a42,1,2,2,35,2,175.5261,175.5261,250.4807,2497.401,2497.431,2594.826,2594.826,1.2492,0,Done
fam_p5_s4_r1_a42,1,3,2,36,2,194.3773,194.3773,271.0273,2934.902,2934.908,3110.279,3110.279,1.2775,0,Done
fam_p5_s4_r1_a42,1,4,3,1,4,396.7966,396.7966,459.5813,2633.847,2633.864,2815.792,2815.792,1.0464,0,Done
fam_p5_s4_r1_a42,1,5,1,37,2,437.2867,437.2867,517.7171,3245.286,3245.311,3380.392,3380.392,1.3405,0,Done
fam_p5_s4_r1_a42,1,6,4,2,4,704.7714,704.7714,769.0557,3719.792,3776.279,3918.467,3918.467,1.0714,0,Done
fam_p5_s4_r1_a42,1,7,2,38,2,724.3167,724.3167,805.8967,3219.277,3544.302,3776.579,3776.579,1.3597,0,Done20261023_stageB_fam_p5_r1_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r1_a42,1,983.8033,17.1119,2.5404,,,スタッフ:Staff02,0,1,7.1286
fam_p5_s4_r1_a42,1,2232.522,1.9,8.95,A01,,客:Guest(Clone),0,1,9.6352
fam_p5_s4_r1_a42,1,2233.023,1.5,8.8997,A01,,客:Guest(Clone),0,1,9.7608
fam_p5_s4_r1_a42,1,2424.56,15.5003,5.322,,,スタッフ:Staff02,0,1,7.4862
fam_p5_s4_r1_a42,1,2466.301,19.3228,2.55,,,スタッフ:Staff03,0,1,8.4812
fam_p5_s4_r1_a42,1,2595.877,19.6048,1.67,,,スタッフ:Staff04,0,1,9.861
fam_p5_s4_r1_a42,1,2598.279,19.162,2.188,,,客:Guest(Clone),0,1,3.769320261023_stageB_fam_p5_r1_s1/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:24:09",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット1台・種2(cs:140):20261023_stageB_fam_p5_r1_s2
20261023_stageB_fam_p5_r1_s2/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:34:39",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.5781, "dish_wait_p90": 5.0456, "cold_share": 0.6626, "seat_wait_mean": 9.8752, "turn_mean": 4.6387, "robot_share": 0.6585, "robot_dishes": 162, "staff_dishes": 84, "requeued_dishes": 0, "late_staff_dishes": 84, "late_staff_share": 0.3415, "robot_first_wait_s": 120, "yields": 1232, "yields_by_robot": 0, "yields_by_staff": 1086, "yields_by_guest": 146, "yields_stepped_aside": 171, "yields_in_corner": 60, "yields_passed": 364, "yield_wait_s": 2312.087, "yield_wait_mean_s": 1.8767, "staff_yields": 1086, "staff_yield_wait_s": 1764.56, "staff_yield_mean_s": 1.6248, "staff_yield_share_of_staff_time": 0.0367, "staff_time_total_s": 48041.5, "corner_stops": 13, "corner_stop_s": 67.4995, "corner_stop_count_share": 0.0703, "corner_stop_time_share": 0.0852, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 99, "people_jams": 228, "robot_blocked_jams": 189, "robot_blocked_jam_share": 0.8289, "chair_pulls": 221, "robot_contacts": 33, "robot_yield_waits": 1238, "robot_yield_wait_s": 2291.66, "robot_yield_detours": 12, "register_crowd_max": 10, "register_crowd_mean": 3.1105, "register_pay_count": 89, "register_pay_not_at_back": 1, "register_pay_off_spot": 12, "register_pay_offset_mean_m": 0.1528, "register_pay_offset_max_m": 11.0499, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 37, "drink_bar_gave_up": 19, "drink_bar_wait_mean": 0.6443, "drink_bar_wait_p90": 0.9965, "gave_up": 40, "warped": 56, "table_freed": 22, "people_jam_total_s": 323.2992, "walkers_mean": 11.7758, "measured_minutes": 200.0514},
"site_metrics": {"entry_wait_mean": 11.4668, "full_wait_mean": 6.8818, "staff_wait_mean": 3.353, "blocked_wait_mean": 2.9934, "guide_wait_mean": 0.3596, "seat_wait_mean": 9.8752, "dish_wait_mean": 3.5781, "dish_wait_p90": 5.0456, "cold_share": 0.6626, "turn_mean": 4.6387, "walk_km_per_staff": 3.0049, "staff_util": 0.7539, "robot_util": 0.7679, "robot_share": 0.6585, "rescues": 2, "pauses": 183, "groups": 99},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r1_a42", "arrivals_minutes": 120, "total_minutes": 200.0514, "everyone_left": true, "aisle_deferrals": 0, "staff_first_yield": true, "robot_stuck_detours": 775, "rescues_done": 2, "rescue_wait_s": 105.999, "gave_up": 40, "warped": 56, "table_freed": 22},
"site_result": {"dish_wait_mean": 2.097, "dish_wait_p90": 3.1635, "cold_share": 0.1431, "seat_wait_mean": 0.8897, "turn_mean": 4.3635, "walk_km_per_staff": 1.9834, "staff_util": 0.6504, "robot_util": 0.7491, "robot_share": 0.7197, "robot_bus_share": 0, "collects": 0, "rescues": 0.85, "pauses": 20.2, "fragile_robot": 31.675, "groups": 83.525, "entry_wait_mean": 1.3295, "blocked_wait_mean": 0.7256, "guide_wait_mean": 0.2571, "staff_wait_mean": 0.9827, "full_wait_mean": 0.1641},20261023_stageB_fam_p5_r1_s2/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:34:39",
"condition_id": "fam_p5_s4_r1_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 1,
"seed": 2,
"trips_requested": 0,
"trips_done": 70,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 12003.08,
"wall_seconds": 626.5444,
"speedup": 19.1576,
"frame_delta_s": {"count": 240626, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 240626, "mean": 0.0162, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 240626, "mean": 0.0631, "min": 0, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 22.1156},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 72169,
"people_frames_over_005m_ratio": 0.2999,
"chair_pulls": 221,
"chair_pulls_by_reason": {"座る": 23, "食事中": 53, "ドリンクバー": 51, "トイレ": 10, "戻って座る": 44, "退店": 20, "会計": 20}
}
20261023_stageB_fam_p5_r1_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r1_a42,0.95,normal,1,2,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.528,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,2,1,2,35,9.42,18.3,2.05,2,0.95;1.1,0,0,0,0,1.5276,0,35,1,458.5815,500.9212,0,0.5797,0,0,0,0,2,0,2.05
fam_p5_s4_r1_a42,0.95,normal,1,2,1,3,1,30.9903,53.1495,0.95,1,0.95,0,0,0,0,1.4069,0,1,1,581.7015,625.0409,0,0.5937,0,0,1,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,2,1,4,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.5284,0,36,1,618.5425,703.2218,0,0.5814,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,2,1,5,38,14.61,26.8499,1.4,2,0.95;0.45,0,0,0,1,1.8677,0,38,1,679.6276,746.9611,0,0.5741,0,0,0,0,2,0,1.4
fam_p5_s4_r1_a42,0.95,normal,1,2,1,6,34,9.45,17.25,0.95,1,0.95,0,0,0,0,1.8675,0,34,1,729.8653,798.8484,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r1_a42,0.95,normal,1,2,1,7,39,16.83,30.5498,1.4,2,0.95;0.45,0,0,0,1,1.5284,0,39,1,770.9553,841.1381,0,0.5774,0,0,0,0,2,0,1.420261023_stageB_fam_p5_r1_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r1_a42,2,1,1,458.65,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,2,581.8,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,2,616.15,15.8394,2.4362,,0,椅子・荷物・ベビーカー,Table35/Chair,0,1.1,自分で動き出した,275,275,275,0.15,0,0,0.95,0,15.839;2.436,15.3;4.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,3,625.15,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,4,703.35,16.8534,5.8271,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.853;5.827,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,5,747.1,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r1_a42,2,1,5,786.9,18.5359,2.2299,,0,椅子・荷物・ベビーカー,Table37/Chair,0,0.45,自分で動き出した,88.1099,32.0672,32.0672,0,0,0,0.45,0,18.925;2.212,16.738;2.312,PathComplete,2,0.02520261023_stageB_fam_p5_r1_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r1_a42,2,1,34,1,0,458.5815,458.6315,500.9212,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,2,35,2,0,581.7015,581.7515,625.0409,ロボット,0.05,43.2894,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,3,1,4,0,618.5425,625.0909,703.2218,ロボット,6.5484,78.1309,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,4,36,3,0,679.6276,703.2718,746.9611,ロボット,23.6442,43.6893,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,5,38,6,0,729.8653,747.0111,798.8484,ロボット,17.1458,51.8373,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,6,34,1,0,770.9553,798.8984,841.1381,ロボット,27.9432,42.2397,0,0,0,0,0,0
fam_p5_s4_r1_a42,2,7,39,7,0,829.191,841.1881,896.7245,ロボット,11.9971,55.5364,0,0,0,0,0,020261023_stageB_fam_p5_r1_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r1_a42,2,1219.534,スタッフ:Staff02,1,ロボット1号機,1.1815,2.0505,,,0,2.4,0,1
fam_p5_s4_r1_a42,2,1370.331,スタッフ:Staff01,1,ロボット1号機,0.9972,2.3704,,,0,4.65,0,1
fam_p5_s4_r1_a42,2,1380.892,スタッフ:Staff04,1,ロボット1号機,8.7748,4.5327,,,0,4.6,1,1
fam_p5_s4_r1_a42,2,1824.975,スタッフ:Staff01,1,ロボット1号機,7.1216,3.7646,,,0,1.35,1,1
fam_p5_s4_r1_a42,2,1894.192,客:Guest(Clone),2,ロボット1号機,1.8292,6.6849,A01,,0,1.45,0,1
fam_p5_s4_r1_a42,2,1897.145,客:Guest(Clone),2,ロボット1号機,1.8698,6.6877,A01,,0,1.45,0,1
fam_p5_s4_r1_a42,2,1900.098,客:Guest(Clone),2,ロボット1号機,1.8885,6.6902,A01,,0,1.45,0,120261023_stageB_fam_p5_r1_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
20261023_stageB_fam_p5_r1_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r1_a42,2,1639.644,客,トイレ,39,20.263,2.188,16.9231,2.55,,60,移した
fam_p5_s4_r1_a42,2,2233.674,客,ドリンクバー,4,1.763,10.312,5.0283,12.5296,A02,60,移した
fam_p5_s4_r1_a42,2,2374.261,客,ドリンクバー,3,1.763,8.462,2.6944,4.5235,,60,移した
fam_p5_s4_r1_a42,2,2613.694,客,ドリンクバー,4,1.763,10.312,1.8494,6.2985,A01,60,移した
fam_p5_s4_r1_a42,2,2761.438,客,トイレ,40,21.362,2.188,19.2833,2.313,,60,移した
fam_p5_s4_r1_a42,2,2967.69,客,ドリンクバー,12,5.212,10.513,8.4326,4.5227,,60,移した
fam_p5_s4_r1_a42,2,2993.515,客,ドリンクバー,7,1.763,8.662,1.8258,5.5513,A01,60,移した20261023_stageB_fam_p5_r1_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r1_a42,2,1,2,34,2,31.8198,31.8198,106.5219,3306.932,3306.971,3635.191,3635.191,1.245,0,Done
fam_p5_s4_r1_a42,2,2,1,35,2,51.4195,51.4195,128.3232,3218.687,3218.735,3430.992,3430.992,1.2817,0,Done
fam_p5_s4_r1_a42,2,3,2,36,2,80.4203,80.4203,159.2251,2963.829,2963.836,3065.085,3065.085,1.3134,0,Done
fam_p5_s4_r1_a42,2,4,4,1,4,171.0758,171.0758,234.4797,3411.172,3411.172,3737.791,3737.791,1.0567,0,Done
fam_p5_s4_r1_a42,2,5,1,37,2,180.2264,180.2264,258.7803,3136.643,3136.655,3238.104,3238.104,1.3092,0,Done
fam_p5_s4_r1_a42,2,6,1,38,2,237.2799,237.2799,305.6189,3144.737,3144.762,3340.804,3340.804,1.139,0,Done
fam_p5_s4_r1_a42,2,7,2,39,2,252.6808,252.6808,333.3121,3281.247,3281.296,3533.742,3533.742,1.3439,0,Done20261023_stageB_fam_p5_r1_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r1_a42,2,2533.566,1.6903,10.7195,A01,,客:Guest(Clone),0,1,-0.338
fam_p5_s4_r1_a42,2,2736.714,13.596,5.649,,,スタッフ:Staff02,1,1,9.8296
fam_p5_s4_r1_a42,2,3143.912,5.7226,4.5296,,,客:Guest(Clone),0,1,9.7386
fam_p5_s4_r1_a42,2,3316.88,7.689,4.0428,,,客:Guest(Clone),1,1,9.274
fam_p5_s4_r1_a42,2,3329.443,8.4352,4.8297,A03,,客:Guest(Clone),0,1,9.3689
fam_p5_s4_r1_a42,2,3440.501,8.8586,2.4322,,,客:Guest(Clone),1,1,8.7432
fam_p5_s4_r1_a42,2,3791.694,16.8938,5.6415,,,スタッフ:Staff01,0,1,9.0987
fam_p5_s4_r1_a42,2,4090.635,15.3497,4.5117,,,客:Guest(Clone),0,1,9.0227
fam_p5_s4_r1_a42,2,4141.811,16.712,2.3397,,,客:Guest(Clone),0,1,9.8193
fam_p5_s4_r1_a42,2,5284.53,5.5149,4.4988,,,スタッフ:Staff01,0,1,9.3817
fam_p5_s4_r1_a42,2,5362.175,2.6448,4.1278,,,スタッフ:Staff03,0,1,8.9837
fam_p5_s4_r1_a42,2,5640.683,8.662,4.962,A03,,スタッフ:Staff03,0,1,9.5086
fam_p5_s4_r1_a42,2,5655.525,17.2915,5.8553,,ロボット待機,客:Guest(Clone),0,1,8.3288
fam_p5_s4_r1_a42,2,5679.68,5.3,5.213,A02,,スタッフ:Staff01,0,1,9.2201
fam_p5_s4_r1_a42,2,6437.558,8.5438,12.7656,A03,,スタッフ:Staff04,0,1,9.8517
fam_p5_s4_r1_a42,2,7273.331,14.1323,4.2391,,,スタッフ:Staff01,0,1,9.4933
fam_p5_s4_r1_a42,2,7571.113,13.745,6.9131,,,客:Guest(Clone),0,1,8.9288
fam_p5_s4_r1_a42,2,7641.437,8.6564,6.5886,A03,,客:Guest(Clone),0,1,-0.1825
fam_p5_s4_r1_a42,2,8103.824,8.662,4.962,A03,,スタッフ:Staff04,0,1,9.1766
fam_p5_s4_r1_a42,2,8260.062,5.0768,4.8298,A02,,客:Guest(Clone),0,1,0.4702
fam_p5_s4_r1_a42,2,8725.984,4.1448,4.5495,,,客:Guest(Clone),0,1,9.8711
fam_p5_s4_r1_a42,2,8802.385,15.366,5.1423,,,スタッフ:Staff04,0,1,9.8747
fam_p5_s4_r1_a42,2,8958.522,9.3487,4.5193,,,スタッフ:Staff01,1,1,9.9528
fam_p5_s4_r1_a42,2,8986.762,8.4,4.812,A03,,スタッフ:Staff02,0,1,8.204
fam_p5_s4_r1_a42,2,8988.555,8.75,5.0103,A03,,客:Guest(Clone),0,1,9.9343
fam_p5_s4_r1_a42,2,8988.953,8.4,4.8161,A03,,客:Guest(Clone),0,1,8.4753
fam_p5_s4_r1_a42,2,8990.945,8.4,4.8055,A03,,客:Guest(Clone),0,1,7.7831
fam_p5_s4_r1_a42,2,9100.366,5.3773,4.5127,,,スタッフ:Staff02,0,1,8.9885
fam_p5_s4_r1_a42,2,9275.031,1.8715,5.4833,A01,,スタッフ:Staff03,0,1,9.6773
fam_p5_s4_r1_a42,2,9343.712,5.2775,5.0018,A02,,スタッフ:Staff04,0,1,8.9657
fam_p5_s4_r1_a42,2,9605.485,15.8799,1.9902,,,客:Guest(Clone),0,1,-0.1622
fam_p5_s4_r1_a42,2,9679.794,11.2821,4.5263,,,スタッフ:Staff04,1,1,8.9959
fam_p5_s4_r1_a42,2,9960.991,16.5039,6.25,,ロボット待機,スタッフ:Staff04,0,1,9.8582
20261023_stageB_fam_p5_r1_s2/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:34:40",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット2台・種0(cs:140):20261023_stageB_fam_p5_r2_s0
20261023_stageB_fam_p5_r2_s0/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 00:19:48",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.9381, "dish_wait_p90": 6.411, "cold_share": 0.5882, "seat_wait_mean": 13.1139, "turn_mean": 4.6651, "robot_share": 0.7463, "robot_dishes": 203, "staff_dishes": 69, "requeued_dishes": 6, "late_staff_dishes": 69, "late_staff_share": 0.2537, "robot_first_wait_s": 120, "yields": 3706, "yields_by_robot": 81, "yields_by_staff": 2871, "yields_by_guest": 754, "yields_stepped_aside": 338, "yields_in_corner": 165, "yields_passed": 1010, "yield_wait_s": 7812.228, "yield_wait_mean_s": 2.108, "staff_yields": 2871, "staff_yield_wait_s": 3519.451, "staff_yield_mean_s": 1.2259, "staff_yield_share_of_staff_time": 0.0676, "staff_time_total_s": 52085.65, "corner_stops": 41, "corner_stop_s": 816.2423, "corner_stop_count_share": 0.093, "corner_stop_time_share": 0.1488, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 106, "people_jams": 937, "robot_blocked_jams": 873, "robot_blocked_jam_share": 0.9317, "chair_pulls": 194, "robot_contacts": 103, "robot_yield_waits": 3643, "robot_yield_wait_s": 5838.139, "robot_yield_detours": 22, "register_crowd_max": 11, "register_crowd_mean": 2.5893, "register_pay_count": 91, "register_pay_not_at_back": 1, "register_pay_off_spot": 20, "register_pay_offset_mean_m": 0.1717, "register_pay_offset_max_m": 11.6886, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 45, "drink_bar_gave_up": 25, "drink_bar_wait_mean": 0.8231, "drink_bar_wait_p90": 1.003, "gave_up": 106, "warped": 107, "table_freed": 45, "people_jam_total_s": 1178.843, "walkers_mean": 11.6432, "measured_minutes": 216.8588},
"site_metrics": {"entry_wait_mean": 15.0673, "full_wait_mean": 9.85, "staff_wait_mean": 3.9569, "blocked_wait_mean": 3.2639, "guide_wait_mean": 0.693, "seat_wait_mean": 13.1139, "dish_wait_mean": 3.9381, "dish_wait_p90": 6.411, "cold_share": 0.5882, "turn_mean": 4.6651, "walk_km_per_staff": 3.0054, "staff_util": 0.7428, "robot_util": 0.7209, "robot_share": 0.7463, "rescues": 61, "pauses": 380, "groups": 106},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 216.8588, "everyone_left": true, "aisle_deferrals": 38, "staff_first_yield": true, "robot_stuck_detours": 2336, "rescues_done": 59, "rescue_wait_s": 2414.564, "gave_up": 106, "warped": 107, "table_freed": 45},
"site_result": {"dish_wait_mean": 1.0497, "dish_wait_p90": 2.1196, "cold_share": 0.0157, "seat_wait_mean": 1.191, "turn_mean": 3.9675, "walk_km_per_staff": 1.6822, "staff_util": 0.6219, "robot_util": 0.6062, "robot_share": 0.9898, "robot_bus_share": 0, "collects": 0, "rescues": 1.575, "pauses": 43.25, "fragile_robot": 42.05, "groups": 84.4, "entry_wait_mean": 1.5915, "blocked_wait_mean": 0.7992, "guide_wait_mean": 0.2173, "staff_wait_mean": 1.0166, "full_wait_mean": 0.3917},20261023_stageB_fam_p5_r2_s0/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 00:19:48",
"condition_id": "fam_p5_s4_r2_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 0,
"trips_requested": 0,
"trips_done": 116,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 13011.53,
"wall_seconds": 968.6135,
"speedup": 13.4332,
"frame_delta_s": {"count": 260874, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 260874, "mean": 0.0171, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 260874, "mean": 0.0596, "min": 0, "p50": 0.0488, "p90": 0.05, "p99": 0.05, "max": 22.2371},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 70431,
"people_frames_over_005m_ratio": 0.27,
"chair_pulls": 194,
"chair_pulls_by_reason": {"座る": 22, "食事中": 44, "ドリンクバー": 37, "戻って座る": 38, "トイレ": 10, "会計": 20, "退店": 23}
}
20261023_stageB_fam_p5_r2_s0/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r2_a42,0.95,normal,2,0,1,1,3,38.3101,72.3498,7.4,2,0.95;6.45,0,0,0,1,0.3044,1,3,0,,,0,0.5898,0,0,1,0,2,0,7.4
fam_p5_s4_r2_a42,0.95,normal,2,0,2,2,2,36.8551,70.0497,6.7,3,0.95;4.25;1.5,0,0,0,1,0.2015,1,2;1,0,,,0,0.5818,0,0,1,0,3,0,6.7
fam_p5_s4_r2_a42,0.95,normal,2,0,1,3,1,30.9903,58.5994,5.85,2,0.95;4.9,0,0,0,1,0.3,1,1,1,535.8627,633.2389,0,0.5875,0,0,1,0,2,0,5.85
fam_p5_s4_r2_a42,0.95,normal,2,0,2,4,3,40.5,73.6999,4.55,3,0.95;2.7;0.9,0,0,0,1,0.1242,1,3,2,567.5049;551.9088,720.2676;720.2676,0,0.5857,0,0,1,0,3,0,4.55
fam_p5_s4_r2_a42,0.95,normal,2,0,1,5,2,34.5602,59.0994,0.95,1,0.95,0,0,0,0,0.3665,0,2,1,707.7707,791.4003,0,0.5943,0,0,1,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,0,2,6,34,11.04,19.9,0.95,1,0.95,0,0,0,0,1.8748,0,34,1,715.9187,858.3839,0,0.5826,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,0,1,7,35,9.42,17.2,0.95,1,0.95,0,0,0,0,1.8655,0,35,1,858.3339,942.4634,0,0.5797,0,0,0,0,1,0,0.9520261023_stageB_fam_p5_r2_s0/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r2_a42,0,1,1,535.95,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,1,613.9,9.9748,4.4422,,0,もう1台のロボット,ServingRobot02,0,6.45,自分で動き出した,10.7894,239.2553,10.7894,5.5,0,0,0.95,0,1.869;4.627,11.663;4.413,PathComplete,3,0.025
fam_p5_s4_r2_a42,0,2,2,600.25,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,2,2,613.9,10.6933,4.4889,,0,もう1台のロボット,ServingRobot01,0,4.25,自分で動き出した,243.8956,6.1157,6.1157,2.75,0,0,1.5,0,10.693;4.489,10.693;3.563,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,2,2,621.65,9.6325,3.8784,,0,人が立ち止まっていた,Staff02,0,1.5,自分で動き出した,183.6672,67.5228,67.5228,0.55,0,0,0.95,0,9.635;3.878,1.788;4.612,PathComplete,3,0.025
fam_p5_s4_r2_a42,0,1,3,707.9,16.8547,5.8278,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.855;5.828,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,0,1,3,773.5,9.8795,4.4437,,0,もう1台のロボット,ServingRobot02,0,4.9,自分で動き出した,10.6361,239.4083,10.6361,3.95,0,0,0.95,0,1.904;4.603,11.663;4.413,PathComplete,3,0.02520261023_stageB_fam_p5_r2_s0/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r2_a42,0,1,3,3,0,535.8627,535.9127,633.2389,ロボット,0.05,97.3262,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,3,2,2,0,567.5049,600.197,720.2676,ロボット,32.692,120.0707,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,2,1,1,0,551.9088,600.197,720.2676,ロボット,48.2882,120.0707,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,4,1,1,0,707.7707,707.8207,791.4003,ロボット,0.05,83.5796,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,5,3,3,0,715.9187,759.708,858.3839,ロボット,43.7893,98.6759,0,0,0,1,0,1
fam_p5_s4_r2_a42,0,6,2,2,0,858.3339,858.3839,942.4634,ロボット,0.05,84.0795,0,0,0,0,0,0
fam_p5_s4_r2_a42,0,7,34,4,0,920.8187,920.8687,965.7577,ロボット,0.05,44.889,0,0,0,0,0,020261023_stageB_fam_p5_r2_s0/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r2_a42,0,613.4937,スタッフ:Staff02,1,ロボット1号機,12.1911,5.1843,,,1,0.4,1,1
fam_p5_s4_r2_a42,0,615.2933,ロボット2号機,0,ロボット1号機,10.6933,4.4889,,,1,6.25,1,1
fam_p5_s4_r2_a42,0,618.5425,スタッフ:Staff02,1,ロボット2号機,8.759,3.5983,,,0,3.1,1,1
fam_p5_s4_r2_a42,0,623.1414,スタッフ:Staff02,1,ロボット2号機,7.5374,3.5214,,,0,3.6,1,1
fam_p5_s4_r2_a42,0,644.4362,スタッフ:Staff01,1,ロボット2号機,0.8,2.0331,,,0,49.3495,0,1
fam_p5_s4_r2_a42,0,700.4725,スタッフ:Staff04,1,ロボット2号機,9.1349,4.1216,,,0,4.45,1,1
fam_p5_s4_r2_a42,0,712.3196,スタッフ:Staff01,1,ロボット1号機,12.3279,5.2423,,,1,4.35,1,120261023_stageB_fam_p5_r2_s0/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r2_a42,0,1998.694,19,41,2,0,1340.152,658.5425,1,打ち切り
fam_p5_s4_r2_a42,0,1998.694,21,6,2,0,1386.998,611.6968,1,打ち切り
fam_p5_s4_r2_a42,0,1998.694,20,5,2,0,1383.644,615.05,1,打ち切り
fam_p5_s4_r2_a42,0,4079.374,96,8,1,1,3469.93,609.4446,1,打ち切り
fam_p5_s4_r2_a42,0,8865.338,228,7,1,0,8256.625,608.7129,1,打ち切り
fam_p5_s4_r2_a42,0,11126.22,268,13,2,1,10528.47,597.7559,1,打ち切り
20261023_stageB_fam_p5_r2_s0/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r2_a42,0,1649.003,スタッフ,立ち往生を動かす,0,19.9017,2.2971,19.478,2.2272,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1709.162,スタッフ,立ち往生を動かす,0,19.8963,2.2254,19.491,2.1325,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1769.321,スタッフ,立ち往生を動かす,0,19.8971,2.1577,19.5726,1.9322,,60.0494,移した
fam_p5_s4_r2_a42,0,1869.919,スタッフ,料理を運ぶ,39,20.263,2.188,20.1266,1.5681,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1915.563,スタッフ,立ち往生を動かす,0,19.8982,2.2617,19.4777,2.2168,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,1937.585,スタッフ,料理を運ぶ,39,20.263,2.188,20.1266,1.5681,,60.0494,あきらめた
fam_p5_s4_r2_a42,0,2104.498,スタッフ,案内,29,0.9,2.1,1.138,1.7818,,60.0494,あきらめた20261023_stageB_fam_p5_r2_s0/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r2_a42,0,1,4,1,4,56.4194,56.4194,119.2227,2888.754,2888.763,3016.587,3016.587,1.0467,0,Done
fam_p5_s4_r2_a42,0,2,3,2,4,95.8213,95.8213,161.2752,2967.573,2967.59,3119.288,3119.288,1.0909,0,Done
fam_p5_s4_r2_a42,0,3,4,3,4,103.0217,103.0217,171.1758,2427.404,2507.291,2610.041,2610.041,1.1359,0,Done
fam_p5_s4_r2_a42,0,4,2,34,2,334.1619,334.1619,407.9939,3285.866,3285.9,3392.454,3392.454,1.2305,0,Done
fam_p5_s4_r2_a42,0,5,1,35,2,424.5898,424.5898,499.2216,3273.117,3328.191,3482.642,3482.642,1.2439,0,Done
fam_p5_s4_r2_a42,0,6,4,4,4,434.8373,434.8373,504.5203,2756.216,2812.839,2913.787,2913.787,1.1614,0,Done
fam_p5_s4_r2_a42,0,7,1,0,0,485.9749,485.9749,563.106,4099.78,4099.826,4410.458,4410.458,1.2855,0,Done20261023_stageB_fam_p5_r2_s0/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r2_a42,0,1769.321,19.8971,2.1577,,,スタッフ:Staff01,0,2,-11.0752
fam_p5_s4_r2_a42,0,1939.036,19.83,1.8975,,,スタッフ:Staff03,0,2,9.5874
fam_p5_s4_r2_a42,0,2010.606,19.3033,1.8115,,,スタッフ:Staff03,0,2,9.1367
fam_p5_s4_r2_a42,0,2035.931,8.7003,4.9307,A03,,スタッフ:Staff01,0,1,9.203
fam_p5_s4_r2_a42,0,2139.882,6.013,4.55,,,スタッフ:Staff02,0,1,8.4005
fam_p5_s4_r2_a42,0,2423.108,6.5916,4.55,,,客:Guest(Clone),0,2,9.5148
fam_p5_s4_r2_a42,0,2500.384,7.6921,3.9542,,,客:Guest(Clone),0,1,9.608820261023_stageB_fam_p5_r2_s0/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 00:19:49",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット2台・種1(cs:140):20261023_stageB_fam_p5_r2_s1
20261023_stageB_fam_p5_r2_s1/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:44:07",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.0426, "dish_wait_p90": 5.6579, "cold_share": 0.3923, "seat_wait_mean": 0, "turn_mean": 3.6482, "robot_share": 0.7569, "robot_dishes": 137, "staff_dishes": 44, "requeued_dishes": 2, "late_staff_dishes": 44, "late_staff_share": 0.2431, "robot_first_wait_s": 120, "yields": 2265, "yields_by_robot": 156, "yields_by_staff": 1855, "yields_by_guest": 254, "yields_stepped_aside": 402, "yields_in_corner": 192, "yields_passed": 783, "yield_wait_s": 3780.708, "yield_wait_mean_s": 1.6692, "staff_yields": 1855, "staff_yield_wait_s": 1923.324, "staff_yield_mean_s": 1.0368, "staff_yield_share_of_staff_time": 0.0448, "staff_time_total_s": 42954.96, "corner_stops": 51, "corner_stop_s": 756.6434, "corner_stop_count_share": 0.1121, "corner_stop_time_share": 0.216, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 71, "people_jams": 341, "robot_blocked_jams": 318, "robot_blocked_jam_share": 0.9326, "chair_pulls": 155, "robot_contacts": 65, "robot_yield_waits": 2114, "robot_yield_wait_s": 2659.619, "robot_yield_detours": 4, "register_crowd_max": 9, "register_crowd_mean": 2.2577, "register_pay_count": 69, "register_pay_not_at_back": 0, "register_pay_off_spot": 0, "register_pay_offset_mean_m": 0, "register_pay_offset_max_m": 0, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 26, "drink_bar_gave_up": 11, "drink_bar_wait_mean": 0.8114, "drink_bar_wait_p90": 1.002, "gave_up": 57, "warped": 46, "table_freed": 4, "people_jam_total_s": 929.2074, "walkers_mean": 8.2911, "measured_minutes": 178.8562},
"site_metrics": {"entry_wait_mean": 1.7955, "full_wait_mean": 0, "staff_wait_mean": 0.5522, "blocked_wait_mean": 0, "guide_wait_mean": 0.5522, "seat_wait_mean": 0, "dish_wait_mean": 3.0426, "dish_wait_p90": 5.6579, "cold_share": 0.3923, "turn_mean": 3.6482, "walk_km_per_staff": 2.5108, "staff_util": 0.6973, "robot_util": 0.6137, "robot_share": 0.7569, "rescues": 32, "pauses": 423, "groups": 71},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 178.8562, "everyone_left": true, "aisle_deferrals": 33, "staff_first_yield": true, "robot_stuck_detours": 1377, "rescues_done": 30, "rescue_wait_s": 1259.462, "gave_up": 57, "warped": 46, "table_freed": 4},
"site_result": {"dish_wait_mean": 1.0497, "dish_wait_p90": 2.1196, "cold_share": 0.0157, "seat_wait_mean": 1.191, "turn_mean": 3.9675, "walk_km_per_staff": 1.6822, "staff_util": 0.6219, "robot_util": 0.6062, "robot_share": 0.9898, "robot_bus_share": 0, "collects": 0, "rescues": 1.575, "pauses": 43.25, "fragile_robot": 42.05, "groups": 84.4, "entry_wait_mean": 1.5915, "blocked_wait_mean": 0.7992, "guide_wait_mean": 0.2173, "staff_wait_mean": 1.0166, "full_wait_mean": 0.3917},20261023_stageB_fam_p5_r2_s1/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:44:07",
"condition_id": "fam_p5_s4_r2_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 1,
"trips_requested": 0,
"trips_done": 102,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 10731.37,
"wall_seconds": 563.2718,
"speedup": 19.0519,
"frame_delta_s": {"count": 215092, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 215092, "mean": 0.021, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 215092, "mean": 0.0578, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 21.9068},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 60036,
"people_frames_over_005m_ratio": 0.2791,
"chair_pulls": 155,
"chair_pulls_by_reason": {"座る": 18, "食事中": 33, "ドリンクバー": 40, "トイレ": 3, "戻って座る": 27, "会計": 16, "退店": 18}
}
20261023_stageB_fam_p5_r2_s1/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r2_a42,0.95,normal,2,1,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.6613,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,1,1,2,35,9.42,17.2,0.95,1,0.95,0,0,0,0,0.3905,0,35,1,571.7039,614.0436,0,0.5797,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,1,1,3,36,10.32,20.05,1.75,2,0.95;0.8,0,0,0,1,1.8641,1,36,1,805.5468,847.7865,0,0.5639,0,0,0,0,2,0,1.75
fam_p5_s4_r2_a42,0.95,normal,2,1,2,4,35,11.07,19.95,0.95,1,0.95,0,0,0,0,1.8514,0,35,0,,,0,0.5826,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,1,2,5,37,13.95,26.5499,2.2,2,1.45;0.75,0,0,0,1,0.192,1,37,1,877.7292,922.7182,0,0.5729,0,0,0,0,2,0,2.2
fam_p5_s4_r2_a42,0.95,normal,2,1,1,6,1,30.9903,53.1495,0.95,1,0.95,0,0,0,0,0.3439,0,1,1,860.1335,905.2225,0,0.5937,0,0,1,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,1,2,7,36,11.85,23.3499,2.5,2,0.95;1.55,0,0,0,1,0.054,0,36,1,938.6643,990.2517,0,0.5683,0,0,0,0,2,0,2.520261023_stageB_fam_p5_r2_s1/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r2_a42,1,1,1,571.8,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,1,2,805.7,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,1,3,860.3,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,1,3,896.55,16.4921,2.561,,0,もう1台のロボット,ServingRobot02,0,0.8,自分で動き出した,275,28.52,28.52,0,0,0,0.8,0,16.566;2.413,15.3;4.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,2,4,877.9,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,2,5,938.85,17.6507,5.8081,,0,分からない,,0,1.45,自分で動き出した,275,275,275,0.05,0,0,1.4,0,17.651;5.808,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,1,2,5,979.5,16.9415,2.2973,,0,スタッフとすれ違った,Staff02,0,0.75,自分で動き出した,205.9846,25.5404,25.5404,0,0,0,0.75,0,16.979;2.293,16.562;2.337,PathComplete,2,0.02520261023_stageB_fam_p5_r2_s1/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r2_a42,1,1,34,1,0,571.7039,571.7539,614.0436,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,2,35,2,0,805.5468,805.5968,847.7865,ロボット,0.05,42.1897,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,3,36,3,0,860.1335,860.1835,905.2225,ロボット,0.05,45.039,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,4,35,2,0,877.7292,877.7792,922.7182,ロボット,0.05,44.939,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,6,37,5,0,938.6643,938.7143,990.2517,ロボット,0.05,51.5374,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,5,1,4,0,937.3646,937.4146,1015.546,ロボット,0.05,78.1309,0,0,0,0,0,0
fam_p5_s4_r2_a42,1,7,36,3,0,990.9016,990.9515,1039.308,ロボット,0.05,48.3568,0,0,0,0,0,020261023_stageB_fam_p5_r2_s1/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r2_a42,1,809.7458,スタッフ:Staff02,1,ロボット1号機,16.2292,2.9764,,,0,4.45,1,1
fam_p5_s4_r2_a42,1,942.8633,スタッフ:Staff01,1,ロボット1号機,11.846,4.5818,,,1,4.5,1,1
fam_p5_s4_r2_a42,1,977.9547,スタッフ:Staff02,1,ロボット2号機,15.4982,2.5401,,,0,1.45,1,1
fam_p5_s4_r2_a42,1,991.9513,スタッフ:Staff02,1,ロボット2号機,16.1673,5.507,,,0,2.7,1,1
fam_p5_s4_r2_a42,1,995.6504,スタッフ:Staff02,1,ロボット2号機,15.5151,5.21,,,0,0.9,1,1
fam_p5_s4_r2_a42,1,1159.926,スタッフ:Staff02,1,ロボット1号機,16.963,2.188,,,0,3.3,1,1
fam_p5_s4_r2_a42,1,1371.082,スタッフ:Staff01,1,ロボット1号機,1.1745,1.9902,,,0,26.8499,0,120261023_stageB_fam_p5_r2_s1/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r2_a42,1,2025.821,14,39,1,0,1423.383,602.4377,1,打ち切り
fam_p5_s4_r2_a42,1,4269.062,67,24,1,0,3662.267,606.7947,1,打ち切り
20261023_stageB_fam_p5_r2_s1/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r2_a42,1,1994.14,スタッフ,料理を運ぶ,38,19.162,2.188,19.8488,1.7469,,60.0494,あきらめた
fam_p5_s4_r2_a42,1,2171.713,客,ドリンクバー,4,17.3,3.9,1.5,8.7816,A01,60,あきらめた
fam_p5_s4_r2_a42,1,2355.292,客,ドリンクバー,3,1.763,8.462,16.7934,4.2389,,60,移した
fam_p5_s4_r2_a42,1,2397.934,客,ドリンクバー,4,1.763,10.312,1.8129,7.2132,A01,60,移した
fam_p5_s4_r2_a42,1,2408.644,客,ドリンクバー,3,1.763,8.462,3.4776,3.8763,,60,移した
fam_p5_s4_r2_a42,1,2647.627,客,ドリンクバー,4,1.763,10.312,1.6692,8.5861,A01,60,移した
fam_p5_s4_r2_a42,1,2895.82,客,ドリンクバー,8,1.763,10.513,1.8344,7.0906,A01,60,移した20261023_stageB_fam_p5_r2_s1/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r2_a42,1,1,1,34,2,43.2696,43.2696,117.0225,3035.702,3035.706,3162.88,3162.88,1.2292,0,Done
fam_p5_s4_r2_a42,1,2,2,35,2,175.5261,175.5261,250.4807,2417.659,2417.703,2541.073,2541.073,1.2492,0,Done
fam_p5_s4_r2_a42,1,3,2,36,2,194.3773,194.3773,271.0273,2895.216,2895.219,3040.761,3040.761,1.2775,0,Done
fam_p5_s4_r2_a42,1,4,3,1,4,396.7966,396.7966,459.5813,3639.698,3694.699,4007.554,4007.554,1.0464,0,Done
fam_p5_s4_r2_a42,1,5,1,37,2,437.2867,437.2867,517.7171,3579.379,3579.386,3736.99,3736.99,1.3405,0,Done
fam_p5_s4_r2_a42,1,6,4,2,4,704.7714,704.7714,769.0557,4192.173,4192.213,4575.211,4575.211,1.0714,0,Done
fam_p5_s4_r2_a42,1,7,2,38,2,724.3167,724.3167,805.8967,4257.831,4257.856,4664.959,4664.959,1.3597,0,Done20261023_stageB_fam_p5_r2_s1/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r2_a42,1,996.2502,15.5107,5.136,,,スタッフ:Staff02,0,2,8.8108
fam_p5_s4_r2_a42,1,1967.264,19.747,1.9502,,,スタッフ:Staff04,0,2,8.5594
fam_p5_s4_r2_a42,1,2007.403,18.6984,1.93,,,スタッフ:Staff02,0,1,8.48
fam_p5_s4_r2_a42,1,2018.414,19.3184,1.762,,,スタッフ:Staff02,0,1,9.9276
fam_p5_s4_r2_a42,1,2030.575,15.7244,3.5639,,,スタッフ:Staff03,1,1,7.6105
fam_p5_s4_r2_a42,1,2036.681,17.6227,1.9391,,,スタッフ:Staff02,0,1,9.4694
fam_p5_s4_r2_a42,1,2093.587,6.0698,4.4254,,,スタッフ:Staff03,0,1,9.482320261023_stageB_fam_p5_r2_s1/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:44:08",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},段階B ⑦・ロボット2台・種2(cs:140):20261023_stageB_fam_p5_r2_s2
20261023_stageB_fam_p5_r2_s2/summary.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:54:53",
"note": "speed_mps = distance_m / (total_s - stopped_s)。stopped_s には、動けなくなった60秒と、スタッフを待った秒数(stuck_wait_s)、通路の入口で待った秒数も入る。pause_s は stop_durations_s(自分で動き出した止まりだけ)の分布。site_metrics はサイトの meta.metrics と同じ名前・同じ定義。入店待ちの分け方もサイトの試算と同じで、blocked_wait は片付け待ちの卓の数だけ待っている列の前から順に足した分、full_wait は seat_wait − blocked_wait、staff_wait は blocked_wait + guide_wait。pauses と rescues は、サイト側が unity_measures の仮の値から出した数なので出どころが違う。",
"sim_like": {"dish_wait_mean": 3.6097, "dish_wait_p90": 5.7172, "cold_share": 0.5118, "seat_wait_mean": 10.8884, "turn_mean": 4.875, "robot_share": 0.7953, "robot_dishes": 202, "staff_dishes": 52, "requeued_dishes": 2, "late_staff_dishes": 52, "late_staff_share": 0.2047, "robot_first_wait_s": 120, "yields": 2964, "yields_by_robot": 156, "yields_by_staff": 2289, "yields_by_guest": 519, "yields_stepped_aside": 566, "yields_in_corner": 290, "yields_passed": 1104, "yield_wait_s": 5729.725, "yield_wait_mean_s": 1.9331, "staff_yields": 2289, "staff_yield_wait_s": 2765.17, "staff_yield_mean_s": 1.208, "staff_yield_share_of_staff_time": 0.0546, "staff_time_total_s": 50649.73, "corner_stops": 28, "corner_stop_s": 168.8495, "corner_stop_count_share": 0.0477, "corner_stop_time_share": 0.0325, "corner_range": "x 10.5-13.5 / z 3.5-5.8", "groups": 102, "people_jams": 807, "robot_blocked_jams": 766, "robot_blocked_jam_share": 0.9492, "chair_pulls": 224, "robot_contacts": 116, "robot_yield_waits": 2818, "robot_yield_wait_s": 4329.604, "robot_yield_detours": 12, "register_crowd_max": 9, "register_crowd_mean": 2.5289, "register_pay_count": 95, "register_pay_not_at_back": 0, "register_pay_off_spot": 23, "register_pay_offset_mean_m": 0.054, "register_pay_offset_max_m": 0.2996, "register_back_intruders": 0, "register_back_intruder_s": 0, "drink_bar_queued": 35, "drink_bar_gave_up": 9, "drink_bar_wait_mean": 0.6241, "drink_bar_wait_p90": 0.9965, "gave_up": 69, "warped": 84, "table_freed": 33, "people_jam_total_s": 1475.655, "walkers_mean": 11.2208, "measured_minutes": 210.9038},
"site_metrics": {"entry_wait_mean": 12.6712, "full_wait_mean": 7.1859, "staff_wait_mean": 4.2409, "blocked_wait_mean": 3.7024, "guide_wait_mean": 0.5385, "seat_wait_mean": 10.8884, "dish_wait_mean": 3.6097, "dish_wait_p90": 5.7172, "cold_share": 0.5118, "turn_mean": 4.875, "walk_km_per_staff": 2.8439, "staff_util": 0.7384, "robot_util": 0.7056, "robot_share": 0.7953, "rescues": 49, "pauses": 538, "groups": 102},
"site_run": {"site_run": true, "condition_id": "fam_p5_s4_r2_a42", "arrivals_minutes": 120, "total_minutes": 210.9038, "everyone_left": true, "aisle_deferrals": 35, "staff_first_yield": true, "robot_stuck_detours": 1641, "rescues_done": 49, "rescue_wait_s": 1548.744, "gave_up": 69, "warped": 84, "table_freed": 33},
"site_result": {"dish_wait_mean": 1.0497, "dish_wait_p90": 2.1196, "cold_share": 0.0157, "seat_wait_mean": 1.191, "turn_mean": 3.9675, "walk_km_per_staff": 1.6822, "staff_util": 0.6219, "robot_util": 0.6062, "robot_share": 0.9898, "robot_bus_share": 0, "collects": 0, "rescues": 1.575, "pauses": 43.25, "fragile_robot": 42.05, "groups": 84.4, "entry_wait_mean": 1.5915, "blocked_wait_mean": 0.7992, "guide_wait_mean": 0.2173, "staff_wait_mean": 1.0166, "full_wait_mean": 0.3917},20261023_stageB_fam_p5_r2_s2/run_info.json
{
"run_label": "stageB",
"written_at": "2026-10-24 02:54:53",
"condition_id": "fam_p5_s4_r2_a42",
"store_kind": "StoreLayout_p5_crammed",
"time_mode": "FixedStep",
"time_scale": 1,
"capture_delta_time": 0.05,
"aisle_width_m": 0.95,
"delivery_offset_m": 0,
"delivery_offset_used_m": 0,
"crowd": "normal",
"robots": 2,
"seed": 2,
"trips_requested": 0,
"trips_done": 118,
"stopped_early": false,
"one_robot_per_aisle": true,
"yield_order_enabled": true,
"unity_cs": "cs:140",
"pending_changes": "",
"staff_first_yield": true,
"sim_seconds": 12654.23,
"wall_seconds": 641.7984,
"speedup": 19.7168,
"frame_delta_s": {"count": 253700, "mean": 0.0499, "min": 0.02, "p50": 0.05, "p90": 0.05, "p99": 0.05, "max": 0.05},
"robot_step_m": {"count": 253700, "mean": 0.019, "min": 0, "p50": 0.03, "p90": 0.03, "p99": 0.03, "max": 0.03},
"people_step_m": {"count": 253700, "mean": 0.0613, "min": 0, "p50": 0.0493, "p90": 0.05, "p99": 0.05, "max": 21.7868},
"frames_over_005m": 0,
"frames_over_005m_ratio": 0,
"people_frames_over_005m": 67836,
"people_frames_over_005m_ratio": 0.2674,
"chair_pulls": 224,
"chair_pulls_by_reason": {"座る": 23, "食事中": 59, "ドリンクバー": 54, "トイレ": 7, "戻って座る": 39, "会計": 20, "退店": 22}
}
20261023_stageB_fam_p5_r2_s2/trips.csv
condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s
fam_p5_s4_r2_a42,0.95,normal,2,2,1,1,34,9.48,17.3,0.95,1,0.95,0,0,0,0,1.528,0,34,0,,,0,0.5798,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,2,1,2,35,9.42,18.3,2.05,2,0.95;1.1,0,0,0,0,1.5276,0,35,1,458.5815,500.9212,0,0.5797,0,0,0,0,2,0,2.05
fam_p5_s4_r2_a42,0.95,normal,2,2,2,3,1,32.6103,55.8494,0.95,1,0.95,0,0,0,0,1.5618,0,1,0,,,0,0.594,0,0,1,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,2,1,4,36,10.32,18.7,0.95,1,0.95,0,0,0,0,1.8641,0,36,1,581.7015,625.0409,0,0.5814,0,0,0,0,1,0,0.95
fam_p5_s4_r2_a42,0.95,normal,2,2,1,5,38,14.61,88.0008,61.4494,4,0.95;0.45;4.5;55.5494,0,0,0,1,1.5315,1,38,1,679.6276,723.3669,0,0.5503,0,0,0,0,4,0,61.4494
fam_p5_s4_r2_a42,0.95,normal,2,2,2,6,34,7.4725,51.7495,36.6497,5,0.95;2.75;30.7998;0.8;1.35,0,0,0,1,1.8754,1,34,1,618.4925,699.3727,0,0.4949,0,0,0,0,5,0,36.6498
fam_p5_s4_r2_a42,0.95,normal,2,2,2,7,37,13.95,24.7499,0.95,1,0.95,0,0,0,0,1.5395,0,37,1,770.9553,847.7365,0,0.5861,0,0,0,0,1,0,0.9520261023_stageB_fam_p5_r2_s2/stops.csv
condition_id,seed,robot_id,trip_id,t_s,x,z,aisle,in_narrow,cause,cause_detail,path_blocked,duration_s,resolved,clearance_left_cm,clearance_right_cm,min_gap_cm,blocked_s,no_path_s,yield_s,clear_wait_s,replans,solve_from,solve_to,solve_status,solve_corners,off_mesh_m
fam_p5_s4_r2_a42,2,1,1,458.65,16.9,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.9;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,1,2,581.8,16.8519,5.8225,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.852;5.822,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,1,2,616.15,15.8394,2.4362,,0,椅子・荷物・ベビーカー,Table35/Chair,0,1.1,自分で動き出した,275,275,275,0.15,0,0,0.95,0,15.839;2.436,15.3;4.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,2,3,618.6,17.7,6.05,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,17.7;6.05,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,1,4,679.75,16.851,5.8214,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.851;5.821,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,1,5,730,16.8575,5.833,,0,分からない,,0,0.95,自分で動き出した,275,275,275,0,0,0,0.95,0,16.858;5.833,15.3;5.95,PathComplete,2,0.025
fam_p5_s4_r2_a42,2,1,5,769.8,18.5359,2.2299,,0,椅子・荷物・ベビーカー,Table37/Chair,0,0.45,自分で動き出した,88.1099,32.0672,32.0672,0,0,0,0.45,0,18.925;2.212,16.738;2.312,PathComplete,2,0.02520261023_stageB_fam_p5_r2_s2/dishes.csv
condition_id,seed,dish_id,table_id,group_id,fragile,ready_s,first_taken_s,arrived_s,carried_by,pass_wait_s,carry_s,requeue_lost_s,requeued,staff_from_start,robot_wait_expired,late_staff_pickup,deferred_for_aisle
fam_p5_s4_r2_a42,2,1,34,1,0,458.5815,458.6315,500.9212,ロボット,0.05,42.2897,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,2,35,2,0,581.7015,581.7515,625.0409,ロボット,0.05,43.2894,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,3,1,4,0,618.4925,618.5425,699.3727,ロボット,0.05,80.8303,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,4,36,3,0,679.6276,679.6776,723.3669,ロボット,0.05,43.6893,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,5,38,6,0,729.8653,729.9153,842.8877,ロボット,0.05,112.9724,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,6,34,1,0,770.9553,771.0052,847.7365,ロボット,0.05,76.7313,0,0,0,0,0,0
fam_p5_s4_r2_a42,2,8,37,5,0,843.6375,847.7865,897.5244,ロボット,4.149,49.7379,0,0,0,0,0,020261023_stageB_fam_p5_r2_s2/yields.csv
condition_id,seed,t_s,who,rank,to_whom,x,z,aisle,place,in_corner,waited_s,stepped_aside,passed
fam_p5_s4_r2_a42,2,778.9533,ロボット2号機,0,ロボット1号機,15.4689,5.0553,,,0,30.0498,1,0
fam_p5_s4_r2_a42,2,836.0894,ロボット2号機,0,ロボット1号機,15.8227,5.0805,,,0,6.5,1,1
fam_p5_s4_r2_a42,2,1000.199,ロボット2号機,0,ロボット1号機,18.0213,2.3732,,,0,2.45,1,1
fam_p5_s4_r2_a42,2,1005.198,ロボット2号機,0,ロボット1号機,18.0992,1.8215,,,0,2,1,1
fam_p5_s4_r2_a42,2,1009.747,ロボット2号機,0,ロボット1号機,18.3403,1.9861,,,0,2.55,1,1
fam_p5_s4_r2_a42,2,1014.946,ロボット2号機,0,ロボット1号機,18.3705,2.1699,,,0,3,1,1
fam_p5_s4_r2_a42,2,1020.694,ロボット2号機,0,ロボット1号機,18.1804,2.3263,,,0,2.6,1,120261023_stageB_fam_p5_r2_s2/requeues.csv
condition_id,seed,t_s,dish_id,table_id,robot_id,fragile,ready_s,waited_s,requeued_so_far,why
fam_p5_s4_r2_a42,2,1585.741,10,40,2,0,985.103,600.6385,1,打ち切り
fam_p5_s4_r2_a42,2,4426.395,91,31,1,0,3741.194,685.2007,1,打ち切り
20261023_stageB_fam_p5_r2_s2/give_ups.csv
condition_id,seed,t_s,who,job,table_id,to_x,to_z,x,z,aisle,waited_s,action
fam_p5_s4_r2_a42,2,1664.618,スタッフ,案内,11,0.9,2.1,17.5653,2.5239,,60.0494,あきらめた
fam_p5_s4_r2_a42,2,1724.777,スタッフ,案内,11,0.9,2.1,17.5664,2.5339,,60.0494,あきらめた
fam_p5_s4_r2_a42,2,1789.791,スタッフ,案内,15,0.9,2.1,17.5667,2.5319,,60.0494,あきらめた
fam_p5_s4_r2_a42,2,1831.031,客,ドリンクバー,3,1.763,8.462,5.3107,4.2441,,60,移した
fam_p5_s4_r2_a42,2,1847.797,スタッフ,呼び出し,37,18.062,2.188,16.2086,2.8223,,60.0494,あきらめた
fam_p5_s4_r2_a42,2,1907.906,スタッフ,呼び出し,37,18.062,2.188,16.1842,2.7856,,60.0494,あきらめた
fam_p5_s4_r2_a42,2,1964.911,客,ドリンクバー,2,1.763,6.613,5.2281,4.2609,,60,移した20261023_stageB_fam_p5_r2_s2/groups.csv
condition_id,seed,group_id,size,table_id,table_seats,arrive_s,guide_start_s,seated_s,eat_end_s,pay_start_s,pay_s,left_s,waited_min,warmup,state
fam_p5_s4_r2_a42,2,1,2,34,2,31.8198,31.8198,106.5219,3313.53,3313.577,3449.109,3449.109,1.245,0,Done
fam_p5_s4_r2_a42,2,2,1,35,2,51.4195,51.4195,128.3232,2725.93,2725.954,2848.974,2848.974,1.2817,0,Done
fam_p5_s4_r2_a42,2,3,2,36,2,80.4203,80.4203,159.2251,2829.593,2829.605,2957.73,2957.73,1.3134,0,Done
fam_p5_s4_r2_a42,2,4,4,1,4,171.0758,171.0758,234.4297,2841.06,2841.066,3047.918,3047.918,1.0559,0,Done
fam_p5_s4_r2_a42,2,5,1,37,2,180.2264,180.2264,258.7803,3432.656,3432.693,3539.297,3539.297,1.3092,0,Done
fam_p5_s4_r2_a42,2,6,1,38,2,237.2799,237.2799,305.6189,3816.513,3816.518,3918.117,3918.117,1.139,0,Done
fam_p5_s4_r2_a42,2,7,2,39,2,252.6808,252.6808,333.3621,3246.686,3246.712,3343.957,3343.957,1.3447,0,Done20261023_stageB_fam_p5_r2_s2/contacts.csv
condition_id,seed,t_s,x,z,aisle,place,who,careless,robot_id,gap_cm
fam_p5_s4_r2_a42,2,1137.404,19.0982,2.55,,,スタッフ:Staff01,0,1,8.3968
fam_p5_s4_r2_a42,2,1291.204,17.5109,2.55,,,スタッフ:Staff01,0,2,9.8012
fam_p5_s4_r2_a42,2,1337.85,17.501,2.5479,,,スタッフ:Staff03,0,2,9.8821
fam_p5_s4_r2_a42,2,1421.281,17.5043,2.55,,,スタッフ:Staff04,0,2,9.9893
fam_p5_s4_r2_a42,2,1504.762,17.536,2.55,,,スタッフ:Staff01,0,2,9.1511
fam_p5_s4_r2_a42,2,1592.648,16.5624,2.3099,,,スタッフ:Staff02,0,2,7.9401
fam_p5_s4_r2_a42,2,1600.606,17.0565,2.0791,,,スタッフ:Staff02,0,2,8.943720261023_stageB_fam_p5_r2_s2/conditions.json
{
"run_name": "family_v0",
"written_at": "2026-10-24 02:54:54",
"unity_version": "2022.3.62f3",
"trips_csv_columns": "condition_id,aisle_width_m,crowd,robots,seed,robot_id,trip_id,table_id,distance_m,total_s,stopped_s,n_stops,stop_durations_s,stuck,timeout,wait_aisle_s,max_decel_mps2,min_clearance_m,met_robot,table_ids,dishes,dish_ready_s,dish_arrived_s,undelivered,speed_mps,stuck_count,stuck_wait_s,via_narrow,stops_in_narrow,stops_out_narrow,stopped_in_narrow_s,stopped_out_narrow_s",
"settings": {
"store_layout": {"aisleWidthOptions":[0.949999988079071],"aisleWidthIndex":0,"deliveryOffsetFromAisleCenter":0.0,"aisleEntranceSetback":0.800000011920929,"aisleEntranceSideOffset":0.44999998807907107,"wallHeight":2.700000047683716,"wallThickness":0.15000000596046449,"floorThickness":0.20000000298023225,"showAisleMarks":true,"aisleMarkThickness":0.019999999552965165,"showFloorPaint":true,"floorPaintCellSize":0.05000000074505806,"floorPaintHeight":0.029999999329447748,"navAgentRadius":0.25,"navAgentHeight":1.2000000476837159,"navAgentClimb":0.20000000298023225,"navAgentSlope":10.0,"navVoxelSize":0.05000000074505806,"navMinRegionArea":0.30000001192092898,"navBoundsPadding":1.0,"layoutJson":{"instanceID":13238},"summaryJson":{"instanceID":13240},"layoutFileName":"p5_crammed","fetchedAt":"2026-10-23 17:00:00 JST(版 82023936eb99)","sourceUrl":"https://pixelstomotors.com/sim/layouts/unity/p5_crammed.json","benchBackThickness":0.07999999821186066,"benchSeatInset":0.029999999329447748,"keepoutMarkThickness":0.019999999552965165},
"robot_spec": {"diameter":0.5,"height":1.2000000476837159,"maxSpeed":0.6000000238418579,"acceleration":1.0,"deceleration":1.0,"turnSpeedDegPerSec":180.0,"sensorRange":0.6000000238418579,"sensorWidth":0.5,"sensorHeight":1.2000000476837159,"resumeAfterClearSec":1.0,"replanAfterStoppedSec":10.0,"stuckAfterStoppedSec":60.0,"stuckRecoveryWaitSec":15.0,"maxTripSec":600.0,"aisleYielding":true,"aisleWaitMaxSec":20.0,"aisleWaitSetbackM":0.8999999761581421,"aisleWaitSideM":0.6000000238418579,"robotYieldAfterSec":2.0,"robotYieldMaxSec":20.0,"robotYieldClearM":0.6000000238418579,"robotYieldBackM":0.8999999761581421,"useReturnLine":true,"passReturnOffsetM":1.0,"passReturnSeparationM":1.0,"passReturnKeepAwayM":0.6000000238418579,"passReturnCheckStepM":0.05000000074505806,"oneRobotPerAisle":true,"yieldOrderEnabled":true,"yieldSideClearM":0.6000000238418579,"yieldSideSearchM":2.5,"yieldSideStepM":0.20000000298023225,"yieldSideWaitMaxSec":30.0,"yieldPathAheadM":2.0,"cornerMinX":10.5,"cornerMaxX":13.5,"cornerMinZ":3.5,"cornerMaxZ":5.800000190734863,"tableDwellSec":25.0,"arriveRadius":0.25,"cornerReachDistance":0.11999999731779099,"stoppedSpeedEpsilon":0.019999999552965165,"clearanceProbeHeight":0.30000001192092898,"clearanceProbeRange":3.0,"pathBlockSearchRadius":2.0,"avoidancePriority":0,"repathRetrySec":1.0,"noPathForceReplanSec":10.0,"escapeToAisleEntranceOnPartialPath":true,"followSiteRoutes":true,"waypointReachDistance":0.25,"routePointSnapM":0.10000000149011612},