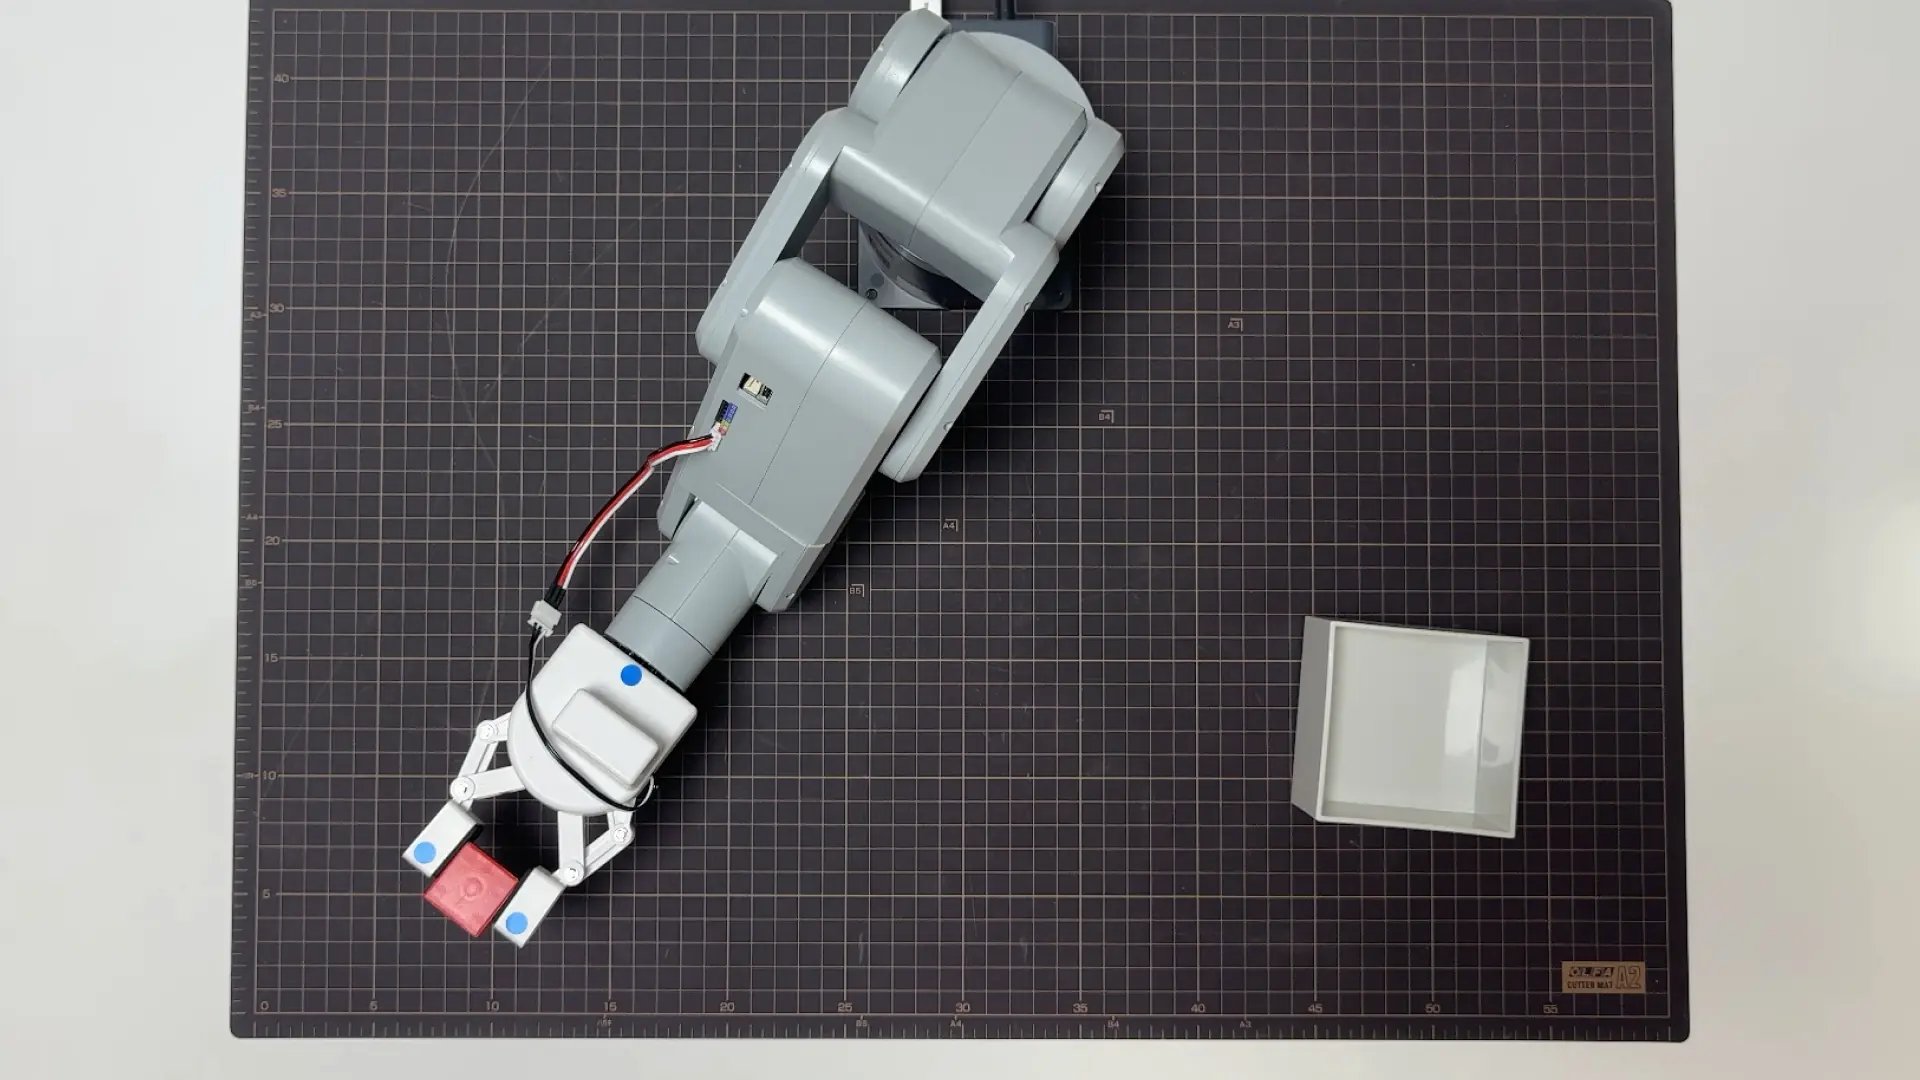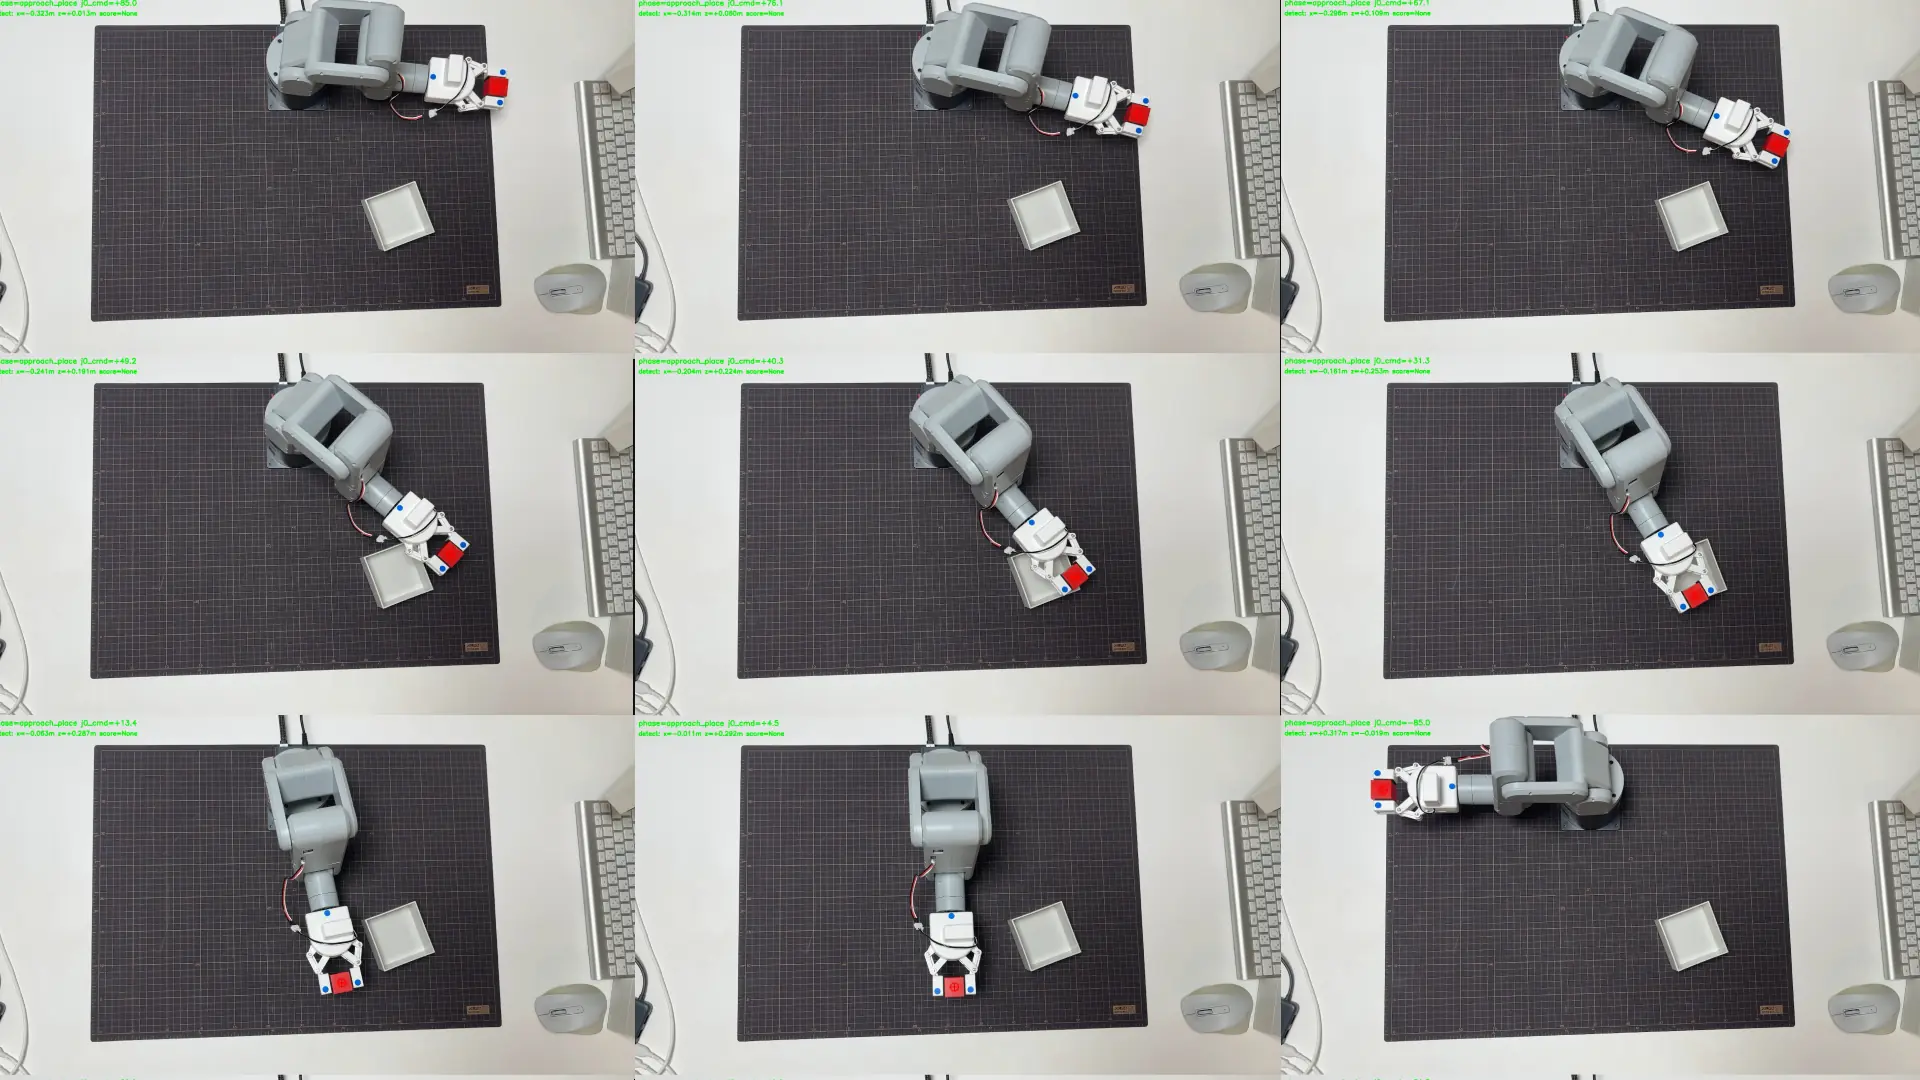
mechArm 270 Pi 動的追従の限界を探る Log#34 | 置く姿勢は、ドラッグティーチングで教えた軌道の中にあった
PICK高度のj0スイープを成立させるセッションだった。入口の課題は前回からの持ち越しである「到達許容の2°問題」。j2が目標まであと2.02°を詰め切れず、許容2.0°を0.02°超えてABORTする、という話だった。この問題自体は実績値の流用であっさり解決した。本質的な不具合はその直後に起きた。送信したコマンドにアームが反応しない。daemonまでは届いている。エラーも出ない。ただ動かない。
この沈黙の犯人を特定するまでに、ストリーミング送信の廃止、リトライ機構の追加、確認プロンプトを全部外したシンプル版の新規作成、と3回コードを作り替えた。どれも犯人ではなかった。犯人はコマンドの中身、j1=91.66という値そのものだった。88.0に変えたら、何事もなかったかのように全部動いた。
入口の2°問題は、すぐ終わった
前回止まっていたのは、PICK基準姿勢への到達判定だった。j2が目標まであと2.02°を詰め切れず、tol 2.0°を0.02°だけ超えてABORTしていた。床ギリギリの姿勢では負荷がかかり、最後の2°が残る。
ここは新しい数値を作らず、play-Aで実機実績のあるHOLD_TOL_DEG=3.0°をPICK工程だけに流用した。外部レビュー(codex)で、tol変更がPICK工程だけに効くこと、3.0をハードコード複製せずHOLD_TOL_DEGをimport参照することを確認している。結果、基準姿勢への移動はmax|Δ|=1.40°(tol 3.0°)で到達OK。
ここまでは想定内だった。問題はその直後に起きた。
1点目で完全不動
基準姿勢には着いた。スイープ1点目、j0を-34.98から-85.00へ振る送信で、アームが1°も動かなくなった。
[MOVE] 基準姿勢(教示時 j0=-36.03°)へ移動 ...
[SEND] to base: streaming send_angles  speed=20  (pre max|Δ|=90.17° → 46 ticks @ 0.1s = 4.6s, post-stream timeout 15.5s)
[SEND] arrival OK: max|Δ|=1.40° (tol 3.0°)
--- [ 1/19] j0_cmd=-85.00° target=[ -85.00,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[SEND] [ 1/19] j0=-85.00: streaming send_angles  speed=20  (pre max|Δ|=50.02° → 26 ticks @ 0.1s = 2.6s, post-stream timeout 9.5s)
[SEND] [TIMEOUT] 9.5s 内に未到達: max|Δ|=50.02° actual=[ -34.98,  +90.35,  -20.47,   +1.05,  -69.87,  -32.43]
[ABORT] [ 1/19] 到達確認タイムアウト。これまでの記録を保存して終了
部分的に動いて止まったのではない。j0の実測が小数点以下まで送信前のまま。完全な無反応だった。実機のそばで見ていても、唸りも震えもない。
直前のHOME→基準への46 tickストリーミングは正常に動いていた。daemon・TCP接続・ストリーミング機構そのものは生きている。基準姿勢に到達した後の送信だけが死ぬ。
このときは、前回確定していた「グリッパーclose後の沈黙」と症状が同じに見えた。だがcloseコマンドは一度も打っていない。沈黙のトリガー条件がcloseだけではない可能性が出てきて、ここから切り分けが始まった。
時間で解ける説 → リトライ実装 → それでも無視
約10分後、HOME復帰スクリプトを実行したらアームは動いた。「沈黙は時間経過で解ける短命のもの」という仮説を立て、最小変更として「タイムアウト時に5秒待って1回だけ再送するリトライ」を実装した。安全条件として、送信前後の移動量が1.0°以上ある場合(部分移動・ストール疑い)はリトライしない設計にした。負荷で止まっているアームへの追撃を防ぐため。
このリトライ実装も外部レビューを通した。リトライが最大1回でループしないこと、ストール疑い時に再送しない条件が効いていること、戻り値2要素化で呼び出し側に不整合がないこと、の3点を確認して全✅。
実機に投入した結果がこれだった。
--- [ 1/19] j0_cmd=-85.00° target=[ -85.00,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[SEND] [ 1/19] j0=-85.00: streaming send_angles  speed=20  (pre max|Δ|=50.20° → 26 ticks @ 0.1s = 2.6s, post-stream timeout 9.5s)
[SEND] [TIMEOUT] 9.5s 内に未到達: max|Δ|=50.20° actual=[ -34.80,  +90.35,  -21.00,   +1.23,  -68.73,  -32.95]
[RETRY] 1回目送信が無視された(移動量 0.00°)。5.0s 待って再送します
[RETRY] [ 1/19] j0=-85.00 (retry): streaming send_angles  speed=20  (pre max|Δ|=50.20° → 26 ticks @ 0.1s = 2.6s, post-stream timeout 9.5s)
[RETRY] 失敗。ABORT へ. 9.5s 内に未到達: max|Δ|=50.20° actual=[ -34.80,  +90.35,  -21.00,   +1.23,  -68.73,  -32.95]
[ABORT] [ 1/19] 到達確認タイムアウト。これまでの記録を保存して終了
リトライも完全無視。移動量0.00°。時間説が揺らいだ。
daemonログが示した事実:送信は届いている
Pi側のdaemonログを見ると、Mac側から送ったコマンドはすべて正常に受理されていた。
[DAEMON 16:04:08] cmd received: send_angles
[DAEMON 16:04:08] send_angles 呼び出し前: angles=[-85.0, 91.66, -21.44, 1.4, -70.48, -32.87], speed=20, wait=0.0
[DAEMON 16:04:08] send_angles 呼び出し後: result=None, elapsed_ms=10.9
[DAEMON 16:04:08] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
result=None、elapsed_ms約10ms。pymycobotのsend_angles呼び出しは正常に完了している。それでも実測角度は変わらない。沈黙はdaemonより下、コントローラかサーボの層で起きている。TCP・daemon・シリアル呼び出しのどこにも異常がない、という消去法がここで効いた。
08は動く。ストリーミングを捨てて単発に戻す
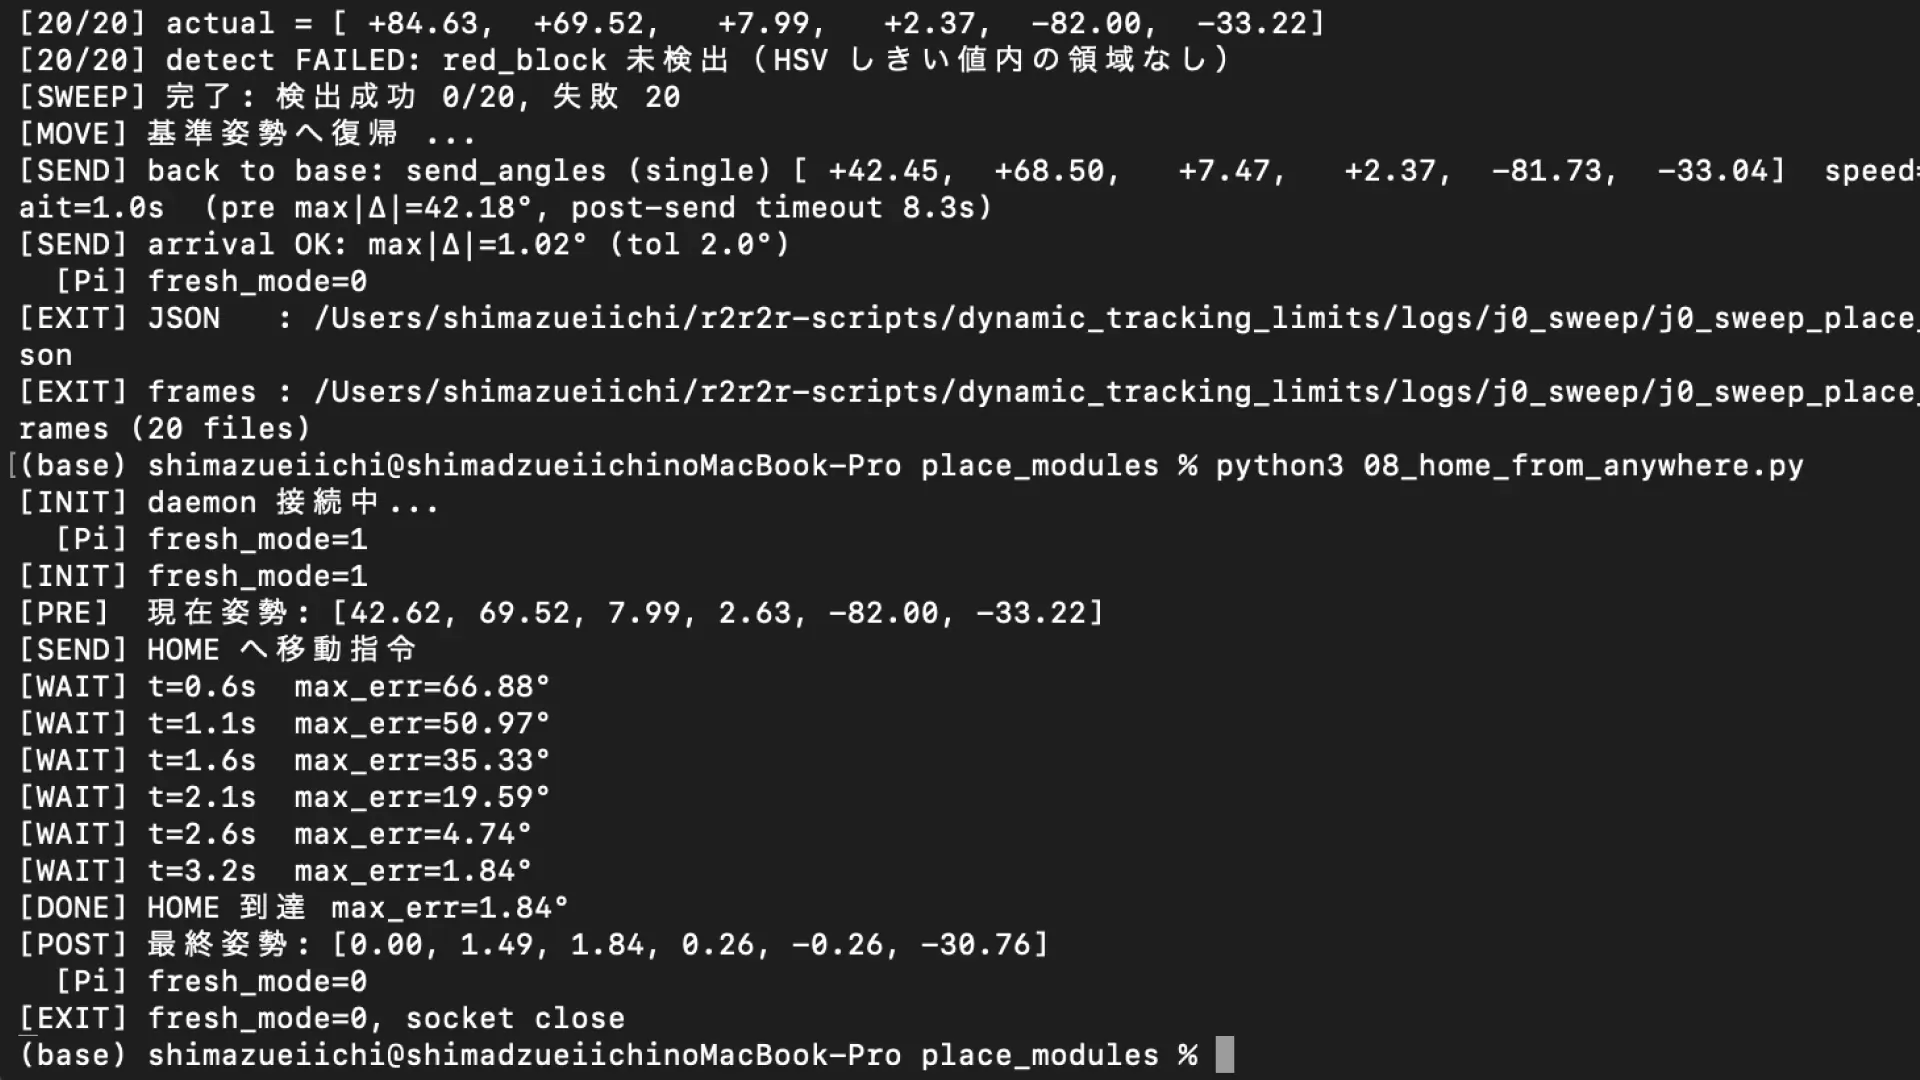
同じ沈黙状態から、HOME復帰スクリプト(08_home_from_anywhere.py)は即座にアームを動かせた。daemonログを見ると、08がやっていたのは単発のsend_angles 1発だけ。特別な蘇生処理は何もない。
[DAEMON 16:06:06] cmd received: send_angles
[DAEMON 16:06:06] send_angles 呼び出し前: angles=[0, 0, 0, 0, 0, -30], speed=20, wait=0.0
[DAEMON 16:06:06] send_angles 呼び出し後: result=None, elapsed_ms=12.0
ここで方針を変えた。そもそもストリーミング送信を入れた理由は「グリッパーclose後の単発send沈黙」の回避だったが、このスクリプトはcloseを一切使わない。回避策の前提が存在しない。08と同じ単発方式に戻す。新規発明を避ける流用原則の徹底。送信部を単発send_angles 1発+実測ポーリングに置き換え、リトライ機構は残した。
アームは動くからスクリプトがおかしいだけだって。アームを疑うのはやめてスクリプト修正に集中して
実機を一番近くで見ている側からの、正しい軌道修正だった。実際、アームのハードはこの日一度も壊れていなかった。
単発でも止まる。仮説が全部死んだ
単発化した版でも、スイープ点への送信は無視された。さらに、確認プロンプトも到達判定も持たないシンプル版を新規に書き、HOMEから直接スイープ点へ向かわせても結果は同じだった。
--- [ 1/20] j0_cmd=-85.00° target=[ -85.00,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[ 1/20] send_angles (single)  speed=20  pre max|Δ|=90.43° → sleep 9.04s
[ 1/20] actual = [  +0.00,   +1.93,   +1.66,   +0.17,   +0.17,  -29.70]
HOMEから動いてすらいない。一方このときdaemonログでは、直前のウォームアップ送信(現在姿勢宛)の後にj1が1.49→1.93へわずかに動いた記録があり、送信経路は確かに生きている。
ここで決定的な比較材料が得られた。08_home_from_anywhere.pyを連続実行したとき、1回目はHOME送信が24秒間無反応でCtrl+C、2回目はまったく同一のコマンドで即到達、という記録が取れていた。同一コマンドが1回目は無視され2回目で通る。このときは「接続後の初回sendが1回捨てられる」仮説を立てたが、シンプル版はウォームアップ送信で初回枠を消費した上で全滅しており、これも棄却された。
時間説、ストリーミング説、初回send捨て説。仮説が全部死んだ。
成功と失敗を並べたら、j1で割れた
ここで、その日の全送信を成功・失敗で並べ直した。
送信 | targetのj1 | 結果 |
|---|---|---|
08 HOME復帰(単発) | 0 | 動く |
approach_pickスイープ20点(単発・前回) | 87.74 | 動く |
HOME→PICK基準(ストリーミング) | 91.66宛・実測90.35で停止(tol内で到達扱い) | 動く |
PICK基準→スイープ点(ストリーミング) | 91.66 | 全滅 |
PICK基準→スイープ点(単発・リトライ込み) | 91.66 | 全滅 |
HOME→スイープ点(シンプル版・単発) | 91.66 | 全滅 |
失敗した送信は、すべてj1=91.66を含んでいた。成功した送信は、すべてj1が90.35以下だった。方式でもタイミングでもなく、コマンドの中身で割れている。
仮説:コントローラはj1(ショルダー)に受理限界を持っていて、それを超える値を含むsend_anglesをエラーも返さず丸ごと捨てる。基準姿勢のj1=91.66はドラッグ教示のJSONから抽出した値で、手でアームを動かす教示では物理的に到達できても、コマンドとしては受理されない領域だった。実測到達が毎回90.35前後で止まっていたこととも符合する。過去に「ショルダー実測上限88°」という記録があったことも思い当たった。
検証は1回の送信で済む。j1だけ88.0に下げた1点送信。
[SEND] to base: send_angles (single) [ -36.03,  +88.00,  -21.44,   +1.40,  -70.48,  -32.87]  speed=20  (pre max|Δ|=86.07°, post-send timeout 14.9s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
新規接続の1発目から、HOME→PICK高度への86°ジャンプが一発で通った。初回send捨て説の残骸もここで完全に消えた。犯人はj1=91.66。1°と少しの差だった。
19点スイープ成立
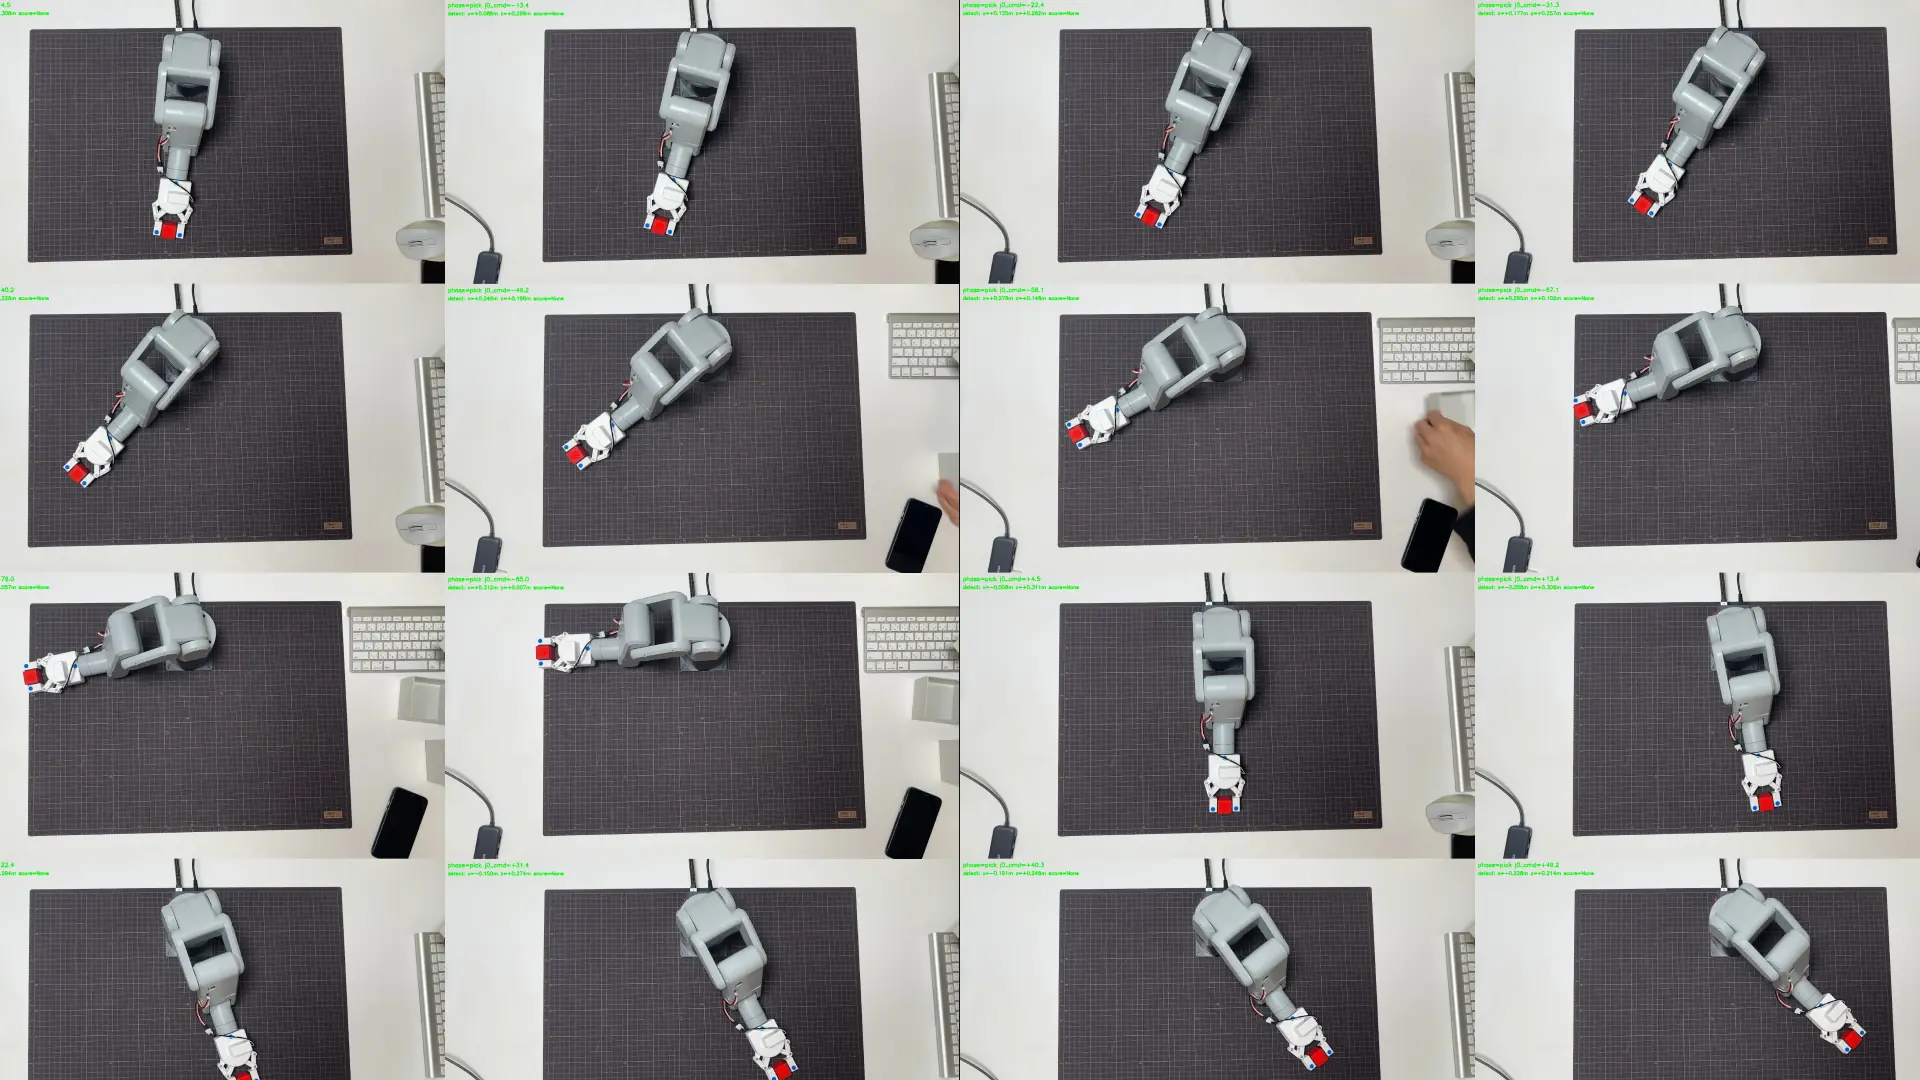
j1=88.0を基準に、j0を-85°から+76°まで19点振った。
(_19 実行ログ全量)
(base) shimazueiichi@shimadzueiichinoMacBook-Pro place_modules % python3 j0_sweep_scan.py --phase pick --base-angles="-36.03,88.0,-21.44,1.4,-70.48,-32.87" --j0-min=-85 --j0-max=85 --step=8.95
[INIT] reach_tol_deg = 3.00° (phase=pick)
[INIT] base_angles を CLI で直接指定(teach JSON 抽出はスキップ)
[INIT] phase=pick 基準姿勢: [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87]
[INIT] 抽出根拠: cli_direct: -36.03,88.0,-21.44,1.4,-70.48,-32.87
[INIT] 教示時 j0 = -36.03°
[INIT] スイープ点 (19 点): -85.00, -76.05, -67.10, -58.15, -49.20, -40.25, -31.30, -22.35, -13.40, -4.45, +4.50, +13.45, +22.40, +31.35, +40.30, +49.25, +58.20, +67.15, +76.10
[INIT] JOINT_LIMITS 一括検査 ...
[INIT] JOINT_LIMITS OK (base + 19 スイープ点)
[INIT] daemon 接続中 ...
[INIT] daemon ping OK
[Pi] fresh_mode=1
[INIT] fresh_mode=1
[INIT] 現在姿勢を取得(最大 12 回・0.2s 間隔・ゴミ読みフィルタ)
[INIT] 現在姿勢 = [ -35.59, +89.12, -20.12, +1.49, -70.75, -32.51]
[INIT] 現在 → 基準姿勢 max|Δ| = 1.32°
[CAM] 接続中カメラ一覧:
index=0 name=FaceTime HDカメラ
index=1 name=Iriun Camera
index=2 name=iPhone14 Pro MAXのカメラ
[CAM] 上カメラ(iPhone) index=2
[CAM] 横カメラ(Iriun) index=1
[CAM] 上カメラ index = 2
[Mac] マット四隅検出中... (10フレーム)
[Mac] ✓ マット四隅検出: 10/10 フレーム成功
[Mac] ✓ 動的homography計算完了
[Mac] ✓ マット範囲: X=[366, 1569] Y=[109, 979]
[CAM] homography OK
[CONFIRM] phase=pick → 検出対象=赤ブロック。爪に赤ブロックを咥えさせた状態にしてください。OK なら Enter
[OUT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_19.json
[OUT] frames: /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_19_frames/
[MOVE] 基準姿勢(教示時 j0=-36.03°)へ移動 ...
[SEND] to base: send_angles (single) [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=1.32°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
--- [ 1/19] j0_cmd=-85.00° target=[ -85.00, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 1/19] j0=-85.00: send_angles (single) [ -85.00, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=49.41°, post-send timeout 9.4s)
[SEND] arrival OK: max|Δ|=2.21° (tol 3.0°)
[ 1/19] settle 1.0s
[ 1/19] actual = [ -84.72, +89.12, -20.12, +1.49, -70.75, -32.51]
[ 1/19] detect OK: xz=(+0.312, +0.007) (red_block pixel=(371, 295))
--- [ 2/19] j0_cmd=-76.05° target=[ -76.05, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 2/19] j0=-76.05: send_angles (single) [ -76.05, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.67°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 2/19] settle 1.0s
[ 2/19] actual = [ -75.84, +89.12, -20.12, +1.05, -70.75, -32.51]
[ 2/19] detect OK: xz=(+0.307, +0.057) (red_block pixel=(379, 388))
--- [ 3/19] j0_cmd=-67.10° target=[ -67.10, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 3/19] j0=-67.10: send_angles (single) [ -67.10, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.74°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 3/19] settle 1.0s
[ 3/19] actual = [ -67.41, +89.12, -20.12, +1.14, -70.75, -32.51]
[ 3/19] detect OK: xz=(+0.295, +0.102) (red_block pixel=(401, 473))
--- [ 4/19] j0_cmd=-58.15° target=[ -58.15, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 4/19] j0=-58.15: send_angles (single) [ -58.15, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.26°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 4/19] settle 1.0s
[ 4/19] actual = [ -58.35, +89.12, -20.12, +1.31, -70.75, -32.51]
[ 4/19] detect OK: xz=(+0.276, +0.148) (red_block pixel=(437, 560))
--- [ 5/19] j0_cmd=-49.20° target=[ -49.20, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 5/19] j0=-49.20: send_angles (single) [ -49.20, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.15°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 5/19] settle 1.0s
[ 5/19] actual = [ -49.30, +89.12, -20.12, +1.31, -70.75, -32.51]
[ 5/19] detect OK: xz=(+0.249, +0.190) (red_block pixel=(488, 640))
--- [ 6/19] j0_cmd=-40.25° target=[ -40.25, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 6/19] j0=-40.25: send_angles (single) [ -40.25, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.05°, post-send timeout 8.0s)
[SEND] [TIMEOUT] 8.0s 内に未到達: max|Δ|=9.05° actual=[ -49.30, +89.12, -20.12, +1.40, -70.75, -32.51]
[RETRY] 1回目送信が無視された(移動量 0.09°)。5.0s 待って再送します
[RETRY] [ 6/19] j0=-40.25 (retry): send_angles (single) [ -40.25, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.05°, post-send timeout 8.0s)
[RETRY] 成功: arrival OK max|Δ|=1.32° (tol 3.0°)
[ 6/19] settle 1.0s
[ 6/19] actual = [ -40.42, +89.12, -20.12, +1.14, -70.75, -32.51]
[ 6/19] detect OK: xz=(+0.217, +0.226) (red_block pixel=(550, 709))
--- [ 7/19] j0_cmd=-31.30° target=[ -31.30, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 7/19] j0=-31.30: send_angles (single) [ -31.30, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.12°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 7/19] settle 1.0s
[ 7/19] actual = [ -31.11, +89.12, -20.12, +1.31, -70.75, -32.51]
[ 7/19] detect OK: xz=(+0.177, +0.257) (red_block pixel=(628, 769))
--- [ 8/19] j0_cmd=-22.35° target=[ -22.35, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 8/19] j0=-22.35: send_angles (single) [ -22.35, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.76°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 8/19] settle 1.0s
[ 8/19] actual = [ -22.32, +89.12, -20.12, +1.23, -70.75, -32.51]
[ 8/19] detect OK: xz=(+0.135, +0.282) (red_block pixel=(710, 815))
--- [ 9/19] j0_cmd=-13.40° target=[ -13.40, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 9/19] j0=-13.40: send_angles (single) [ -13.40, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.92°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 9/19] settle 1.0s
[ 9/19] actual = [ -13.18, +89.12, -20.12, +1.14, -70.75, -32.51]
[ 9/19] detect OK: xz=(+0.088, +0.299) (red_block pixel=(801, 847))
--- [10/19] j0_cmd=-4.45° target=[ -4.45, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [10/19] j0=-4.45: send_angles (single) [ -4.45, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.73°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[10/19] settle 1.0s
[10/19] actual = [ -4.74, +89.12, -20.12, +1.23, -70.75, -32.51]
[10/19] detect OK: xz=(+0.043, +0.308) (red_block pixel=(889, 863))
--- [11/19] j0_cmd=+4.50° target=[ +4.50, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [11/19] j0=+4.50: send_angles (single) [ +4.50, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.24°, post-send timeout 8.0s)
[SEND] [TIMEOUT] 8.0s 内に未到達: max|Δ|=9.24° actual=[ -4.74, +89.12, -20.12, +1.23, -70.75, -32.51]
[RETRY] 1回目送信が無視された(移動量 0.00°)。5.0s 待って再送します
[RETRY] [11/19] j0=+4.50 (retry): send_angles (single) [ +4.50, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.24°, post-send timeout 8.0s)
[RETRY] 成功: arrival OK max|Δ|=1.32° (tol 3.0°)
[11/19] settle 1.0s
[11/19] actual = [ +4.30, +89.12, -20.12, +1.31, -70.75, -32.51]
[11/19] detect OK: xz=(-0.008, +0.311) (red_block pixel=(987, 867))
--- [12/19] j0_cmd=+13.45° target=[ +13.45, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [12/19] j0=+13.45: send_angles (single) [ +13.45, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.15°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[12/19] settle 1.0s
[12/19] actual = [ +13.53, +89.12, -20.12, +1.40, -70.75, -32.51]
[12/19] detect OK: xz=(-0.058, +0.306) (red_block pixel=(1084, 856))
--- [13/19] j0_cmd=+22.40° target=[ +22.40, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [13/19] j0=+22.40: send_angles (single) [ +22.40, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.87°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[13/19] settle 1.0s
[13/19] actual = [ +22.23, +89.12, -20.12, +1.31, -70.75, -32.51]
[13/19] detect OK: xz=(-0.104, +0.294) (red_block pixel=(1172, 831))
--- [14/19] j0_cmd=+31.35° target=[ +31.35, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [14/19] j0=+31.35: send_angles (single) [ +31.35, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.12°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[14/19] settle 1.0s
[14/19] actual = [ +31.37, +89.12, -20.12, +1.31, -70.75, -32.51]
[14/19] detect OK: xz=(-0.150, +0.274) (red_block pixel=(1259, 790))
--- [15/19] j0_cmd=+40.30° target=[ +40.30, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [15/19] j0=+40.30: send_angles (single) [ +40.30, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.93°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[15/19] settle 1.0s
[15/19] actual = [ +40.16, +89.12, -20.12, +1.14, -70.75, -32.51]
[15/19] detect OK: xz=(-0.191, +0.248) (red_block pixel=(1334, 739))
--- [16/19] j0_cmd=+49.25° target=[ +49.25, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [16/19] j0=+49.25: send_angles (single) [ +49.25, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.09°, post-send timeout 8.0s)
[SEND] [TIMEOUT] 8.0s 内に未到達: max|Δ|=9.09° actual=[ +40.16, +89.12, -20.12, +1.14, -70.75, -32.51]
[RETRY] 1回目送信が無視された(移動量 0.00°)。5.0s 待って再送します
[RETRY] [16/19] j0=+49.25 (retry): send_angles (single) [ +49.25, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.09°, post-send timeout 8.0s)
[RETRY] 成功: arrival OK max|Δ|=1.32° (tol 3.0°)
[16/19] settle 1.0s
[16/19] actual = [ +49.48, +89.12, -20.12, +1.31, -70.75, -32.51]
[16/19] detect OK: xz=(-0.228, +0.214) (red_block pixel=(1402, 673))
--- [17/19] j0_cmd=+58.20° target=[ +58.20, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [17/19] j0=+58.20: send_angles (single) [ +58.20, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=8.72°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[17/19] settle 1.0s
[17/19] actual = [ +58.09, +89.12, -20.12, +0.96, -70.75, -32.51]
[17/19] detect OK: xz=(-0.258, +0.177) (red_block pixel=(1456, 602))
--- [18/19] j0_cmd=+67.15° target=[ +67.15, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [18/19] j0=+67.15: send_angles (single) [ +67.15, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.06°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[18/19] settle 1.0s
[18/19] actual = [ +67.06, +89.12, -20.12, +1.14, -70.75, -32.51]
[18/19] detect OK: xz=(-0.283, +0.135) (red_block pixel=(1499, 522))
--- [19/19] j0_cmd=+76.10° target=[ +76.10, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [19/19] j0=+76.10: send_angles (single) [ +76.10, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.04°, post-send timeout 8.0s)
[SEND] [TIMEOUT] 8.0s 内に未到達: max|Δ|=9.04° actual=[ +67.06, +89.12, -20.12, +1.14, -70.75, -32.51]
[RETRY] 1回目送信が無視された(移動量 0.00°)。5.0s 待って再送します
[RETRY] [19/19] j0=+76.10 (retry): send_angles (single) [ +76.10, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=9.04°, post-send timeout 8.0s)
[WARN] daemon_get_angles failed: daemon error: get_angles returned empty/invalid after 12 retries
[WARN] daemon_get_angles failed: daemon error: get_angles returned empty/invalid after 12 retries
[WARN] daemon_get_angles failed: daemon error: get_angles returned empty/invalid after 12 retries
[WARN] daemon_get_angles failed: daemon error: get_angles returned empty/invalid after 12 retries
[RETRY] 失敗。ABORT へ. 8.0s 内に未到達: max|Δ|=9.13° actual=[ +66.97, +89.12, -20.12, +1.14, -70.75, -32.51]
[ABORT] [19/19] 到達確認タイムアウト。これまでの記録を保存して終了
[Pi] fresh_mode=0
[EXIT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_19.json
[EXIT] frames : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_19_frames (18 files)18点目まで取れたところで、19点目のリトライ中にget_anglesまで失敗し始めて打ち切りになった。残る1点(+76.10)は単独で再実行して取得した。
(_20 JSON全量)
{
  "phase": "pick",
  "detect_target": "red_block",
  "base_angles": [
    -36.03,
    88.0,
    -21.44,
    1.4,
    -70.48,
    -32.87
  ],
  "source_teach_json": null,
  "base_source": "cli_direct: -36.03,88.0,-21.44,1.4,-70.48,-32.87",
  "height_note": "床面homography基準。工程をまたぐ位置データの混用禁止",
  "frames_dir": "j0_sweep_pick_20_frames/",
  "sweep_params": {
    "j0_min": 76.1,
    "j0_max": 76.1,
    "step": 1.0,
    "settle_sec": 1.0,
    "n_points": 1,
    "speed": 20,
    "tol_reach_deg": 3.0,
    "no_move": false
  },
  "sweep": [
    {
      "j0_cmd": 76.1,
      "angles_actual": [
        75.93,
        89.12,
        -20.12,
        0.52,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.3001910400390625,
        0.08913672637939453
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+076.1.jpg",
      "send_retried": true
    }
  ]
}
これで19/19点。全点で赤ブロックの検出に成功し、関節実測は全点でj1=89.12、j2=-20.12と完全に一致した。j0だけが変数の、純度の高いデータセットになった。ブロックの検出座標は半径約0.31mの円弧をきれいに描いている。
副産物:5点周期の送信無視と、リトライの効用
19点の中で、send_retried=trueの点が3つある。6点目、11点目、16点目。きれいに5点周期だった。連続して数回送ると1回無視される、というコントローラかシリアル層の癖を示唆している。単独再実行した+76.10の1点もリトライ発生だったので、この日リトライ機構は4回発動して4回とも成功している。この機構がなければスイープは6点目で終わっていた。
「時間で解ける説」という外れた仮説のために入れたリトライが、5点周期の送信無視という別の現象に対する必須部品になった。今後のスイープ系スクリプトには標準で残す。
境界は未確定として残す
正確さのために明記しておく。j1の受理限界そのものは、この日特定していない。
j1=91.66:拒否(複数方式・複数セッションで再現)
j1=88.00:受理(19点で安定動作。コマンド値88.0に対し実測は全点89.12で一貫)
過去のPICK_J1_FIXED=90.87:受理されていた(過去のPICK成功実績)
つまり境界は90.87と91.66の間のどこかにある。「上限88°」と丸めて記録すると過去の実績と矛盾する。teach由来の91.66という値が、この日初めてコマンド側に使われて発覚した、という構図だった。手で動かして記録した角度が、そのまま送れる角度とは限らない。
確定事項 | 内容 |
|---|---|
j1=91.66を含むsend_anglesは黙って捨てられる | エラーなし・result=None・実測不動 |
j1=88.0なら同条件で動く(実測は89.12で一貫) | 新規接続1発目の86°ジャンプも通る |
受理境界は90.87〜91.66の間 | 未測定。丸めて記録しない |
連続送信で約5点周期の無視が起きる | 5秒待ちリトライ1回で通る |
グリッパーclose後沈黙(既知)とは別系統 | closeなしで発生・電源リセット不要 |
今回得たルール
手で動かせる角度と、コマンドで送れる角度は同じではなかった。teach JSONに残ったj1=91.66°は教示データとしては正しい。だがsend_anglesの目標値としてはコントローラに受理されず、しかもresult=Noneで正常終了したように見え、実機だけが沈黙した。通信ログだけを見ていても分からない。成功したコマンドと失敗したコマンドを並べ、どの値で割れているかを見るしかなかった。
このセッションで実装・運用に落とすルールは3つ。
ルール | 反映先 |
|---|---|
teach値をそのままsend_anglesに使わない。手で動かせた角度でも受理されるとは限らない | スイープ基準はCLI直接指定でj1=88.0に固定。teach抽出値を命令にそのまま流さない |
受理境界は丸めない。j1=88.0受理・91.66拒否・境界は90.87〜91.66の間で未測定 | 次セッションで境界を1°刻みで詰める。handoffに記載 |
連続送信の周期的な無視には5秒待ち1回リトライ。ストール疑い(移動量≥1.0°)には再送しない | scan版に実装済み。4/4成功の実績 |
沈黙していたのはアームではなかった。daemonでもなかった。ストリーミングでも、初回sendでもなかった。コマンドの中に、1°だけ送ってはいけない角度が混ざっていた。
最終コード
j0_sweep_scan.py(単発送信・PICKのみtol 3.0°・1回リトライ・全量)。
#!/usr/bin/env python3
# -*- coding: utf-8 -*-
"""j0_sweep_scan.py — j0 単軸スイープ自動計測(工程姿勢ベース)
工程姿勢の j0 だけを段階的に振りながら、各停止点で「関節実測角度」と
「上カメラによる位置検出」をペアで記録する。Mac 上で実行し、アームは
daemon 経由(TCP 192.168.2.1:5555)で動かす。
工程と検出対象(人が事前に爪の状態を準備すること。set_gripper は呼ばない):
approach_pick : 爪が空 → 爪先(青シール)/ visual_servo_pick.detect_tip_from_frame
pick : 爪が赤ブロックを咥える → 赤ブロック / visual_servo_pick.detect_red_block
approach_place: 爪が赤ブロックを咥える → 赤ブロック / 同上
place : 爪が赤ブロックを咥える → 赤ブロック / 同上
絶対ルール:
- send_coords() / release_all_servos() を呼ばない(daemon 経由なので構造的に呼べない)
- set_gripper を呼ばない(このスクリプトはグリッパー操作の責任外)
- daemon にコマンドを追加しない
- 既存の fk_scan_motion_based*.csv に書き込まない
- 全送信前に JOINT_LIMITS(waypoint_replay の実測値)一括検査
- 1点ごとに JSON を atomic write(途中 ABORT でもデータが残る)
CLI:
python3 j0_sweep_scan.py --phase pick --j0-min -20 --j0-max 20 --step 2
python3 j0_sweep_scan.py --phase approach_pick --j0-min -20 --j0-max 20 --step 2
出力:
~/r2r2r-scripts/logs/j0_sweep/j0_sweep_{phase}_{NN}.json
~/r2r2r-scripts/logs/j0_sweep/j0_sweep_{phase}_{NN}_frames/j0_{j0_cmd:+06.1f}.jpg
"""
from __future__ import print_function
import argparse
import importlib
import json
import math
import os
import sys
import time
import types
from pathlib import Path
# ---- パス解決 --------------------------------------------------------------
_THIS = Path(__file__).resolve()
_PLACE_MODULES_DIR = _THIS.parent
_SCRIPTS_ROOT = _THIS.parents[3] # ~/r2r2r-scripts
_DRAG_TEACHING_DIR = _SCRIPTS_ROOT / "dynamic_tracking_limits" / "drag_teaching"
sys.path.insert(0, str(_SCRIPTS_ROOT))
sys.path.insert(0, str(_PLACE_MODULES_DIR))
sys.path.insert(0, str(_DRAG_TEACHING_DIR))
# ---- pymycobot スタブ ------------------------------------------------------
# waypoint_replay.py は import 時に `from pymycobot.mycobot import MyCobot` を
# 実行するが、このスクリプトはアーム制御を全て daemon TCP 経由で行うため、
# MyCobot を一切インスタンス化しない。Mac に pymycobot が無い前提で、
# import エラーを起こさないようスタブだけ差し込む(waypoint_replay 自体は
# 変更しない)。スタブを呼び出した瞬間に RuntimeError を投げ、誤って実体化
# しようとしたら直ちに分かるようにする。
if "pymycobot" not in sys.modules:
_pkg = types.ModuleType("pymycobot")
_mod = types.ModuleType("pymycobot.mycobot")
class _MyCobotStub(object):
def __init__(self, *args, **kwargs):
raise RuntimeError(
"j0_sweep_scan.py: MyCobot stub is not callable. "
"Arm control must go through daemon TCP, not direct serial.")
_mod.MyCobot = _MyCobotStub
sys.modules["pymycobot"] = _pkg
sys.modules["pymycobot.mycobot"] = _mod
# ---- 流用 import ----------------------------------------------------------
import cv2 # noqa: E402
import numpy as np # noqa: E402
import waypoint_replay as wr # noqa: E402
import waypoint_streaming_replay as wsr # noqa: E402 # _interpolate / STREAM_INTERVAL_SEC / STEP_DEG_PER_TICK 流用
from visual_servo_pick import ( # noqa: E402
get_daemon_socket,
close_daemon_socket,
daemon_send_angles,
daemon_get_angles,
daemon_set_fresh_mode,
setup_homography_and_mat_range,
pixel_to_unity,
detect_red_block,
detect_tip_from_frame,
)
# ---- 定数 -----------------------------------------------------------------
DEFAULT_TEACH_JSON = _DRAG_TEACHING_DIR / "drag_v2_20221013_152840_with_pos.json"
DEFAULT_OUTPUT_ROOT = Path.home() / "r2r2r-scripts" / "dynamic_tracking_limits" / "logs" / "j0_sweep"
SPEED = 20 # 全送信共通(task 仕様)
TOL_REACH_DEG = 2.0 # 到達判定(task 仕様)
# タイムアウト時の1回限り再送パラメータ(実機で再現した「到達直後の2本目が完全無視される」事象向け)。
# pre→last 移動量が RETRY_NO_MOVE_THRESHOLD_DEG 未満 → 送信無視疑い → RETRY_PAUSE_SEC 待って1回だけ再送。
# 1.0° 以上動いている場合は部分移動/ストール疑いとしてリトライしない(負荷で止まっているアームに送り続けない)。
RETRY_PAUSE_SEC = 5.0
RETRY_NO_MOVE_THRESHOLD_DEG = 1.0
# 到達確認 timeout は wr._compute_arrival_timeout(max_delta) で送信ごとに算出する
# (DAY228実績の式:BASE + max_delta/SPEED * FACTOR、MIN/MAX で clamp)。
# REACH_TIMEOUT_SEC はフォールバック下限:
# - 現在姿勢が取れず max_delta を算出できないときの固定値
# - 算出値が REACH_TIMEOUT_SEC 未満になるケースの最終下限
REACH_TIMEOUT_SEC = 8.0
POLL_SLEEP = 0.3
GET_ANGLES_RETRY = 12 # 読みリトライ(waypoint_replay と同値)
GET_ANGLES_RETRY_SLEEP = 0.2
WARMUP_FRAMES = 30
FIRST_MOVE_WARN_DEG = 30.0
DEFAULT_SETTLE_SEC = 1.0
# フレーム取得失敗時の placeholder 画像サイズ(成功フレームを 1 枚も得ていない場合のフォールバック)
PLACEHOLDER_W = 1280
PLACEHOLDER_H = 720
VALID_PHASES = ("approach_pick", "pick", "approach_place", "place")
PHASE_TO_WP_KEY = {
"approach_pick": "APPROACH_PICK",
"pick": "PICK",
"approach_place": "APPROACH_PLACE",
"place": "PLACE",
}
PHASE_DETECT_TARGET = {
"approach_pick": "tip",
"pick": "red_block",
"approach_place": "red_block",
"place": "red_block",
}
# ---- ヘルパ ---------------------------------------------------------------
def _fmt_angles(a):
if a is None:
return "None"
return "[" + ", ".join("{:+7.2f}".format(v) for v in a) + "]"
def _daemon_get_angles_filtered():
"""daemon_get_angles を最大 GET_ANGLES_RETRY 回試し、waypoint_replay の
_is_valid_angles(JOINT_LIMITS ± READ_SANITY_MARGIN_DEG)を通った値だけ返す。
全失敗で None。
"""
for _ in range(GET_ANGLES_RETRY):
a = None
try:
a = daemon_get_angles()
except Exception:
a = None
if wr._is_valid_angles(a):
return [float(x) for x in a]
time.sleep(GET_ANGLES_RETRY_SLEEP)
return None
def _send_and_wait_arrival(target, label, reach_tol_deg):
"""target を単発 send_angles で送信し、tol 内に入るまで到達確認する。
本スクリプトは set_gripper(close) を一切呼ばないため、DAY228 で問題となった
「close 直後の単発 send_angles 沈黙」事象は本スクリプトには該当しない。
一方、ストリーミング送信(0.1s 周期連打)は PICK 基準姿勢からのスイープ移動で
コントローラに完全無視される事象が実機2セッションで再現したため、
08_home_from_anywhere 等で実績のある単発 send_angles 方式に統一する。
手順:
1. 送信前姿勢を取得し、wr._compute_arrival_timeout(pre_max) で timeout 算出
(送信前姿勢が取れない場合は ABORT。fallback はしない)
2. target を 1 回だけ daemon_send_angles(target, speed=SPEED, wait=0) で送信
3. timeout 窓で get_angles 実測ポーリング、tol reach_tol_deg で到達判定
4. 1回目がタイムアウトした場合、pre_actual と最後の実測 last_actual の max|Δ| を見て
RETRY_NO_MOVE_THRESHOLD_DEG 未満なら「送信無視」とみなし、RETRY_PAUSE_SEC 待って
現在姿勢を取り直して target を1回だけ単発再送(最大1回・ループしない)。
1.0° 以上動いている(部分移動/ストール)場合はリトライしない。
返り値: (success: bool, retried: bool)。
retried は「タイムアウト時に1回限りの再送を実行したか」のフラグ。
ABORT 経路は変更しない。
"""
# 1. 送信前姿勢 → timeout 算出(取れない場合は ABORT。fallback はしない)
pre_actual = _daemon_get_angles_filtered()
if pre_actual is None:
print("[SEND] [ABORT] {}: 送信前実測が取得できないため中止".format(label))
return False, False
pre_max, _ = wr._max_axis_diff(target, pre_actual)
timeout_sec = max(REACH_TIMEOUT_SEC, wr._compute_arrival_timeout(pre_max))
# 2. 単発送信(target を 1 回だけ送る)
print("[SEND] {}: send_angles (single) {} speed={} "
"(pre max|Δ|={:.2f}°, post-send timeout {:.1f}s)".format(
label, _fmt_angles(target), SPEED, pre_max, timeout_sec))
try:
daemon_send_angles(target, speed=SPEED, wait=0)
except Exception as e:
print("[SEND] [ERROR] daemon_send_angles 例外: {}".format(e))
return False, False
# 3. 到達確認ポーリング
t0 = time.time()
last_err = None
last_actual = None
while time.time() - t0 < timeout_sec:
actual = _daemon_get_angles_filtered()
if actual is not None:
max_d, _ = wr._max_axis_diff(actual, target)
last_err = max_d
last_actual = actual
if max_d <= reach_tol_deg:
print("[SEND] arrival OK: max|Δ|={:.2f}° (tol {:.1f}°)".format(
max_d, reach_tol_deg))
return True, False
time.sleep(POLL_SLEEP)
le = "{:.2f}".format(last_err) if last_err is not None else "None"
la = _fmt_angles(last_actual) if last_actual is not None else "None"
print("[SEND] [TIMEOUT] {:.1f}s 内に未到達: max|Δ|={}° actual={}".format(
timeout_sec, le, la))
# 4. リトライ判定(1回目タイムアウト時のみ・最大1回・ループしない)
# pre_actual → last_actual の max|Δ| を見る:
# < RETRY_NO_MOVE_THRESHOLD_DEG → 送信無視疑い → 1回だけ単発再送
# >= RETRY_NO_MOVE_THRESHOLD_DEG → 部分移動/ストール → リトライしない
if last_actual is None:
print("[SEND] リトライ判定不可: タイムアウト中に実測が一度も取れなかった。ABORT へ")
return False, False
move_d, _ = wr._max_axis_diff(last_actual, pre_actual)
if move_d >= RETRY_NO_MOVE_THRESHOLD_DEG:
print("[SEND] リトライしません: pre→last 移動量 {:.2f}° >= {:.1f}° "
"(部分移動/ストール疑い)".format(move_d, RETRY_NO_MOVE_THRESHOLD_DEG))
return False, False
print("[RETRY] 1回目送信が無視された(移動量 {:.2f}°)。"
"{:.1f}s 待って再送します".format(move_d, RETRY_PAUSE_SEC))
time.sleep(RETRY_PAUSE_SEC)
# 現在姿勢を取り直し、target を1回だけ単発再送
pre_actual_retry = _daemon_get_angles_filtered()
if pre_actual_retry is None:
print("[RETRY] 失敗。再送前実測が取得できないため中止。ABORT へ")
return False, True
pre_max_retry, _ = wr._max_axis_diff(target, pre_actual_retry)
timeout_retry_sec = max(REACH_TIMEOUT_SEC, wr._compute_arrival_timeout(pre_max_retry))
print("[RETRY] {} (retry): send_angles (single) {} speed={} "
"(pre max|Δ|={:.2f}°, post-send timeout {:.1f}s)".format(
label, _fmt_angles(target), SPEED, pre_max_retry, timeout_retry_sec))
try:
daemon_send_angles(target, speed=SPEED, wait=0)
except Exception as e:
print("[RETRY] [ERROR] daemon_send_angles 例外: {}. ABORT へ".format(e))
return False, True
# 再送の到達確認(同じ tol・同じ算出ルールの timeout 窓で1回だけ)
t0 = time.time()
last_err_retry = None
last_actual_retry = None
while time.time() - t0 < timeout_retry_sec:
actual = _daemon_get_angles_filtered()
if actual is not None:
max_d, _ = wr._max_axis_diff(actual, target)
last_err_retry = max_d
last_actual_retry = actual
if max_d <= reach_tol_deg:
print("[RETRY] 成功: arrival OK max|Δ|={:.2f}° (tol {:.1f}°)".format(
max_d, reach_tol_deg))
return True, True
time.sleep(POLL_SLEEP)
le_r = "{:.2f}".format(last_err_retry) if last_err_retry is not None else "None"
la_r = _fmt_angles(last_actual_retry) if last_actual_retry is not None else "None"
print("[RETRY] 失敗。ABORT へ. {:.1f}s 内に未到達: max|Δ|={}° actual={}".format(
timeout_retry_sec, le_r, la_r))
return False, True
def _next_output_paths(out_root, phase):
"""j0_sweep_{phase}_{NN}.json と j0_sweep_{phase}_{NN}_frames/ の次の連番を返す。
既存ファイル/ディレクトリは上書きしない。"""
out_root.mkdir(parents=True, exist_ok=True)
for n in range(1, 1000):
seq = "{:02d}".format(n)
json_path = out_root / "j0_sweep_{}_{}.json".format(phase, seq)
frames_dir = out_root / "j0_sweep_{}_{}_frames".format(phase, seq)
if not json_path.exists() and not frames_dir.exists():
frames_dir.mkdir(parents=True, exist_ok=False)
return json_path, frames_dir
raise RuntimeError("出力ファイル連番が 999 を超えました")
def _atomic_write_json(path, data):
"""tmp ファイルに書き出してから rename。途中 ABORT でも path が壊れない。"""
tmp = path.with_suffix(path.suffix + ".tmp")
with open(str(tmp), "w") as f:
json.dump(data, f, ensure_ascii=False, indent=2)
os.replace(str(tmp), str(path))
def _capture_frame(cap):
"""cap から 1 frame 取得(数枚捨ててバッファをクリア)。"""
for _ in range(3):
cap.read()
ret, frame = cap.read()
if not ret or frame is None:
return None
return frame
def _detect_for_phase(frame, phase):
"""phase に応じた検出を実行。
戻り値: {"ok", "xz_m", "score", "pixel", "info"}
- tip / red_block とも score は提供されないため None で記録する
- pixel は描画用(成功時のみ)
"""
target = PHASE_DETECT_TARGET[phase]
if target == "tip":
try:
tip_pixel, blue_markers, tip_unity = detect_tip_from_frame(frame)
except Exception as e:
return {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "tip 検出例外: {}".format(e)}
if tip_pixel is None or tip_unity is None:
n_markers = 0 if blue_markers is None else len(blue_markers)
return {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "tip 未検出(青マーカー {} 点)".format(n_markers)}
ux, uz = tip_unity
return {"ok": True, "xz_m": [float(ux), float(uz)], "score": None,
"pixel": tip_pixel,
"info": "tip pixel=({}, {})".format(int(tip_pixel[0]), int(tip_pixel[1]))}
elif target == "red_block":
try:
pixel = detect_red_block(frame)
except Exception as e:
return {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "red_block 検出例外: {}".format(e)}
if pixel is None:
return {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "red_block 未検出(HSV しきい値内の領域なし)"}
cx, cy = pixel
try:
ux, uz = pixel_to_unity(cx, cy)
except Exception as e:
return {"ok": False, "xz_m": None, "score": None, "pixel": pixel,
"info": "pixel_to_unity 例外: {}".format(e)}
return {"ok": True, "xz_m": [float(ux), float(uz)], "score": None,
"pixel": pixel,
"info": "red_block pixel=({}, {})".format(int(cx), int(cy))}
return {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "unknown detect target: {}".format(target)}
def _annotate_and_save(frame, det, j0_cmd, phase, dst_path):
"""frame に検出結果を描画して dst_path に保存する(成功・失敗とも保存)。"""
out = frame.copy()
cv2.putText(out, "phase={} j0_cmd={:+.1f}".format(phase, j0_cmd),
(10, 30), cv2.FONT_HERSHEY_SIMPLEX, 0.7, (0, 255, 0), 2)
if det.get("pixel") is not None:
try:
ipx = int(det["pixel"][0])
ipy = int(det["pixel"][1])
cv2.circle(out, (ipx, ipy), 12, (0, 0, 255), 2)
cv2.drawMarker(out, (ipx, ipy), (0, 0, 255), cv2.MARKER_CROSS, 22, 2)
except Exception:
pass
if det["ok"]:
ux, uz = det["xz_m"]
score = det["score"]
s_str = "{:.3f}".format(score) if isinstance(score, (int, float)) else "None"
cv2.putText(out,
"detect: x={:+.3f}m z={:+.3f}m score={}".format(ux, uz, s_str),
(10, 60), cv2.FONT_HERSHEY_SIMPLEX, 0.6, (0, 255, 0), 2)
else:
cv2.putText(out, "detect: FAILED ({})".format(det.get("info", "")),
(10, 60), cv2.FONT_HERSHEY_SIMPLEX, 0.6, (0, 0, 255), 2)
ok_write = cv2.imwrite(str(dst_path), out)
if not ok_write:
print("[WARN] cv2.imwrite が False を返しました: {}".format(dst_path))
def _resolve_base_angles(teach_json_path, phase):
"""waypoint_replay の抽出ロジックを流用し、指定工程の 6 軸基準姿勢を返す。
抽出ロジック自体は触らない(印優先・phase 範囲フィルタ・APPROACH argmax)。"""
payload, angles, phases, gripper_events, count = wr._load_teach(str(teach_json_path))
waypoints, sources = wr._extract_waypoints(angles, phases, gripper_events, count)
name = PHASE_TO_WP_KEY[phase]
base = list(waypoints[name])
src = sources[name]
return base, src
def _parse_base_angles_arg(s):
"""--base-angles の "j0,j1,j2,j3,j4,j5" をパースして長さ 6 の float リストを返す。
フォーマット違反は ValueError。"""
parts = [p.strip() for p in s.split(",")]
if len(parts) != 6:
raise ValueError(
"--base-angles は 6 値(カンマ区切り)が必要。got {} 値: {!r}".format(
len(parts), s))
vals = []
for i, p in enumerate(parts):
try:
vals.append(float(p))
except ValueError:
raise ValueError(
"--base-angles の {} 番目が数値でない: {!r}(全体: {!r})".format(
i + 1, p, s))
return vals
def _generate_sweep_points(j0_min, j0_max, step):
"""j0_min から step 刻みで j0_max まで(境界含む)の点列を返す。"""
if step <= 0:
raise ValueError("step must be > 0")
if j0_max < j0_min:
raise ValueError("j0_max < j0_min")
pts = []
n = int(math.floor((j0_max - j0_min) / step + 1e-9)) + 1
for k in range(n):
v = j0_min + step * k
if v > j0_max + 1e-6:
break
pts.append(round(v, 6))
return pts
# ---- メイン --------------------------------------------------------------
def main():
p = argparse.ArgumentParser(description="j0 単軸スイープ + 上カメラ位置検出(工程別)")
p.add_argument("--phase", required=True, choices=VALID_PHASES,
help="計測する工程")
p.add_argument("--j0-min", type=float, default=None,
help="j0 最小値 (度)。--no-move 時は不要")
p.add_argument("--j0-max", type=float, default=None,
help="j0 最大値 (度)。--no-move 時は不要")
p.add_argument("--step", type=float, default=None,
help="j0 ステップ幅 (度, >0)。--no-move 時は不要")
p.add_argument("--no-move", action="store_true",
help=("アームへの送信を一切行わず、現在姿勢で 1 点だけ測定する。"
"事前に人手で目標姿勢へ移動済みのケース用。"
"--j0-min/--j0-max/--step は無視され、j0_cmd には実測 j0 が入る"))
p.add_argument("--settle", type=float, default=DEFAULT_SETTLE_SEC,
help="各停止点での安定待ち秒 (デフォルト {:.1f}s)".format(DEFAULT_SETTLE_SEC))
p.add_argument("--teach-json", type=str, default=str(DEFAULT_TEACH_JSON),
help="teach JSON のパス(--base-angles 指定時は使用しない)")
p.add_argument("--base-angles", type=str, default=None,
help=('基準姿勢を直接指定("j0,j1,j2,j3,j4,j5" カンマ区切り)。'
'指定時は teach JSON 抽出をスキップし、この値を base_angles として使う。'
'JOINT_LIMITS 検査は従来どおり適用'))
p.add_argument("--out-dir", type=str, default=str(DEFAULT_OUTPUT_ROOT),
help="出力ディレクトリ")
p.add_argument("--top", type=int, default=None,
help="上カメラ index(未指定なら camera_resolver で自動)")
args = p.parse_args()
if args.settle < 0:
print("[ABORT] --settle は 0 以上を指定してください")
sys.exit(1)
if not args.no_move:
if args.j0_min is None or args.j0_max is None or args.step is None:
print("[ABORT] 通常モードでは --j0-min / --j0-max / --step が必須です "
"(--no-move 指定時は不要)")
sys.exit(1)
if args.step <= 0:
print("[ABORT] --step は正の値を指定してください")
sys.exit(1)
if args.j0_max < args.j0_min:
print("[ABORT] --j0-max < --j0-min は不正")
sys.exit(1)
phase = args.phase
# 到達許容: PICK 工程のみ wsr.HOLD_TOL_DEG(=3.0°)に緩和。他工程は TOL_REACH_DEG(=2.0°)。
# 3.0 を別途ハードコードせず、wsr.HOLD_TOL_DEG から参照する(値の出どころを1か所に保つ)。
reach_tol_deg = wsr.HOLD_TOL_DEG if phase == "pick" else TOL_REACH_DEG
print("[INIT] reach_tol_deg = {:.2f}° (phase={})".format(reach_tol_deg, phase))
# 1. 基準姿勢の解決:--base-angles が指定されていればそれを使い、
# 無ければ teach JSON から既存の抽出ロジックで取り出す。
teach_json = None # cli_direct 時は None のまま(出力 JSON の source_teach_json で参照)
if args.base_angles is not None:
try:
base_angles = _parse_base_angles_arg(args.base_angles)
except ValueError as e:
print("[ABORT] {}".format(e))
sys.exit(1)
base_source = "cli_direct: {}".format(args.base_angles)
print("[INIT] base_angles を CLI で直接指定(teach JSON 抽出はスキップ)")
else:
teach_json = Path(args.teach_json).expanduser()
if not teach_json.exists():
print("[ABORT] teach JSON が見つかりません: {}".format(teach_json))
sys.exit(1)
print("[INIT] teach JSON: {}".format(teach_json))
try:
base_angles, base_source = _resolve_base_angles(teach_json, phase)
except SystemExit:
raise
except Exception as e:
print("[ABORT] 基準姿勢の抽出で例外: {}".format(e))
sys.exit(1)
print("[INIT] phase={} 基準姿勢: {}".format(phase, _fmt_angles(base_angles)))
print("[INIT] 抽出根拠: {}".format(base_source))
j0_teach = base_angles[0]
print("[INIT] 教示時 j0 = {:+.2f}°".format(j0_teach))
# 2. スイープ点を生成(--no-move 時は生成しない)
if args.no_move:
pts = None
print("[INIT] --no-move 指定: 現在姿勢で 1 点のみ測定(送信なし)")
else:
pts = _generate_sweep_points(args.j0_min, args.j0_max, args.step)
print("[INIT] スイープ点 ({} 点): {}".format(
len(pts), ", ".join("{:+.2f}".format(v) for v in pts)))
if len(pts) == 0:
print("[ABORT] スイープ点がゼロです")
sys.exit(1)
# 3. JOINT_LIMITS 一括検査(送信前)
# base_angles 自体も検査する。基準姿勢は最初に send_angles される(STEP 8)ので、
# スイープ点の検査より前に守る必要がある。
# --no-move 時は送信しないが、base_angles は metadata として記録されるので検査は維持。
print("[INIT] JOINT_LIMITS 一括検査 ...")
base_viol = wr._check_joint_limits(base_angles)
if base_viol:
print("[ABORT] JOINT_LIMITS 違反: base_angles が範囲外(基準姿勢が不正)")
for axis, val, lo, hi in base_viol:
print(" base j{}={:+.3f} not in [{:.1f}, {:.1f}]".format(
axis + 1, val, lo, hi))
sys.exit(1)
if pts is not None:
bad = []
for j0v in pts:
target = [j0v] + list(base_angles[1:])
viol = wr._check_joint_limits(target)
if viol:
bad.append((j0v, viol))
if bad:
print("[ABORT] JOINT_LIMITS 違反 ({} 点):".format(len(bad)))
for j0v, viol in bad:
for axis, val, lo, hi in viol:
print(" j0_cmd={:+.2f}° j{}={:+.3f} not in [{:.1f}, {:.1f}]".format(
j0v, axis + 1, val, lo, hi))
sys.exit(1)
print("[INIT] JOINT_LIMITS OK (base + {} スイープ点)".format(len(pts)))
else:
print("[INIT] JOINT_LIMITS OK (base のみ。スイープ点は --no-move のため対象外)")
# 4. daemon ping(get_daemon_socket 内部で ping を発行)
print("[INIT] daemon 接続中 ...")
try:
get_daemon_socket()
except Exception as e:
print("[ABORT] daemon ping 失敗: {}".format(e))
sys.exit(1)
print("[INIT] daemon ping OK")
cap = None
output_data = None
json_path = None
frames_dir = None
exit_code = 0
try:
if not daemon_set_fresh_mode(1):
print("[ABORT] fresh_mode=1 設定に失敗")
sys.exit(1)
print("[INIT] fresh_mode=1")
# 現在姿勢 → base_angles 差分チェック
print("[INIT] 現在姿勢を取得(最大 {} 回・{:.1f}s 間隔・ゴミ読みフィルタ)".format(
GET_ANGLES_RETRY, GET_ANGLES_RETRY_SLEEP))
current = _daemon_get_angles_filtered()
if current is None:
print("[ABORT] 現在姿勢が取得できません")
sys.exit(1)
print("[INIT] 現在姿勢 = {}".format(_fmt_angles(current)))
if args.no_move:
print("[INIT] --no-move のため、基準姿勢への移動・30° 急加速チェックはスキップ")
else:
first_max, _ = wr._max_axis_diff(base_angles, current)
print("[INIT] 現在 → 基準姿勢 max|Δ| = {:.2f}°".format(first_max))
if first_max > FIRST_MOVE_WARN_DEG:
print("[WARN] 先頭移動の max|Δ| {:.2f}° > {:.1f}°。急加速の可能性があります".format(
first_max, FIRST_MOVE_WARN_DEG))
print("[INIT] 続行するには 'yes' と入力(それ以外は中止)")
try:
ans = input().strip()
except EOFError:
print("[ABORT] stdin EOF")
sys.exit(1)
if ans != "yes":
print("[INIT] 中止しました")
sys.exit(1)
# 5. カメラ解決+セットアップ
top_index = args.top
if top_index is None:
try:
cr = importlib.import_module("camera_resolver")
cams = cr.resolve_cameras(require_top=True, require_side=False)
top_index = cams.get("top") if cams else None
except Exception as e:
print("[ABORT] camera_resolver 失敗: {}".format(e))
sys.exit(1)
if top_index is None:
print("[ABORT] 上カメラ未解決")
sys.exit(1)
print("[CAM] 上カメラ index = {}".format(top_index))
cap = cv2.VideoCapture(top_index)
if not cap.isOpened():
print("[ABORT] カメラ open 失敗 (index={})".format(top_index))
sys.exit(1)
for _ in range(WARMUP_FRAMES):
cap.read()
if not setup_homography_and_mat_range(cap):
print("[ABORT] homography セットアップ失敗")
sys.exit(1)
print("[CAM] homography OK")
# 6. 爪状態確認
if phase == "approach_pick":
prompt = ("[CONFIRM] phase={} → 検出対象=爪先(青シール)。"
"爪は空(ブロックを咥えていない)状態にしてください。OK なら Enter".format(phase))
else:
prompt = ("[CONFIRM] phase={} → 検出対象=赤ブロック。"
"爪に赤ブロックを咥えさせた状態にしてください。OK なら Enter".format(phase))
print(prompt)
try:
input()
except EOFError:
print("[ABORT] stdin EOF")
sys.exit(1)
# 7. 出力パス確保(連番。既存があればインクリメント。上書き禁止)
out_root = Path(args.out_dir).expanduser()
json_path, frames_dir = _next_output_paths(out_root, phase)
print("[OUT] JSON : {}".format(json_path))
print("[OUT] frames: {}/".format(frames_dir))
output_data = {
"phase": phase,
"detect_target": PHASE_DETECT_TARGET[phase],
"base_angles": list(base_angles),
"source_teach_json": teach_json.name if teach_json is not None else None,
"base_source": base_source,
"height_note": "床面homography基準。工程をまたぐ位置データの混用禁止",
"frames_dir": frames_dir.name + "/",
"sweep_params": {
"j0_min": args.j0_min,
"j0_max": args.j0_max,
"step": args.step,
"settle_sec": args.settle,
"n_points": 1 if args.no_move else len(pts),
"speed": SPEED,
"tol_reach_deg": reach_tol_deg,
"no_move": bool(args.no_move),
},
"sweep": [],
}
_atomic_write_json(json_path, output_data)
# 8〜10: --no-move 時は送信を一切行わず、現在姿勢で 1 点だけ測定する
if args.no_move:
print("[MEASURE] --no-move: 単一点測定モード(送信なし)")
print("[MEASURE] settle {:.1f}s".format(args.settle))
time.sleep(args.settle)
actual = _daemon_get_angles_filtered()
if actual is None:
print("[ABORT] 測定時の get_angles 全失敗。記録なしで終了")
sys.exit(1)
j0_cmd = actual[0] # 実測 j0 を j0_cmd として記録
print("[MEASURE] actual = {} (j0_cmd = j0_actual = {:+.2f}°)".format(
_fmt_angles(actual), j0_cmd))
frame = _capture_frame(cap)
if frame is None:
print("[WARN] フレーム取得失敗。placeholder 画像で記録")
det = {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "frame capture failed"}
frame_for_save = np.zeros((PLACEHOLDER_H, PLACEHOLDER_W, 3),
dtype=np.uint8)
else:
det = _detect_for_phase(frame, phase)
frame_for_save = frame
frame_filename = "j0_{:+06.1f}.jpg".format(j0_cmd)
frame_path = frames_dir / frame_filename
try:
_annotate_and_save(frame_for_save, det, j0_cmd, phase, frame_path)
except Exception as e:
print("[WARN] フレーム保存例外: {}".format(e))
if det["ok"]:
ux, uz = det["xz_m"]
print("[MEASURE] detect OK: xz=({:+.3f}, {:+.3f}) ({})".format(
ux, uz, det["info"]))
else:
print("[MEASURE] detect FAILED: {}".format(det["info"]))
point = {
"j0_cmd": j0_cmd,
"angles_actual": actual,
"detect_xz_m": det["xz_m"],
"detect_score": det["score"],
"detect_ok": bool(det["ok"]),
"frame_file": frame_filename,
"send_retried": False,
}
if not det["ok"]:
point["detect_info"] = det["info"]
output_data["sweep"].append(point)
_atomic_write_json(json_path, output_data)
print("[MEASURE] 完了(1 点記録)")
else:
# 通常モード:基準姿勢へ移動 → スイープループ → 基準姿勢へ復帰
# 8. 基準姿勢へ移動
print("[MOVE] 基準姿勢(教示時 j0={:+.2f}°)へ移動 ...".format(j0_teach))
ok, _ = _send_and_wait_arrival(base_angles, "to base", reach_tol_deg)
if not ok:
print("[ABORT] 基準姿勢への到達確認タイムアウト。スイープを開始しません")
sys.exit(1)
# 9. スイープループ
n_ok = 0
n_fail = 0
# 直前の成功フレームのサイズを記録(取得失敗時の placeholder サイズに使う)
last_frame_shape = None
for i, j0v in enumerate(pts):
tag = "[{:2d}/{:2d}]".format(i + 1, len(pts))
target = [j0v] + list(base_angles[1:])
print("--- {} j0_cmd={:+.2f}° target={} ---".format(
tag, j0v, _fmt_angles(target)))
ok, retried = _send_and_wait_arrival(target, "{} j0={:+.2f}".format(tag, j0v), reach_tol_deg)
if not ok:
print("[ABORT] {} 到達確認タイムアウト。これまでの記録を保存して終了".format(tag))
_atomic_write_json(json_path, output_data)
sys.exit(1)
print("{} settle {:.1f}s".format(tag, args.settle))
time.sleep(args.settle)
actual = _daemon_get_angles_filtered()
if actual is None:
print("[ABORT] {} get_angles 全失敗。これまでの記録を保存して終了".format(tag))
_atomic_write_json(json_path, output_data)
sys.exit(1)
print("{} actual = {}".format(tag, _fmt_angles(actual)))
frame = _capture_frame(cap)
if frame is None:
print("[WARN] {} フレーム取得失敗。検出スキップ・placeholder 画像で記録".format(tag))
det = {"ok": False, "xz_m": None, "score": None, "pixel": None,
"info": "frame capture failed"}
if last_frame_shape is not None:
ph_h, ph_w = last_frame_shape[0], last_frame_shape[1]
ph_c = last_frame_shape[2] if len(last_frame_shape) >= 3 else 3
else:
ph_h, ph_w, ph_c = PLACEHOLDER_H, PLACEHOLDER_W, 3
frame_for_save = np.zeros((ph_h, ph_w, ph_c), dtype=np.uint8)
else:
det = _detect_for_phase(frame, phase)
frame_for_save = frame
last_frame_shape = frame.shape
frame_filename = "j0_{:+06.1f}.jpg".format(j0v)
frame_path = frames_dir / frame_filename
try:
_annotate_and_save(frame_for_save, det, j0v, phase, frame_path)
except Exception as e:
print("[WARN] {} フレーム保存例外: {}".format(tag, e))
if det["ok"]:
ux, uz = det["xz_m"]
print("{} detect OK: xz=({:+.3f}, {:+.3f}) ({})".format(
tag, ux, uz, det["info"]))
n_ok += 1
else:
print("{} detect FAILED: {}".format(tag, det["info"]))
n_fail += 1
point = {
"j0_cmd": j0v,
"angles_actual": actual,
"detect_xz_m": det["xz_m"],
"detect_score": det["score"],
"detect_ok": bool(det["ok"]),
"frame_file": frame_filename,
"send_retried": bool(retried),
}
if not det["ok"]:
point["detect_info"] = det["info"]
output_data["sweep"].append(point)
_atomic_write_json(json_path, output_data)
print("[SWEEP] 完了: 検出成功 {}/{}, 失敗 {}".format(n_ok, len(pts), n_fail))
# 10. 基準姿勢へ復帰
print("[MOVE] 基準姿勢へ復帰 ...")
ok, _ = _send_and_wait_arrival(base_angles, "back to base", reach_tol_deg)
if not ok:
print("[WARN] 復帰の到達確認タイムアウト。送信は停止します(姿勢はその場維持)")
except KeyboardInterrupt:
print("\n[INTERRUPT] Ctrl-C 検出。新しい送信を停止し、これまでの記録を保存します")
if output_data is not None and json_path is not None:
try:
_atomic_write_json(json_path, output_data)
except Exception as e:
print("[WARN] 中断時の保存に失敗: {}".format(e))
exit_code = 130
finally:
try:
if cap is not None:
cap.release()
except Exception:
pass
try:
cv2.destroyAllWindows()
except Exception:
pass
try:
daemon_set_fresh_mode(0)
except Exception as e:
print("[WARN] fresh_mode=0 失敗: {}".format(e))
try:
close_daemon_socket()
except Exception:
pass
# 最終保存(KeyboardInterrupt 経路も含めもう一度ベストエフォートで)
if output_data is not None and json_path is not None:
try:
_atomic_write_json(json_path, output_data)
except Exception:
pass
if json_path is not None:
print("[EXIT] JSON : {}".format(json_path))
if frames_dir is not None:
try:
n_files = sum(1 for p in frames_dir.iterdir() if p.is_file())
except Exception:
n_files = -1
print("[EXIT] frames : {} ({} files)".format(frames_dir, n_files))
sys.exit(exit_code)
if __name__ == "__main__":
main()
確認プロンプトと到達判定を持たないシンプル版。この日は犯人特定の比較材料として働いた。j1=91.66問題が解決した後は、到達確認を持つscan版を主力に戻している。
#!/usr/bin/env python3
# -*- coding: utf-8 -*-
"""j0_sweep_simple.py — j0 単軸スイープ シンプル直行版(プロンプト・判定なし)

PICK 高度の j0 スイープを一直線に取り切る最小構成。エイイチが実機を目視で見張る
前提のため、確認プロンプト・到達判定・タイムアウト ABORT・リトライを持たない。
ヘルパ(実測取得・JSON 保存・フレーム取得・検出・描画)は j0_sweep_scan.py
からそのまま import 流用する。新規発明はしない。

絶対ルール:
- send_coords() / release_all_servos() を呼ばない(daemon TCP 経由なので構造的に呼べない)
- set_gripper を呼ばない(このスクリプトはグリッパー操作の責任外)
- daemon にコマンドを追加しない
- 全送信前に JOINT_LIMITS(waypoint_replay の実測値)一括検査
- 1点ごとに JSON を atomic write(途中 Ctrl+C でもデータが残る)

動作フロー(プロンプト一切なし):
  1. daemon 接続 → fresh_mode=1
  2. 現在姿勢を取得(_daemon_get_angles_filtered)
  3. ウォームアップ: 現在姿勢宛に send_angles を1回 → WARMUP_SLEEP_SEC 待ち
     (接続後初回 send が捨てられる実機事象対策。現在姿勢宛なので物理的に無害)
  4. カメラ初期化 + homography
  5. スイープループ (k=1..N):
       target = [j0_k, *PICK_BASE_ANGLES[1:]]
       send_angles(target, speed=SPEED, wait=0) を1回
       sleep = max(SETTLE_MIN_SEC, max|Δ|(target, prev_actual) / SETTLE_PER_DEG)
       実測取得(届いていなくてもそのまま記録)
       上カメラ frame → 赤ブロック検出(失敗なら detect_ok=false で続行)
       JSON へ追記保存
  6. HOME へ1回送信 → fresh_mode=0 → 終了

CLI:
    python3 j0_sweep_simple.py --j0-min=-85 --j0-max=85 --points=20

出力:
    ~/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_simple_{NN}.json
    ~/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_simple_{NN}_frames/j0_{j0_cmd:+06.1f}.jpg
"""

from __future__ import print_function

import argparse
import importlib
import sys
import time
import types
from pathlib import Path


# ---- パス解決(j0_sweep_scan.py と同じ計算)-------------------------------
_THIS = Path(__file__).resolve()
_PLACE_MODULES_DIR = _THIS.parent
_SCRIPTS_ROOT = _THIS.parents[3]  # ~/r2r2r-scripts
_DRAG_TEACHING_DIR = _SCRIPTS_ROOT / "dynamic_tracking_limits" / "drag_teaching"
sys.path.insert(0, str(_SCRIPTS_ROOT))
sys.path.insert(0, str(_PLACE_MODULES_DIR))
sys.path.insert(0, str(_DRAG_TEACHING_DIR))


# ---- pymycobot スタブ(waypoint_replay 系の import 対策。実体化されたら即 RuntimeError)
# j0_sweep_scan.py と同等。先に注入しておけば、後段の j0_sweep_scan import 時に
# 同モジュールのスタブ注入は条件分岐でスキップされる。
if "pymycobot" not in sys.modules:
    _pkg = types.ModuleType("pymycobot")
    _mod = types.ModuleType("pymycobot.mycobot")

    class _MyCobotStub(object):
        def __init__(self, *args, **kwargs):
            raise RuntimeError(
                "j0_sweep_simple.py: MyCobot stub is not callable. "
                "Arm control must go through daemon TCP, not direct serial.")

    _mod.MyCobot = _MyCobotStub
    sys.modules["pymycobot"] = _pkg
    sys.modules["pymycobot.mycobot"] = _mod


# ---- 流用 import ----------------------------------------------------------
import cv2  # noqa: E402
import numpy as np  # noqa: E402

import waypoint_replay as wr  # noqa: E402
from visual_servo_pick import (  # noqa: E402
    get_daemon_socket,
    close_daemon_socket,
    daemon_send_angles,
    daemon_set_fresh_mode,
    setup_homography_and_mat_range,
)
# j0_sweep_scan の検査済みヘルパをそのまま流用(新規発明しない):
#   _daemon_get_angles_filtered / _fmt_angles / _atomic_write_json
#   _capture_frame / _detect_for_phase / _annotate_and_save
import j0_sweep_scan as jss  # noqa: E402


# ---- 定数 -----------------------------------------------------------------
# PICK 基準姿勢: drag_v2 teach (drag_v2_20221013_152840_with_pos.json) の PICK
# ウェイポイントから抽出した値。j0 のみスイープで動かす(スイープ中は target[0] に
# j0_cmd を入れ、[1:] は不変)。先頭の 0.0 はループ内で上書きされる placeholder。
PICK_BASE_ANGLES = [0.0, 91.66, -21.44, 1.40, -70.48, -32.87]
HOME_ANGLES = [0.0, 0.0, 0.0, 0.0, 0.0, -30.0]

SPEED = 20                       # 全送信共通

WARMUP_SLEEP_SEC = 0.5            # ウォームアップ送信後の待ち
SETTLE_MIN_SEC = 3.0              # 各点の sleep 下限
SETTLE_PER_DEG = 10.0             # max|Δ|° / SETTLE_PER_DEG で動的下乗せ

WARMUP_FRAMES = 30
PLACEHOLDER_W = 1280
PLACEHOLDER_H = 720

PHASE = "pick"
DETECT_TARGET = "red_block"

DEFAULT_OUTPUT_ROOT = Path.home() / "r2r2r-scripts" / "dynamic_tracking_limits" / "logs" / "j0_sweep"


# ---- ヘルパ ---------------------------------------------------------------
def _generate_sweep_points(j0_min, j0_max, n_points):
    """j0_min から j0_max まで等分割(両端含む)で n_points 点を返す。"""
    if n_points < 2:
        raise ValueError("--points は 2 以上を指定してください")
    if j0_max <= j0_min:
        raise ValueError("--j0-max は --j0-min より大きい値を指定してください")
    step = (j0_max - j0_min) / (n_points - 1)
    pts = [round(j0_min + step * k, 6) for k in range(n_points)]
    # 浮動小数誤差で末端が j0_max と僅かに食い違うのを補正
    pts[-1] = round(j0_max, 6)
    return pts


def _next_output_paths_simple(out_root):
    """j0_sweep_pick_simple_{NN}.json と ..._frames/ の次の連番を返す。
    既存ファイル/ディレクトリは上書きしない。"""
    out_root.mkdir(parents=True, exist_ok=True)
    for n in range(1, 1000):
        seq = "{:02d}".format(n)
        json_path = out_root / "j0_sweep_pick_simple_{}.json".format(seq)
        frames_dir = out_root / "j0_sweep_pick_simple_{}_frames".format(seq)
        if not json_path.exists() and not frames_dir.exists():
            frames_dir.mkdir(parents=True, exist_ok=False)
            return json_path, frames_dir
    raise RuntimeError("出力ファイル連番が 999 を超えました")


# ---- メイン --------------------------------------------------------------
def main():
    p = argparse.ArgumentParser(
        description="j0 単軸スイープ シンプル直行版(プロンプト・到達判定・リトライなし)")
    p.add_argument("--j0-min", type=float, required=True, help="j0 最小値 (度)")
    p.add_argument("--j0-max", type=float, required=True, help="j0 最大値 (度)")
    p.add_argument("--points", type=int, required=True,
                   help="点数(両端含む等分割。2 以上)")
    p.add_argument("--out-dir", type=str, default=str(DEFAULT_OUTPUT_ROOT),
                   help="出力ディレクトリ")
    p.add_argument("--top", type=int, default=None,
                   help="上カメラ index(未指定なら camera_resolver で自動)")
    args = p.parse_args()

    # スイープ点生成
    try:
        pts = _generate_sweep_points(args.j0_min, args.j0_max, args.points)
    except ValueError as e:
        print("[ABORT] {}".format(e))
        sys.exit(1)
    print("[INIT] スイープ点 ({} 点): {}".format(
        len(pts), ", ".join("{:+.2f}".format(v) for v in pts)))

    # JOINT_LIMITS 一括検査(送信前のみ。実行中は判定しない)
    print("[INIT] JOINT_LIMITS 一括検査 ...")
    base_viol = wr._check_joint_limits(PICK_BASE_ANGLES)
    if base_viol:
        print("[ABORT] JOINT_LIMITS 違反: PICK_BASE_ANGLES が範囲外")
        for axis, val, lo, hi in base_viol:
            print("  base  j{}={:+.3f} not in [{:.1f}, {:.1f}]".format(
                axis + 1, val, lo, hi))
        sys.exit(1)
    home_viol = wr._check_joint_limits(HOME_ANGLES)
    if home_viol:
        print("[ABORT] JOINT_LIMITS 違反: HOME_ANGLES が範囲外")
        for axis, val, lo, hi in home_viol:
            print("  home  j{}={:+.3f} not in [{:.1f}, {:.1f}]".format(
                axis + 1, val, lo, hi))
        sys.exit(1)
    bad = []
    for j0v in pts:
        target = [j0v] + list(PICK_BASE_ANGLES[1:])
        viol = wr._check_joint_limits(target)
        if viol:
            bad.append((j0v, viol))
    if bad:
        print("[ABORT] JOINT_LIMITS 違反 ({} 点):".format(len(bad)))
        for j0v, viol in bad:
            for axis, val, lo, hi in viol:
                print("  j0_cmd={:+.2f}°  j{}={:+.3f} not in [{:.1f}, {:.1f}]".format(
                    j0v, axis + 1, val, lo, hi))
        sys.exit(1)
    print("[INIT] JOINT_LIMITS OK (base + HOME + {} スイープ点)".format(len(pts)))

    # daemon 接続
    print("[INIT] daemon 接続中 ...")
    try:
        get_daemon_socket()
    except Exception as e:
        print("[ABORT] daemon ping 失敗: {}".format(e))
        sys.exit(1)
    print("[INIT] daemon ping OK")

    cap = None
    output_data = None
    json_path = None
    frames_dir = None
    exit_code = 0
    try:
        if not daemon_set_fresh_mode(1):
            print("[ABORT] fresh_mode=1 設定に失敗")
            sys.exit(1)
        print("[INIT] fresh_mode=1")

        # 現在姿勢取得
        print("[INIT] 現在姿勢を取得 ...")
        current = jss._daemon_get_angles_filtered()
        if current is None:
            print("[ABORT] 現在姿勢が取得できません")
            sys.exit(1)
        print("[INIT] 現在姿勢 = {}".format(jss._fmt_angles(current)))

        # ウォームアップ送信(現在姿勢宛 → 物理的に動かない。初回 send 捨て対策)
        print("[INIT] ウォームアップ送信(現在姿勢宛 1 回)→ {:.1f}s 待機".format(
            WARMUP_SLEEP_SEC))
        try:
            daemon_send_angles(current, speed=SPEED, wait=0)
        except Exception as e:
            print("[ABORT] ウォームアップ送信例外: {}".format(e))
            sys.exit(1)
        time.sleep(WARMUP_SLEEP_SEC)

        # カメラ + homography
        top_index = args.top
        if top_index is None:
            try:
                cr = importlib.import_module("camera_resolver")
                cams = cr.resolve_cameras(require_top=True, require_side=False)
                top_index = cams.get("top") if cams else None
            except Exception as e:
                print("[ABORT] camera_resolver 失敗: {}".format(e))
                sys.exit(1)
            if top_index is None:
                print("[ABORT] 上カメラ未解決")
                sys.exit(1)
        print("[CAM] 上カメラ index = {}".format(top_index))
        cap = cv2.VideoCapture(top_index)
        if not cap.isOpened():
            print("[ABORT] カメラ open 失敗 (index={})".format(top_index))
            sys.exit(1)
        for _ in range(WARMUP_FRAMES):
            cap.read()
        if not setup_homography_and_mat_range(cap):
            print("[ABORT] homography セットアップ失敗")
            sys.exit(1)
        print("[CAM] homography OK")

        # 出力パス
        out_root = Path(args.out_dir).expanduser()
        json_path, frames_dir = _next_output_paths_simple(out_root)
        print("[OUT] JSON  : {}".format(json_path))
        print("[OUT] frames: {}/".format(frames_dir))

        output_data = {
            "phase": PHASE,
            "detect_target": DETECT_TARGET,
            "base_angles": list(PICK_BASE_ANGLES),
            "base_source": "code constant: PICK_BASE_ANGLES (drag_v2 teach の PICK 基準)",
            "frames_dir": frames_dir.name + "/",
            "sweep_params": {
                "j0_min": args.j0_min,
                "j0_max": args.j0_max,
                "n_points": len(pts),
                "speed": SPEED,
                "settle_min_sec": SETTLE_MIN_SEC,
                "settle_per_deg": SETTLE_PER_DEG,
                "warmup_sleep_sec": WARMUP_SLEEP_SEC,
            },
            "sweep": [],
        }
        jss._atomic_write_json(json_path, output_data)

        # スイープループ:各点 1 回送信 → 時間待ち → 記録(判定なし)
        prev_actual = current  # 待ち時間計算用の前回実測(初回はウォームアップ前の current)
        for i, j0v in enumerate(pts):
            tag = "[{:2d}/{:2d}]".format(i + 1, len(pts))
            target = [j0v] + list(PICK_BASE_ANGLES[1:])

            max_d, _ = wr._max_axis_diff(target, prev_actual)
            settle_sec = max(SETTLE_MIN_SEC, max_d / SETTLE_PER_DEG)

            print("--- {} j0_cmd={:+.2f}° target={} ---".format(
                tag, j0v, jss._fmt_angles(target)))
            print("{} send_angles (single)  speed={}  "
                  "pre max|Δ|={:.2f}° → sleep {:.2f}s".format(
                      tag, SPEED, max_d, settle_sec))

            try:
                daemon_send_angles(target, speed=SPEED, wait=0)
            except Exception as e:
                print("[ABORT] {} daemon_send_angles 例外: {}. "
                      "これまでの記録を保存して終了".format(tag, e))
                jss._atomic_write_json(json_path, output_data)
                sys.exit(1)

            time.sleep(settle_sec)

            actual = jss._daemon_get_angles_filtered()
            if actual is None:
                print("{} [WARN] 実測取得失敗。actual=null で記録(判定はしない)".format(tag))
            else:
                prev_actual = actual
                print("{} actual = {}".format(tag, jss._fmt_angles(actual)))

            frame = jss._capture_frame(cap)
            if frame is None:
                print("[WARN] {} フレーム取得失敗。placeholder 画像で記録".format(tag))
                det = {"ok": False, "xz_m": None, "score": None, "pixel": None,
                       "info": "frame capture failed"}
                frame_for_save = np.zeros((PLACEHOLDER_H, PLACEHOLDER_W, 3),
                                          dtype=np.uint8)
            else:
                det = jss._detect_for_phase(frame, PHASE)
                frame_for_save = frame

            frame_filename = "j0_{:+06.1f}.jpg".format(j0v)
            frame_path = frames_dir / frame_filename
            try:
                jss._annotate_and_save(frame_for_save, det, j0v, PHASE, frame_path)
            except Exception as e:
                print("[WARN] {} フレーム保存例外: {}".format(tag, e))

            if det["ok"]:
                ux, uz = det["xz_m"]
                print("{} detect OK: xz=({:+.3f}, {:+.3f}) ({})".format(
                    tag, ux, uz, det["info"]))
            else:
                print("{} detect FAILED: {}".format(tag, det["info"]))

            point = {
                "j0_cmd": j0v,
                "angles_actual": actual,
                "detect_xz_m": det["xz_m"],
                "detect_ok": bool(det["ok"]),
                "frame_file": frame_filename,
            }
            if not det["ok"]:
                point["detect_info"] = det["info"]
            output_data["sweep"].append(point)
            jss._atomic_write_json(json_path, output_data)

        print("[SWEEP] 完了 ({} 点)".format(len(pts)))

        # HOME へ 1 回送信(判定なし。失敗してもログのみで続行)
        print("[MOVE] HOME へ送信(判定なし。各点同様 1 回のみ)")
        try:
            daemon_send_angles(HOME_ANGLES, speed=SPEED, wait=0)
        except Exception as e:
            print("[WARN] HOME 送信例外: {}".format(e))

    except KeyboardInterrupt:
        # Ctrl+C: 新しい送信は一切行わず、これまでの記録を保存して終了
        print("\n[INTERRUPT] Ctrl-C 検出。新しい送信を停止し、これまでの記録を保存します")
        if output_data is not None and json_path is not None:
            try:
                jss._atomic_write_json(json_path, output_data)
            except Exception as e:
                print("[WARN] 中断時の保存に失敗: {}".format(e))
        exit_code = 130
    finally:
        try:
            if cap is not None:
                cap.release()
        except Exception:
            pass
        try:
            cv2.destroyAllWindows()
        except Exception:
            pass
        try:
            daemon_set_fresh_mode(0)
        except Exception as e:
            print("[WARN] fresh_mode=0 失敗: {}".format(e))
        try:
            close_daemon_socket()
        except Exception:
            pass
        # 最終保存(KeyboardInterrupt 経路も含めもう一度ベストエフォートで)
        if output_data is not None and json_path is not None:
            try:
                jss._atomic_write_json(json_path, output_data)
            except Exception:
                pass
        if json_path is not None:
            print("[EXIT] JSON   : {}".format(json_path))
        if frames_dir is not None:
            try:
                n_files = sum(1 for p in frames_dir.iterdir() if p.is_file())
            except Exception:
                n_files = -1
            print("[EXIT] frames : {} ({} files)".format(frames_dir, n_files))

    sys.exit(exit_code)


if __name__ == "__main__":
    main()
実行ログ(経過の全量)
リトライ実装後・ストリーミング版の最後の試行(_15)。
(base) shimazueiichi@shimadzueiichinoMacBook-Pro r2r2r-content % python3 ~/r2r2r-scripts/dynamic_tracking_limits/place/place_modules/j0_sweep_scan.py --phase pick --j0-min=-85 --j0-max=85 --step=8.95
[INIT] reach_tol_deg = 3.00° (phase=pick)
[INIT] teach JSON: /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/drag_teaching/drag_v2_20221013_152840_with_pos.json
[INIT] phase=pick 基準姿勢: [ -36.03, +91.66, -21.44, +1.40, -70.48, -32.87]
[INIT] 抽出根拠: gripper close mark idx=270(PICK phase 範囲内)
[INIT] 教示時 j0 = -36.03°
[INIT] スイープ点 (19 点): -85.00, -76.05, -67.10, -58.15, -49.20, -40.25, -31.30, -22.35, -13.40, -4.45, +4.50, +13.45, +22.40, +31.35, +40.30, +49.25, +58.20, +67.15, +76.10
[INIT] JOINT_LIMITS 一括検査 ...
[INIT] JOINT_LIMITS OK (base + 19 スイープ点)
[INIT] daemon 接続中 ...
[INIT] daemon ping OK
[Pi] fresh_mode=1
[INIT] fresh_mode=1
[INIT] 現在姿勢を取得(最大 12 回・0.2s 間隔・ゴミ読みフィルタ)
[INIT] 現在姿勢 = [ -34.80, +90.35, -21.00, +1.23, -68.73, -32.95]
[INIT] 現在 → 基準姿勢 max|Δ| = 1.75°
[CAM] 接続中カメラ一覧:
index=0 name=FaceTime HDカメラ
index=1 name=Iriun Camera
index=2 name=iPhone14 Pro MAXのカメラ
[CAM] 上カメラ(iPhone) index=2
[CAM] 横カメラ(Iriun) index=1
[CAM] 上カメラ index = 2
[Mac] マット四隅検出中... (10フレーム)
[Mac] ✓ マット四隅検出: 10/10 フレーム成功
[Mac] ✓ 動的homography計算完了
[Mac] ✓ マット範囲: X=[359, 1581] Y=[107, 1005]
[CAM] homography OK
[CONFIRM] phase=pick → 検出対象=赤ブロック。爪に赤ブロックを咥えさせた状態にしてください。OK なら Enter
[OUT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_15.json
[OUT] frames: /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_15_frames/
[MOVE] 基準姿勢(教示時 j0=-36.03°)へ移動 ...
[SEND] to base: streaming send_angles speed=20 (pre max|Δ|=1.75° → 1 ticks @ 0.1s = 0.1s, post-stream timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.75° (tol 3.0°)
--- [ 1/19] j0_cmd=-85.00° target=[ -85.00, +91.66, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 1/19] j0=-85.00: streaming send_angles speed=20 (pre max|Δ|=50.20° → 26 ticks @ 0.1s = 2.6s, post-stream timeout 9.5s)
[SEND] [TIMEOUT] 9.5s 内に未到達: max|Δ|=50.20° actual=[ -34.80, +90.35, -21.00, +1.23, -68.73, -32.95]
[RETRY] 1回目送信が無視された(移動量 0.00°)。5.0s 待って再送します
[RETRY] [ 1/19] j0=-85.00 (retry): streaming send_angles speed=20 (pre max|Δ|=50.20° → 26 ticks @ 0.1s = 2.6s, post-stream timeout 9.5s)
[RETRY] 失敗。ABORT へ. 9.5s 内に未到達: max|Δ|=50.20° actual=[ -34.80, +90.35, -21.00, +1.23, -68.73, -32.95]
[ABORT] [ 1/19] 到達確認タイムアウト。これまでの記録を保存して終了
[Pi] fresh_mode=0
[EXIT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_15.json
[EXIT] frames : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_15_frames (0 files)_15実行時のPi側daemonログ(提供範囲の全量)。
DAEMON 16:04:06] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:06] cmd received: send_angles
[DAEMON 16:04:06] send_angles 呼び出し前: angles=[-71.48461538461538, 91.30730769230769, -21.321538461538463, 1.3542307692307691, -70.00884615384616, -32.89153846153846], speed=20, wait=0.0
[DAEMON 16:04:06] send_angles 呼び出し後: result=None, elapsed_ms=10.3
[DAEMON 16:04:06] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:06] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:06] cmd received: send_angles
[DAEMON 16:04:06] send_angles 呼び出し前: angles=[-73.41538461538462, 91.3576923076923, -21.33846153846154, 1.3607692307692307, -70.07615384615384, -32.888461538461534], speed=20, wait=0.0
[DAEMON 16:04:06] send_angles 呼び出し後: result=None, elapsed_ms=9.7
[DAEMON 16:04:06] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:07] cmd received: send_angles
[DAEMON 16:04:07] send_angles 呼び出し前: angles=[-75.34615384615384, 91.40807692307692, -21.355384615384615, 1.3673076923076923, -70.14346153846154, -32.885384615384616], speed=20, wait=0.0
[DAEMON 16:04:07] send_angles 呼び出し後: result=None, elapsed_ms=10.8
[DAEMON 16:04:07] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:07] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:07] cmd received: send_angles
[DAEMON 16:04:07] send_angles 呼び出し前: angles=[-77.27692307692308, 91.45846153846153, -21.372307692307693, 1.3738461538461537, -70.21076923076923, -32.88230769230769], speed=20, wait=0.0
[DAEMON 16:04:07] send_angles 呼び出し後: result=None, elapsed_ms=9.4
[DAEMON 16:04:07] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:07] cmd received: send_angles
[DAEMON 16:04:07] send_angles 呼び出し前: angles=[-79.2076923076923, 91.50884615384615, -21.38923076923077, 1.3803846153846153, -70.27807692307692, -32.879230769230766], speed=20, wait=0.0
[DAEMON 16:04:07] send_angles 呼び出し後: result=None, elapsed_ms=8.9
[DAEMON 16:04:08] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:08] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:08] cmd received: send_angles
[DAEMON 16:04:08] send_angles 呼び出し前: angles=[-81.13846153846154, 91.55923076923077, -21.40615384615385, 1.386923076923077, -70.34538461538462, -32.87615384615384], speed=20, wait=0.0
[DAEMON 16:04:08] send_angles 呼び出し後: result=None, elapsed_ms=11.9
[DAEMON 16:04:08] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:08] cmd received: send_angles
[DAEMON 16:04:08] send_angles 呼び出し前: angles=[-83.06923076923077, 91.60961538461538, -21.423076923076923, 1.3934615384615383, -70.41269230769231, -32.87307692307692], speed=20, wait=0.0
[DAEMON 16:04:08] send_angles 呼び出し後: result=None, elapsed_ms=11.1
[DAEMON 16:04:08] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:08] cmd received: send_angles
[DAEMON 16:04:08] send_angles 呼び出し前: angles=[-85.0, 91.66, -21.44, 1.4, -70.48, -32.87], speed=20, wait=0.0
[DAEMON 16:04:08] send_angles 呼び出し後: result=None, elapsed_ms=10.9
[DAEMON 16:04:08] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:08] cmd received: get_angles
[DAEMON 16:04:08] cmd received: get_angles
[DAEMON 16:04:09] cmd received: get_angles
[DAEMON 16:04:09] cmd received: get_angles
[DAEMON 16:04:09] cmd received: get_angles
[DAEMON 16:04:10] cmd received: get_angles
[DAEMON 16:04:10] cmd received: get_angles
[DAEMON 16:04:10] cmd received: get_angles
[DAEMON 16:04:11] cmd received: get_angles
[DAEMON 16:04:11] cmd received: get_angles
[DAEMON 16:04:11] cmd received: get_angles
[DAEMON 16:04:12] cmd received: get_angles
[DAEMON 16:04:12] cmd received: get_angles
[DAEMON 16:04:12] cmd received: get_angles
[DAEMON 16:04:13] cmd received: get_angles
[DAEMON 16:04:13] cmd received: get_angles
[DAEMON 16:04:13] cmd received: get_angles
[DAEMON 16:04:14] cmd received: get_angles
[DAEMON 16:04:14] cmd received: get_angles
[DAEMON 16:04:14] cmd received: get_angles
[DAEMON 16:04:15] cmd received: get_angles
[DAEMON 16:04:15] cmd received: get_angles
[DAEMON 16:04:15] cmd received: get_angles
[DAEMON 16:04:15] cmd received: get_angles
[DAEMON 16:04:16] cmd received: get_angles
[DAEMON 16:04:16] cmd received: get_angles
[DAEMON 16:04:16] cmd received: get_angles
[DAEMON 16:04:17] cmd received: get_angles
[DAEMON 16:04:17] cmd received: get_angles
[DAEMON 16:04:17] cmd received: get_angles
[DAEMON 16:04:23] cmd received: get_angles
[DAEMON 16:04:23] cmd received: send_angles
[DAEMON 16:04:23] send_angles 呼び出し前: angles=[-36.730769230769226, 90.40038461538461, -21.016923076923078, 1.2365384615384616, -68.7973076923077, -32.94692307692308], speed=20, wait=0.0
[DAEMON 16:04:23] send_angles 呼び出し後: result=None, elapsed_ms=11.5
[DAEMON 16:04:25] send_angles_after: get_angles success retry=8 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:25] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:25] cmd received: send_angles
[DAEMON 16:04:25] send_angles 呼び出し前: angles=[-38.661538461538456, 90.45076923076923, -21.033846153846152, 1.243076923076923, -68.86461538461539, -32.94384615384616], speed=20, wait=0.0
[DAEMON 16:04:25] send_angles 呼び出し後: result=None, elapsed_ms=9.4
[DAEMON 16:04:25] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:26] cmd received: send_angles
[DAEMON 16:04:26] send_angles 呼び出し前: angles=[-40.59230769230769, 90.50115384615384, -21.05076923076923, 1.2496153846153846, -68.93192307692308, -32.940769230769234], speed=20, wait=0.0
[DAEMON 16:04:26] send_angles 呼び出し後: result=None, elapsed_ms=12.3
[DAEMON 16:04:26] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:26] cmd received: send_angles
[DAEMON 16:04:26] send_angles 呼び出し前: angles=[-42.52307692307692, 90.55153846153846, -21.067692307692308, 1.2561538461538462, -68.99923076923078, -32.93769230769231], speed=20, wait=0.0
[DAEMON 16:04:26] send_angles 呼び出し後: result=None, elapsed_ms=10.6
[DAEMON 16:04:26] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:26] cmd received: send_angles
[DAEMON 16:04:26] send_angles 呼び出し前: angles=[-44.45384615384615, 90.60192307692307, -21.084615384615386, 1.2626923076923076, -69.06653846153847, -32.934615384615384], speed=20, wait=0.0
[DAEMON 16:04:26] send_angles 呼び出し後: result=None, elapsed_ms=10.4
[DAEMON 16:04:29] send_angles_after: get_angles success retry=11 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:29] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:29] cmd received: send_angles
[DAEMON 16:04:29] send_angles 呼び出し前: angles=[-46.38461538461539, 90.65230769230769, -21.10153846153846, 1.2692307692307692, -69.13384615384616, -32.931538461538466], speed=20, wait=0.0
[DAEMON 16:04:29] send_angles 呼び出し後: result=None, elapsed_ms=12.3
[DAEMON 16:04:29] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:29] cmd received: send_angles
[DAEMON 16:04:29] send_angles 呼び出し前: angles=[-48.315384615384616, 90.7026923076923, -21.11846153846154, 1.2757692307692308, -69.20115384615384, -32.92846153846154], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=12.6
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-50.246153846153845, 90.75307692307692, -21.135384615384616, 1.2823076923076924, -69.26846153846154, -32.925384615384615], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=10.8
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-52.176923076923075, 90.80346153846153, -21.152307692307694, 1.2888461538461538, -69.33576923076923, -32.92230769230769], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=1.1
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-54.107692307692304, 90.85384615384615, -21.16923076923077, 1.2953846153846154, -69.40307692307692, -32.91923076923077], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=12.0
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-56.03846153846153, 90.90423076923076, -21.186153846153847, 1.301923076923077, -69.47038461538462, -32.91615384615385], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=12.0
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-57.96923076923077, 90.95461538461538, -21.203076923076924, 1.3084615384615383, -69.53769230769231, -32.91307692307692], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=11.0
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-59.9, 91.005, -21.22, 1.315, -69.605, -32.91], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=11.8
[DAEMON 16:04:30] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:30] cmd received: send_angles
[DAEMON 16:04:30] send_angles 呼び出し前: angles=[-61.83076923076923, 91.05538461538461, -21.236923076923077, 1.3215384615384616, -69.6723076923077, -32.90692307692308], speed=20, wait=0.0
[DAEMON 16:04:30] send_angles 呼び出し後: result=None, elapsed_ms=9.1
[DAEMON 16:04:31] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:31] cmd received: send_angles
[DAEMON 16:04:31] send_angles 呼び出し前: angles=[-63.76153846153846, 91.10576923076923, -21.253846153846155, 1.328076923076923, -69.73961538461539, -32.90384615384615], speed=20, wait=0.0
[DAEMON 16:04:31] send_angles 呼び出し後: result=None, elapsed_ms=10.1
[DAEMON 16:04:31] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:31] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:31] cmd received: send_angles
[DAEMON 16:04:31] send_angles 呼び出し前: angles=[-65.6923076923077, 91.15615384615384, -21.270769230769233, 1.3346153846153845, -69.80692307692308, -32.90076923076923], speed=20, wait=0.0
[DAEMON 16:04:31] send_angles 呼び出し後: result=None, elapsed_ms=10.7
[DAEMON 16:04:31] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:31] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] cmd received: send_angles
[DAEMON 16:04:32] send_angles 呼び出し前: angles=[-67.62307692307692, 91.20653846153846, -21.287692307692307, 1.3411538461538461, -69.87423076923078, -32.89769230769231], speed=20, wait=0.0
[DAEMON 16:04:32] send_angles 呼び出し後: result=None, elapsed_ms=11.8
[DAEMON 16:04:32] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] cmd received: send_angles
[DAEMON 16:04:32] send_angles 呼び出し前: angles=[-69.55384615384615, 91.25692307692307, -21.304615384615385, 1.3476923076923075, -69.94153846153847, -32.894615384615385], speed=20, wait=0.0
[DAEMON 16:04:32] send_angles 呼び出し後: result=None, elapsed_ms=9.3
[DAEMON 16:04:32] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] cmd received: send_angles
[DAEMON 16:04:32] send_angles 呼び出し前: angles=[-71.48461538461538, 91.30730769230769, -21.321538461538463, 1.3542307692307691, -70.00884615384616, -32.89153846153846], speed=20, wait=0.0
[DAEMON 16:04:32] send_angles 呼び出し後: result=None, elapsed_ms=11.0
[DAEMON 16:04:32] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] cmd received: send_angles
[DAEMON 16:04:32] send_angles 呼び出し前: angles=[-73.41538461538462, 91.3576923076923, -21.33846153846154, 1.3607692307692307, -70.07615384615384, -32.888461538461534], speed=20, wait=0.0
[DAEMON 16:04:32] send_angles 呼び出し後: result=None, elapsed_ms=11.4
[DAEMON 16:04:32] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:32] cmd received: send_angles
[DAEMON 16:04:32] send_angles 呼び出し前: angles=[-75.34615384615384, 91.40807692307692, -21.355384615384615, 1.3673076923076923, -70.14346153846154, -32.885384615384616], speed=20, wait=0.0
[DAEMON 16:04:32] send_angles 呼び出し後: result=None, elapsed_ms=11.3
[DAEMON 16:04:32] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:33] cmd received: send_angles
[DAEMON 16:04:33] send_angles 呼び出し前: angles=[-77.27692307692308, 91.45846153846153, -21.372307692307693, 1.3738461538461537, -70.21076923076923, -32.88230769230769], speed=20, wait=0.0
[DAEMON 16:04:33] send_angles 呼び出し後: result=None, elapsed_ms=9.4
[DAEMON 16:04:33] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:33] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:33] cmd received: send_angles
[DAEMON 16:04:33] send_angles 呼び出し前: angles=[-79.2076923076923, 91.50884615384615, -21.38923076923077, 1.3803846153846153, -70.27807692307692, -32.879230769230766], speed=20, wait=0.0
[DAEMON 16:04:33] send_angles 呼び出し後: result=None, elapsed_ms=10.6
[DAEMON 16:04:33] send_angles_after: get_angles success retry=1 angles=[-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:33] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:33] cmd received: send_angles
[DAEMON 16:04:33] send_angles 呼び出し前: angles=[-81.13846153846154, 91.55923076923077, -21.40615384615385, 1.386923076923077, -70.34538461538462, -32.87615384615384], speed=20, wait=0.0
[DAEMON 16:04:33] send_angles 呼び出し後: result=None, elapsed_ms=11.1
[DAEMON 16:04:33] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:34] cmd received: send_angles
[DAEMON 16:04:34] send_angles 呼び出し前: angles=[-83.06923076923077, 91.60961538461538, -21.423076923076923, 1.3934615384615383, -70.41269230769231, -32.87307692307692], speed=20, wait=0.0
[DAEMON 16:04:34] send_angles 呼び出し後: result=None, elapsed_ms=10.1
[DAEMON 16:04:34] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:34] cmd received: send_angles
[DAEMON 16:04:34] send_angles 呼び出し前: angles=[-85.0, 91.66, -21.44, 1.4, -70.48, -32.87], speed=20, wait=0.0
[DAEMON 16:04:34] send_angles 呼び出し後: result=None, elapsed_ms=10.6
[DAEMON 16:04:34] send_angles 後の現在角度: [-34.8, 90.35, -21.0, 1.23, -68.73, -32.95]
[DAEMON 16:04:34] cmd received: get_angles
[DAEMON 16:04:34] cmd received: get_angles
[DAEMON 16:04:35] cmd received: get_angles
[DAEMON 16:04:35] cmd received: get_angles
[DAEMON 16:04:35] cmd received: get_angles
[DAEMON 16:04:36] cmd received: get_angles
[DAEMON 16:04:36] cmd received: get_angles
[DAEMON 16:04:36] cmd received: get_angles
[DAEMON 16:04:36] cmd received: get_angles
[DAEMON 16:04:37] cmd received: get_angles
[DAEMON 16:04:37] cmd received: get_angles
[DAEMON 16:04:37] cmd received: get_angles
[DAEMON 16:04:38] cmd received: get_angles
[DAEMON 16:04:38] cmd received: get_angles
[DAEMON 16:04:38] cmd received: get_angles
[DAEMON 16:04:39] cmd received: get_angles
[DAEMON 16:04:39] cmd received: get_angles
[DAEMON 16:04:39] cmd received: get_angles
[DAEMON 16:04:40] cmd received: get_angles
[DAEMON 16:04:40] cmd received: get_angles
[DAEMON 16:04:40] cmd received: get_angles
[DAEMON 16:04:41] cmd received: get_angles
[DAEMON 16:04:41] cmd received: get_angles
[DAEMON 16:04:41] cmd received: get_angles
[DAEMON 16:04:42] cmd received: get_angles
[DAEMON 16:04:42] cmd received: get_angles
[DAEMON 16:04:42] cmd received: get_angles
[DAEMON 16:04:43] cmd received: get_angles
[DAEMON 16:04:43] cmd received: get_angles
[DAEMON 16:04:43] cmd received: get_angles
[DAEMON 16:04:44] cmd received: set_fresh_mode
[DAEMON 16:04:44] set_fresh_mode(0)
[DAEMON 16:04:44] 切断: ('192.168.2.2', 63045)
08_home_from_anywhere.py 連続実行(1回目無反応・2回目即到達)。
(base) shimazueiichi@shimadzueiichinoMacBook-Pro physical-ai-todo % python3 ~/r2r2r-scripts/dynamic_tracking_limits/place/place_modules/08_home_from_anywhere.py
[INIT] daemon 接続中...
  [Pi] fresh_mode=1
[INIT] fresh_mode=1
[PRE]  現在姿勢: [-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
[SEND] HOME へ移動指令
[WAIT] t=0.9s  max_err=50.88°
[WAIT] t=1.4s  max_err=50.88°
[WAIT] t=1.9s  max_err=50.88°
[WAIT] t=2.4s  max_err=50.88°
[WAIT] t=3.0s  max_err=50.88°
[WAIT] t=3.5s  max_err=50.88°
[WAIT] t=4.0s  max_err=50.88°
[WAIT] t=4.5s  max_err=50.88°
[WAIT] t=5.1s  max_err=50.88°
[WAIT] t=5.6s  max_err=50.88°
[WAIT] t=6.1s  max_err=50.88°
[WAIT] t=6.6s  max_err=50.88°
[WAIT] t=7.1s  max_err=50.88°
[WAIT] t=7.7s  max_err=50.88°
[WAIT] t=8.2s  max_err=50.88°
[WAIT] t=8.7s  max_err=50.88°
[WAIT] t=9.2s  max_err=50.88°
[WAIT] t=9.8s  max_err=50.88°
[WAIT] t=10.3s  max_err=50.88°
[WAIT] t=10.8s  max_err=50.88°
[WAIT] t=11.3s  max_err=50.88°
[WAIT] t=11.9s  max_err=50.88°
[WAIT] t=12.4s  max_err=50.88°
[WAIT] t=12.9s  max_err=50.88°
[WAIT] t=13.4s  max_err=50.88°
[WAIT] t=14.0s  max_err=50.88°
[WAIT] t=14.5s  max_err=50.88°
[WAIT] t=15.0s  max_err=50.88°
[WAIT] t=15.5s  max_err=50.88°
[WAIT] t=16.0s  max_err=50.88°
[WAIT] t=16.6s  max_err=50.88°
[WAIT] t=17.1s  max_err=50.88°
[WAIT] t=17.6s  max_err=50.88°
[WAIT] t=18.1s  max_err=50.88°
[WAIT] t=18.7s  max_err=50.88°
[WAIT] t=19.2s  max_err=50.88°
[WAIT] t=19.7s  max_err=50.88°
[WAIT] t=20.2s  max_err=50.88°
[WAIT] t=20.8s  max_err=50.88°
[WAIT] t=21.3s  max_err=50.88°
[WAIT] t=21.8s  max_err=50.88°
[WAIT] t=22.3s  max_err=50.88°
[WAIT] t=22.9s  max_err=50.88°
[WAIT] t=23.4s  max_err=50.88°
[WAIT] t=23.9s  max_err=50.88°
^C[INTERRUPT] Ctrl+C 検出
[POST] 最終姿勢: [-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
  [Pi] fresh_mode=0
[EXIT] fresh_mode=0, socket close
(base) shimazueiichi@shimadzueiichinoMacBook-Pro physical-ai-todo % python3 ~/r2r2r-scripts/dynamic_tracking_limits/place/place_modules/08_home_from_anywhere.py
[INIT] daemon 接続中...
  [Pi] fresh_mode=1
[INIT] fresh_mode=1
[PRE]  現在姿勢: [-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
[SEND] HOME へ移動指令
[WAIT] t=0.6s  max_err=38.40°
[WAIT] t=1.1s  max_err=23.11°
[WAIT] t=1.6s  max_err=7.99°
[WAIT] t=2.1s  max_err=2.54°
[WAIT] t=2.6s  max_err=2.54°
[WAIT] t=3.2s  max_err=2.54°
[WAIT] t=3.7s  max_err=2.46°
[DONE] HOME 到達 max_err=2.46°
[POST] 最終姿勢: [-0.35, 1.49, 0.79, -0.08, 2.46, -30.05]
  [Pi] fresh_mode=0
[EXIT] fresh_mode=0, socket close
08実行時のdaemonログ。
[DAEMON 16:28:12] 接続: ('192.168.2.2', 63708)
[DAEMON 16:28:12] cmd received: ping
[DAEMON 16:28:12] cmd received: set_fresh_mode
[DAEMON 16:28:12] set_fresh_mode(1)
[DAEMON 16:28:12] cmd received: get_angles
[DAEMON 16:28:12] cmd received: send_angles
[DAEMON 16:28:12] send_angles 呼び出し前: angles=[0, 0, 0, 0, 0, -30], speed=20, wait=0.0
[DAEMON 16:28:12] send_angles 呼び出し後: result=None, elapsed_ms=12.0
[DAEMON 16:28:12] send_angles_after: get_angles success retry=1 angles=[-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
[DAEMON 16:28:12] send_angles 後の現在角度: [-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
[DAEMON 16:28:13] cmd received: get_angles
[DAEMON 16:28:13] cmd received: get_angles
[DAEMON 16:28:14] cmd received: get_angles
[DAEMON 16:28:14] cmd received: get_angles
[DAEMON 16:28:15] cmd received: get_angles
[DAEMON 16:28:15] cmd received: get_angles
[DAEMON 16:28:16] cmd received: get_angles
[DAEMON 16:28:16] cmd received: get_angles
[DAEMON 16:28:17] cmd received: get_angles
[DAEMON 16:28:17] cmd received: get_angles
[DAEMON 16:28:18] cmd received: get_angles
[DAEMON 16:28:19] cmd received: get_angles
[DAEMON 16:28:19] cmd received: get_angles
[DAEMON 16:28:20] cmd received: get_angles
[DAEMON 16:28:20] cmd received: get_angles
[DAEMON 16:28:21] cmd received: get_angles
[DAEMON 16:28:21] cmd received: get_angles
[DAEMON 16:28:22] cmd received: get_angles
[DAEMON 16:28:22] cmd received: get_angles
[DAEMON 16:28:23] cmd received: get_angles
[DAEMON 16:28:23] cmd received: get_angles
[DAEMON 16:28:24] cmd received: get_angles
[DAEMON 16:28:24] cmd received: get_angles
[DAEMON 16:28:25] cmd received: get_angles
[DAEMON 16:28:25] cmd received: get_angles
[DAEMON 16:28:26] cmd received: get_angles
[DAEMON 16:28:26] cmd received: get_angles
[DAEMON 16:28:27] cmd received: get_angles
[DAEMON 16:28:27] cmd received: get_angles
[DAEMON 16:28:28] cmd received: get_angles
[DAEMON 16:28:28] cmd received: get_angles
[DAEMON 16:28:29] cmd received: get_angles
[DAEMON 16:28:29] cmd received: get_angles
[DAEMON 16:28:30] cmd received: get_angles
[DAEMON 16:28:31] cmd received: get_angles
[DAEMON 16:28:31] cmd received: get_angles
[DAEMON 16:28:32] cmd received: get_angles
[DAEMON 16:28:32] cmd received: get_angles
[DAEMON 16:28:33] cmd received: get_angles
[DAEMON 16:28:33] cmd received: get_angles
[DAEMON 16:28:34] cmd received: get_angles
[DAEMON 16:28:34] cmd received: get_angles
[DAEMON 16:28:35] cmd received: get_angles
[DAEMON 16:28:35] cmd received: get_angles
[DAEMON 16:28:36] cmd received: get_angles
[DAEMON 16:28:36] cmd received: get_angles
[DAEMON 16:28:36] cmd received: set_fresh_mode
[DAEMON 16:28:36] set_fresh_mode(0)
[DAEMON 16:28:36] 切断: ('192.168.2.2', 63708)
[DAEMON 16:28:37] 接続: ('192.168.2.2', 63719)
[DAEMON 16:28:37] cmd received: ping
[DAEMON 16:28:37] cmd received: set_fresh_mode
[DAEMON 16:28:37] set_fresh_mode(1)
[DAEMON 16:28:37] cmd received: get_angles
[DAEMON 16:28:38] cmd received: send_angles
[DAEMON 16:28:38] send_angles 呼び出し前: angles=[0, 0, 0, 0, 0, -30], speed=20, wait=0.0
[DAEMON 16:28:38] send_angles 呼び出し後: result=None, elapsed_ms=11.7
[DAEMON 16:28:38] send_angles 後の現在角度: [-0.35, 1.49, 0.79, -0.08, 50.88, -30.14]
[DAEMON 16:28:38] cmd received: get_angles
[DAEMON 16:28:39] cmd received: get_angles
[DAEMON 16:28:39] cmd received: get_angles
[DAEMON 16:28:40] cmd received: get_angles
[DAEMON 16:28:40] cmd received: get_angles
[DAEMON 16:28:41] cmd received: get_angles
[DAEMON 16:28:41] cmd received: get_angles
[DAEMON 16:28:41] cmd received: get_angles
[DAEMON 16:28:41] cmd received: set_fresh_mode
[DAEMON 16:28:41] set_fresh_mode(0)
[DAEMON 16:28:41] 切断: ('192.168.2.2', 63719)
シンプル版の実行(HOMEから不動・抜粋ではなく提供範囲の全量)。
CAM] 上カメラ index = 2
[Mac] マット四隅検出中... (10フレーム)
[Mac] ✓ マット四隅検出: 10/10 フレーム成功
[Mac] ✓ 動的homography計算完了
[Mac] ✓ マット範囲: X=[374, 1578] Y=[101, 961]
[CAM] homography OK
[OUT] JSON  : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_simple_02.json
[OUT] frames: /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_simple_02_frames/
--- [ 1/20] j0_cmd=-85.00° target=[ -85.00,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[ 1/20] send_angles (single)  speed=20  pre max|Δ|=90.43° → sleep 9.04s
[ 1/20] actual = [  +0.00,   +1.93,   +1.66,   +0.17,   +0.17,  -29.70]
[ 1/20] detect OK: xz=(+0.010, +0.316) (red_block pixel=(964, 872))
--- [ 2/20] j0_cmd=-76.05° target=[ -76.05,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[ 2/20] send_angles (single)  speed=20  pre max|Δ|=89.73° → sleep 8.97s
[ 2/20] actual = [  +0.00,   +1.93,   +1.66,   +0.17,   +0.17,  -29.70]
[ 2/20] detect OK: xz=(+0.010, +0.316) (red_block pixel=(963, 873))
--- [ 3/20] j0_cmd=-67.11° target=[ -67.11,  +91.66,  -21.44,   +1.40,  -70.48,  -32.87] ---
[ 3/20] send_angles (single)  speed=20  pre max|Δ|=89.73° → sleep 8.97s
j1=88.0の1点検証(_18)。
(base) shimazueiichi@shimadzueiichinoMacBook-Pro place_modules % python3 j0_sweep_scan.py --phase pick --base-angles="-36.03,88.0,-21.44,1.4,-70.48,-32.87" --j0-min=-36.03 --j0-max=-36.03 --step=1
[INIT] reach_tol_deg = 3.00° (phase=pick)
[INIT] base_angles を CLI で直接指定(teach JSON 抽出はスキップ)
[INIT] phase=pick 基準姿勢: [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87]
[INIT] 抽出根拠: cli_direct: -36.03,88.0,-21.44,1.4,-70.48,-32.87
[INIT] 教示時 j0 = -36.03°
[INIT] スイープ点 (1 点): -36.03
[INIT] JOINT_LIMITS 一括検査 ...
[INIT] JOINT_LIMITS OK (base + 1 スイープ点)
[INIT] daemon 接続中 ...
[INIT] daemon ping OK
[Pi] fresh_mode=1
[INIT] fresh_mode=1
[INIT] 現在姿勢を取得(最大 12 回・0.2s 間隔・ゴミ読みフィルタ)
[INIT] 現在姿勢 = [ +0.00, +1.93, +1.66, +0.17, +0.17, -29.70]
[INIT] 現在 → 基準姿勢 max|Δ| = 86.07°
[WARN] 先頭移動の max|Δ| 86.07° > 30.0°。急加速の可能性があります
[INIT] 続行するには 'yes' と入力(それ以外は中止)
yes
[CAM] 接続中カメラ一覧:
index=0 name=FaceTime HDカメラ
index=1 name=Iriun Camera
index=2 name=iPhone14 Pro MAXのカメラ
[CAM] 上カメラ(iPhone) index=2
[CAM] 横カメラ(Iriun) index=1
[CAM] 上カメラ index = 2
[Mac] マット四隅検出中... (10フレーム)
[Mac] ✓ マット四隅検出: 10/10 フレーム成功
[Mac] ✓ 動的homography計算完了
[Mac] ✓ マット範囲: X=[364, 1572] Y=[108, 981]
[CAM] homography OK
[CONFIRM] phase=pick → 検出対象=赤ブロック。爪に赤ブロックを咥えさせた状態にしてください。OK なら Enter
[OUT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_18.json
[OUT] frames: /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_18_frames/
[MOVE] 基準姿勢(教示時 j0=-36.03°)へ移動 ...
[SEND] to base: send_angles (single) [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=86.07°, post-send timeout 14.9s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
--- [ 1/ 1] j0_cmd=-36.03° target=[ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87] ---
[SEND] [ 1/ 1] j0=-36.03: send_angles (single) [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=1.32°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[ 1/ 1] settle 1.0s
[ 1/ 1] actual = [ -35.50, +89.12, -20.12, +1.49, -69.34, -32.51]
[ 1/ 1] detect OK: xz=(+0.196, +0.242) (red_block pixel=(590, 741))
[SWEEP] 完了: 検出成功 1/1, 失敗 0
[MOVE] 基準姿勢へ復帰 ...
[SEND] back to base: send_angles (single) [ -36.03, +88.00, -21.44, +1.40, -70.48, -32.87] speed=20 (pre max|Δ|=1.32°, post-send timeout 8.0s)
[SEND] arrival OK: max|Δ|=1.32° (tol 3.0°)
[Pi] fresh_mode=0
[EXIT] JSON : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_18.json
[EXIT] frames : /Users/shimazueiichi/r2r2r-scripts/dynamic_tracking_limits/logs/j0_sweep/j0_sweep_pick_18_frames (1 files)_19のJSON(19点中18点・全量)。
{
  "phase": "pick",
  "detect_target": "red_block",
  "base_angles": [
    -36.03,
    88.0,
    -21.44,
    1.4,
    -70.48,
    -32.87
  ],
  "source_teach_json": null,
  "base_source": "cli_direct: -36.03,88.0,-21.44,1.4,-70.48,-32.87",
  "height_note": "床面homography基準。工程をまたぐ位置データの混用禁止",
  "frames_dir": "j0_sweep_pick_19_frames/",
  "sweep_params": {
    "j0_min": -85.0,
    "j0_max": 85.0,
    "step": 8.95,
    "settle_sec": 1.0,
    "n_points": 19,
    "speed": 20,
    "tol_reach_deg": 3.0,
    "no_move": false
  },
  "sweep": [
    {
      "j0_cmd": -85.0,
      "angles_actual": [
        -84.72,
        89.12,
        -20.12,
        1.49,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.31152346801757813,
        0.007356892585754395
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-085.0.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -76.05,
      "angles_actual": [
        -75.84,
        89.12,
        -20.12,
        1.05,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.3068103942871094,
        0.056832714080810545
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-076.0.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -67.1,
      "angles_actual": [
        -67.41,
        89.12,
        -20.12,
        1.14,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.294947509765625,
        0.10178321838378906
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-067.1.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -58.15,
      "angles_actual": [
        -58.35,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.27594622802734375,
        0.1475557403564453
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-058.1.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -49.2,
      "angles_actual": [
        -49.3,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.24938540649414062,
        0.18951194763183593
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-049.2.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -40.25,
      "angles_actual": [
        -40.42,
        89.12,
        -20.12,
        1.14,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.21734461975097658,
        0.22566352844238283
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-040.2.jpg",
      "send_retried": true
    },
    {
      "j0_cmd": -31.3,
      "angles_actual": [
        -31.11,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.17722288513183593,
        0.2571953430175781
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-031.3.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -22.35,
      "angles_actual": [
        -22.32,
        89.12,
        -20.12,
        1.23,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.13513058471679687,
        0.281521240234375
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-022.4.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -13.4,
      "angles_actual": [
        -13.18,
        89.12,
        -20.12,
        1.14,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.08840620422363281,
        0.2987588195800781
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-013.4.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": -4.45,
      "angles_actual": [
        -4.74,
        89.12,
        -20.12,
        1.23,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        0.04311785888671875,
        0.3078060302734375
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_-004.5.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 4.5,
      "angles_actual": [
        4.3,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.007521985530853272,
        0.3108388366699219
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+004.5.jpg",
      "send_retried": true
    },
    {
      "j0_cmd": 13.45,
      "angles_actual": [
        13.53,
        89.12,
        -20.12,
        1.4,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.05796367263793945,
        0.3061882019042969
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+013.4.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 22.4,
      "angles_actual": [
        22.23,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.10411856079101563,
        0.29422921752929687
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+022.4.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 31.35,
      "angles_actual": [
        31.37,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.15024888610839843,
        0.27392694091796876
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+031.4.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 40.3,
      "angles_actual": [
        40.16,
        89.12,
        -20.12,
        1.14,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.19054719543457033,
        0.24817266845703126
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+040.3.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 49.25,
      "angles_actual": [
        49.48,
        89.12,
        -20.12,
        1.31,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.22772747802734375,
        0.21430802917480468
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+049.2.jpg",
      "send_retried": true
    },
    {
      "j0_cmd": 58.2,
      "angles_actual": [
        58.09,
        89.12,
        -20.12,
        0.96,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.2578714294433594,
        0.17739671325683595
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+058.2.jpg",
      "send_retried": false
    },
    {
      "j0_cmd": 67.15,
      "angles_actual": [
        67.06,
        89.12,
        -20.12,
        1.14,
        -70.75,
        -32.51
      ],
      "detect_xz_m": [
        -0.282582763671875,
        0.1352918701171875
      ],
      "detect_score": null,
      "detect_ok": true,
      "frame_file": "j0_+067.2.jpg",
      "send_retried": false
    }
  ]
}